Host Computer System.pdf - 第45页
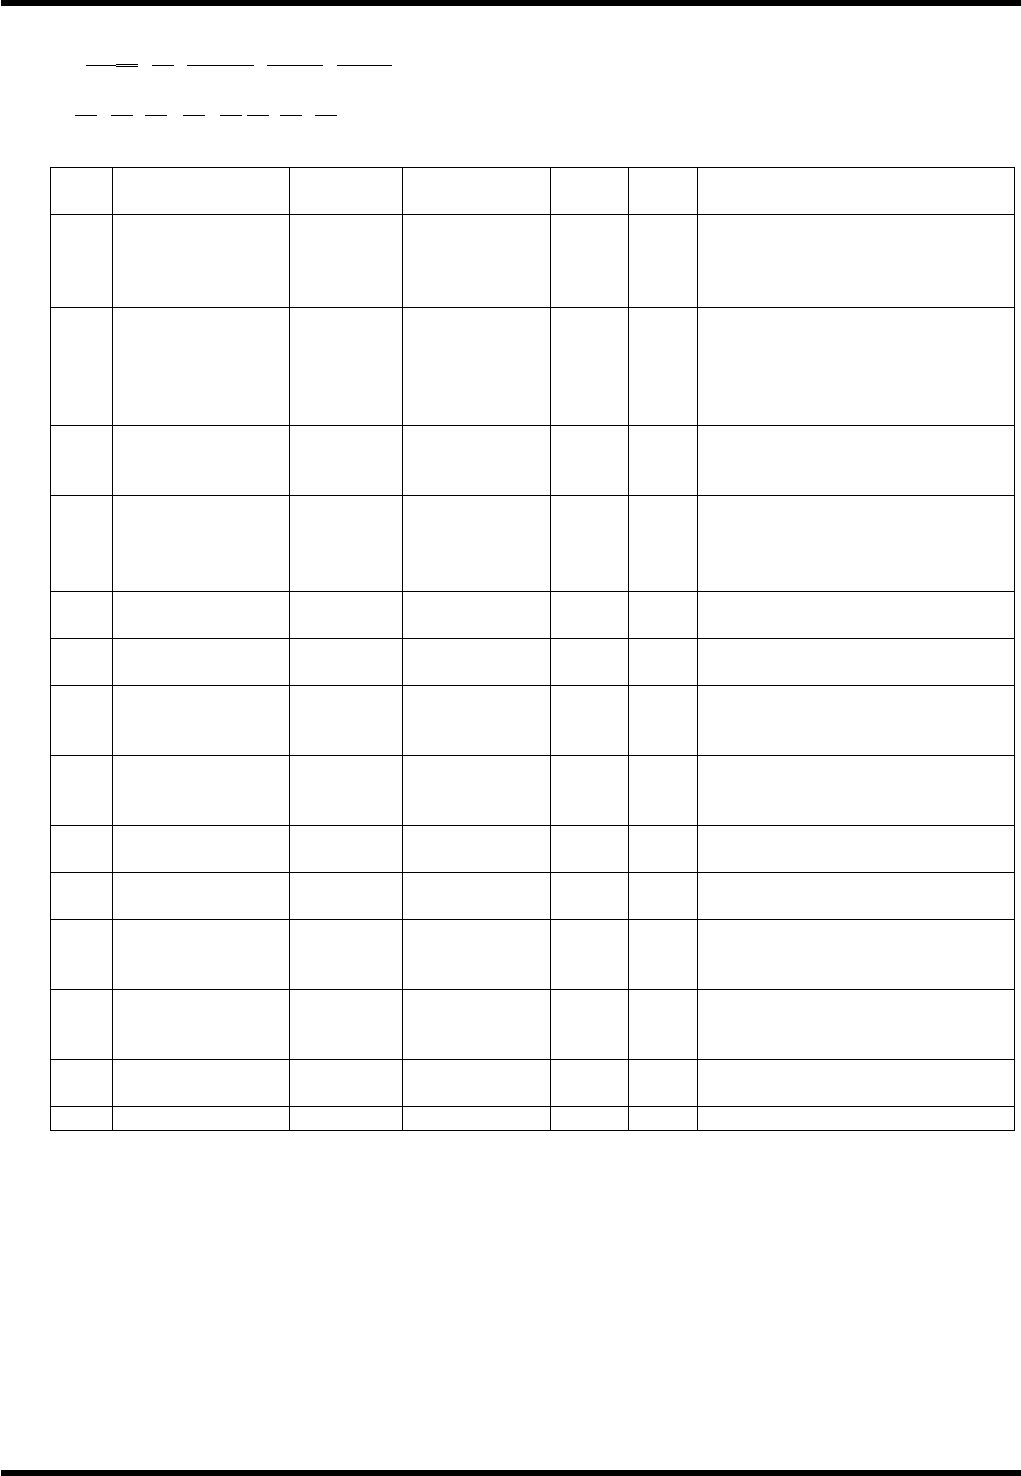
AVK3 HOST COMPUTER SYSTEM 2.4 Downloadi ng Indiv idual M achi ne Dat a D77HEC-52- 050A0 2.4- 14 1) - 36 D0LO A( ± ) nnnnnn B( ± )nnnnnn C( ± )nnnnnn D( ± )nnnnnn 1 2 3 4 5 E( ± )nnnnnn F( ± )nnnnnn 6 7 No. Data name Ma…
AVK3
HOST COMPUTER SYSTEM
2.4 Downloading Individual Machine Data
D77HEC-52-050A0
2.4-13
1) - 35
D0DGnnPnnAnnnnnnBnnnnnCnnnnn
1 2 3 4 5 6
Dnn
EnnFnnGnnHnnInnJnnKnn
7 8 9 10 11 12 13 14
No. Data name
Max.
digits
Input range
Sup-
press
Vari-
able
Remarks
1
Driver gain
command
2
× ×
Acknowledges as the set data
of driver gain.
When it is omitted, the
following data will be ignored.
2
NC axis
designation
2 01 to 14
×
01: X, 02: Y, 03: ZL,
04: H, 05: θH, 06: θA,
07: ZR, 08: U, 09: WH,
10: WA, 11: V, 12: T, 13: X2
14: Y2
3 Pattern No. 2 01 to 13
×
01 to 10: Pattern No.
11: ORG, 12: TCH (L),
13: TCH (H)
4 Distance to move 6 0 to 999999
+ direction only.
ZL, ZR axis: 0-120
1 / 100 mm, 1 / 100° (H, θH,
θA, T), feeder (ZL, ZR)
5 Maximum speed 5 0 to 65535
+ direction only.
100pps
6 Acceleration 5 0 to 65535
+ direction only.
10Kpps
2
7
Position
proportional gain
(in motion)
2 0 to 31
+ direction only.
8
Speed
proportional gain
(in motion)
2 0 to 31
+ direction only.
9
Speed integral
gain (in motion)
2 0 to 31
+ direction only.
10
Feed forward
gain (in motion)
2 0 to 31
+ direction only.
11
Position
proportional gain
(in stop)
2 0 to 31
+ direction only.
12
Speed
proportional gain
(in stop)
2 0 to 31
+ direction only.
13
Speed integral
gain (in stop)
2 0 to 31
+ direction only.
14 Changeover time 2 0 to 31 + direction only.
=REMARKS=
If the data of 2 to 14 is out of range, 0 is returned.
AVK3
HOST COMPUTER SYSTEM
2.4 Downloading Individual Machine Data
D77HEC-52-050A0
2.4-14
1) - 36
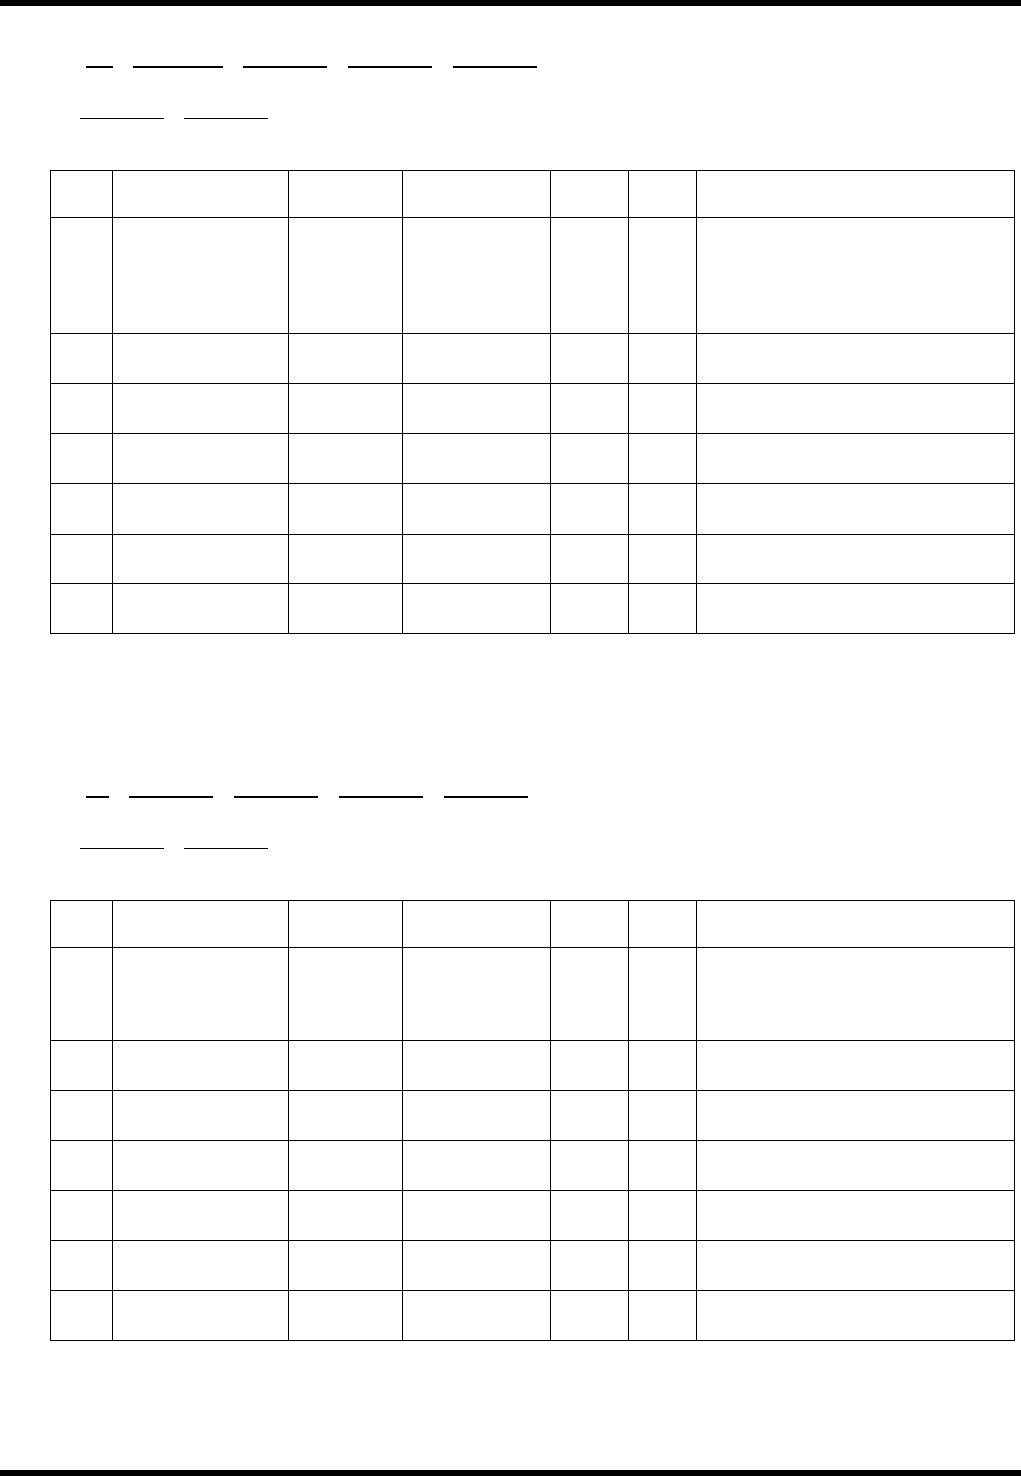
D0LOA(±) nnnnnnB(±)nnnnnnC(±)nnnnnnD(±)nnnnnn
1 2 3 4 5
E(±)nnnnnn
F(±)nnnnnn
6 7
No. Data name
Max.
digits
Input range
Sup-
press
Vari-
able
Remarks
1
Width control
data origin
position
command
2
× ×
Acknowledges as the set data
of width control data origin
position.
When it is omitted, the
following data will be ignored.
2
1st axis origin
position
7
-999999 to
+999999
Max. digit includes ±.
µm
3
2nd axis origin
position
7
-999999 to
+999999
Max. digit includes ±.
µm
4
3rd axis origin
position
7
-999999 to
+999999
Max. digit includes ±.
µm
5
4th axis origin
position
7
-999999 to
+999999
Max. digit includes ±.
µm
6
5th axis origin
position
7
-999999 to
+999999
Max. digit includes ±.
µm
7
6th axis origin
position
7
-999999 to
+999999
Max. digit includes ±.
µm
=REMARKS=
When automatic width control is valid, data will be valid.
1) - 37
D0LFA(±)nnnnnnB(±)nnnnnnC(±)nnnnnnD(±)nnnnnn
1 2 3 4 5
E(±)nnnnnn
F(±)nnnnnn
6 7
No. Data name
Max.
digits
Input range
Sup-
press
Vari-
able
Remarks
1
Width control
data offset
command
2
× ×
Acknowledges as the set data
of width control data offset.
When it is omitted, the
following data will be ignored.
2 1st axis offset 7
-999999 to
+999999
Max. digit includes ±.
µm
3 2nd axis offset 7
-999999 to
+999999
Max. digit includes ±.
µm
4 3rd axis offset 7
-999999 to
+999999
Max. digit includes ±.
µm
5 4th axis offset 7
-999999 to
+999999
Max. digit includes ±.
µm
6 5th axis offset 7
-999999 to
+999999
Max. digit includes ±.
µm
7 6th axis offset 7
-999999 to
+999999
Max. digit includes ±.
µm
=REMARKS=
When automatic width control is valid, data will be valid.
AVK3
HOST COMPUTER SYSTEM
2.4 Downloading Individual Machine Data
D77HEC-52-050A0
2.4-15
1) - 38
D0LPRn
1 2
No. Data name
Max.
digits
Input range
Sup-
press
Vari-
able
Remarks
1
Width control
condition data
command
2
× ×
Acknowledges as the set data
of width control condition data.
When it is omitted, the
following data will be ignored.
2
Origin return in
automatic width
control
(in operating)
1 0 to 1
×
0: No, 1: Yes
=REMARKS=
When automatic width control is valid, data will be valid.
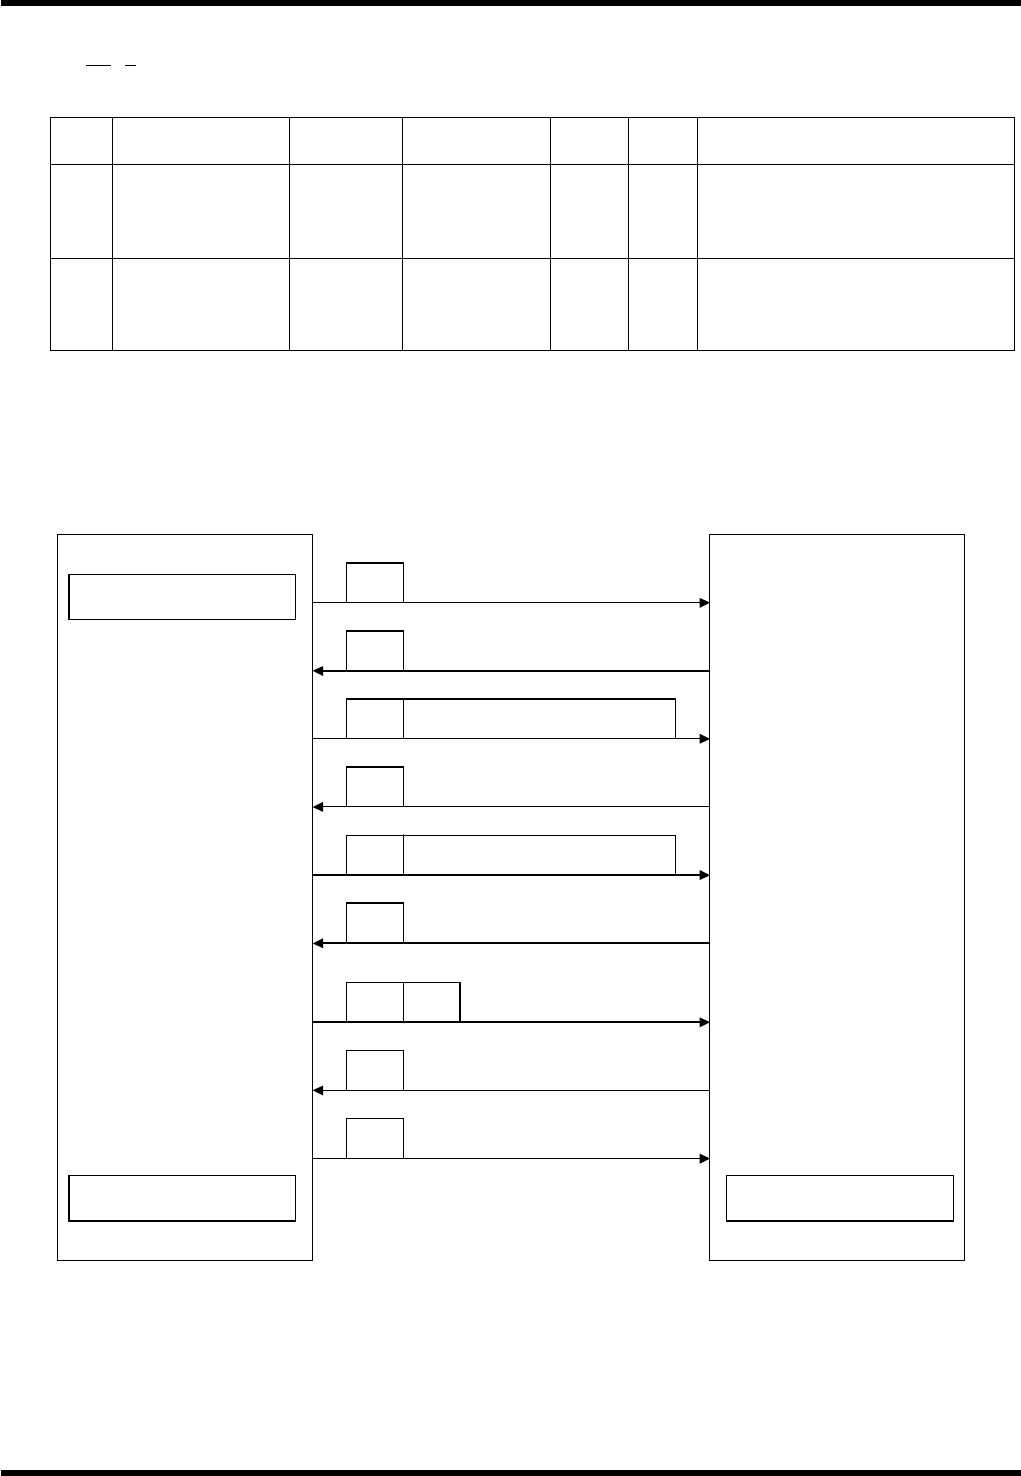
Protocol
Start of download
Host computer
Requests next data.
AVK3
D 0 Machine individual data
A 0
C0G
D 0
Machine individual data
Transfers machine
individual data.
A 0
Transfers machine
individual data.
Requests next data.
A 0
Transfers EOP data
D 0
∗
A 0
A 2
End of transmission
End of reception
Creates a directory.
Stores the received
machine individual data
in RAM.
Stores the received
machine individual data
in RAM.
Requests next data.