Host Computer System.pdf - 第74页
AVK3 HOST COMPUTER SYSTEM 3.4 Upl oading Indivi dual Machine Dat a D77HEC-53- 050-A0 3.4- 13 1) -35 D0LO A( ± ) nnnnnn B( ± )nnnnnn C( ± )nnnnnn D( ± )nnnnnn 1 2 3 4 5 E( ± )nnnnnn F( ± )nnnnnn 6 7 No. Data name Max. d…
AVK3
HOST COMPUTER SYSTEM
3.4 Uploading Individual Machine Data
D77HEC-53-050-A0
3.4-12
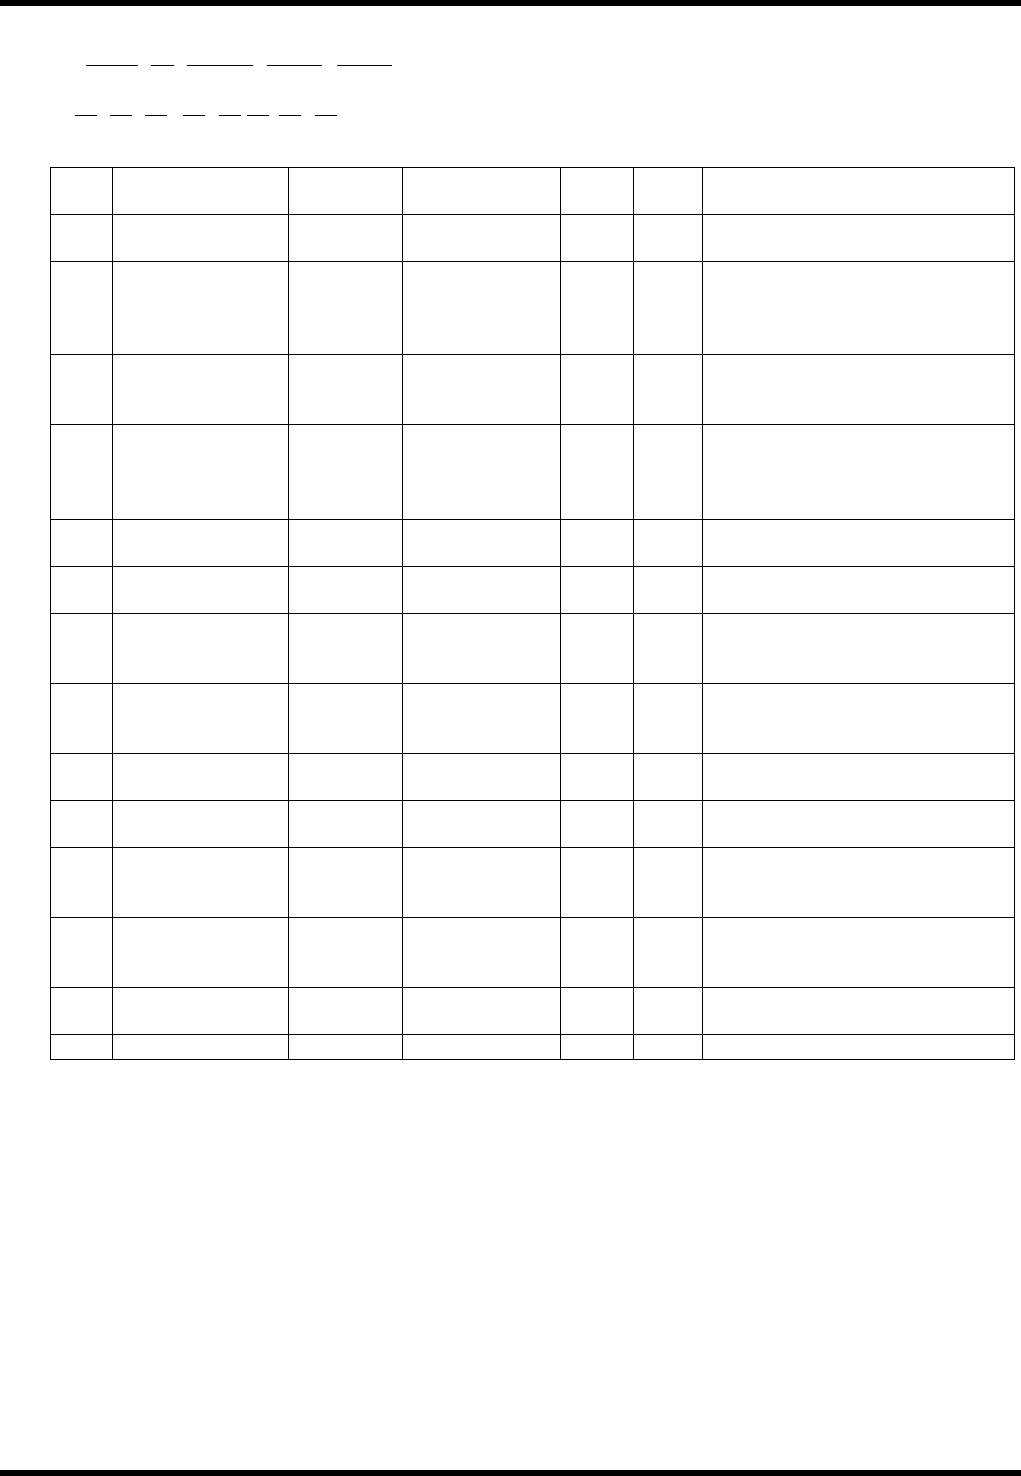
1) -34
D0DGnnPnnAnnnnnnBnnnnnCnnnnn
1 2 3 4 5 6
Dnn
EnnFnnGnnHnnInnJnnKnn
7 8 9 10 11 12 13 14
No. Data name
Max.
digits
Input range
Sup-
press
Fix Remarks
1
Driver gain
command
2
×
Output command for the driver
gain
2
NC axis
designation
2 01 to 12
×
01: X, 02: Y, 03: ZL, 04: H,
05: QH, 06: QA, 07: ZR,
08: U, 09: WH, 10: WA,
11: V, 12: T, 13: X2, 14: Y2
3 Pattern No. 2 01 to 13
×
01 to 10: Pattern No.
11: ORG, 12: TCH (L),
13: TCH (H)
4 Distance to move 6 0 to 999999
×
+ direction only
ZL, ZR axis: 0 - 120
1 / 100 mm, 1 / 100° (H, QH,
QA, T), feeder (ZL, ZR)
5 Maximum speed 5 0 to 65535
×
+ direction only
100pps
6 Acceleration 5 0 to 65535
×
+ direction only
10Kpps
2
7
Position
proportional gain
(in motion)
2 0 to 31
×
+ direction only
8
Speed
proportional gain
(in motion)
2 0 to 31
×
+ direction only
9
Speed integral
gain (in motion)
2 0 to 31
×
+ direction only
10
Feed forward
gain (in motion)
2 0 to 31
×
+ direction only
11
Position
proportional gain
(in stop)
2 0 to 31
×
+ direction only
12
Speed
proportional gain
(in stop)
2 0 to 31
×
+ direction only
13
Speed integral
gain (in stop)
2 0 to 31
×
+ direction only
14 Changeover time 2 0 to 31
×
+ direction only
AVK3
HOST COMPUTER SYSTEM
3.4 Uploading Individual Machine Data
D77HEC-53-050-A0
3.4-13
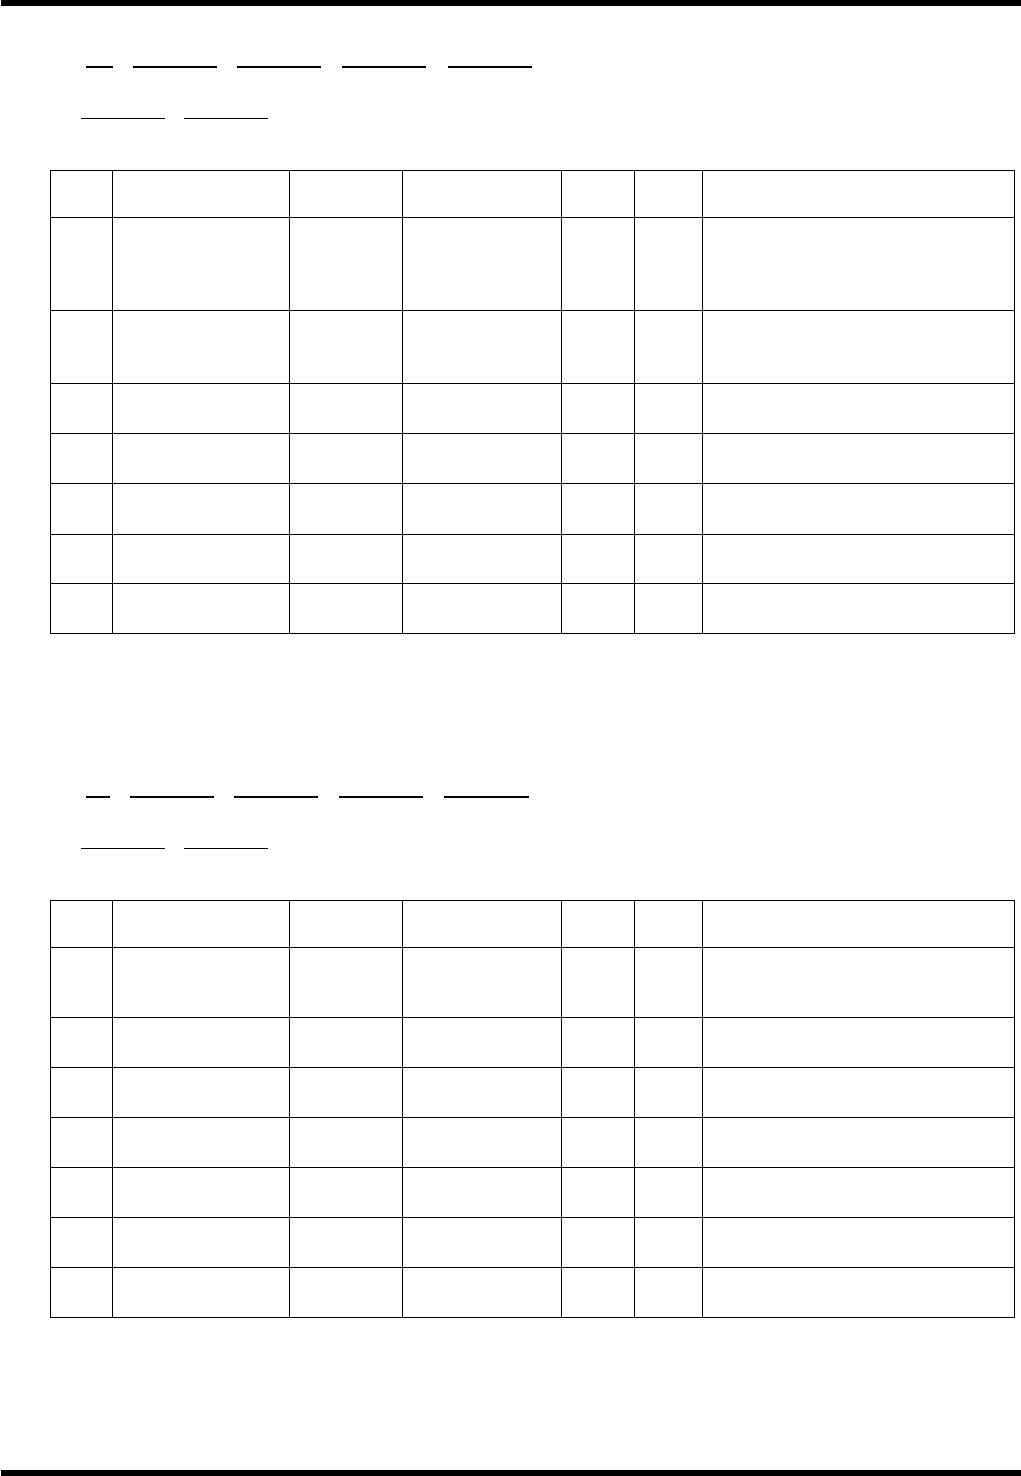
1) -35
D0LOA(±)nnnnnnB(±)nnnnnnC(±)nnnnnnD(±)nnnnnn
1 2 3 4 5
E(±)nnnnnn
F(±)nnnnnn
6 7
No. Data name
Max.
digits
Input range
Sup-
press
Fix Remarks
1
Width control
data origin
position
command
2
×
Output command for the width
control data origin position
2
1st axis origin
position
7
-999999 to
+999999
×
Max. digit includes ±.
µm
3
2nd axis origin
position
7
-999999 to
+999999
×
Max. digit includes ±.
µm
4
3rd axis origin
position
7
-999999 to
+999999
×
Max. digit includes ±.
µm
5
4th axis origin
position
7
-999999 to
+999999
×
Max. digit includes ±.
µm
6
5th axis origin
position
7
-999999 to
+999999
×
Max. digit includes ±.
µm
7
6th axis origin
position
7
-999999 to
+999999
×
Max. digit includes ±.
µm
=REMARKS=
When automatic width control is valid, data will be output.
1) -36
D0LFA(±)nnnnnnB(±)nnnnnnC(±)nnnnnnD(±)nnnnnn
1 2 3 4 5
E(±)nnnnnn
F(±)nnnnnn
6 7
No. Data name
Max.
digits
Input range
Sup-
press
Fix Remarks
1
Width control
data offset
command
2
×
Output command for the width
control data offset
2 1st axis offset 7
-999999 to
+999999
×
Max. digit includes ±.
µm
3 2nd axis offset 7
-999999 to
+999999
×
Max. digit includes ±.
µm
4 3rd axis offset 7
-999999 to
+999999
×
Max. digit includes ±.
µm
5 4th axis offset 7
-999999 to
+999999
×
Max. digit includes ±.
µm
6 5th axis offset 7
-999999 to
+999999
×
Max. digit includes ±.
µm
7 6th axis offset 7
-999999 to
+999999
×
Max. digit includes ±.
µm
=REMARKS=
When automatic width control is valid, data will be output.
AVK3
HOST COMPUTER SYSTEM
3.4 Uploading Individual Machine Data
D77HEC-53-050-A0
3.4-14
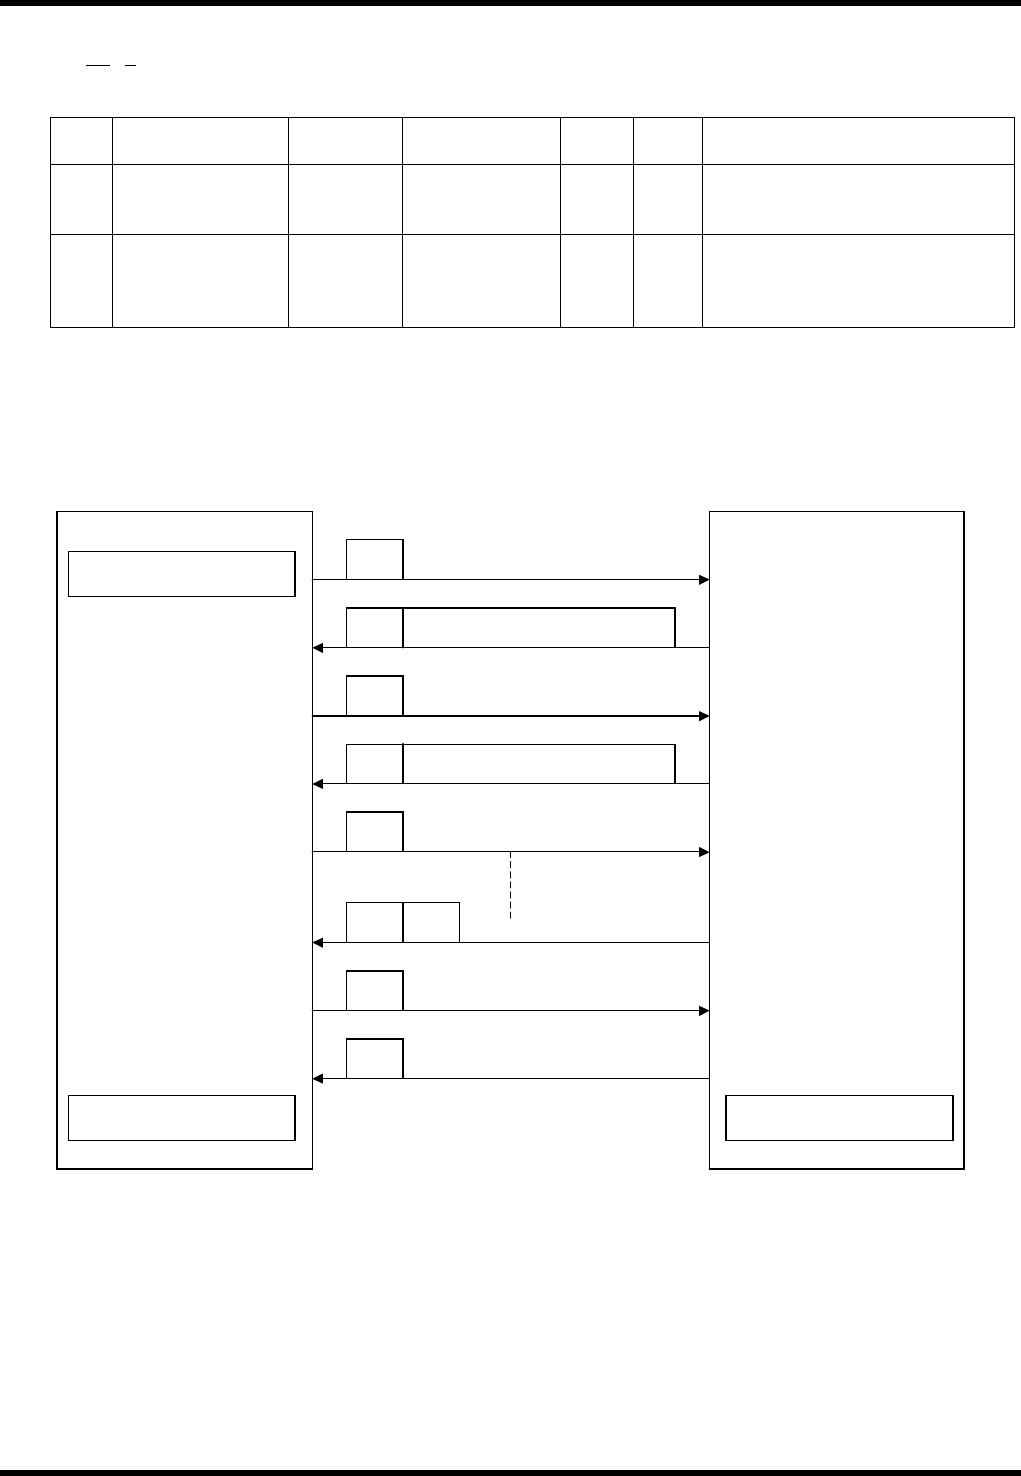
1) -37
D0LPRn
1 2
No. Data name
Max.
digits
Input range
Sup-
press
Fix Remarks
1
Width control
condition data
command
2
×
Output command for the width
control condition data
2
Origin return in
automatic width
control
(in operating)
1 0 to 1
×
0 = No, 1 = Yes
=REMARKS=
When automatic width control is valid, data will be output.
Protocol
Condition
Can be used in standard specification.
Valid in ONLINE mode only.
Start of upload
Host computer
Sends out machine
individual data.
AVK3
D 0 Machine individual data
A 0
C1G
D 0
Machine individual data
Requests next data.
A 0
Requests next data.
Sends out machine
individual data.
Sends out EOP data.
A 0
D 0
∗
A 2
End of transmission
End of reception