mi14061267.pdf - 第3页
Micromachines 2023 , 14 , 1267 3 of 17 compressed, and instantaneous pulsating high pressur e is generated in the cavity . Under the action of high pressure, the droplets are driven to converge at the nozzle and obtain k…
Micromachines 2023, 14, 1267 2 of 17
accuracy, fast dynamic response, simple structure, no electromagnetic interference and
green environment protection [19].
The existing piezoelectric micro-jet devices can be roughly divided into four structural
types: squeeze type, bend type, push type and shear type [
13
]. Ulmke et al. [
20
] proposed a
squeeze-type piezoelectric micro-jet device, which could generate droplets with a diameter
ranging from 10 microns to 100 microns, which was equivalent to the volume of the ejected
droplets as low as 0.6 pl. Li et al. [
21
] designed a bend-type piezoelectric micro-jet device
to realize the active lubrication of space bearings and micro-fluid lubrication on demand.
The minimum volume of oil ejected by the device could reach 0.012 L. Gross et al. [
22
]
proposed a push-type piezoelectric micro-jet device, which used a nozzle with a diameter
of 40 um and could control the droplet volume within the range of 100 PL to 250 PL. Cheng
et al. [
23
] proposed a shear-type piezoelectric printhead with a special polarization design,
and the maximum displacement was 400 nm at a driving voltage of 120 V
pp
.
Although the existing piezoelectric micro-jet devices have a series of advantages such
as high precision of injection control and fast dynamic response speed, they are still prone
to problems such as the existence of bubbles in the cavity, leading to the degradation of
injection performance or even failure, and complicated disassembly after the failure of
ceramics. In this work, a nozzle-driven piezoelectric micro-jet device is proposed, which
adopts a drive mode of nozzle vibration with piezoelectric ceramic pasted at the nozzle part.
Compared with the traditional cavity vibration method (in the traditional piezoelectric
micro-jet, the vibrator is a part of the fixed surface of the cavity, and the nozzle does not
move), the problem of reducing the injection performance due to the bubble entering the
cavity is avoided. Moreover, the external nozzle has stronger interchangeability. When
the ceramic is damaged, it is not necessary to disassemble the whole device and directly
re-paste the new ceramic.
2. Structure and Mechanism
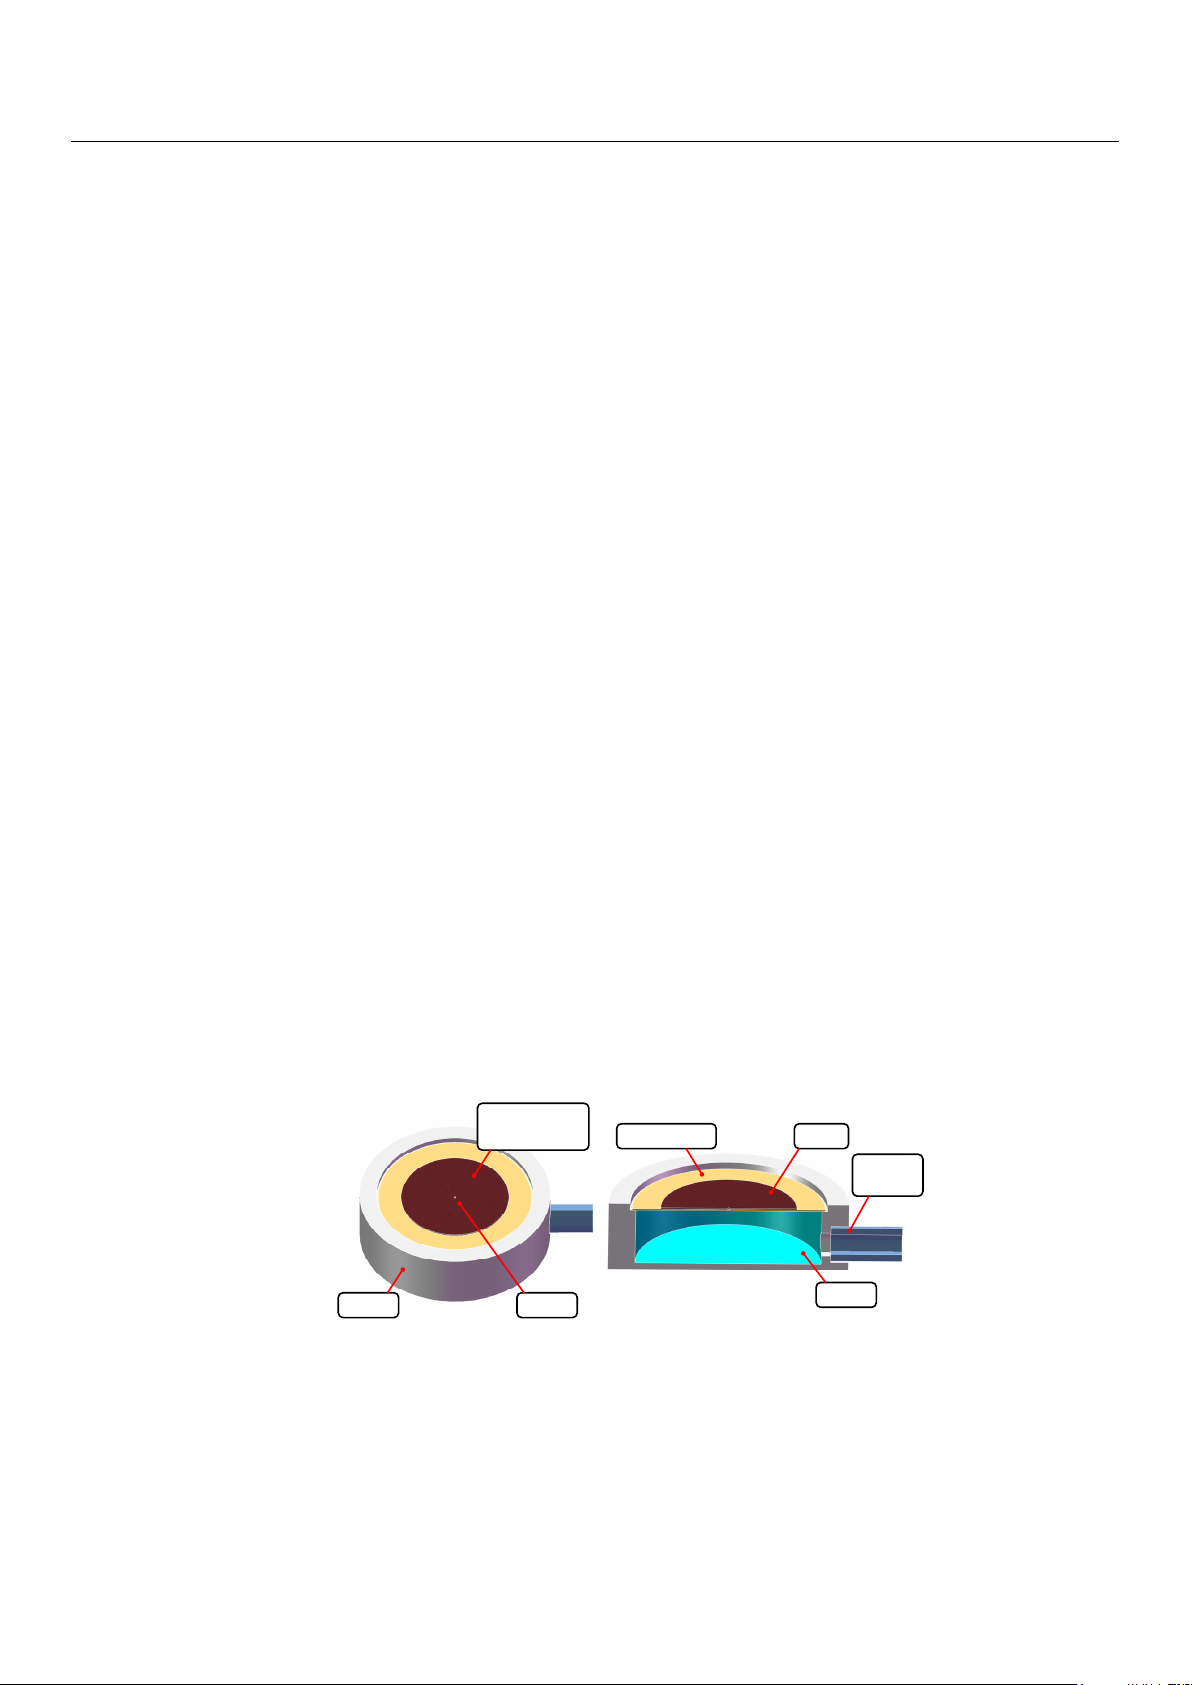
The nozzle-driven piezoelectric micro-jet device proposed in this work is shown in
Figure 1, in which Figure 1a is the overall structure and Figure 1b is the section view of
the device. The device is mainly composed of a piezoelectric vibrator, cavity and infusion
tube, through which, viscosity lubrication oil is transported and stored in the cavity. The
piezoelectric vibrator is the core component of the micro-jet device, which is composed
of a PZT ceramic and a copper sheet and is fixed on the cavity via epoxy resin. In order
to prevent the piezoelectric vibrator from short circuiting when it encounters viscous
lubrication oil, the external surface of the PZT ceramic is insulated.
Micromachines 2023, 14, x FOR PEER REVIEW 2 of 28
dynamic response, simple structure, no electromagnetic interference and green environ-
ment protection [19].
The existing piezoelectric micro-jet devices can be roughly divided into four struc-
tural types: squeeze type, bend type, push type and shear type [13]. Ulmke et al. [20] pro-
posed a squeeze-type piezoelectric micro-jet device, which could generate droplets with
a diameter ranging from 10 microns to 100 microns, which was equivalent to the volume
of the ejected droplets as low as 0.6 pl. Li et al. [21] designed a bend-type piezoelectric
micro-jet device to realize the active lubrication of space bearings and micro-fluid lubri-
cation on demand. The minimum volume of oil ejected by the device could reach 0.012 L.
Gross et al. [22] proposed a push-type piezoelectric micro-jet device, which used a nozzle
with a diameter of 40 um and could control the droplet volume within the range of 100
PL to 250 PL. Cheng et al. [23] proposed a shear-type piezoelectric printhead with a special
polarization design, and the maximum displacement was 400 nm at a driving voltage of
120 V
pp.
Although the existing piezoelectric micro-jet devices have a series of advantages such
as high precision of injection control and fast dynamic response speed, they are still prone
to problems such as the existence of bubbles in the cavity, leading to the degradation of
injection performance or even failure, and complicated disassembly after the failure of
ceramics. In this work, a nozzle-driven piezoelectric micro-jet device is proposed, which
adopts a drive mode of nozzle vibration with piezoelectric ceramic pasted at the nozzle
part. Compared with the traditional cavity vibration method (in the traditional piezoelec-
tric micro-jet, the vibrator is a part of the fixed surface of the cavity, and the nozzle does
not move), the problem of reducing the injection performance due to the bubble entering
the cavity is avoided. Moreover, the external nozzle has stronger interchangeability. When
the ceramic is damaged, it is not necessary to disassemble the whole device and directly
re-paste the new ceramic.
2. Structure and Mechanism
The nozzle-driven piezoelectric micro-jet device proposed in this work is shown in
Figure 1, in which Figure 1a is the overall structure and Figure 1b is the section view of
the device. The device is mainly composed of a piezoelectric vibrator, cavity and infusion
tube, through which, viscosity lubrication oil is transported and stored in the cavity. The
piezoelectric vibrator is the core component of the micro-jet device, which is composed of
a PZT ceramic and a copper sheet and is fixed on the cavity via epoxy resin. In order to
prevent the piezoelectric vibrator from short circuiting when it encounters viscous lubri-
cation oil, the external surface of the PZT ceramic is insulated.
a
b
Fluid
Cavity
Piezoelectric
vibrator
Nozzle
Cooper sheet PZT
Infusion
tube
Figure 1. The overall structure and section view of piezoelectric jet device: (a) The overall structure
of piezoelectric jet device; (b) the section view of piezoelectric jet device.
Figure 1.
The overall structure and section view of piezoelectric jet device: (
a
) The overall structure
of piezoelectric jet device; (b) the section view of piezoelectric jet device.
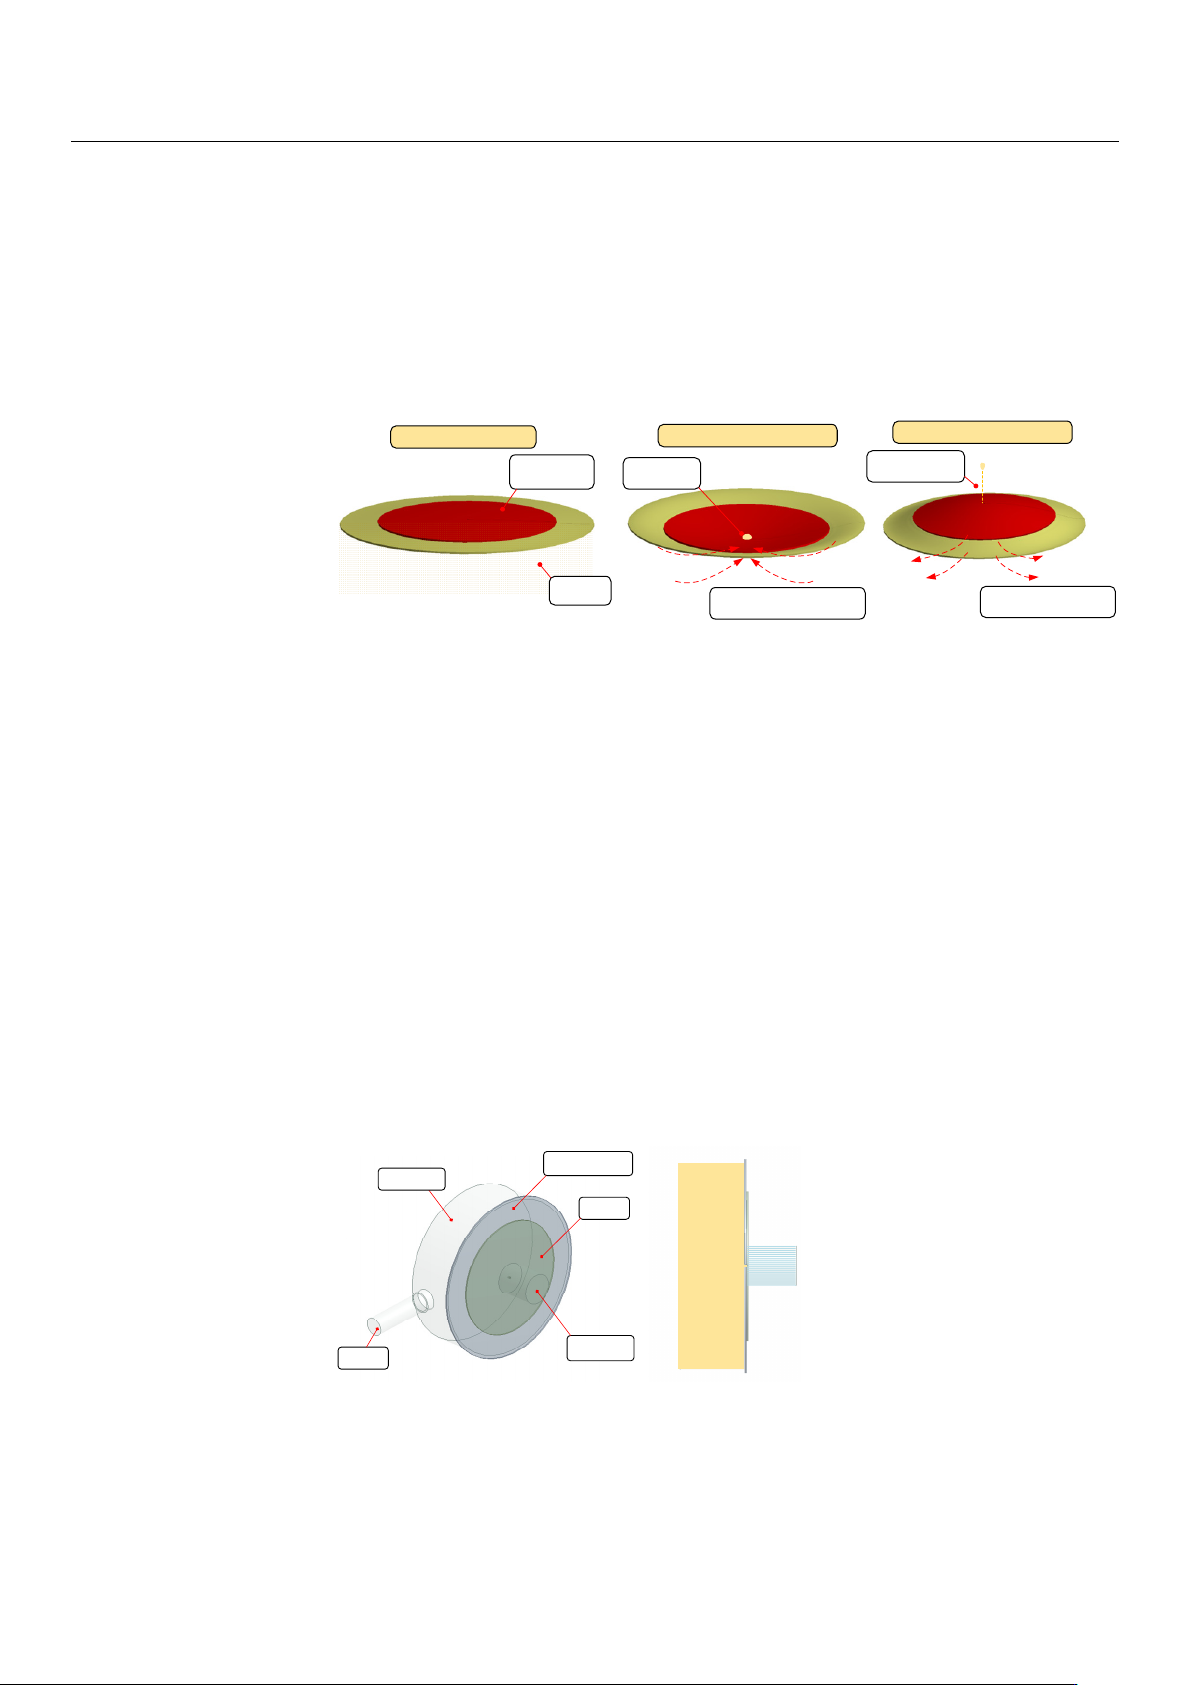
A nozzle is drilled in the center of the piezoelectric vibrator with a high-precision
drilling machine, and the operation process of ejecting oil is shown in Figure 2. When the
piezoelectric vibrator is not working, as shown in Figure 2a, the vibrator always keeps
contact with the oil. When periodic square wave signals are applied in the vibrator, the
vibrator vibrates and produces deformation, and the oil begins to periodically eject from the
nozzle. As shown in Figure 2b, when the vibrator generates concave deformation, the oil is
Micromachines 2023, 14, 1267 3 of 17
compressed, and instantaneous pulsating high pressure is generated in the cavity. Under
the action of high pressure, the droplets are driven to converge at the nozzle and obtain
kinetic energy. As shown in Figure 2c, when the vibrator generates convex deformation,
the cavity expands, resulting in pulsating negative pressure in the cavity. Under the dual
action of negative pressure and acquired kinetic energy, the liquid droplets are separated
from the oil in the cavity and then fly out to form liquid droplets. According to the above
analysis, the droplets are ejected periodically and uniformly with the periodic deformation
of the piezoelectric vibrator.
Micromachines 2023, 14, x FOR PEER REVIEW 3 of 28
A nozzle is drilled in the center of the piezoelectric vibrator with a high-precision
drilling machine, and the operation process of ejecting oil is shown in Figure 2. When the
piezoelectric vibrator is not working, as shown in Figure 2a, the vibrator always keeps
contact with the oil. When periodic square wave signals are applied in the vibrator, the
vibrator vibrates and produces deformation, and the oil begins to periodically eject from
the nozzle. As shown in Figure 2b, when the vibrator generates concave deformation, the
oil is compressed, and instantaneous pulsating high pressure is generated in the cavity.
Under the action of high pressure, the droplets are driven to converge at the nozzle and
obtain kinetic energy. As shown in Figure 2c, when the vibrator generates convex defor-
mation, the cavity expands, resulting in pulsating negative pressure in the cavity. Under
the dual action of negative pressure and acquired kinetic energy, the liquid droplets are
separated from the oil in the cavity and then fly out to form liquid droplets. According to
the above analysis, the droplets are ejected periodically and uniformly with the periodic
deformation of the piezoelectric vibrator.
Piezoelectric
vibrator
Oil fluid
Droplet
formation
a
b
c
When no signal is applied
When concave deformation occurs
When convex deformation occurs
Droplet separates
and is ejected
Instantaneous pulsating high
pressure effect
Negative pressure effect
Figure 2. The ejection process of droplets: (a) When no signal is applied; (b) when concave defor-
mation occurs; (c) when convex deformation occurs.
In order to further reveal the principle of the piezoelectric micro-jet and study the
influence of signal, oil viscosity and nozzle size on the injection performance, we use AN-
SYS software to carry out a two-phase, two-way fl uid–structure coupling analysis on the
designed piezoelectric micro-jet device. The simulation model is shown in Figure 3. As
can be seen from the axonal diagram of the model in Figure 3a, the simulation model is
composed of a cavity, copper sheet, PZT ceramics, liquid inlet and liquid outlet. The solid
model of the cavity and infusion tube is removed, and the internal fluid model of the cav-
ity and infusion tube is added. As can be seen from the front view of the model in Figure
3b, in order to simulate the injection of oil from the nozzle into the air, a fluid domain
simulating the external air environment is added on the right side of the nozzle. The pie-
zoelectric vibrator is set as the structural domain, and the cavity part is set as the fluid
domain (oil). PZT-5H is selected as the material of PZT ceramics, and its Young′s modulus
is 56 Gpa, Poisson’s ratio is 0.36 and density is 7600 kg/m
3
. The copper sheet is made of
red copper with a Young′s modulus of 108 Gpa and Poisson′s ratio of 0.32. The thickness
of copper and PZT ceramics is 0.2 mm. The transient structure analysis module and fluent
module are used to simulate the two-phase, two-way fluid–structure coupling analysis.
Figure 2.
The ejection process of droplets: (
a
) When no signal is applied; (
b
) when concave deforma-
tion occurs; (c) when convex deformation occurs.
In order to further reveal the principle of the piezoelectric micro-jet and study the
influence of signal, oil viscosity and nozzle size on the injection performance, we use
ANSYS software to carry out a two-phase, two-way fluid–structure coupling analysis on
the designed piezoelectric micro-jet device. The simulation model is shown in Figure 3. As
can be seen from the axonal diagram of the model in Figure 3a, the simulation model is
composed of a cavity, copper sheet, PZT ceramics, liquid inlet and liquid outlet. The solid
model of the cavity and infusion tube is removed, and the internal fluid model of the cavity
and infusion tube is added. As can be seen from the front view of the model in Figure 3b, in
order to simulate the injection of oil from the nozzle into the air, a fluid domain simulating
the external air environment is added on the right side of the nozzle. The piezoelectric
vibrator is set as the structural domain, and the cavity part is set as the fluid domain (oil).
PZT-5H is selected as the material of PZT ceramics, and its Young
0
s modulus is 56 Gpa,
Poisson’s ratio is 0.36 and density is 7600 kg/m
3
. The copper sheet is made of red copper
with a Young
0
s modulus of 108 Gpa and Poisson
0
s ratio of 0.32. The thickness of copper
and PZT ceramics is 0.2 mm. The transient structure analysis module and fluent module
are used to simulate the two-phase, two-way fluid–structure coupling analysis.
Micromachines 2023, 14, x FOR PEER REVIEW 4 of 28
Air
Oil
Inlet
Cooper sheet
PZT
Outlet
a
b
Cavity
Figure 3. The axonometric and frontal view of the simulation model: (a) The axonometric view of
the simulation model; (b) the frontal view of the simulation model.
In the transient analysis module, the fixed boundary condition is applied to the cir-
cumference of the copper sheet. The surface where the piezoelectric vibrator contacts the
fluid domain is set as the fluid–solid interface, and a square wave pulse signal is applied
to the piezoelectric vibrator. In the fluent module, the fluid domain is meshed via the
sweep method, and the dynamic mesh method (remesh and smooth) is used to simulate
the dynamic change in the fluid domain caused by the deformation of the piezoelectric
vibrator through the coupling surface. The inlet of the fluid domain is set to the pressure
inlet of 100 MPa constant pressure, and the outlet of the fluid domain is set to the pressure
outlet of 0 MPa constant pressure.
In order to achieve the best injection effect, it is necessary to find an optimal injection
frequency. The acoustic structure coupling analysis of the piezoelectric vibrator is carried
out, that is, the bidirectional coupling frequency response analysis considering fluid reac-
tion. First, the frequency with the largest amplitude is found within a large frequency
range, and then, the frequency analysis range shrinks towards this frequency to obtain the
exact optimal frequency value. The results of the amplitude–frequency response are
shown in Figure 4. Figure 4a shows the result of the amplitude–frequency response in a
large frequency analysis range, and Figure 4b shows the exact optimal frequency value. It
can be seen that the vibration amplitude of the piezoelectric vibrator is maximum at 8090
Hz, so 8090 Hz is set as the optimal working frequency in this work.
Figure 3.
The axonometric and frontal view of the simulation model: (
a
) The axonometric view of the
simulation model; (b) the frontal view of the simulation model.
In the transient analysis module, the fixed boundary condition is applied to the
circumference of the copper sheet. The surface where the piezoelectric vibrator contacts the
fluid domain is set as the fluid–solid interface, and a square wave pulse signal is applied
to the piezoelectric vibrator. In the fluent module, the fluid domain is meshed via the
Micromachines 2023, 14, 1267 4 of 17
sweep method, and the dynamic mesh method (remesh and smooth) is used to simulate
the dynamic change in the fluid domain caused by the deformation of the piezoelectric
vibrator through the coupling surface. The inlet of the fluid domain is set to the pressure
inlet of 100 MPa constant pressure, and the outlet of the fluid domain is set to the pressure
outlet of 0 MPa constant pressure.
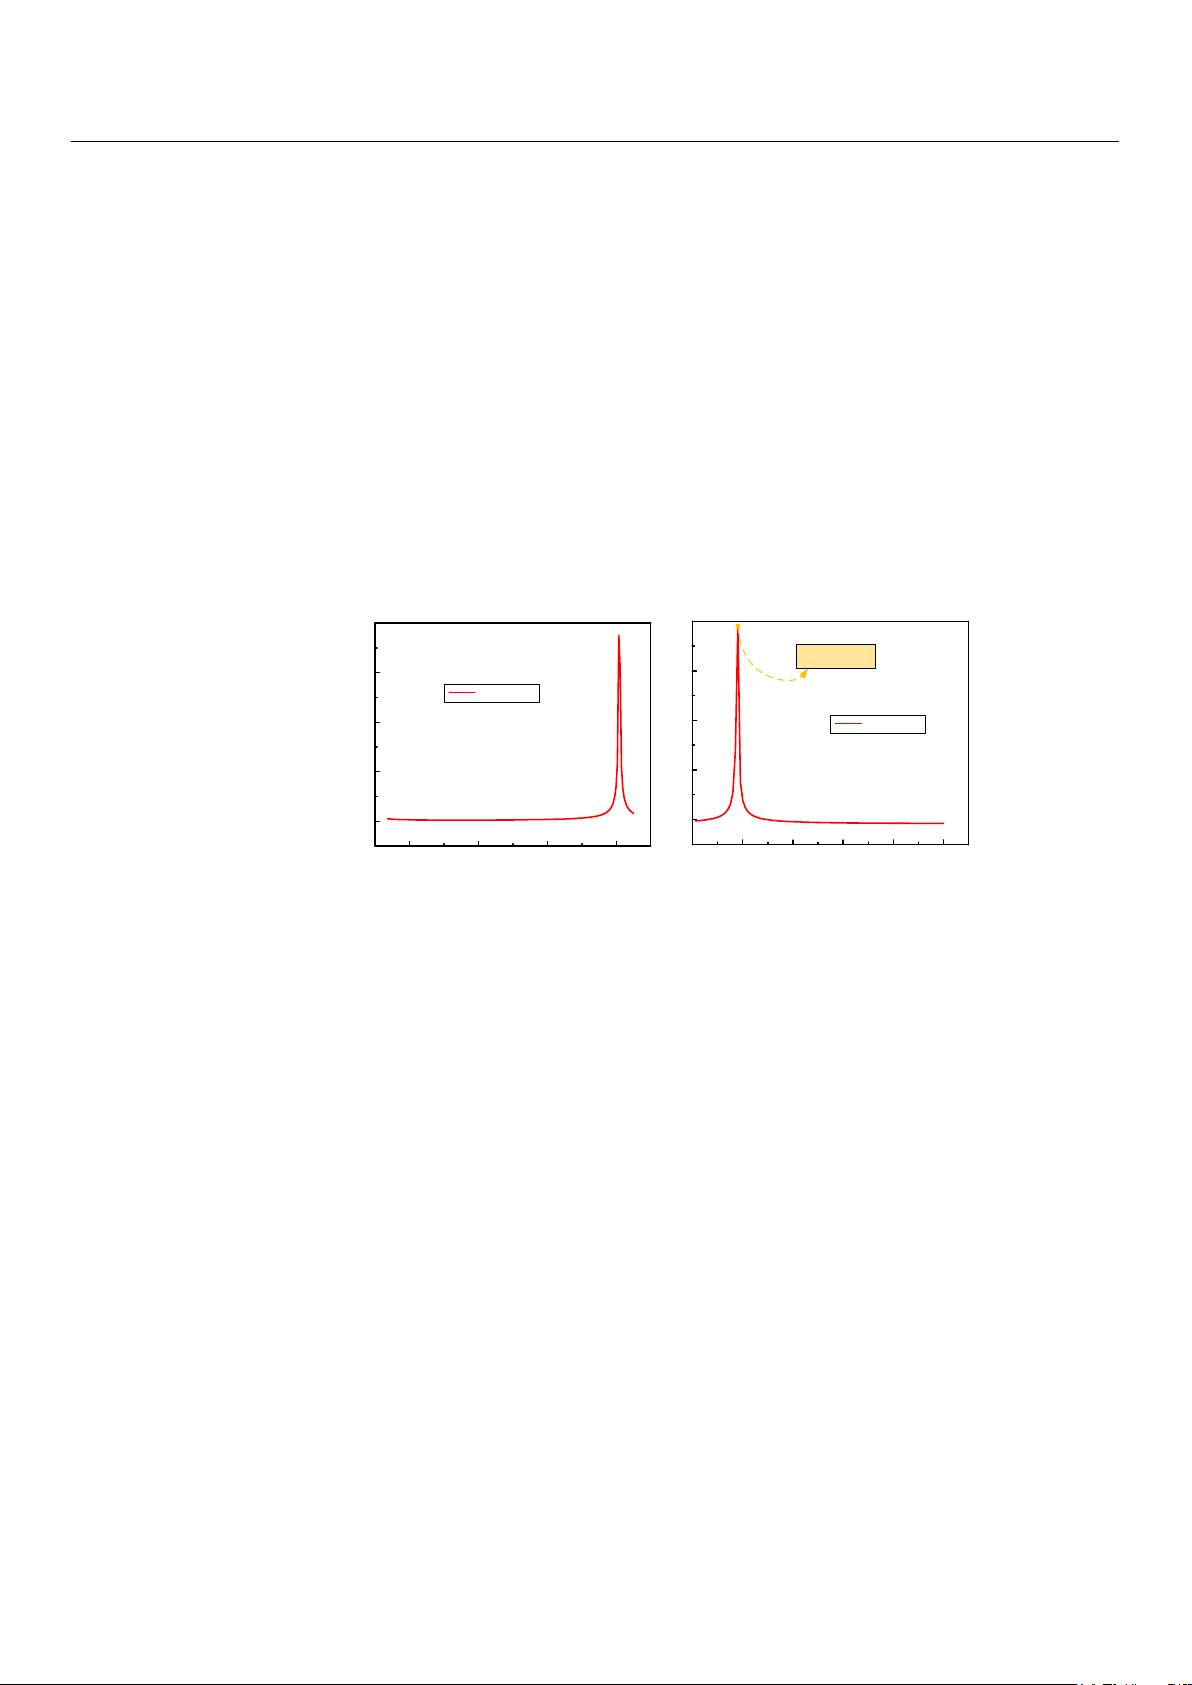
In order to achieve the best injection effect, it is necessary to find an optimal injection
frequency. The acoustic structure coupling analysis of the piezoelectric vibrator is carried
out, that is, the bidirectional coupling frequency response analysis considering fluid re-
action. First, the frequency with the largest amplitude is found within a large frequency
range, and then, the frequency analysis range shrinks towards this frequency to obtain the
exact optimal frequency value. The results of the amplitude–frequency response are shown
in Figure 4. Figure 4a shows the result of the amplitude–frequency response in a large
frequency analysis range, and Figure 4b shows the exact optimal frequency value. It can be
seen that the vibration amplitude of the piezoelectric vibrator is maximum at 8090 Hz, so
8090 Hz is set as the optimal working frequency in this work.
Micromachines 2023, 14, x FOR PEER REVIEW 5 of 28
2000 4000 6000 8000
0
50
100
150
200
Amplitude (um)
Frequency (Hz)
Amplitude
8000 8100 8200 8300 8400 8500
Amplitude (um)
Frequency (Hz)
Amplitude
8090Hz
0
50
100
150
200
a
b
Figure 4. The results of the amplitude–frequency response: (a) The result of amplitude–frequency
response in a large frequency analysis range; (b) the exact optimal frequency value.
Figure 4.
The results of the amplitude–frequency response: (
a
) The result of amplitude–frequency
response in a large frequency analysis range; (b) the exact optimal frequency value.
For the follow-up study on the influence of a single parameter on the injection state, the
basic parameters are set as follows: voltage amplitude is 100 V, signal frequency is 8090 Hz,
nozzle diameter is 0.4 mm, and oil viscosity is 200 Pa.s. The single-droplet-injection two-
phase flow diagram of the piezoelectric micro-jet device under standard parameters is
shown in Figure 5. The mechanism of the piezoelectric micro-jet will be elaborated upon in
Figure 5. At
t
= 0 s, the device has no signal input and the liquid level remains stationary. At
t
1
, the high-level pulse signal is applied to the piezoelectric vibrator, and the vibrator begins
to produce concave deformation and squeezes the cavity to produce positive pressure,
resulting in the oil beginning to converge to the nozzle. From t
1
to t
3
, the vibrator continues
to receive positive voltage signal, the cavity keeps positive pressure and the oil continues
to be ejected out. At t
4
, the pulse signal changes to a low level after the falling edge. At this
time, the vibrator begins to produce convex deformation, and the cavity begins to expand,
negative pressure begins to be generated and part of the oil begins to be sucked back. At t
5
,
it can be seen that part of the droplets are sucked back, and the droplets are completely
separated from the oil and ejected outward. The simulation results show the feasibility of
the piezoelectric micro-jet and describe the generation process of droplets in detail.