Infinity EX Rail System Module.pdf - 第10页
INFINITY EX RAIL S YSTEM M ODULE DRIVE S AND SEN SORS 15.1 0 Technical Reference Manual Chapter Issue 2 Jan 04 Board at Left/Right Sens ors The board at left and board at right sensors are diffuse opto type sensors. Thes…
INFINITY
EX
RAIL SYSTEM MODULE
DRIVES AND SENSORS
Chapter Issue 2 Jan 04 Technical Reference Manual 15.9
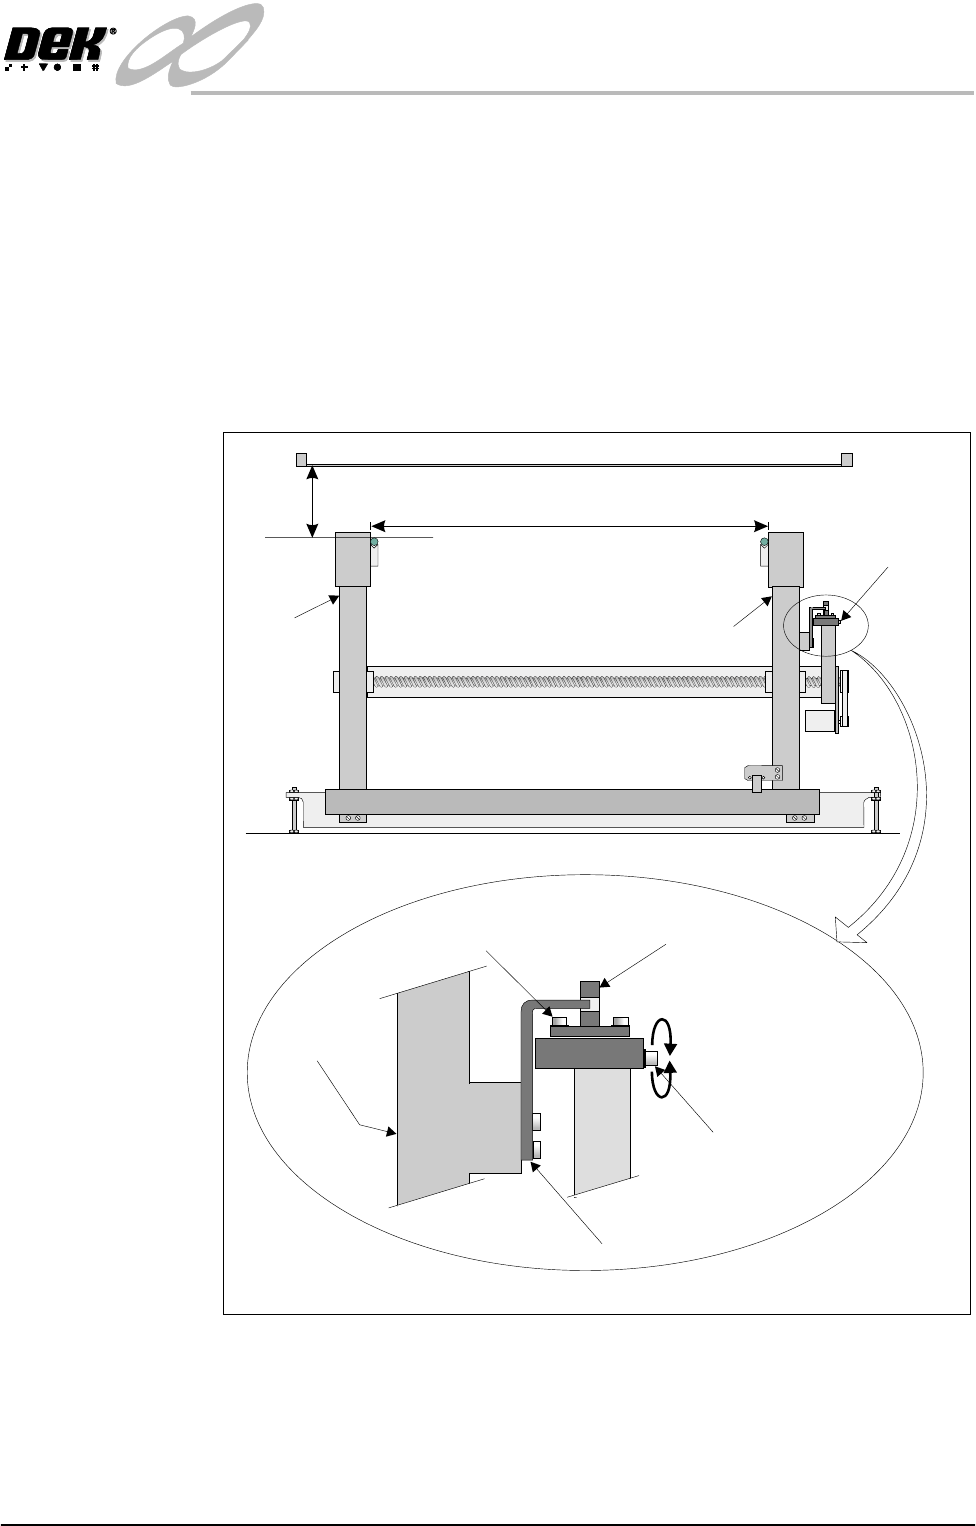
Rail Home Sensor The rail home sensor is a through beam opto type sensor.
The sensor is used for accurately determining the front and rear rail widths.
During machine initialization, (power-up or upon exiting diagnostics), the rear
rail moves to the rear of the machine where upon the rail opto vane enters the
rail home sensor, the rear rail is now at the home position.
NOTE
Homing Sequence of this chapter refers.
The rail home sensor feeds directly to the Multiplexer controller and is used to
set the datum value for the rail width (508.5mm - 508.7mm).
Figure 15-6 Rail Home Setting
Home Position
Adjustment
508.5 - 508.7mm
85mm Rail Transport Height
Front Rail
(Fixed)
Rear Rail
(Moving)
Adjustable Through
Beam Opto Sensor
Home Sensor Adjustment
Screw (0.5mm Pitched
Thread)
Rear Rail
Opto Flag
Sensor Forward Securing Screw
View on Right Hand Side of Machine
Enlarged View of Rail Home Position Sensor
INFINITY
EX
RAIL SYSTEM MODULE
DRIVES AND SENSORS
15.10 Technical Reference Manual Chapter Issue 2 Jan 04
Board at Left/Right
Sensors
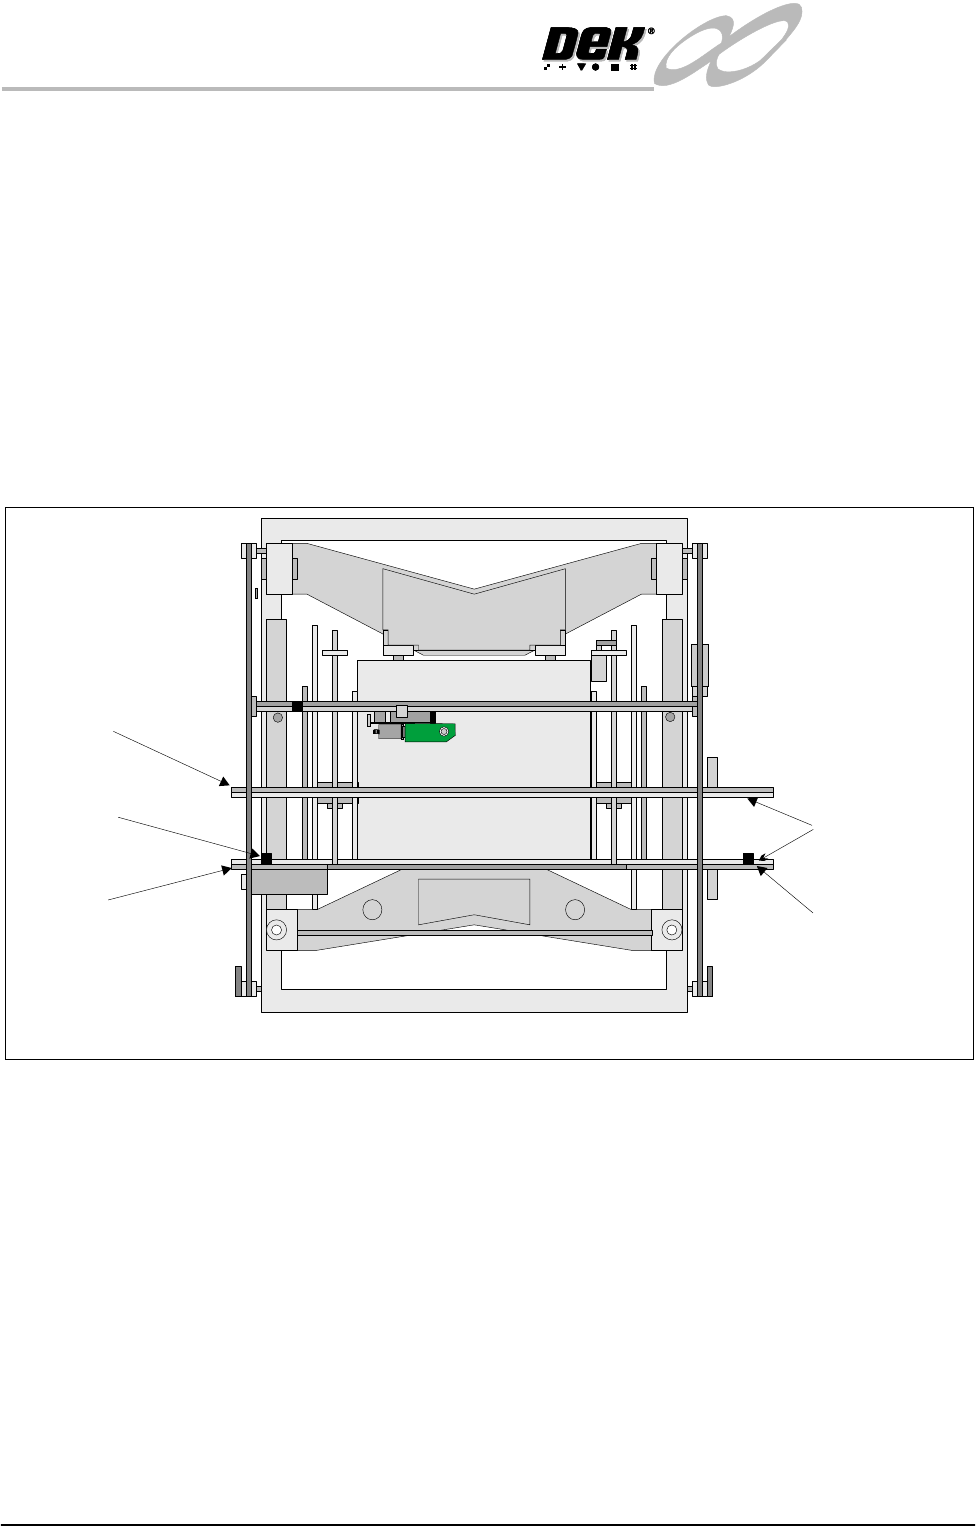
The board at left and board at right sensors are diffuse opto type sensors.
These two sensors are used to detect a board at the input and output of the
transport belt. As the machine is bi-directional the functions of both optos are
reversed when the pass through direction is changed.
The input sensor is used to start the transport belt on detection of a board. The
board is transported into the machine and processed after which it is transferred
to the output sensor where it stops and waits for the command to be passed onto
the next machine in the line.
These optos are fitted with a red and green LED along with a sensitivity control.
There is a small amount of positional adjustment in the bracket but generally it
is not necessary to reset it as the footprint used by the diffuse opto is large enough
to cope with the holes in an average production board.
Figure 15-7 Board at Left/Right Opto Locations
BoardTransport
Belts
Boardat Right
Sensor
Boardat Left
Sensor
Moving Rail
FixedRail
Plan View on Machine - Printhead Removed
PULNIX
TM-6EX
INFINITY
EX
RAIL SYSTEM MODULE
SEQUENCES
Chapter Issue 2 Jan 04 Technical Reference Manual 15.11
SEQUENCES
Homing Sequence The rail system is homed during machine initialization only, (during power-up
or upon exiting diagnostics).
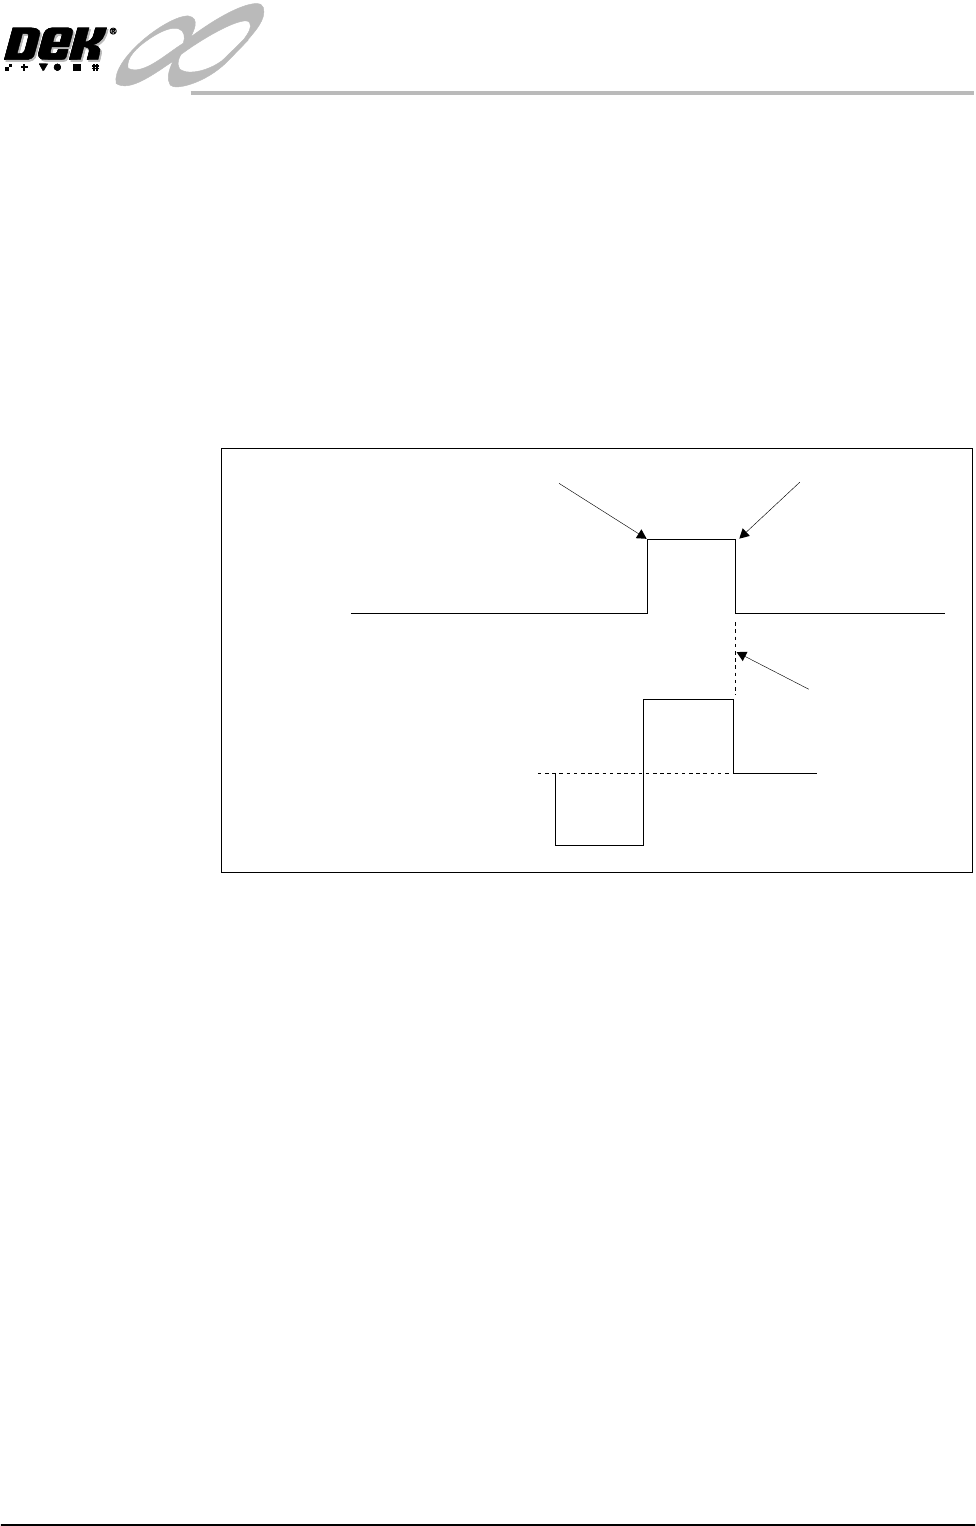
When the home command is received the rear moving rail is driven (in the
reverse direction) to the rear of the machine until the home vane, attached to it,
is detected by the rail home sensor. Upon detection (sensor ON) the motor is
driven in the opposite direction until the vane clears the home sensor and the
motor stops (sensor OFF).
This position has a set dimension of 508.5mm to 508.7mm measured between
the inside of each rail, (Positioning section of this chapter refers)
Figure 15-8 Rail Timing Diagram
Rail Positioning There is a fixed relationship between steps of the stepper drive motor and rail
movement (in mm) due to the gearing ratios and pitch of the driving leadscrews.
Therefore when a width is selected this is multiplied by the steps/mm factor and
sent to the stepper drive system.
All positions are relative to the home position.
Home Position
Fwd
Stepper
Motor
Home
Sensor
0V
12V
Stopped
Rev
Vane leaves sensor
Vane enters sensor