Vista Sensors and Motors.pdf - 第22页
SENSORS AND MOTORS MOTORS 20.22 Technical Reference Manual Chapter Issue 1 Sep 02 Servo Motor A servo motor is a motor in which the r otat ional posi tion or sp eed is control led by electr ical feed back signals. This f…
SENSORS AND MOTORS
MOTORS
Chapter Issue 1 Sep 02 Technical Reference Manual 20.21
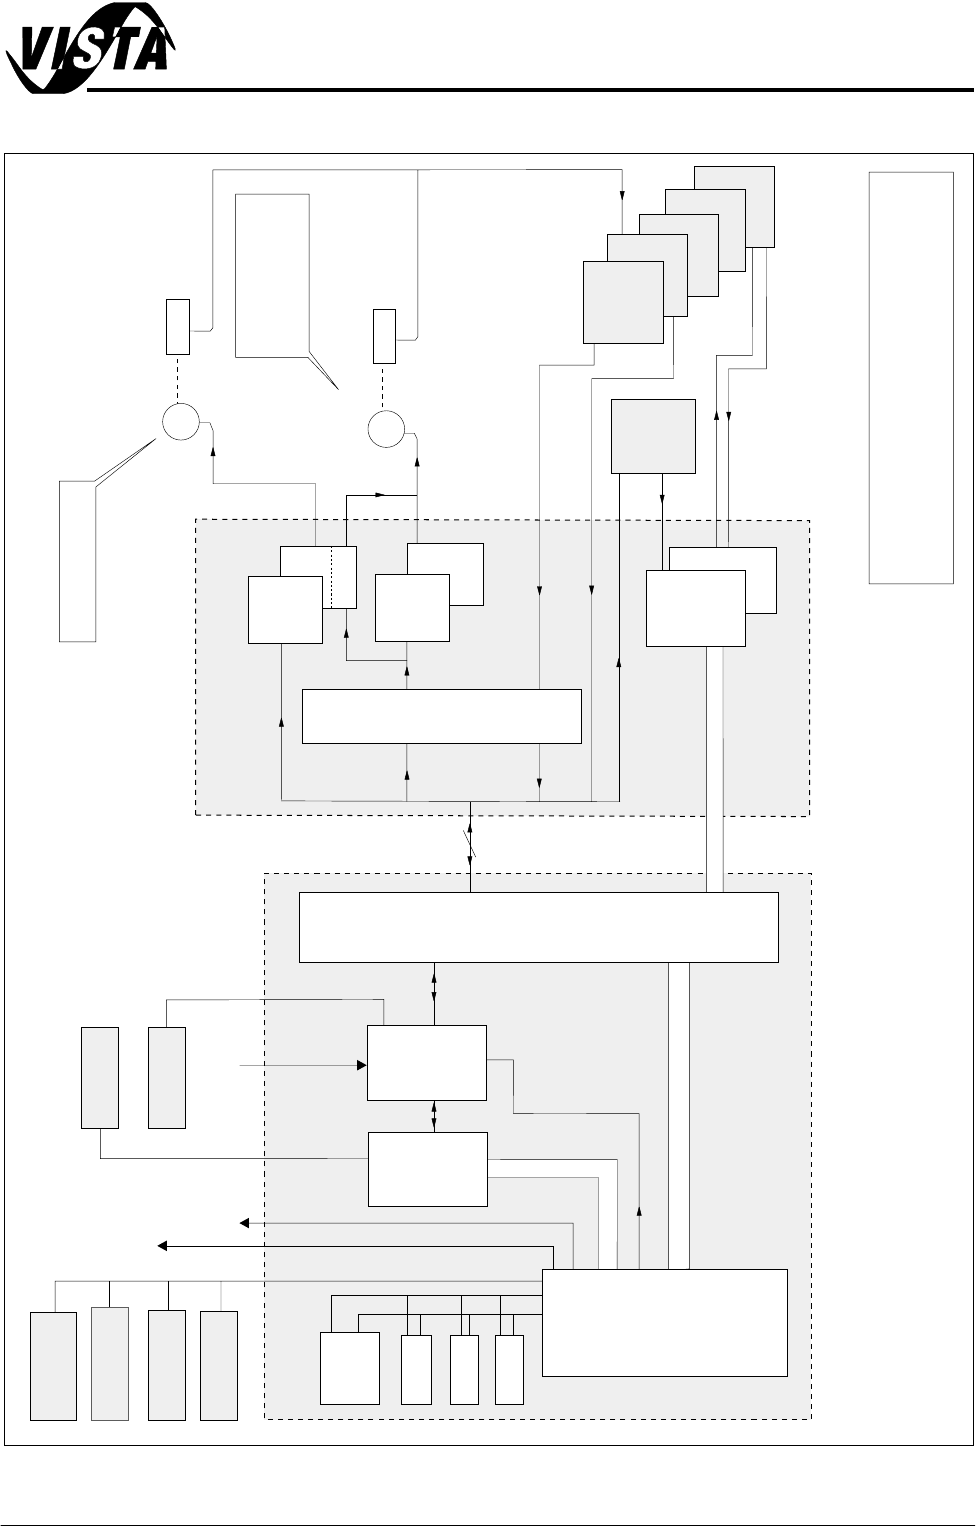
Figure 20-20 Stepper Schematic
24V Stepper Motors
24V Stepper Motors
Front Squeegee
Rear Squeegee
Rail
Machine Controller
Step/Dir - 4,5,6
Step/
Dir-7
I/O Breakout Boards
Squeegees, Rail, P.Disp - Homes
Mux
Home
Critical Real Time I/Ps
16 I/Ps, O/Ps
per card
XF; XR ; Y Actuators
NOTE
The CAN Bus forms part of the 100 way connection
between the Machine PC and Controller enclosures
Host
Comms
Parallel
Printer
PCI Bus
ISA Bus
Machine PC
P.S.U.
HDD
Keyboard
Touchscreen
Camera
24v (U/S)
PCI 3
Vision
Card
Vision
P. C.
Adaptor
ISA 5
CDROM
FDD
P
r
o
c
e
s
s
o
r
ISA 3
Mouse
Lighting
Monitor
100
Way
ISA 10
N
e
x
t
M
o
v
e
CAN Bus
X13
X12
Multi-
Move
A
B
C
D
E
Home
Home
M
M
X5
X3
Dual
Stepper
X6
X4
Dual
Stepper
X1
M
u
l
t
I
p
l
e
x
e
r
Multi-
Interface
Unit
SENSORS AND MOTORS
MOTORS
20.22 Technical Reference Manual Chapter Issue 1 Sep 02
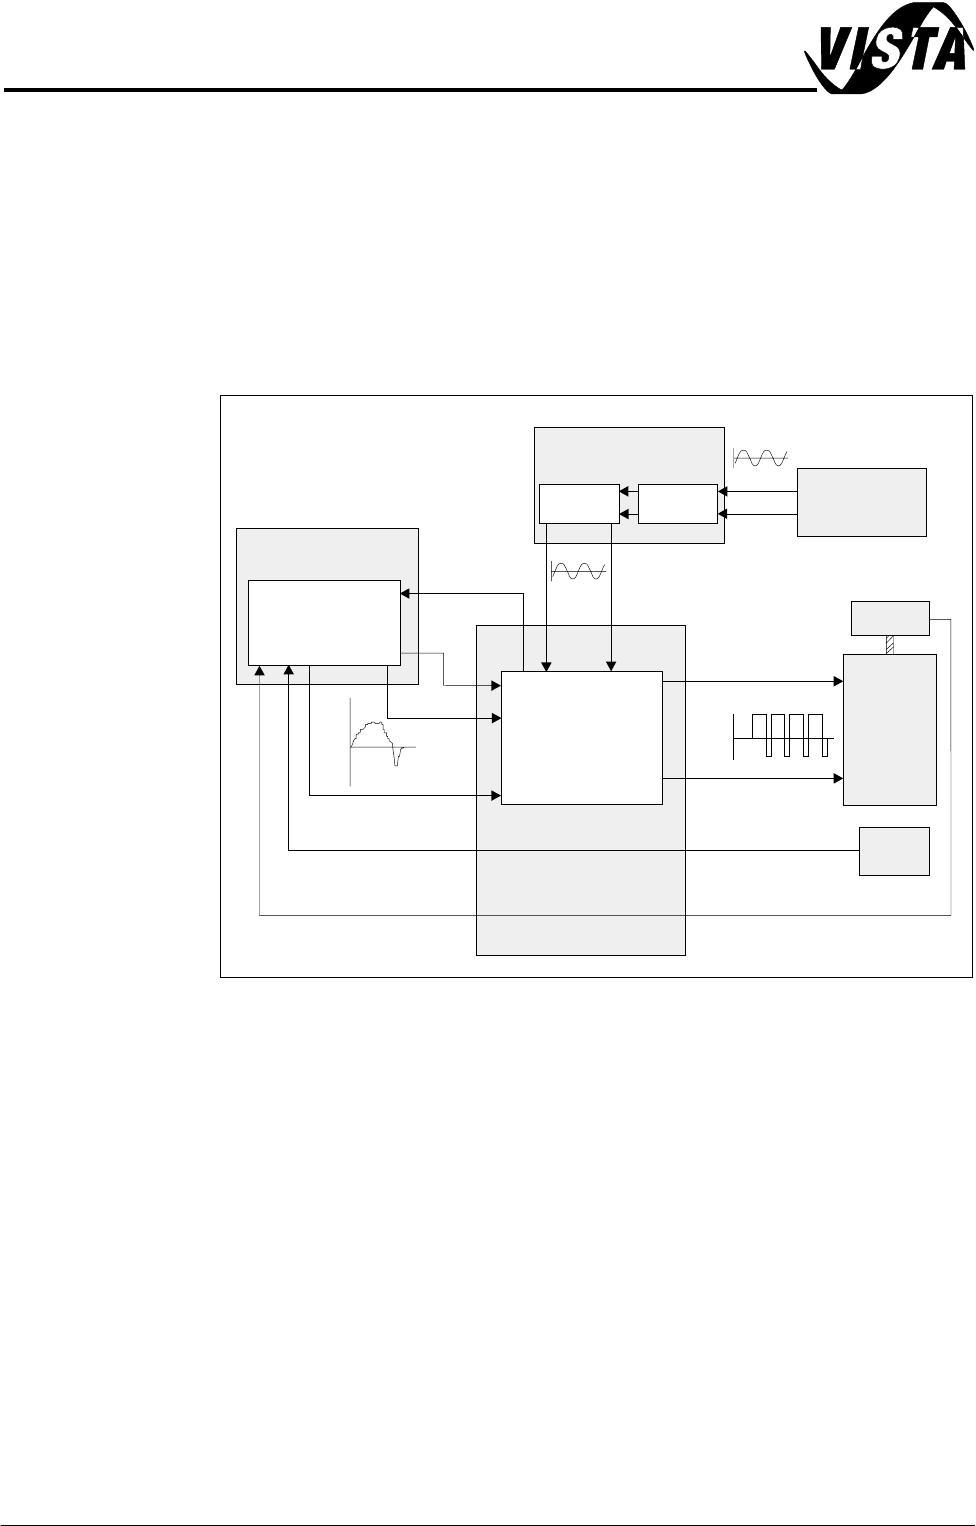
Servo Motor A servo motor is a motor in which the rotational position or speed is controlled
by electrical feedback signals. This feedback is generated by a control system
that measures the difference between the actual and desired position and then
takes action to reduce that difference. A servo motor is used for the following
functions:
• Camera X and Y Axes
• Rising Table
• Print Carriage
Figure 20-21 Servo System Basic Layout
The Servo System Schematic Figure shows a typical servo system, overall
control of the system is by the Machine PC. When axis movement is required
a command is sent via the machine PC NextMove controller to the servo drive
cards in the machine controller.
Demand The demand output from the NextMove controller is in the form of a ±10V dc
level generated by the Nextmove card (Servo System Basic Layout figure
refers). The error signals are derived from the encoder unit.
NextMove
Card
+VE
Motor +VE
Encoder Out
Servo
Motor
Motor -VE
-VE
Demand
Output
to Motor
Error
Enable
Servo Drive
+62V
25kHz PWM
-62V
44V ac
44V ac
+10V
-10V
Encoder
Machine PC
Machine Controller
M24 dc Power
Module
M23 ac Power
Module
Con 3
Con 2
Home
SENSORS AND MOTORS
MOTORS
Chapter Issue 1 Sep 02 Technical Reference Manual 20.23
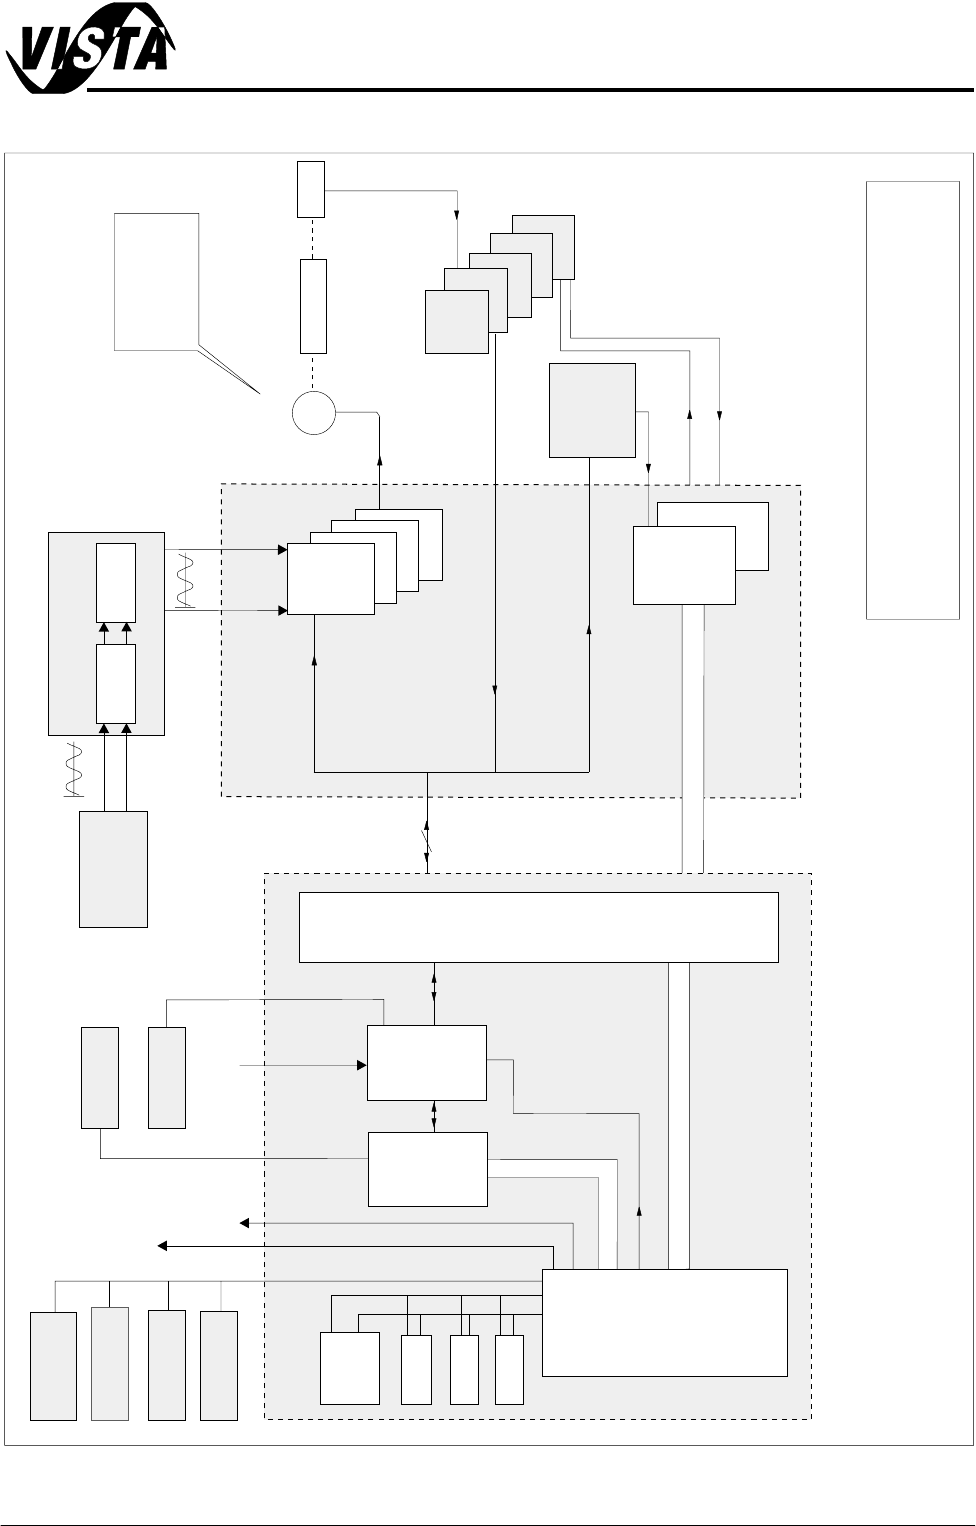
Figure 20-22 Servo System Schematic
Servo Motors
Encoder
Home
Axis 0
Servo
Drive
Axis 1
Axis 2
Axis 3
Dmd 0,1,2,3
CAN Bus
Camera X
Camera Y
Rising Table
Print Carriage
Machine Controller
100 Way
I/O Breakout Boards
A
B
C
D
E
Critical Real Time I/Ps
16 I/Ps, O/Ps
per card
Multi-
Interface
Unit
NOTE
The CAN Bus forms part of the 100 way connection
between the Machine PC and Controller enclosures
X13
X12
Multi-
Move
M
Host
Comms
Parallel
Printer
PCI Bus
ISA Bus
Machine PC
P.S.U.
HDD
Keyboard
Touchscreen
Camera
24v (U/S)
PCI 3
Vision
Card
Vision
P. C.
Adaptor
ISA 5
CDROM
FDD
P
r
o
c
e
s
s
o
r
ISA 3
Mouse
Lighting
Monitor
ISA 10
N
e
x
t
M
o
v
e
44V ac
44V ac
Con 3
Con 2
M23 ac Power
Module
M24 dc Power
Module