E4416A_E4417A EPM-P Series Power Meters and E-Series E9320 Peak and Average Power Sensors.pdf - 第16页
Find us at www.keys ight.com Page 16 Table 7. Calibr ation factor rel ative unc ertainty at 0.1 mW ( – 10 dBm). Frequency Uncertainty (%) (25 ± 10 ° C) 1 Uncertainty (%) (0 to 55 ° C) 1 50 MHz Reference Reference 100 MHz…
Find us at www.keysight.com Page 15
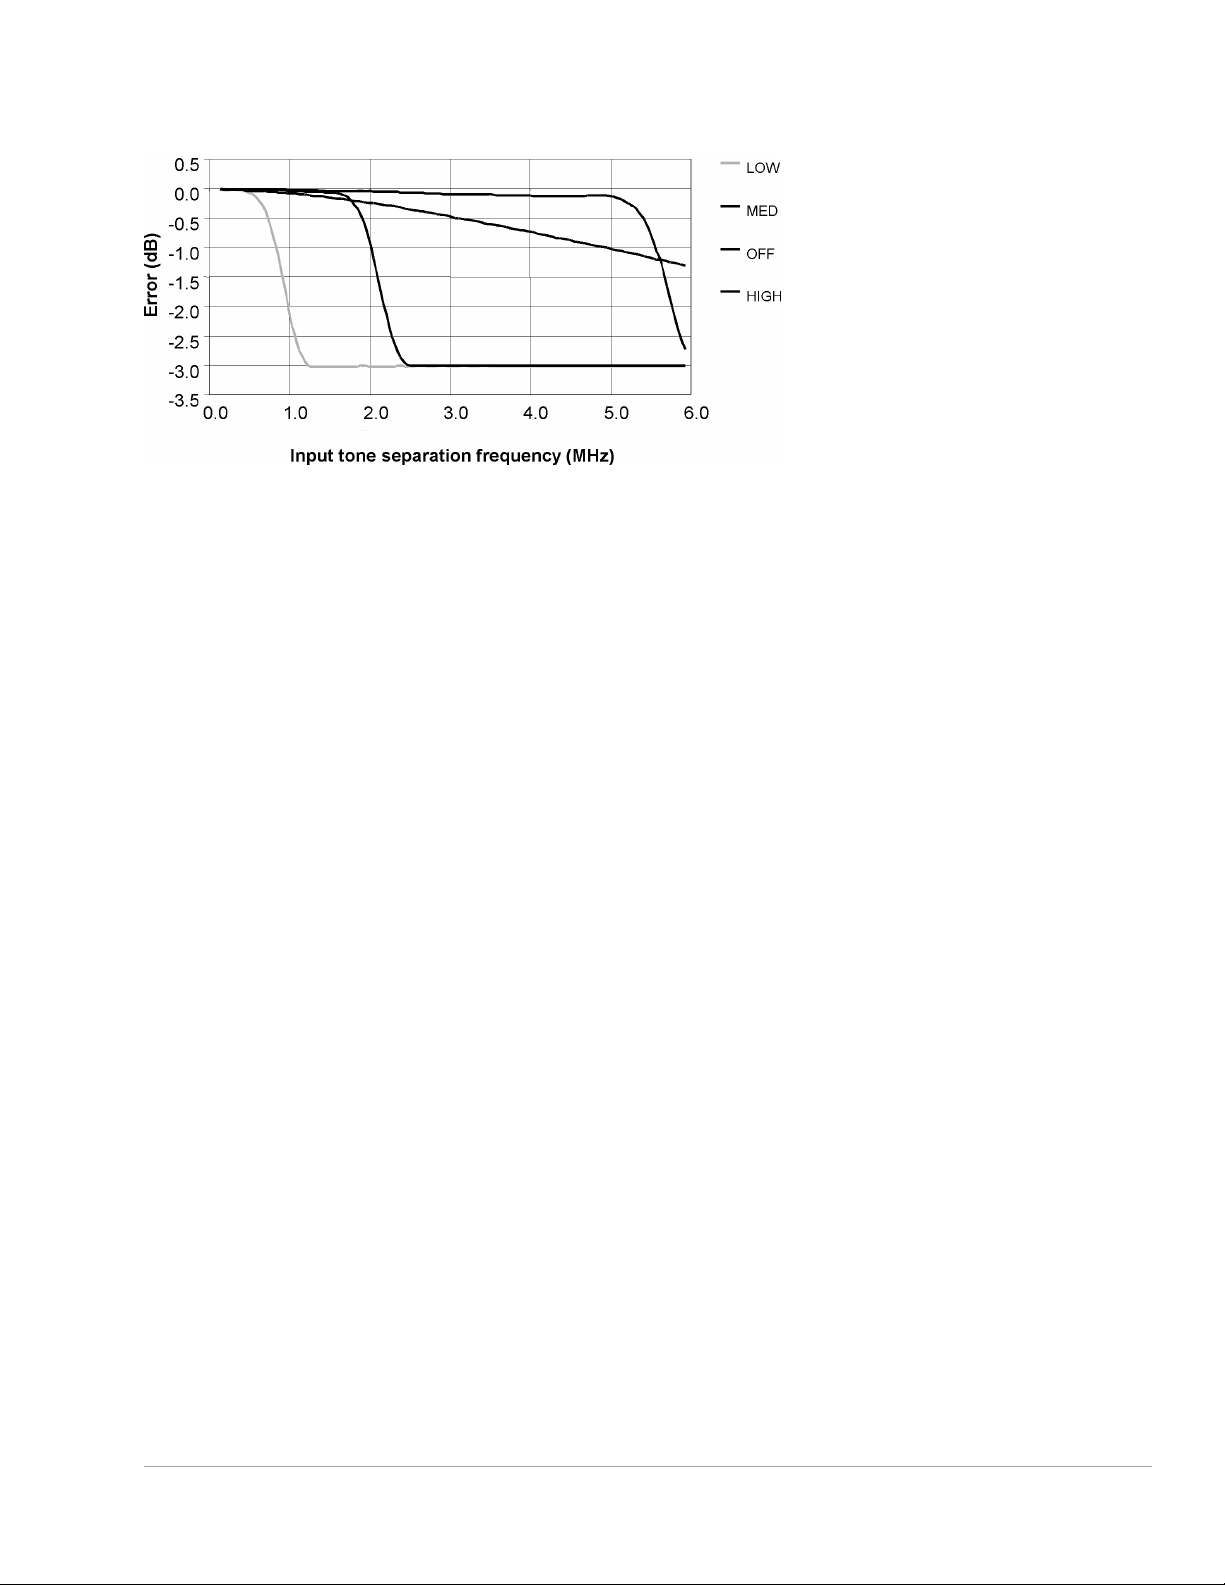
Figure 8. E9323A and E9327A error in peak-to-average measurements for a two-tone input (high, medium, low and
off filters).
Calibration Factor (CF) and Reflection Coefficient (Rho)
Calibration Factor and Reflection Coefficient data are provided at frequency intervals on a data sheet
included with the power sensor. This data is unique to each sensor. If you have more than one sensor,
match the serial number on the data sheet with the serial number of the power sensor you are using.
The CF corrects for the frequency response of the sensor. The EPM-P series power meter automatically
reads the CF data stored in the sensor and uses it to make corrections.
For power levels greater than 0 dBm, add to the calibration factor uncertainty specification:
•
± 0.1%/dB (for E9321A and E9325A sensors),
•
± 0.15%/dB (for E9322A and E9326A sensors) and
•
± 0.2%/dB (for E9323A and E9327A sensors)
Reflection Coefficient (Rho) relates to the SWR according to the formula:
•
SWR = (1 + Rho)/(1 – Rho)
Maximum relative uncertainties of the CF data are listed in Table 7. The uncertainty analysis for the
calibration of the sensors was done in accordance with the ISO Guide. The uncertainty data, reported
on the calibration certificate, is the expanded uncertainty with a 95% confidence level and a coverage
factor of 2.
Find us at www.keysight.com Page 16
Table 7. Calibration factor relative uncertainty at 0.1 mW (–10 dBm).
Frequency Uncertainty (%) (25 ± 10 °C)
1
Uncertainty (%) (0 to 55 °C)
1
50 MHz
Reference
Reference
100 MHz
1.8
2.0
300 MHz
1.8
2.0
500 MHz
1.8
2.0
800 MHz
1.8
2.0
1.0 GHz
2.1
2.3
1.2 GHz
2.1
2.3
1.5 GHz
2.1
2.3
2.0 GHz
2.1
2.3
3.0 GHz
2.1
2.3
4.0 GHz
2.1
2.3
5.0 GHz
2.1
2.3
6.0 GHz
2.1
2.3
7.0 GHz
2.3
2.5
8.0 GHz
2.3
2.5
9.0 GHz
2.3
2.5
10.0 GHz
2.3
2.5
11.0 GHz
2.3
2.5
12.0 GHz
2.3
2.5
12.4 GHz
2.3
2.5
13.0 GHz
2.3
2.5
14.0 GHz
2.5
2.8
15.0 GHz
2.5
2.8
16.0 GHz
2.5
2.8
17.0 GHz
2.5
2.8
18.0 GHz
2.5
2.8
1
The characterized calibration factor should not deviate between periodic calibrations by more than the specified maximum uncertainty in the table.
Compliance is confirmed by the relative deviation (
|
1
−
2
|
1
∗ 100) being less than or equal to √2 times the specified maximum uncertainty. √2∗
with a reference calibration factor of 100%.
Find us at www.keysight.com Page 17
Zero Set
This specification applies to a ZERO performed when the sensor input is not connected to the POWER
REF.
Table 8. Zero set.
Sensor model Zero set (normal mode) Zero set (average only mode)
E9321A, E9325A
5 nW
0.17 nW
E9322A, E9326A
19 nW
0.5 nW
E9323A, E9327A
60 nW
0.6 nW
Zero Drift and Measurement Noise
Table 9. Zero drift and measurement noise.
Zero drift
1
Measurement noise
2
Sensor model Normal mode Average only mode Normal mode
3
Normal mode
4
Average only mode
E9321A, E9325A
< 5 nW
< 60 pW
< 6 nW
< 75 nW
< 165 pW
E9322A, E9326A
< 5 nW
< 100 pW
< 12 nW
< 180 nW
< 330 pW
E9323A, E9327A
< 40 nW
< 100 pW
< 25 nW
< 550 nW
< 400 pW
Effect of averaging on noise: Averaging over 1 to 1024 readings is available for reducing noise. Table 9
provides the measurement noise for a particular sensor. Use the noise multipliers in Table 10, for the
appropriate speed (normal or x 2) or measurement mode (normal or average only) and the number of
averages, to determine the total measurement noise value.
In addition, for x 2 speed (in normal mode) the total measurement noise should be multiplied by 1.2, and
for fast speed (in normal mode), the multiplier is 3.4.
Note that in fast speed, no additional averaging is implemented.
1 Within 1 hour after zero set, at a constant temperature, after a 24-hour warm-up of the power meter.
2 Measured over a one-minute interval, at a constant temperature, two standard deviations, with averaging set to 1
(for normal mode), 16 (for average only mode, normal speed) and 32 (for average only mode, x 2 speed).
3 In free run acquisition mode.
4 Noise per sample, video bandwidth set to OFF with no averaging (i.e. averaging set to 1) - see the note “Effect of
Video Bandwidth Setting” and Table 11.