s26030829.pdf - 第18页
Sensors 2026 , 26 , 829 18 of 21 Figure 20. Robotic Arm Acceleration Curve. As indicated by the simulation results in Figure 18 , the planned joint angular displace- ment profile of the forearm joint is in close agreement…
Sensors 2026, 26, 829
17 of 21
output module is constructed to generate the reference profiles of the joint angle, angular
velocity, and angular acceleration. Meanwhile, a random disturbance module is connected
externally to provide an excitation torque, which is applied as the external input torque
τ
to
the dynamic planning module. A closed-loop control function is then established according
to the governing dynamic equations. The output angular acceleration is integrated twice to
obtain the simulated angular velocity and angular displacement, and the resulting data
are exported to spreadsheets. Furthermore, inverse kinematics is employed to inversely
infer the effect of the external disturbance and back-calculate the corresponding driving
torque, thereby completing the closed-loop simulation test module [
40
]. In this study,
angular displacement, angular velocity, angular acceleration, and joint torque are adopted
as evaluation metrics to assess the time-planning performance and vibration-suppression
capability of the wafer-transfer robot using the Simulink test platform. The integrated
simulation platform is executed, and the Scope outputs are exported to the workspace via
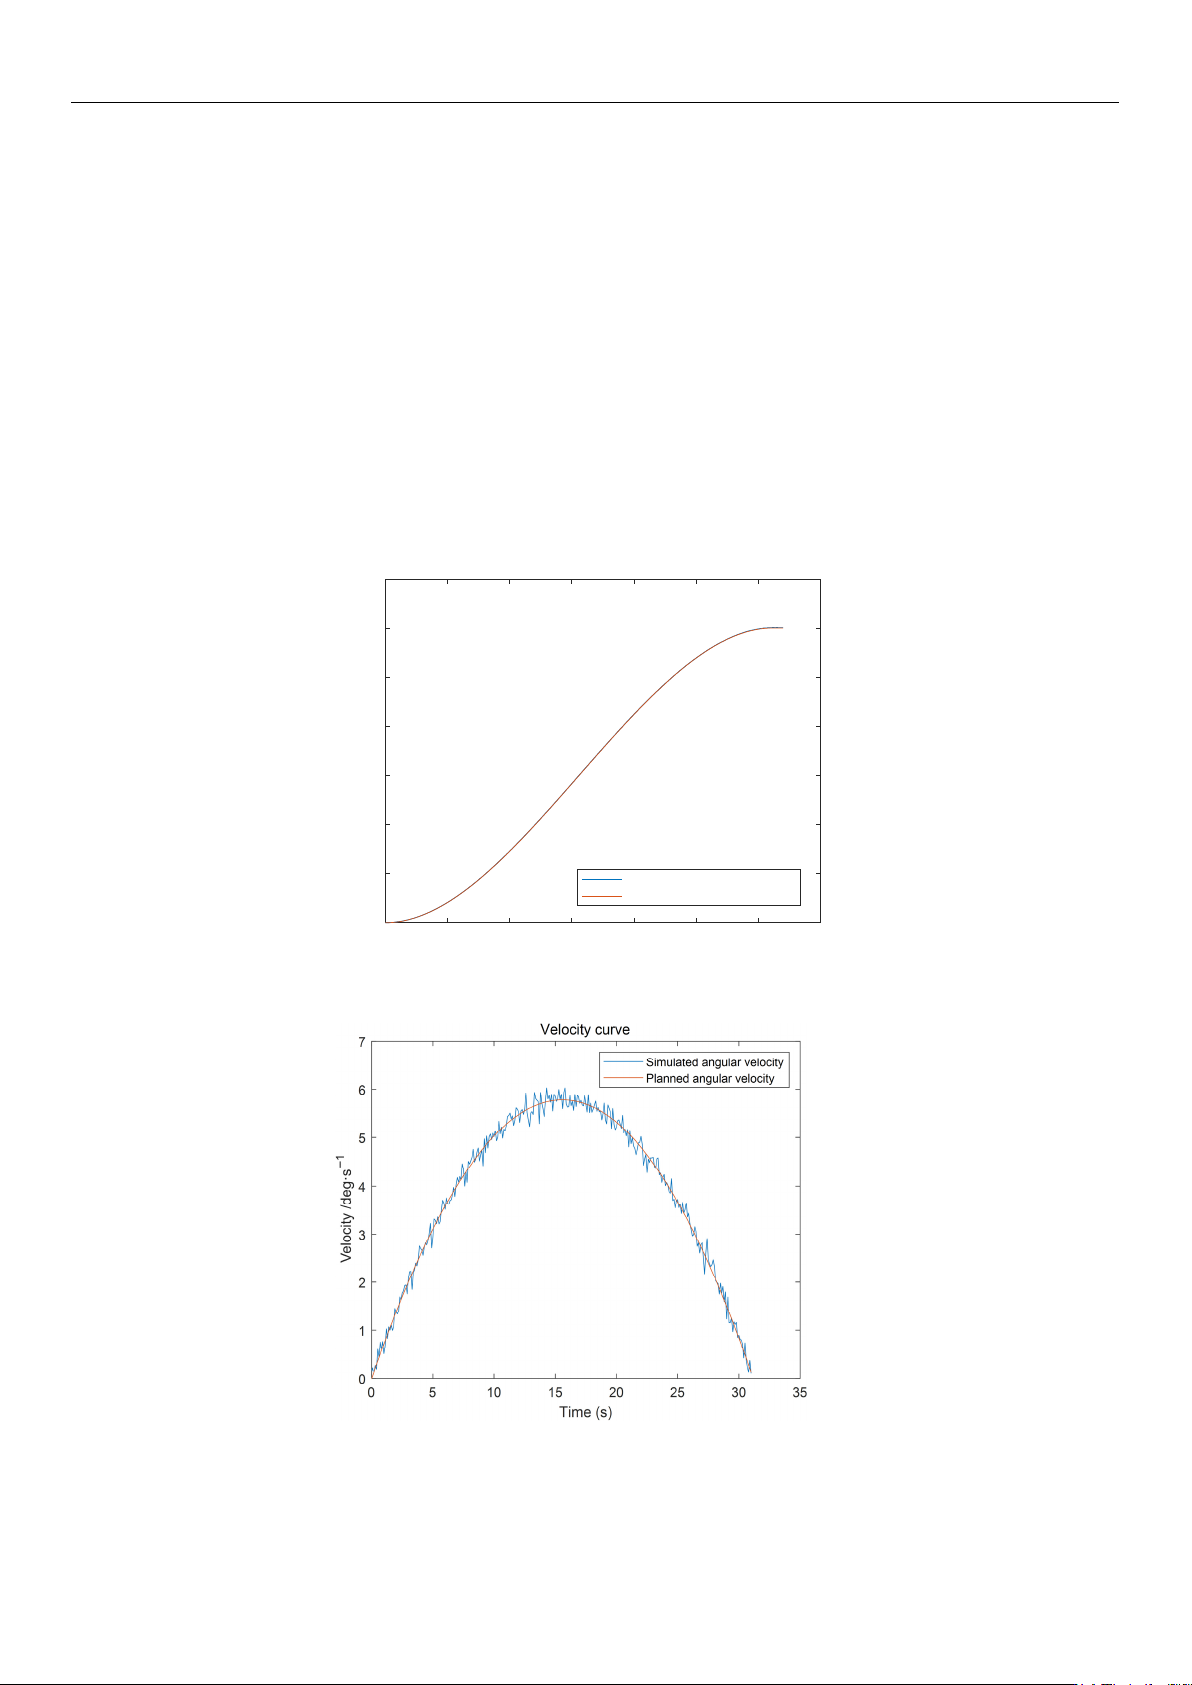
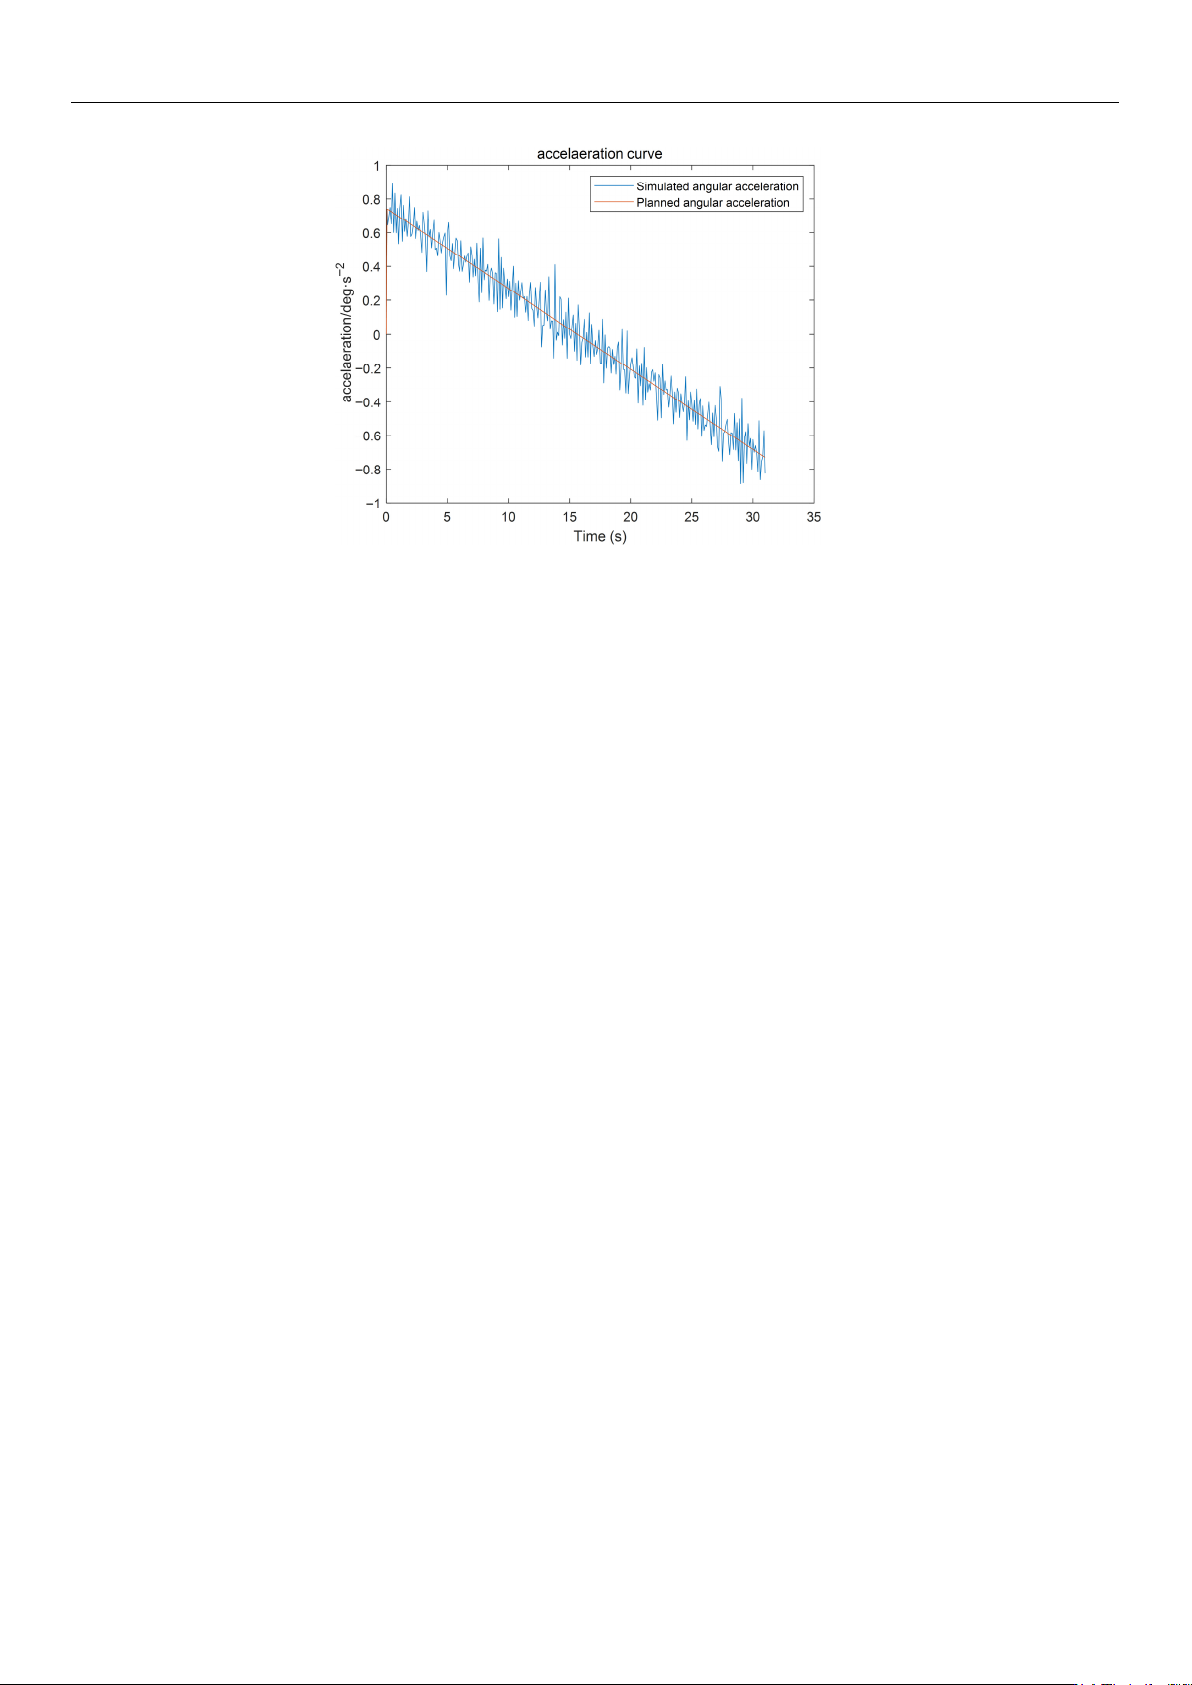
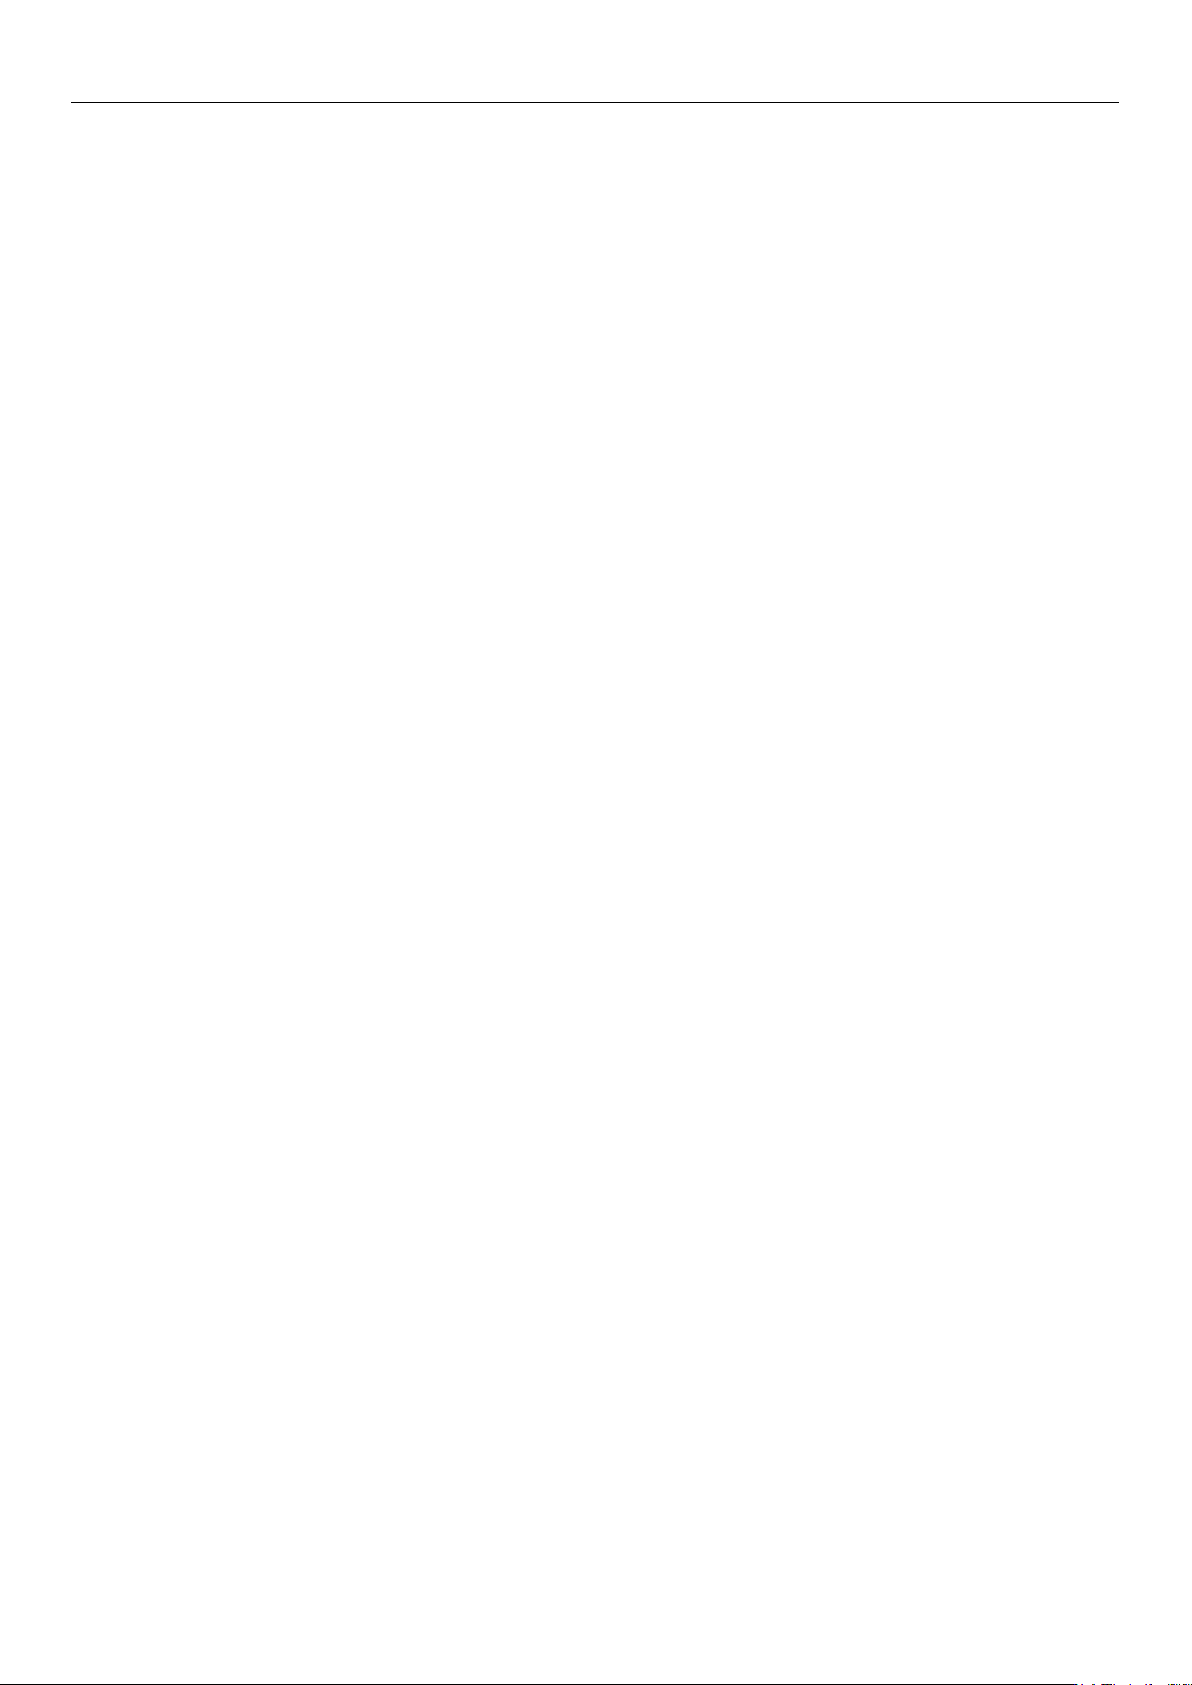
the To Workspace function, yielding the simulation results shown in Figures 18–20.
0 5 10 15 20 25 30 35
Time (s)
0
20
40
60
80
100
120
140
Displacement/deg
displacement curv
e
Simulated angular displacement
Planned angular displacement
Figure 18. Robotic Arm Displacement Curve.
Figure 19. Robotic Arm Velocity Curve.
https://doi.org/10.3390/s26030829
Sensors 2026, 26, 829
18 of 21
Figure 20. Robotic Arm Acceleration Curve.
As indicated by the simulation results in Figure 18, the planned joint angular displace-
ment profile of the forearm joint is in close agreement with the simulated tracking angular
displacement over the entire motion interval. The two curves almost overlap in the initial
stage, the acceleration and constant-velocity transition stage, and the final deceleration
stage, exhibiting an overall smooth S-shaped trajectory. In terms of tracking performance,
the tracking angular displacement shows no evident overshoot or oscillation throughout the
motion, and the steady-state error at the end is virtually negligible, demonstrating that the
system achieves favorable dynamic response characteristics and high steady-state accuracy.
As shown by the simulation results in Figure 19, the planned angular velocity of
the forearm joint agrees well with the simulated tracking angular velocity over the entire
motion interval, with only a negligible deviation observed in the vicinity of the peak
velocity. No evident overshoot or oscillation is observed, indicating that the controller can
accurately track the desired angular-velocity command and that the system exhibits high
velocity-tracking accuracy and stability. Such a smooth velocity profile is beneficial for
reducing vibration levels in the joint and links, and it also prevents inertial impacts induced
by abrupt acceleration/deceleration, which is crucial for maintaining posture stability and
operational safety during wafer handling.
Furthermore, the planned and tracked angular accelerations of the forearm joint
remain highly consistent throughout the motion, as shown in Figure 19. Only minor local
high-frequency fluctuations are present, and no abrupt spikes or severe reverse jumps
are detected. Therefore, the proposed planning method can fundamentally suppress
structural vibrations of the manipulator, thereby supporting the stable operation of the
wafer-transfer robot.
Based on the simulation results shown in Figures 18–20, the vibration suppression per-
formance of the proposed trajectory planning method is further validated. Compared with
conventional polynomial-based trajectory planning approaches, the planned joint angular
displacement, velocity, and acceleration profiles exhibit smooth transitions without evident
oscillations or abrupt fluctuations. In particular, the angular-displacement fluctuation is
constrained within 0.01 deg/s, quantitatively indicating effective disturbance rejection and
enhanced dynamic smoothness, thereby supporting the vibration-suppression effect of the
proposed jerk-minimization trajectory planning strategy.
Moreover, by introducing the proposed improved multi-objective Gray Goose Opti-
mization (MOGGO) algorithm, the solution quality of the dual-objective vibration suppres-
https://doi.org/10.3390/s26030829
Sensors 2026, 26, 829
19 of 21
sion trajectory optimization problem is significantly enhanced, benefiting from improved
population diversity and global search capability.
To further evaluate the robustness of the proposed method, random external torque
disturbances are introduced into the system. Under such disturbances, the tracking re-
sponses remain highly consistent with the planned trajectories, and no significant overshoot
or residual oscillation is observed during acceleration, constant-velocity, or deceleration
phases. In particular, the angular velocity fluctuation is effectively constrained within a
small range, indicating that high-frequency vibration components are significantly sup-
pressed. These results confirm that minimizing the jerk-based vibration energy index leads
to improved dynamic smoothness and enhanced vibration suppression capability of the
wafer-handling robotic arm.
7. Conclusions
This paper addresses the micro-vibration problem of wafer transfer robotic arms and
proposes and validates a vibration suppression trajectory optimization method based on the
Graylag Goose Optimization (GGO) algorithm. After theoretical derivation and simulation
tests, the following conclusions are drawn:
(1) This study established and analyzed the dynamic model of the wafer transfer
robotic arm based on the Lagrange method, providing a theoretical foundation for vi-
bration suppression trajectory planning. The model fully considers the flexible dynamic
characteristics of the robotic arm and accurately describes the system’s dynamic behavior.
(2) By combining a multi-segment polynomial trajectory planning method with a
residual vibration energy dissipation equation, a multi-objective optimization function
targeting both time-optimal performance and vibration energy was constructed. By rea-
sonably setting weight coefficients according to working conditions, a multi-objective
coordinated optimization was achieved to ensure trajectory smoothness and minimal
residual vibration energy.
(3) Simulation results show that when solving the dual-objective vibration suppression
trajectory optimization, introducing the proposed improved multi-objective Gray Goose
Optimization (MOGGO) algorithm effectively solves the dual-objective problem. The
results indicate that the derived trajectory, when subjected to random external disturbances,
maintains speed fluctuations basically within 0.01 deg/s, demonstrating good vibration
suppression performance.
However, this study only performed Pareto optimization for two objectives and has not
been extended to higher-dimensional, multi-objective optimization problems. Moreover, it
is limited to SIMULINK and MATLAB simulation environments. Future work will expand
to validation on a PLC platform and further explore the algorithm’s applicability under
more complex operating conditions and with additional optimization objectives.
Author Contributions: Conceptualization, Y.J.; Software, P.H.; Formal analysis, P.H.; Writing—
original draft, P.H.; Writing—review & editing, P.H.; Supervision, Y.J. All authors have read and
agreed to the published version of the manuscript.
Funding: This research was funded by the Basic Scientific Research Project of Higher EducationInsti-
tutions of Liaoning Province (grant number JYTQN2023064).
Institutional Review Board Statement: Not applicable.
Informed Consent Statement: Not applicable.
Data Availability Statement: The original contributions presented in this study are included in the
article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest: The authors declare no conflicts of interest.
https://doi.org/10.3390/s26030829