s25061872.pdf - 第18页
Sensors 2025 , 25 , 1872 18 of 24 optimization. Because the weights of time and impact are considered consistent in this study , both w 1 and w 2 are set to 0.5. Secondly , the time function F 1 and the impact function F…
Sensors 2025, 25, 1872
17 of 24
dimension (Dim) is 30, the ISO algorithm achieves an optimal fitness value of 0 for the F
1
and F
3
problems in the unimodal test function. Its convergence curve can rapidly jump
out and continue to decline after falling into the local optimum for a short time. This
indicates that the ISO algorithm can effectively escape from a local optimal solution and
successfully obtain a global optimal solution. By contrast, to a certain extent, the other five
algorithms fall into the local optimum. For the F
2
and F
4
problems, although the average
value of the ISO algorithm is not zero, the variance is zero, indicating that the algorithm
can obtain a global optimal solution to some extent. Its average precision is better than
that of the second ranked GWO algorithm. In addition, the convergence speed of the ISO
algorithm is faster than those of the other algorithms. For the F
5
problem, the performances
of the ISO algorithm and the other five algorithms are similar, but its overall optimization
precision is slightly higher, and the convergence curve is better, without falling into the
local optimum too early. Overall, the optimization effect of the ISO algorithm on unimodal
functions is significantly better than that of the other five algorithms. Further analyzing
Figure 9f–h, when the dimension (Dim) is 30 in the multi-modal test functions, the SO,
GWO, WOA, and ISO algorithms can achieve the global optimal value in the F
6
and F
7
problems with good overall performance, but the ISO algorithm has a faster iteration speed.
However, the performance of the six algorithms is not outstanding in the F
8
problem, but
the average value and variance of the ISO algorithm are the best, with an optimization
precision approximately twice that of the other algorithms. In summary, the ISO algorithm
demonstrates higher optimization precision in both unimodal and multi-modal functions
than the other algorithms. It also improves the avoidance of falling into the local optimum
compared to the SO algorithm, showing the expected optimization effect.
3.1.3. The Friedman Test
Further analysis of the results from 20 experimental groups using the Friedman test
method reveal significant differences in the overall performance of the six algorithms across
eight benchmark functions. It is a flexible and effective tool that does not depend on the
specific distribution of data, making it particularly suitable for comparing the algorithm
performance. When dimension (Dim) is set to 30, the average ranking of the mean and
variance of each algorithm is shown in Table 8. A lower average ranking indicates that
the algorithm performed better, and the results are more stable. According to the data in
Table 8, the ISO algorithm achieved the highest rankings in both mean value and variance.
Compared with the GWO algorithm, which ranked second, the average ranking score of the
ISO algorithm’s mean and variance are 38.9% higher. Combined with the SO algorithm, the
ISO algorithm shows a significant improvement in the average ranking score of the mean
and variance, reaching 60.8% and 63.4%, respectively. Considering the overall performance
of the algorithm, the ISO algorithm exhibits better performance in terms of stability and
convergence accuracy.
Table 8. The Friedman test table.
Algorithm SO SA PSO GWO WOA ISO
Mean rank 3.5 6 5 2.25 2.875 1.375
STD rank 3.75 6 4.875 2.25 2.75 1.375
3.2. Time-Jerk Optimal Trajectory Planning Based on ISO
After elaborating on the ISO algorithm and the modified S-shaped speed curve in
detail, a combination of the two is performed. The objective function is obtained in this
study, as presented in Equation (4). Firstly, Equation (4) adopts a compromise algorithm by
adjusting the values of w
1
and w
2
to determine the equilibrium point in the multi-objective
Sensors 2025, 25, 1872
18 of 24
optimization. Because the weights of time and impact are considered consistent in this
study, both w
1
and w
2
are set to 0.5. Secondly, the time function F
1
and the impact function
F
2
belong to different categories of physical quantities. When the weighted sum of their
calculation results is taken directly, it leads to an imbalance between the time and impact.
To address this issue, a minimum–maximum normalization method is employed in this
study. It is typically used to eliminate the influence of dimensions among different features,
making the data comparable on the same scale, as shown in Equations (28) and (29).
F
1_norm
=
F
1
−min(F
1
)
max(F
1
) − min(F
1
)
(28)
F
2_norm
=
F
2
−min(F
2
)
max(F
2
) − min(F
2
)
(29)
After the above operations, the domains of the values for F
1
and F
2
functions are
restricted within the same range. Based on this, a set of excellent solutions is selected
by solving a multi-objective function. Then, the optimal solution is identified using the
Pareto optimization method. The Pareto judgment standard is as follows. If a new solution
improves at least one objective without causing a performance decline in other objectives,
then the new solution is considered to be superior to the original solution. When these
Pareto optimal solutions are smoothly connected, a Pareto frontier is formed. Ultimately,
this study aims to determine a balance point on this curve to achieve the best overall effect.
The specific parameter configuration of the simulation experiment can be found in
Table 9 for the application of the ISO algorithm to the S-shaped speed curve optimization
problem, and the kinematic parameters are set according to Industrial Robot ISO 9283:1998.
In the simulation experiments, a
max
and j
max
are set as independent variables and their
upper bound (ub) and lower bound (lb) are between 80 and 120. In the SO algorithm,
the empirical values of threshold parameters threshold
1
, threshold
2
, and threshold
3
are
0.25, 0.6, and 0.6, respectively. To determine more reasonable parameter combinations, the
ranges of these thresholds are unified and adjusted. The range of threshold
1
is limited
to 0.05 to 0.45, while the ranges of threshold
2
and threshold
3
are adjusted to 0.4 to 0.8.
Correspondingly, the search range of the threshold parameter (Bayesian threshold) in the
Bayesian optimization process is also set to 0.05 to 0.8 to facilitate determining the optimal
parameter configuration. The other parameters have the same meanings as those described
earlier. The Bayesian optimization threshold simulation results are shown in Table 10,
which includes the iteration, the actual observed objective value of the current iteration,
the best observed value among all observations (BestSoFar_observed), the model-predicted
best value (BestSoFar_estimated), and the best thresholds combination obtained in this
generation. However, because there are not enough data to support the construction of
the first-generation model of Bayesian optimization, Objective, BestSoFar_estimated, and
BestSoFar_observed are not included in the calculation. In addition, a simulation diagram
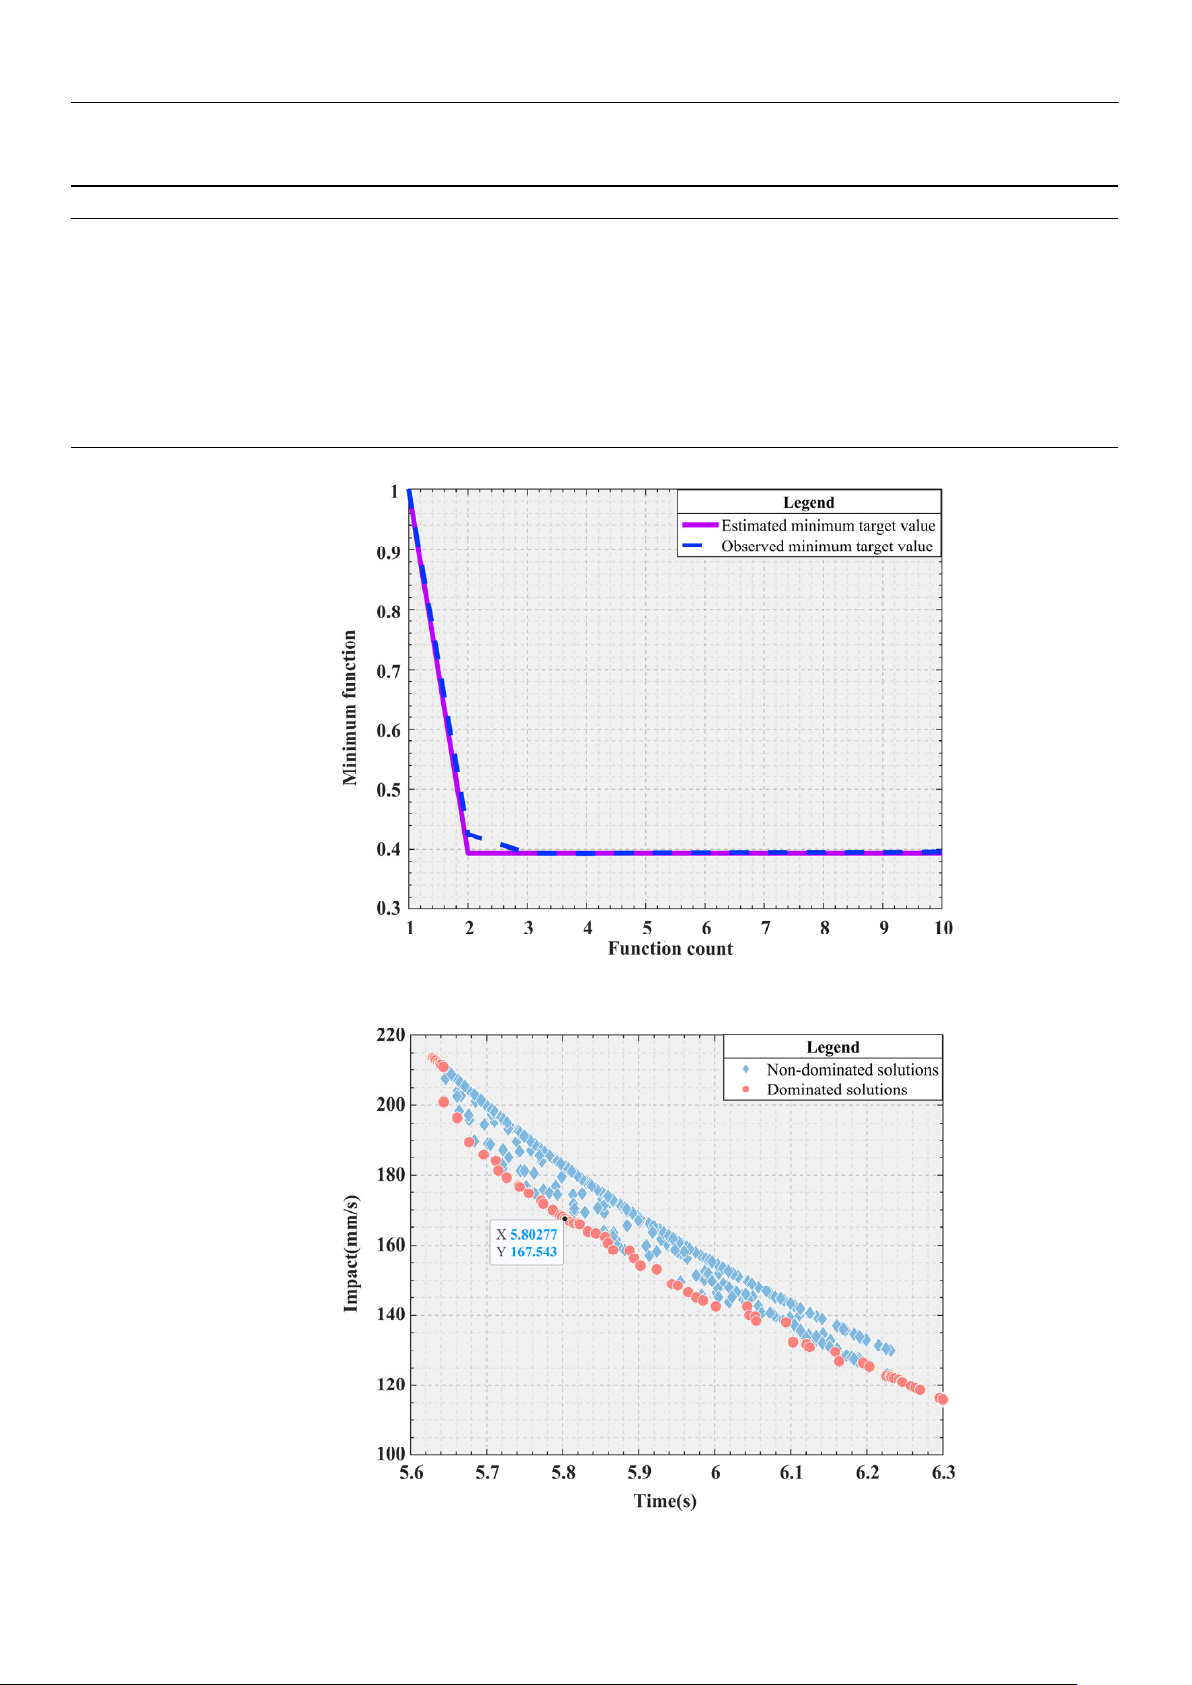
of the minimum objective value and function calculation times corresponding to Bayesian
optimization is shown in Figure 10, where the initial value of the first generation is replaced
by number 1. For the dual-objective optimization problem considered in this study, the
distribution of the Pareto frontier is generally in the form of a curve, which is intuitively
shown in Figure 11.
Table 9. The main parameter setting.
v_ p
0
(mm/s)
v_ p
1
(mm/s)
v_ p
2
(mm/s)
v
max
(mm/s)
r
1
(mm)
Bayesian
Evaluations
Bayesian
Threshold
T
max
Dim N lb ub
0 100 0 100 30 10 [0.05,0.8] 100 2 20 [80,120] [80,120]
Sensors 2025, 25, 1872
19 of 24
Table 10. The iterative graph of Bayesian thresholds.
Iteration
Objective BestSoFar (Observed) BestSoFar (Estimated) Threshold
1
Threshold
2
Threshold
3
1 — — — 0.4227 0.7616 0.5225
2 0.3936 0.3936 0.4255 0.0989 0.7764 0.5705
3 0.3952 0.3936 0.3936 0.1721 0.7210 0.7933
4 0.3969 0.3936 0.3932 0.0752 0.4968 0.5437
5 0.3953 0.3936 0.3942 0.1403 0.6057 0.7633
6 0.3991 0.3936 0.3946 0.0500 0.5764 0.5441
7 0.3957 0.3936 0.3949 0.1485 0.5278 0.4003
8 0.3969 0.3936 0.3951 0.1113 0.7425 0.4637
9 0.3955 0.3936 0.3951 0.1592 0.7106 0.7313
10 0.3979 0.3936 0.3958 0.1587 0.6833 0.6341
Sensors2025,25,xFORPEERREVIEW 20 of 25
Figure10.Functioncount.
Figure11.Paretofrontier.
ToverifytheperformanceofBayesianoptimizationinoptimizingtheparametersof
theobjectivefunction,a5‐foldcross‐validationmethodwasadoptedinthisstudy.The
experimentalresultsareshowninFigure12.Itcanbeclearlyseenthattheperformance
ofthismodelduringthe5‐foldcross‐vali da tio n
processisrelativelystable,withasmall
fluctuationrangeoftheSingleScores,whichfullyindicatesthatthemodelhasacertain
fittingability.Generallyspeaking,across‐validationscorewithi n0.2canbere ga rd ed
asexcellent, andascorebetween0.2and0.5indicatesaverageperformance.Theaver‐
age
scoreofthisexperimentisapproximately0.4,whichindicatesthatthemodelhasa
certainpredictiveabilityonthisdatasetasa whole,butthereisstillroomforimprove‐
ment.
Figure 10. Function count.
Sensors2025,25,xFORPEERREVIEW 20 of 25
Figure10.Functioncount.
Figure11.Paretofrontier.
ToverifytheperformanceofBayesianoptimizationinoptimizingtheparametersof
theobjectivefunction,a5‐foldcross‐validationmethodwasadoptedinthisstudy.The
experimentalresultsareshowninFigure12.Itcanbeclearlyseenthattheperformance
ofthismodelduringthe5‐foldcross‐vali da tio n
processisrelativelystable,withasmall
fluctuationrangeoftheSingleScores,whichfullyindicatesthatthemodelhasacertain
fittingability.Generallyspeaking,across‐validationscorewithi n0.2canbere ga rd ed
asexcellent, andascorebetween0.2and0.5indicatesaverageperformance.Theaver‐
age
scoreofthisexperimentisapproximately0.4,whichindicatesthatthemodelhasa
certainpredictiveabilityonthisdatasetasa whole,butthereisstillroomforimprove‐
ment.
Figure 11. Pareto frontier.