mi17050592.pdf - 第6页
Micromachines 2026 , 17 , 592 6 of 34 2.3. Alignment Optimization Algorithms The selection of the optical alignment search algorithm fundamentally determines both the speed and the reliability of the per-die coupling ste…
Micromachines 2026, 17, 592
5 of 34
a systematic optimization of optical alignment routines specific for high-throughput PIC
testing, confirming that algorithm selection has a direct and quantifiable impact on test
throughput and yield in production environments [
11
]. Fully automated edge-coupling
probers have further shown that optimized optical search routines and move sequences
can reduce per-die alignment time to the multi-second range, yielding throughputs on the
order of several thousand optical alignments per hour in single-fiber scenarios [10].
A complementary challenge, intimately linked to both alignment speed and precision,
concerns the motion stage itself. In automated PIC assembly and test, the demands for high
positioning precision and high throughput are fundamentally opposed: operating a motion
stage faster imposes higher control bandwidth requirements and degrades repeatability [
20
].
Mandelli et al. developed machine-learning models to predict motion stage precision as
a function of operating speed for PIC assembly systems, demonstrating that data-driven
approaches can characterize and compensate for these trade-offs without offline calibration
runs [
20
]. These findings directly motivate the evaluation of high-speed operating regimes
in the present work, and the need to understand how alignment algorithms degrade under
reduced repeatability conditions.
2.2. Optical Coupling Methods
Two primary optical coupling architectures are relevant to wafer-level PIC testing,
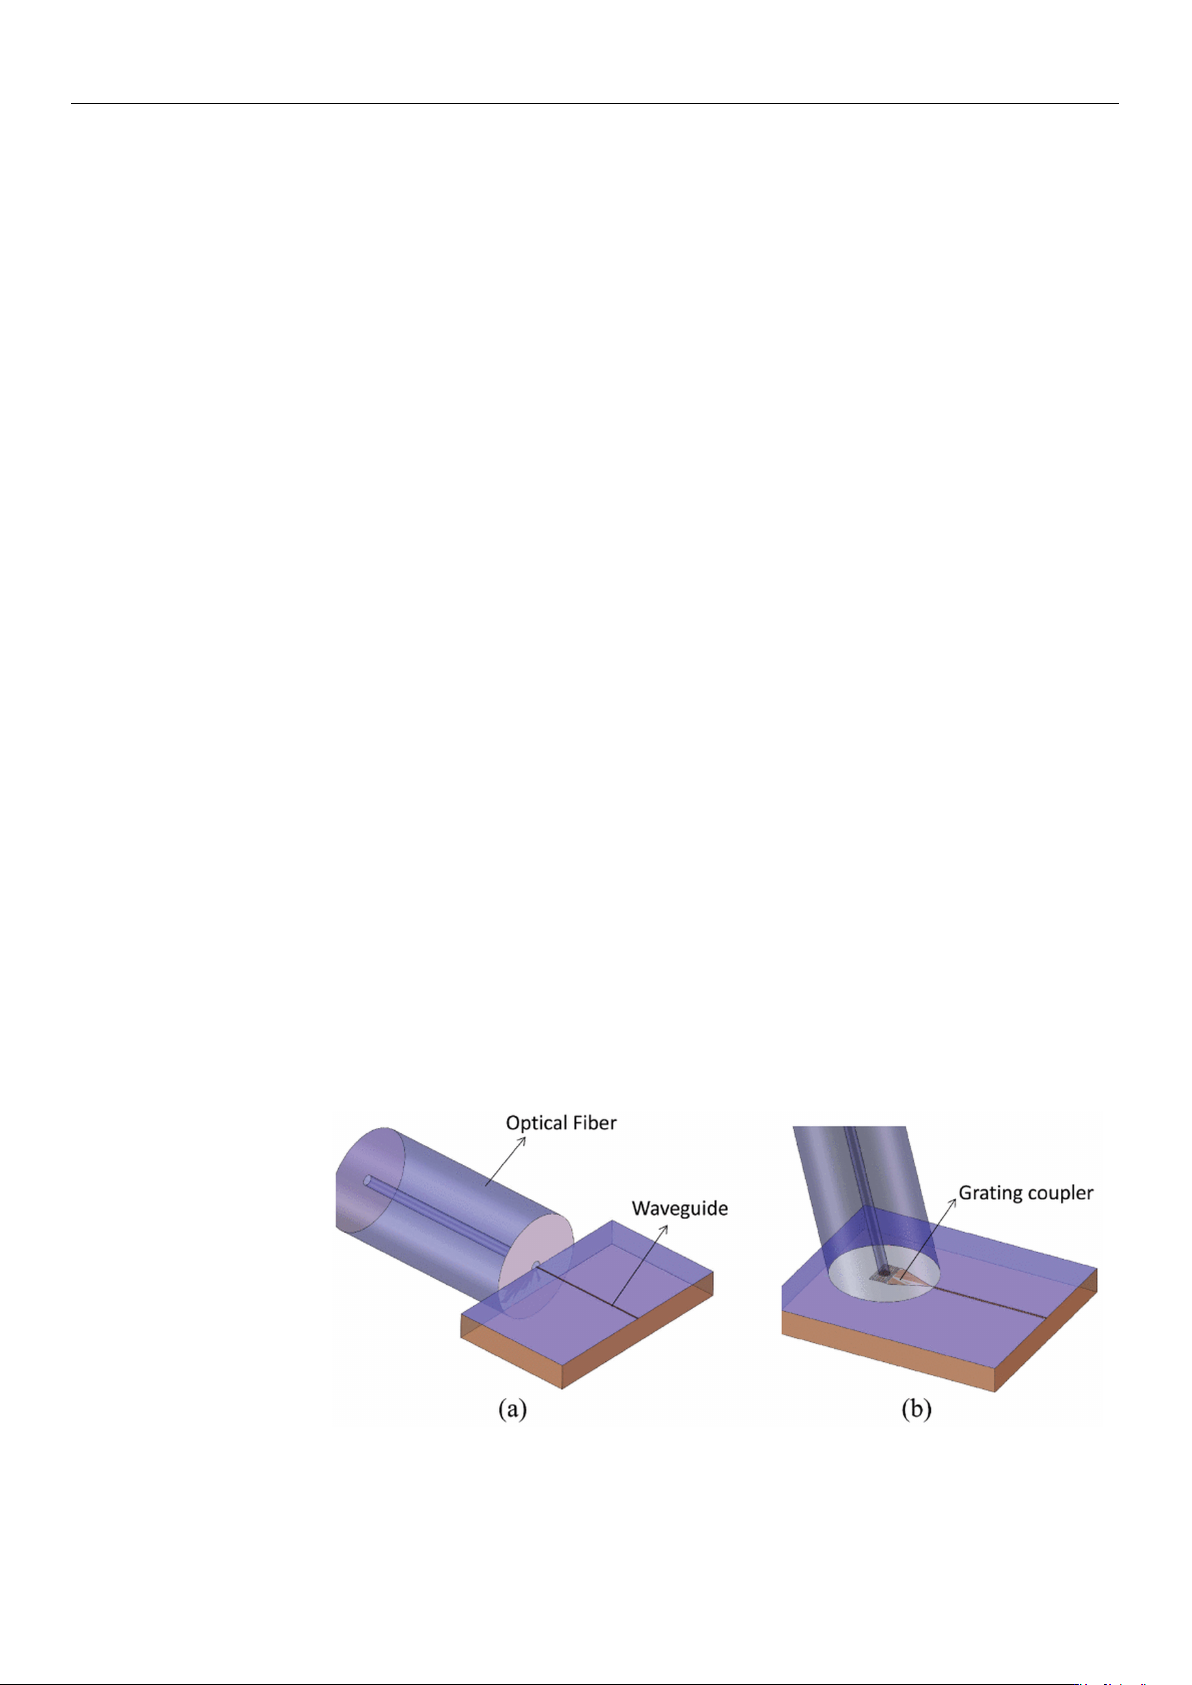
as illustrated in Figure 1. As a foundational concept, edge couplers offer high coupling
efficiency and broad optical bandwidth by laterally aligning an optical fiber to the cleaved
or polished chip edge, requiring tight positional tolerances (typically below 1
µ
m) [
21
,
22
].
However, as illustrated conceptually in Figure 1a, pure lateral access is often physically
impossible in densely packed wafer-scale environments, necessitating the use of specialized
vertical-to-horizontal beam delivery tools. Grating couplers provide a more convenient
vertical-incidence interface compatible with full-wafer probing without edge preparation,
but at the expense of higher insertion loss, narrower wavelength bandwidth, and moderate
polarization sensitivity [23,24].
Most integrated probe card solutions for grating couplers rely either on external
positioning stages or on beam-expansion optics to reduce sensitivity to lateral misalignment,
the latter incurring an additional insertion-loss penalty [
25
]. The Eclipse Dynamic system
investigated here targets grating coupler interfaces, where the piezoelectric FAU provides
the fine positioning needed to maximize coupling efficiency across the full 15
µm ×
15
µm
scan range.
Figure 1. Schematic diagrams of the two primary optical coupling approaches: (a) traditional
horizontal edge coupling (which, for high-density wafer-level testing, is modified using micro-lenses
to allow vertical fiber access) and (b) Grating coupling [26].
https://doi.org/10.3390/mi17050592
Micromachines 2026, 17, 592
6 of 34
2.3. Alignment Optimization Algorithms
The selection of the optical alignment search algorithm fundamentally determines
both the speed and the reliability of the per-die coupling step in photonic testing. Conven-
tional procedures have historically relied on brute-force scanning or iterative hill-climbing
techniques to locate the optimal coupling position. A typical approach involves raster or
spiral scanning, where the optical fiber is translated exhaustively across a multidimensional
grid until an initial optical signal is detected, followed by dense sweeps to map the cou-
pling efficiency landscape and identify the peak. Although robust to complex landscape
topologies, these exhaustive methods require a prohibitively large number of actuator
motions and power readings. Consequently, they can consume dozens of seconds for
a single alignment, making them impractical for high-volume manufacturing scenarios,
especially when multiple degrees of freedom are involved [
4
]. To mitigate this measure-
ment burden, cross-scan or dimensional-reduction approaches sequentially sweep along
individual axes to identify approximate peak coordinates before performing a focused local
refinement scan.
To further accelerate the alignment process, modern systems increasingly employ ad-
vanced optimization algorithms, such as gradient-based searches. These methods estimate
local coupling gradients, often through small dither motions, and steer the optical array in
the ascent direction to rapidly approach the optimum. Analogous to numerical gradient
descent or ascent, this targeted approach can converge significantly faster than blind scan-
ning. For instance, substituting a coarse spiral scan with an optimized gradient search has
been shown to yield an approximate 5
×
reduction in fiber coupling time [
10
]. Despite their
simplicity and speed, gradient methods are inherently susceptible to local maxima in the
measured optical power and require careful tuning of step-size parameters, particularly
when the coupling landscape contains secondary lobes or is distorted by actuator nonlin-
earities [
10
,
11
]. A central tension in these systems lies in balancing aggressive, adaptive
step sizes that yield the fastest convergence on benign landscapes against conservative,
fixed step sizes that maintain reliability on more challenging topologies.
As a powerful alternative, Bayesian optimization (BO) utilizing Gaussian Process (GP)
surrogates has emerged to address the limitations of both grid-based and gradient methods.
This approach treats the coupling yield as an unknown black-box function, building a
probabilistic surrogate model that is iteratively updated with each measurement [
27
].
By intelligently maximizing an acquisition function such as Expected Improvement, the
optimizer strategically balances the exploration of uncertain regions against the exploitation
of known high-power areas. This enables the algorithm to infer the global landscape
shape and locate optima using far fewer evaluations than traditional methods. Originally
popularized in complex domains like X-ray beamline autoalignment [
28
] and online control
of particle accelerators [
29
], BO excels in environments where the objective function is
expensive to evaluate and subject to noise. These characteristics are highly analogous
to optical power measurements affected by piezoelectric nonlinearities and mechanical
vibrations. Machine-learning-driven alignment has similarly demonstrated success in
multidimensional free-space optical systems and lens assemblies, proving the efficacy of
Bayesian algorithms in handling complex alignments with minimal iterations [30].
Within the BO family, two distinct paradigms are particularly relevant to the photonic
alignment problem. Global BO explores the entire search space from the outset, relying
purely on the GP posterior to select the next sampling location. While this maximizes
coverage and sample efficiency, it scales poorly with search-space dimensionality and can
be sensitive to landscape distortions introduced by actuator nonlinearities. Conversely,
local BO restricts the search to a neighborhood around a promising region identified by
an initial coarse scan. This restricted approach sidesteps the curse of dimensionality and
https://doi.org/10.3390/mi17050592
Micromachines 2026, 17, 592
7 of 34
delivers strong empirical performance while maintaining rigorous convergence guaran-
tees [
31
]. Theoretical analyses have characterized the asymptotic behavior of local BO,
confirming conditions under which locally found stationary points closely approximate
the global optimum [
31
]. Furthermore, replacing standard gradient-descent exploitation
with a strategy that minimizes the upper confidence bound over the GP posterior yields
tighter theoretical guarantees and improved empirical results [
32
]. These theoretical ad-
vances directly motivate localized Bayesian strategies, which combine a coarse cross-scan
initialization with a focused GP refinement step.
Beyond the optimization of single-channel algorithms, the transition toward par-
allel, multi-channel alignment represents a critical advancement for wafer-level testing.
Because modern integrated probe architectures can simultaneously engage multiple in-
put and output fiber pairs across a die, applying alignment algorithms concurrently to
all channels drastically shortens the overall test time. Aligning channels sequentially is
highly inefficient; instead, coordinated multi-dimensional searches that optimize all optical
ports together are essential for maximizing throughput. Ultimately, the field is rapidly
transitioning from simplistic single-variable scans toward intelligent, multi-variable, and
machine-learning-augmented optimizations. Through the integration of these advanced
algorithmic approaches, the optical alignment step can be reduced to a minor fraction of
the total test time, making active alignment on the scale of a few seconds a viable reality for
high-volume production.
2.4. Hysteresis and Nonlinearity Compensation
Piezoelectric actuators are extensively utilized in nanometric alignment systems due
to their high resolution and rapid response times. However, a persistent challenge is their
inherent hysteresis and creep. The displacement produced by the actuator at a given
drive voltage depends not only on that specific voltage but on the entire preceding voltage
history, a phenomenon driven by domain-wall motion and polarization switching within
the piezoelectric ceramic [
13
]. In open-loop operation, this path-dependent nonlinearity
typically introduces positioning errors spanning 10–15% of the total travel range [
33
]. Such
substantial deviations far exceed the strict sub-micron tolerances required for reliable
fiber-to-waveguide alignment in PICs.
The traditional remedy for addressing hysteresis is closed-loop control. By integrating
an embedded feedback sensor such as a capacitive sensor, strain gauge, or linear variable
differential transformer (LVDT), and utilizing PID or iterative control, systems can dynami-
cally correct positioning errors to achieve sub-nanometer accuracy. While highly effective,
closed-loop architectures introduce significant drawbacks: they are more expensive, impose
bandwidth limitations, and add substantial hardware complexity. For dense, multi-channel
probe heads (e.g., a 16-channel array), embedding a dedicated physical sensor and its asso-
ciated wiring on every piezoelectric axis is highly impractical. Position sensors, moreover,
require space for installation that is not available in the application hereby discussed.
To circumvent these hardware limitations, the preferred strategy is open-loop control
enhanced by software-based feedforward compensation algorithms. By characterizing the
hysteresis behavior of the piezo and applying an inverse model to the drive signals, the
response of the actuator can be effectively linearized. This software-driven approach scales
effortlessly across several channels without the prohibitive overhead of extra hardware.
Over the past two decades, various frameworks have been developed to model and com-
pensate for piezoelectric hysteresis. Classical approaches include the Preisach model, which
captures hysteresis through a superposition of elementary bistable operators, and the P-I
model, which employs a weighted sum of play operators [
14
,
15
]. Conceptually, a play
operator acts as a mathematical representation of mechanical backlash: its output remains
https://doi.org/10.3390/mi17050592