User-Manual-NeoDen3V-PNP-machine.pdf - 第25页
20 9) V acuum value: use d for vacuu m test, value ca n b e set against a ctual ne ed. 10) Flash type: outside light 11 ) Skip: Once select th is item, will skip a ll plac ement u nder this feeder. 12) T est wa y: the re…
19
situation, such as the actual 1
st
component is in 2
nd
row, 1
st
column, then type into X2, Y1.
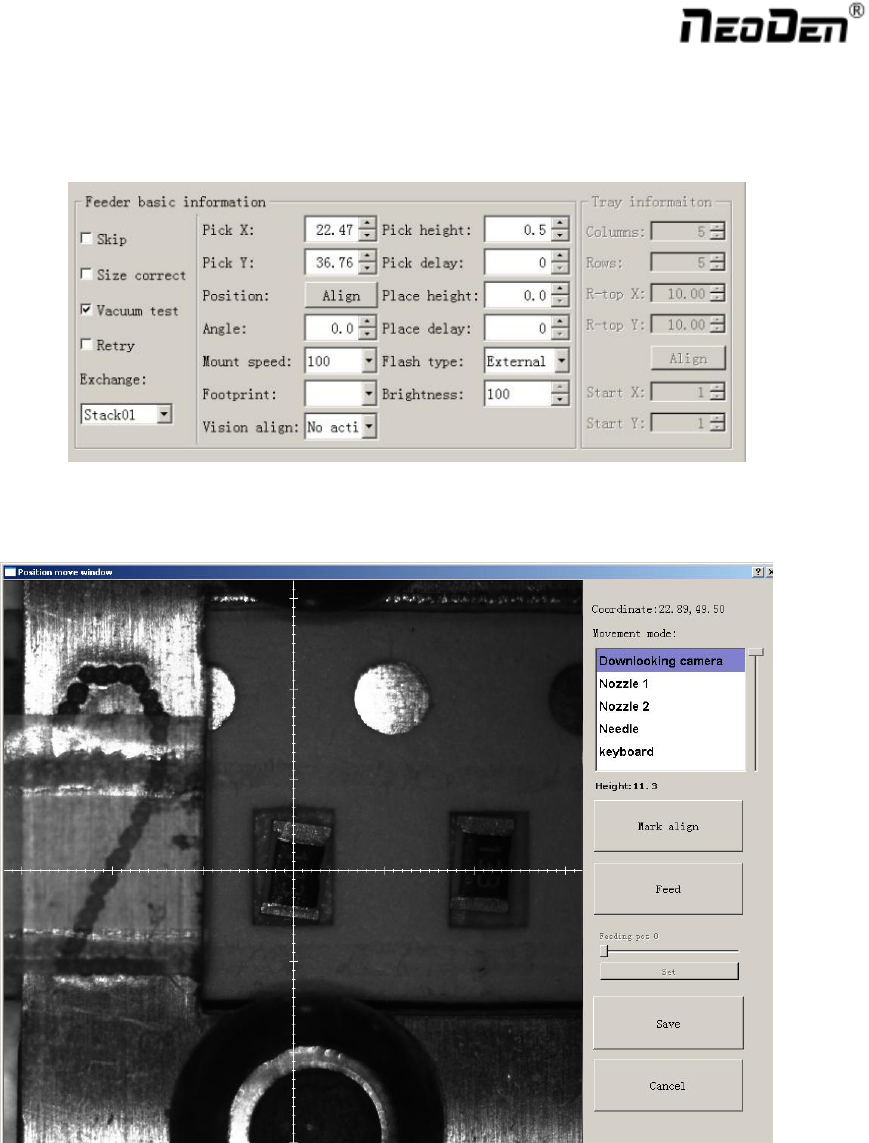
Feeder Basic Information:
1) Firstly click the “Align” under “Position” function, camera will lock the component position on the feeder,
once the modification saved, Pick X/Y data will automatically change to the ones after alignment.
2) Angle: default is 0 degree, support to modify the value to change the mounting angles for wholly feeder.
3) Placement speed: Control the placement speed under this feeder.
4) Footprint: Select corresponding footprint, and in vision alignment, system will take reference of the values in
Footprint Library.
5) Vision: 2 ways as choice against actual need---No action, Jointly .
6) Pick height: control the placement height by dragging the sideward slider.
7) Place height: Set the value according to the exact component thickness.
8) Placement/Pick delay: set a little or 0 both ok.
20
9) Vacuum value: used for vacuum test, value can be set against actual need.
10) Flash type: outside light
11) Skip: Once select this item, will skip all placement under this feeder.
12) Test way: there’re two test methods, Vacuum test /Vision test.
13) Vacuum test : Once “Vacuum test” was selected, the sensor of air pressure will be turned on. So if actual
vacuum hasn’t reached the default value during picking process, machine will drop it and re-pick a
component.
14) Exchange: This may be used in actual situation, if exchange needed between two feeders, you can choose one
feeder, and go to find the exact feeder you need replacement in drop-down box, select, then done.
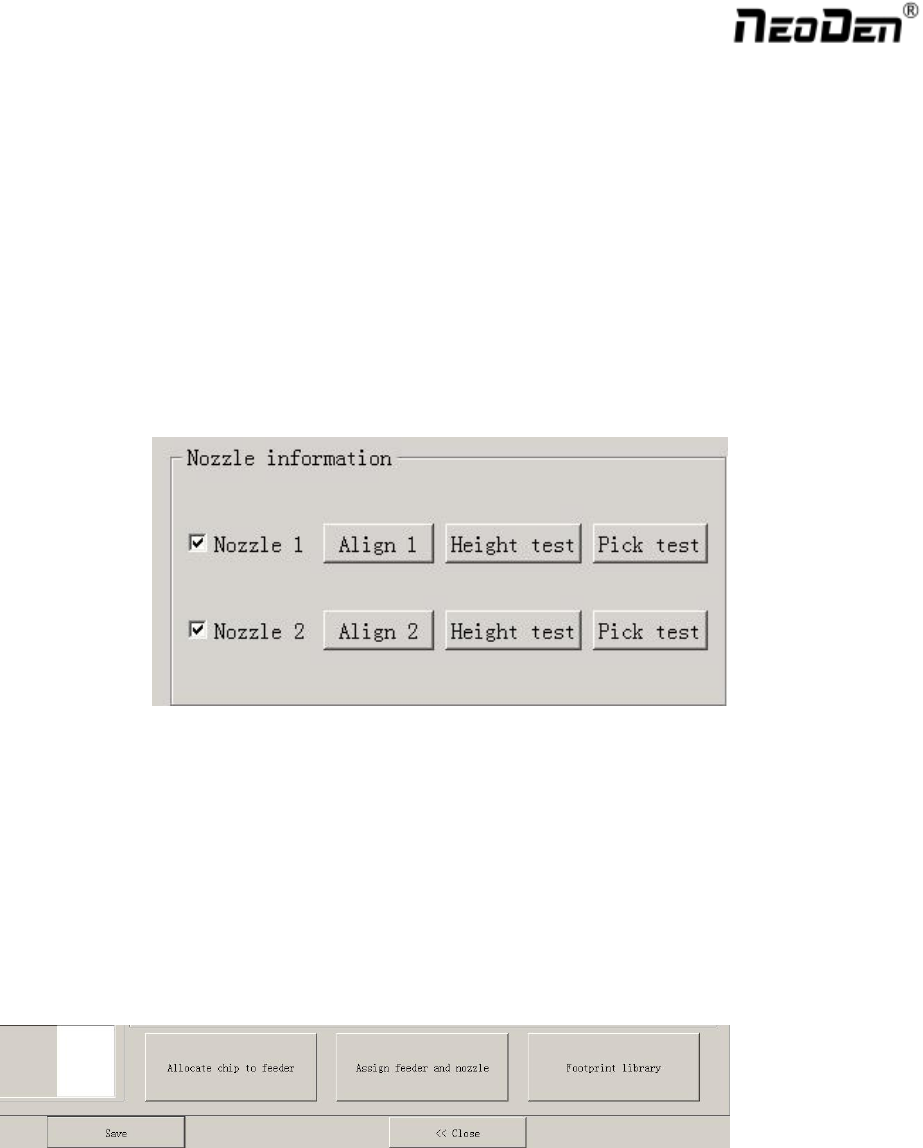
Nozzle Information
Function: Select corresponding nozzle according to actual component size, and it will automatically assign to each
feeder to meet the requirements of single head or multi heads working. Also with below function as Pic.(2.1.5.2-5)
1) Align: Nozzle will align to component’s upside on corresponding feeders after clicking this item ( can be
adjusted manually) .
2) Height test: After clicking this item, nozzle will do down and check whether the pick height is ok. Support do
adjustment of pick height on feeder information item if needed.
3) Pick test: After clicking this item, the corresponding nozzle will pick one component and check whether pick
position is ok. Support do adjustment of pick position on feeder information item if needed.
After finish setting of all above feeder information, you can click “assign feeder and nozzle ”, then chip list will
automatically to be changed correspondingly.
21
2.2. File Mount
First select one file, click”mount”, then you will enter into mounting interface, above picture is an example of one
file in mounting.
1) On the top-left corner shows mounting process, chip list---by the variation of white line, you can track
process of mounting constantly.
2) On the bottom-left corner shows some feedback during mounting process.
3) On the top-right corner shows the status of picking and picking alignment
4) On the top-right corner shows some control information:
5) Real-time air pressure of 2 nozzles
6) Placement speed, can be changed by manual during mounting
7) Continuous,this is used in one-stop smt production line, add conveyors in front and behind,
8) Auto-eject PCB once finished, when select this option, after finished mounting task, PCB will eject its
working area automatically
9) Other control information,Start&Continuous/Step/Pause(stop)/Eject PCB front/Stop
10) The machine will execute command and work constantly
Step: The machine will work one single step
Pause: The machine will stop its work instantly
Eject PCB Front: In order to catch the PCB, after PCB assembly, click this option, PCB will eject from its
feeding position. Kindly notice: After pause the machine then you can execute required command.
Exit: before click this option, you need to click “stop” first