Infinity EX Camera System Module.pdf - 第14页
INFINITY EX CAME RA SY STEM MO DULE SEQUEN CES 17.1 4 Technical Reference Manual Chapter Issue 3 Jan 04 Camera Sequ ence - No In specti on, No SPC PULNIX TM-6EX PULNIX TM-6EX PULNIX TM-6EX PULNIX TM-6EX PULNIX TM-6EX WAR…
INFINITY
EX
CAMERA SYSTEM MODULE
SEQUENCES
Chapter Issue 3 Jan 04 Technical Reference Manual 17.13
SEQUENCES
Homing Sequence Each camera axis homes when the machine initializes (power-up or exit diag-
nostics).
The respective axis drives towards its home sensor until its vane is detected, the
motor reverses direction until the home sensor clears the vane and stops when
the next encoder index pulse is reached.
The sequence starts by driving the Y axis into its respective home sensor
followed by the X axis completing its home routine. See the Camera X Axis and
Camera Y Axis figures for details of the X and Y home sequences and the
relationship between the encoder and axis movement.
INFINITY
EX
CAMERA SYSTEM MODULE
SEQUENCES
17.14 Technical Reference Manual Chapter Issue 3 Jan 04
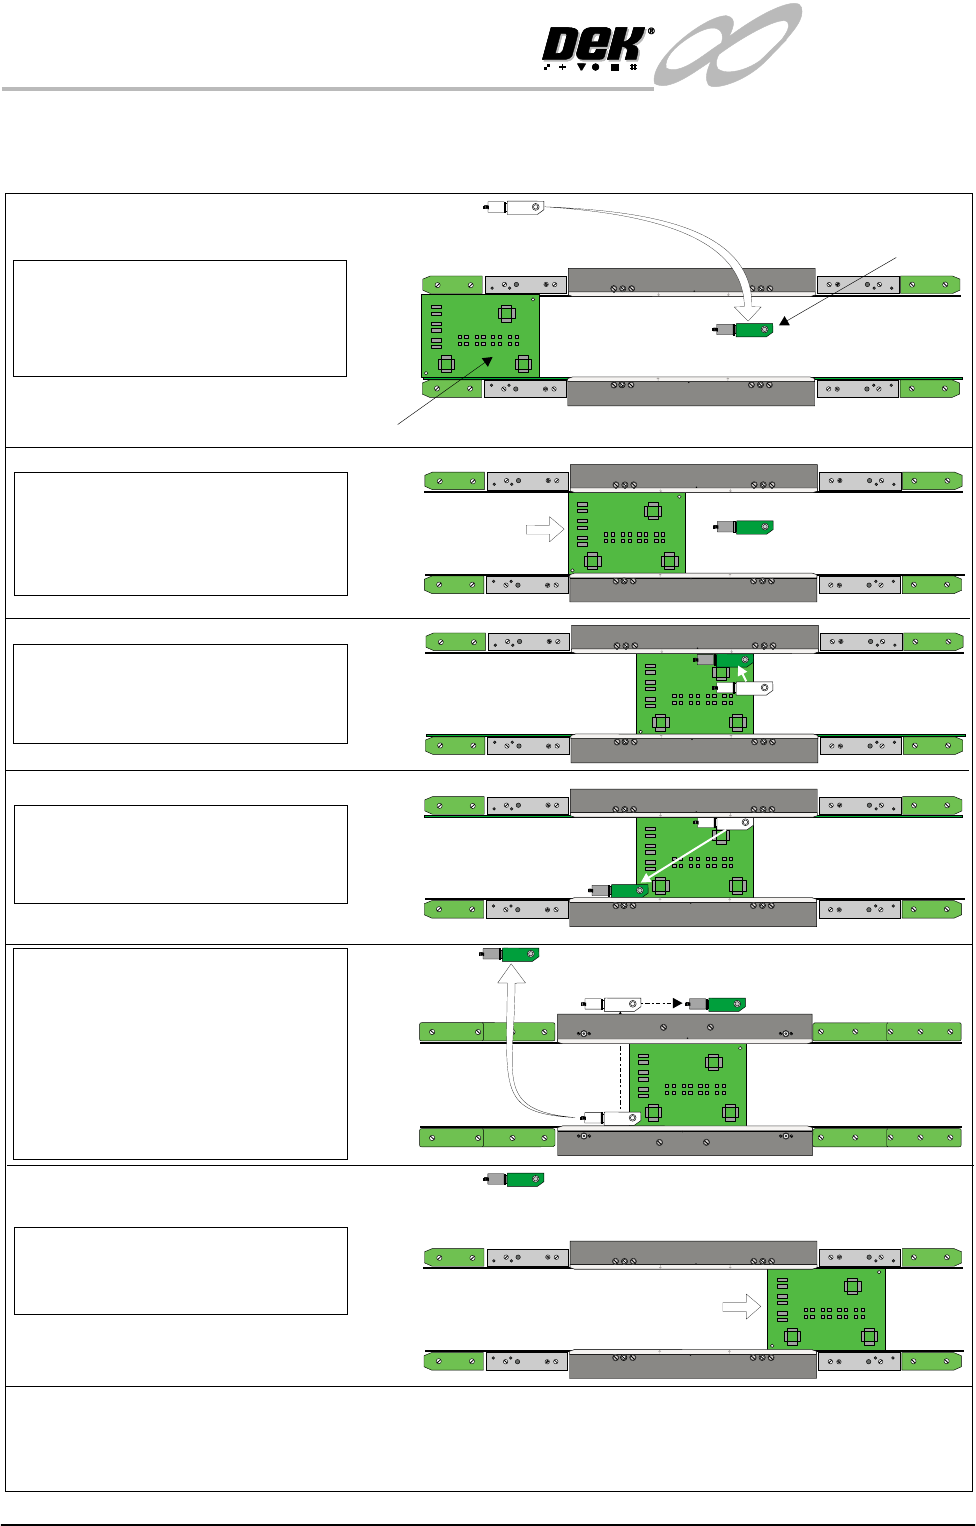
Camera Sequence - No Inspection, No SPC
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
Plan View on Rails (Printhead Removed)
Board
Camera
Step 1
Machine is initialized. Run is pressed on
MMI, the camera is driven to the board stop
coordinates. The board stop is lowered.
Step 2
The board is transported into the machine
stopping at the board stop and the board
clamps are activated. The board stop is
retracted.
Step 3
The camera is driven to Fiducial 1
coordinates. Fiducial capture sequence is
completed.
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
Step 4
Camera is driven to Fiducial 2 coordinates.
Fiducial capture sequence is completed.
Screen alignment is carried out.
Step 5
The camera is driven to the home position.
The print sequence is carried out.
NOTE
If Camera Idle Position is set to Behind Rails
the camera is initially driven to a position
behind the rails in-line with Fiducial 2 and
during the print cycle to a position behind
the rear rail in-line with the board stop.
NOTE
With selective print/pass through enabled, after Step 2 the camera is driven to the select mark coordinates. If the select mark
is recognized the sequence continues with Step 3. If the select mark is not recognized, the board is not printed and the sequence
passes straight to Step 6.
Step 6
The board exits the machine. The sequence
is repeated for subsequent boards.
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENTNo.5157438
WARNING-SHARP EDGE
PATENTNo.5157438
INFINITY
EX
CAMERA SYSTEM MODULE
SEQUENCES
Chapter Issue 3 Jan 04 Technical Reference Manual 17.15
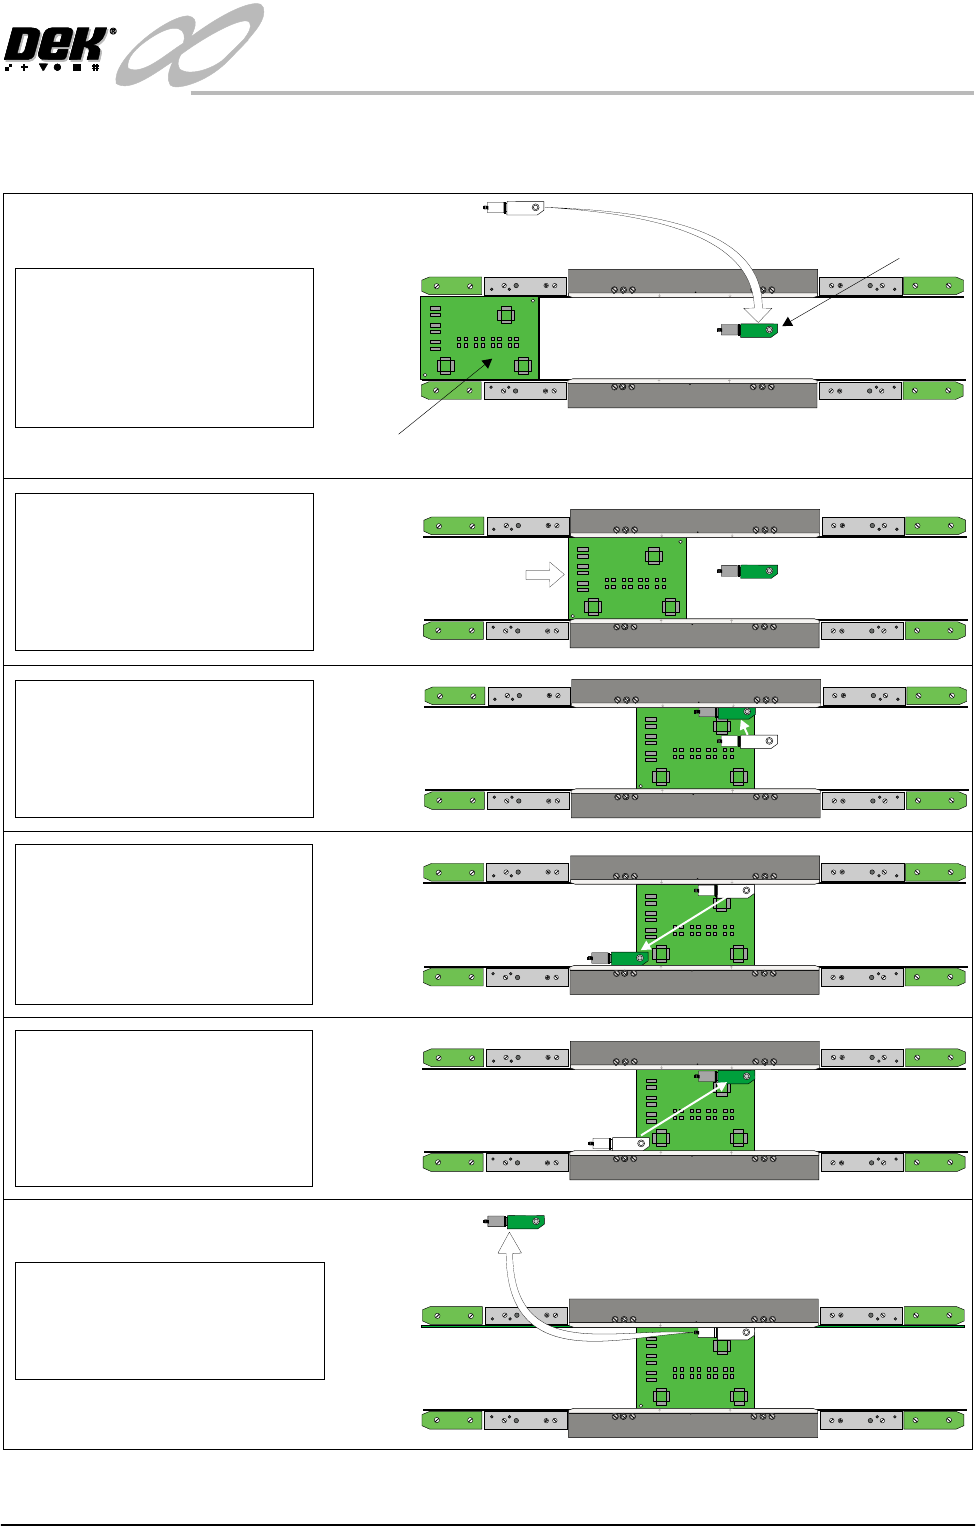
Camera Sequence - No Inspection, SPC Enabled
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
Plan View on Rails (Printhead Removed)
Board
Camera
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
PULNIX
TM-6EX
Step 1
Machine is initialized. Run is
pressed on MMI, the camera
is driven to the board stop
coordinates. The board stop
is lowered.
Step 3
The camera is driven to
Fiducial 1 coordinates.
Fiducial capture sequence
is completed.
Step 4
Camera is driven to Fiducial
2 coordinates. Fiducial
capture sequence is
completed. Screen
alignment is carried out.
Step 6
The camera is driven to the
home position. The print
sequence is carried out.
Step 5
The camera recaptures
Fiducial 2. The camera is
driven to Fiducial 1
coordinates and fiducial
recaptured.
Step 2
The board is transported
into the machine stopping
at the board stop and the
board clamps are activated.
The board stop is retracted.