Infinity EX Camera System Module.pdf - 第19页
INFINITY EX CAME RA SYSTE M MODULE POSITIONING Chapter Issue 3 J an 04 Technical Reference Manual 17.19 POSITIONING Camera Reference Po s it i o n A white dot is located c entrally on the front ra il and 10mm back from t…
INFINITY
EX
CAMERA SYSTEM MODULE
SEQUENCES
17.18 Technical Reference Manual Chapter Issue 3 Jan 04
PULNIX
TM-6EX
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
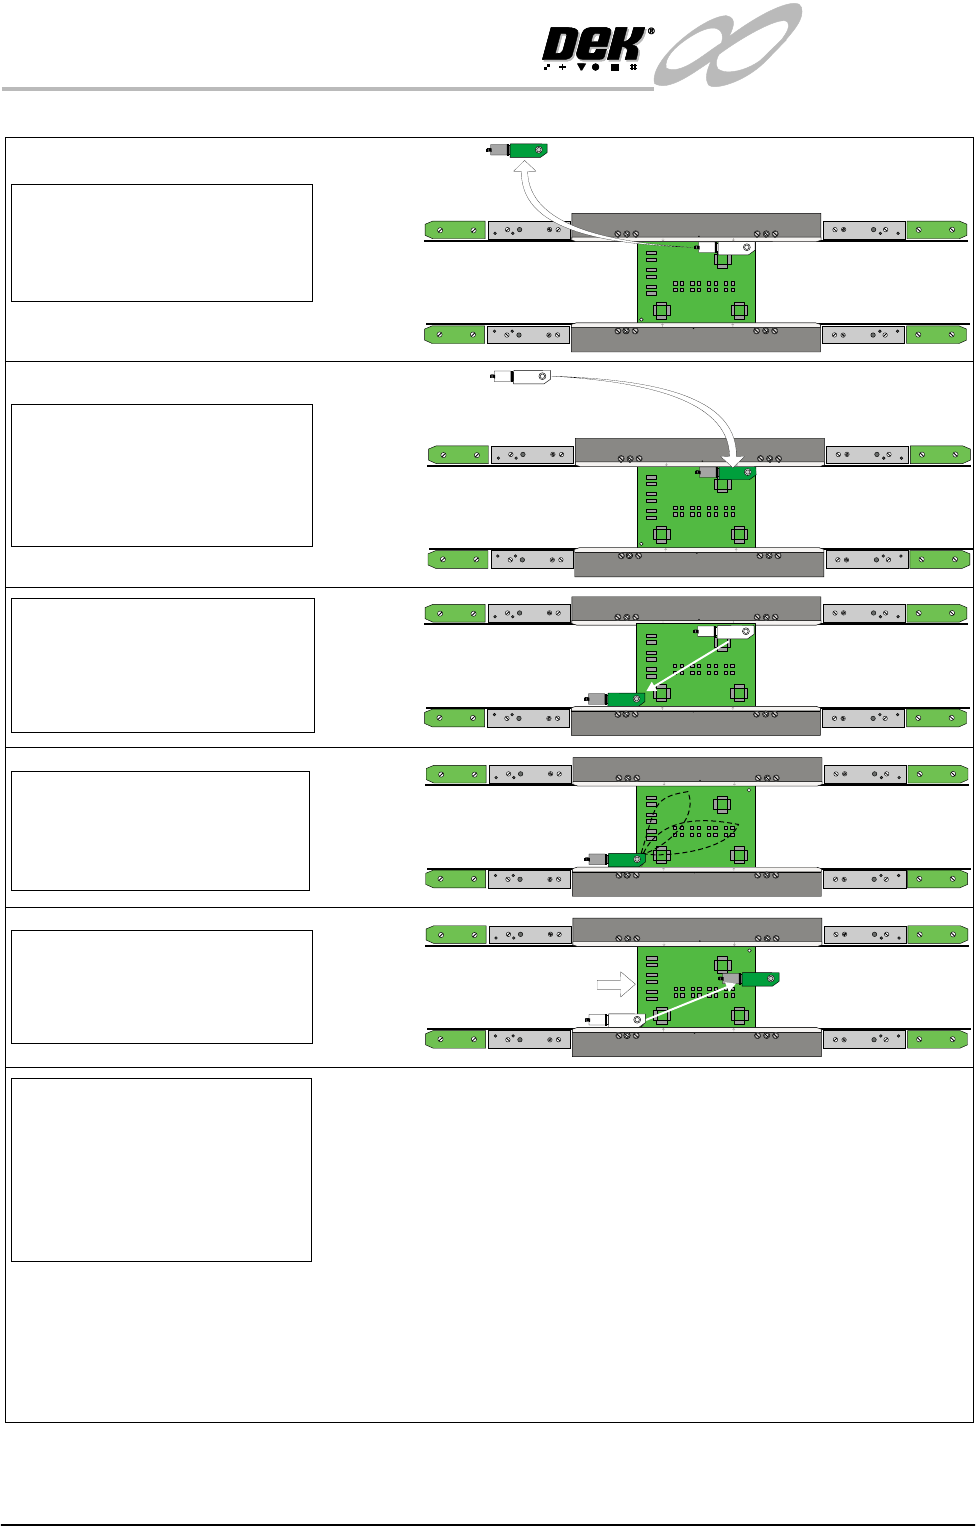
Step 8
The camera is driven to
Fiducial 1 coordinates.
Fiducial recapture sequence
completed.
Step 9
The camera is driven to
Fiducial 2 coordinates.
Fiducial recapture is
completed.
Step 10
The camera is driven to the
inspection sites. Inspection
site recapture is completed.
Step 11
Camera is driven to the
board stop coordinates. The
board exits the machine.
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
Step 12
Steps 2 -10 are repeated for
subsequent boards with
Pre-image set to Every.
Steps2-5and7-11are
repeated for subsequent
boards with Pre-image set to 1.
PULNIX
TM-6EX
PULNIX
TM-6EX
WARNING-SHARP EDGE
PATENT No.5157438
WARNING-SHARP EDGE
PATENT No.5157438
Step 7
The camera is driven to the
home position. The print
sequence is carried out.
NOTE
Machines with Pre-Print SPC enabled only, Steps 8-9 are omitted.
Machines with Post-Print SPC enabled only, Step 5 is omitted.
With selective print/pass through enabled, after Step 2 the camera is driven to the select mark coordinates. If the
select mark is recognized the sequence continues with Step 3. If the select mark is not recognized, the board is not
printed and exits the machine.
INFINITY
EX
CAMERA SYSTEM MODULE
POSITIONING
Chapter Issue 3 Jan 04 Technical Reference Manual 17.19
POSITIONING
Camera Reference
Position
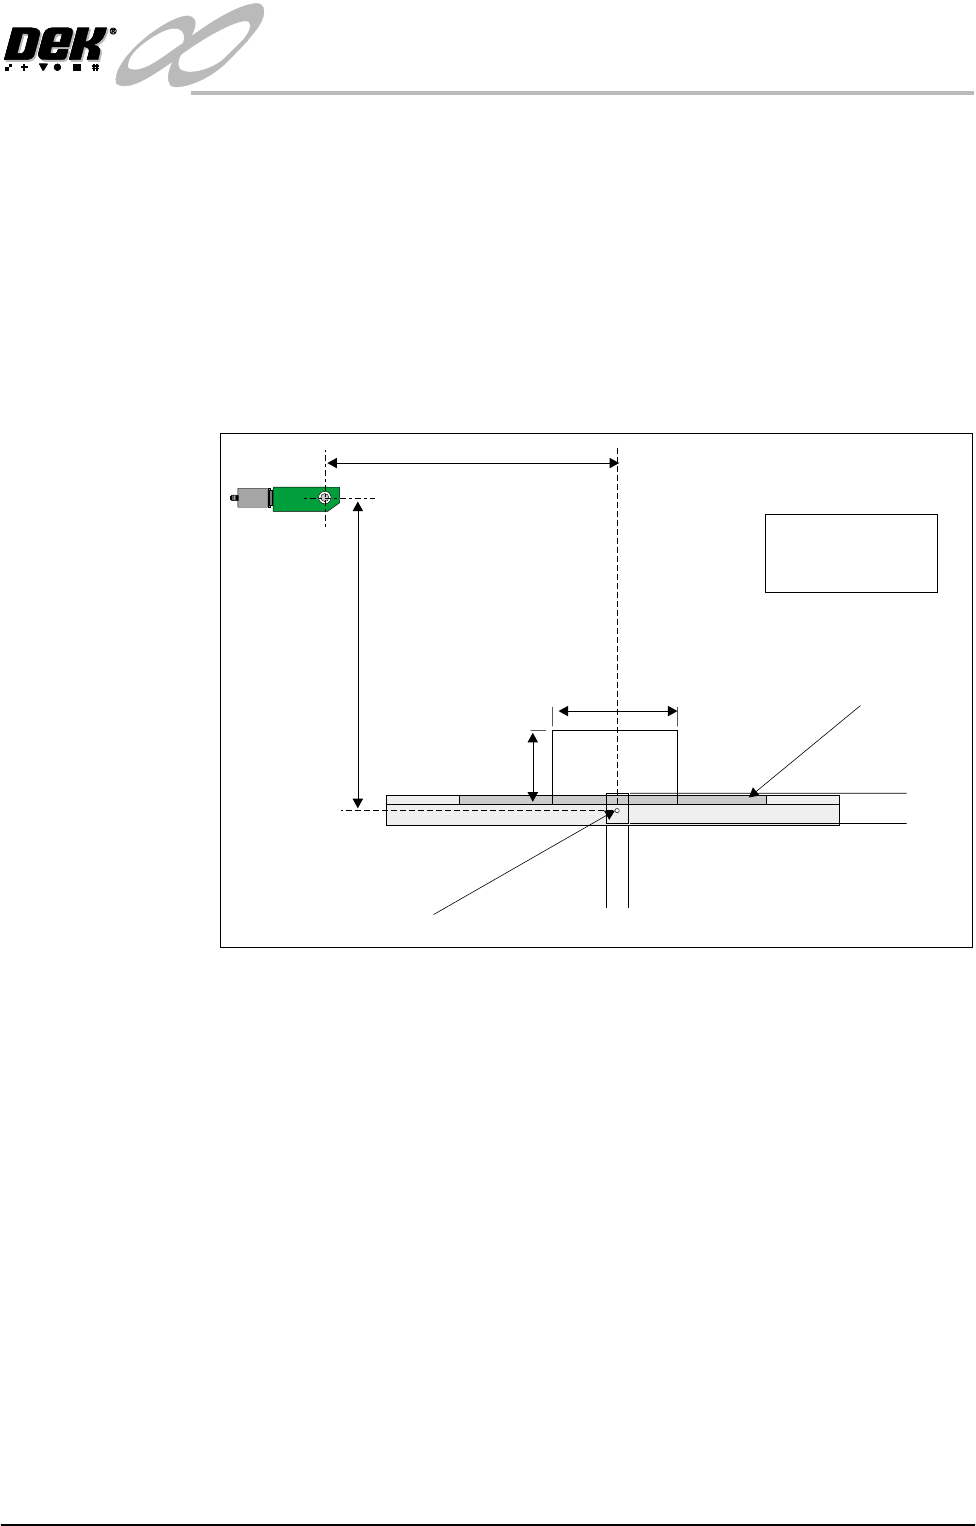
A white dot is located centrally on the front rail and 10mm back from the board
edge, this is the camera reference position.
The camera is driven to the reference position which is stored in the config.cfg
file as a dimension relative to the home position.
It must lie within the X and Y limits as shown on the Camera Reference Position
Figure below, otherwise the position is not saved.
All camera positions, board stop, fiducials, screen cleaner pick-up are calculated
relative to this point.
Figure 17-8 Camera Reference Position
X Reference
Optic Centre at Home
Y Reference
200mm
100mm
560mm
590mm
320mm 340mm
X Limits
Board Clamp
Front Rail
Reference Position
Y Limits
PULNIX
TM-6EX
Eg.
X = 335mm
Y = 572mm
INFINITY
EX
CAMERA SYSTEM MODULE
ADJUSTMENTS AND SETTINGS
17.20 Technical Reference Manual Chapter Issue 3 Jan 04
ADJUSTMENTS AND SETTINGS
X Camera Home Positioning
WARNING
BOARD CLAMPS. EXTREME CARE MUST BE EXERCISED WHEN
WORKING IN THE TOOLING AREA OF THE MACHINE TO AVOID
INJURY. THE FOILS ON THE FRONT AND REAR BOARD CLAMPS
ARE VERY SHARP.
1. In Camera Diagnostics select the following parameters in sequence:
a. Home Camera X Axis
b. Home Camera Y Axis
c. Drive to Reference Position
d. Home Camera X Axis (only)
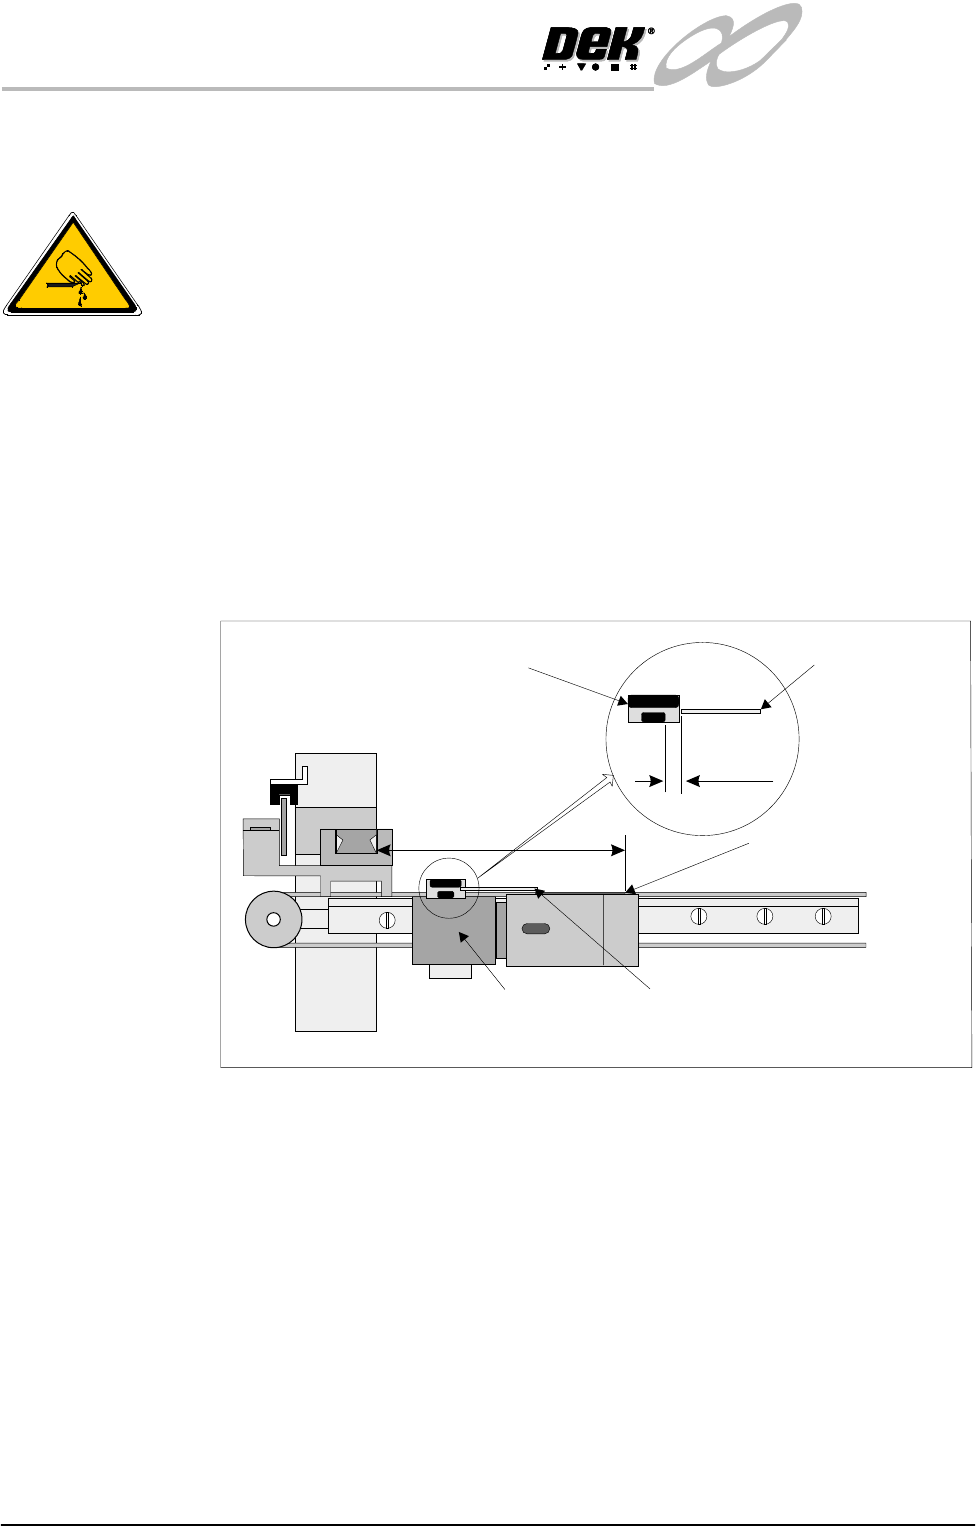
2. Measure the home position (H). This is the distance in millimetres from the
board stop assembly to the inside edge of the Y axis rail.
3. Adjust the camera drive belt for a home position of between 134mm -
139mm. If required, apply a correction to the setting as described in the
remaining procedures.
4. The table shows measured values of H between 128mm and 158mm. Move
the drive belt either to the left or the right by the number of teeth indicated
(as viewed from the front of the machine).
For example: If a home position setting of 144mm -146mm is measured, the
belt therefore has to be moved to the right by 3 teeth.
View From Front of Machine
Vane
Camera
Board Stop Assembly
H
1mm-2mm
X Axis Home Sensor
Carriage Vane