Printer 600 Machine Controller.pdf - 第12页
0$&+,1( &21752//( 5 1(;7029( &$5' 6.12 Technical Reference Manual Chapter Issue 4 May 03 Servo Loop (Analog Output s) The servo motor demands are ± 10V output s buf fered by operational ampl ifiers whi…
0$&+,1(&21752//(5
1(;7029(&$5'
Chapter Issue 4 May 03 Technical Reference Manual 6.11
Digital Outputs The twelve digital outputs are opto-isolated open collector type arranged as a
bank of eight and a bank of four. The bank of eight are NPN Darlington pairs,
the bank of four are FET’s which supply the servo enable control of the servo
drive cards and the stepper MUX control signals.
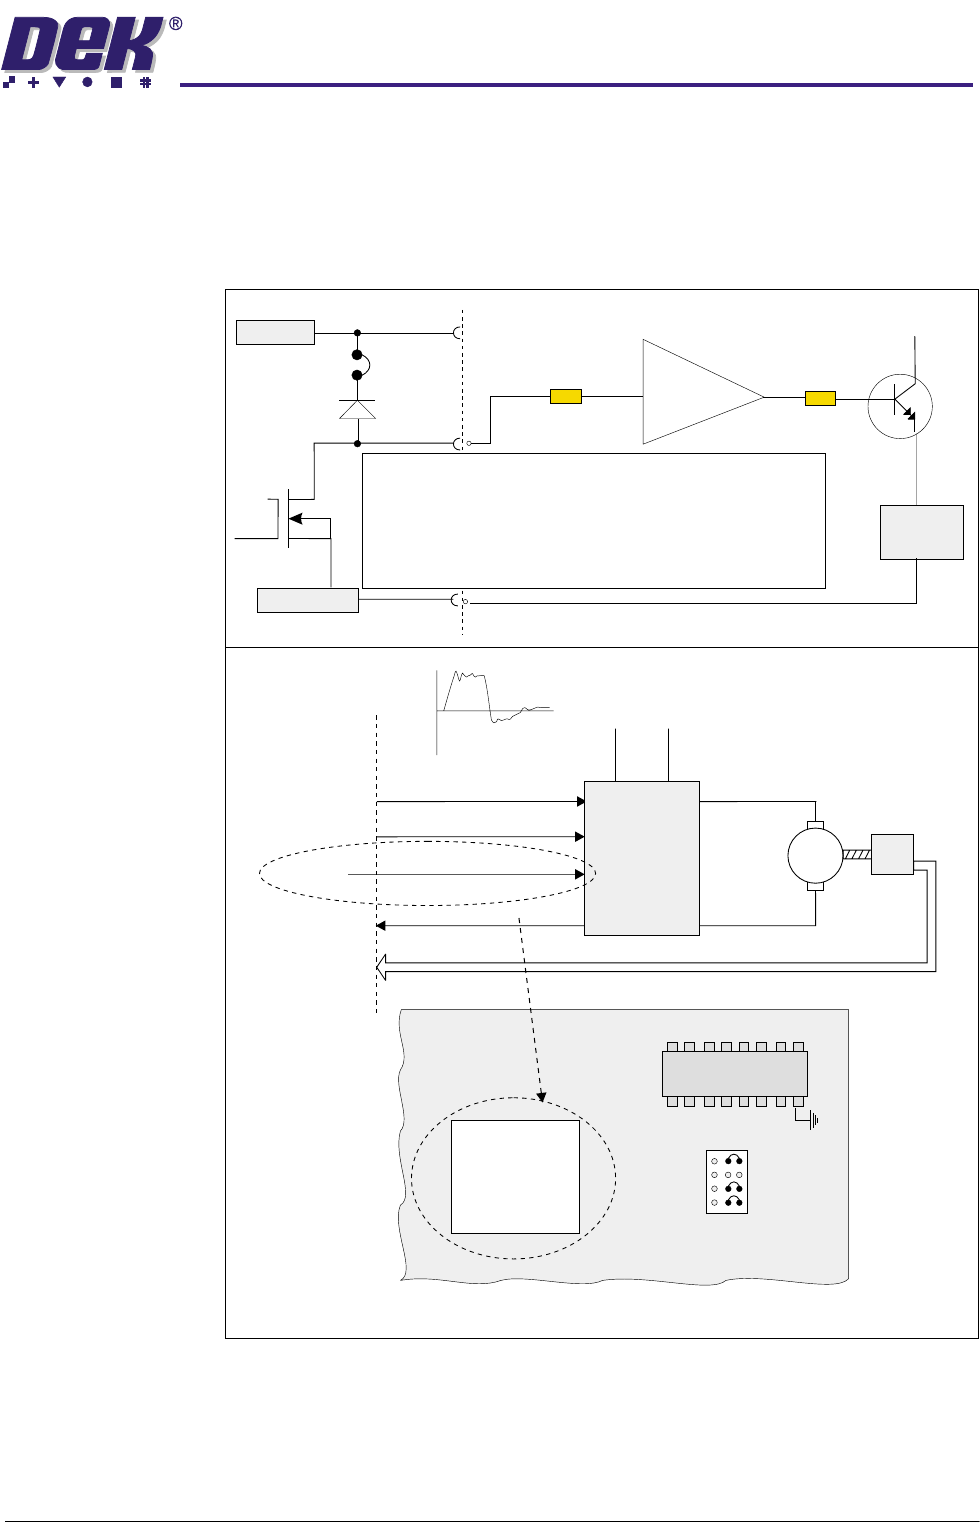
An example of a servo enable control digital output is shown below:
Figure 6-7 Digital Output Sample
Enable In
LED
Link
Z
Enable Out
LED
NextMove Card
FET
*
**
**
User Gnd
For the bank of 8, an NPN Darlington Pair is used instead
of an FET.
For the bank of 8, Link Z is replaced with Link X, which is
not fitted enabling the voltage at the collector to be
different than 12V.
*
ENABLE
IC
Load
Servo Drive
Encoder
NextMove
Dig O/P
(FET)
Dig I/P
Servo 0
Input
Servo 0 Demand +VE
44V
AC2
44V
AC1
+VE
-VE
Servo 0 Enable
Servo 0 Error
Servo 0 Demand -VE
M
Demand
+10V
-10V
ZYXW
1
U37
Com
Part of NextMove Card
ULN 2803
FET
Daughterboard
U38
User V+
12V
0$&+,1(&21752//(5
1(;7029(&$5'
6.12 Technical Reference Manual Chapter Issue 4 May 03
Servo Loop
(Analog Outputs)
The servo motor demands are ±10V outputs buffered by operational amplifiers
which are not opto-isolated. The voltage outputs are arranged in four groups.
These are routed to their respective servo drive cards to drive individual motors.
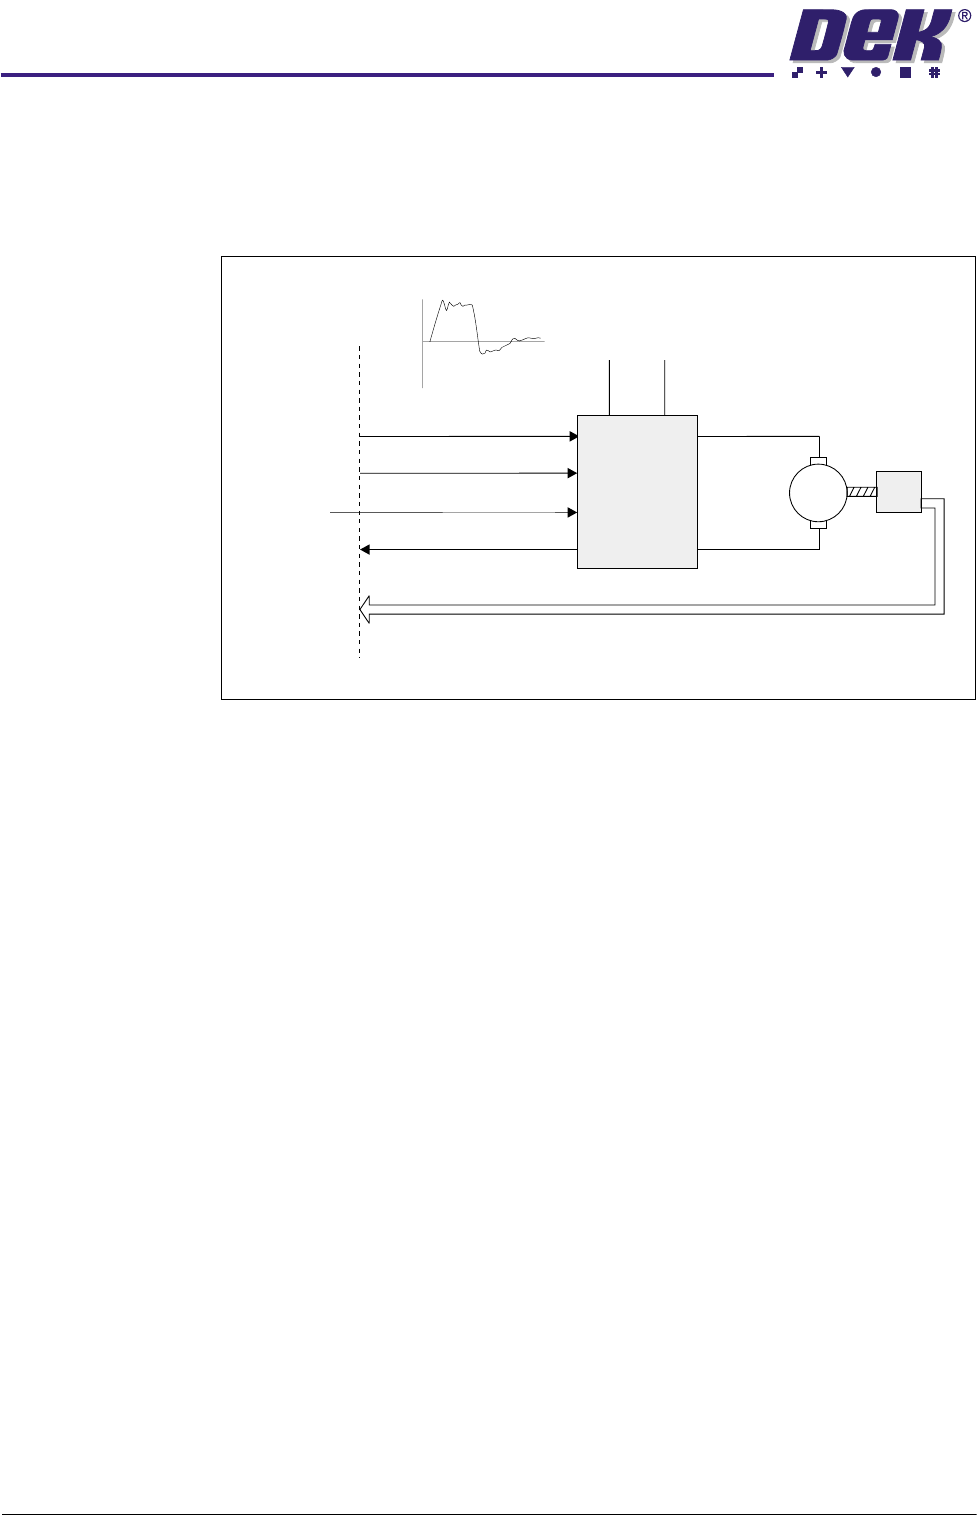
An example of the servo loop connection is shown below:
Figure 6-8 Typical Servo Loop Connection
Servo Drive
Encoder
NextMove
Dig O/P
(FET)
Dig I/P
Servo 0
Input
Servo 0 Demand +VE
44V
AC2
44V
AC1
+VE
-VE
Servo 0 Enable
Servo 0 Error
Servo 0 Demand -VE
M
Demand
+10V
-10V
Servo Loop Block Diagram
0$&+,1(&21752//(5
1(;7029(&$5'
Chapter Issue 4 May 03 Technical Reference Manual 6.13
Stepper Motor
Outputs
The stepper motor demand outputs are digital output drivers which are opto-
isolated. The outputs are arranged in four groups for the three positional axis
drives and the fourth output is used in the multiplexer drive circuit.
Their functions are as follows:
• STEP Step pulses to the stepper drive cards
• DIR Direction of rotation to stepper drive cards.
• BOOST Not used
The outputs are routed to their respective stepper drive cards or via the
multiplexer card to drive the individual motors.
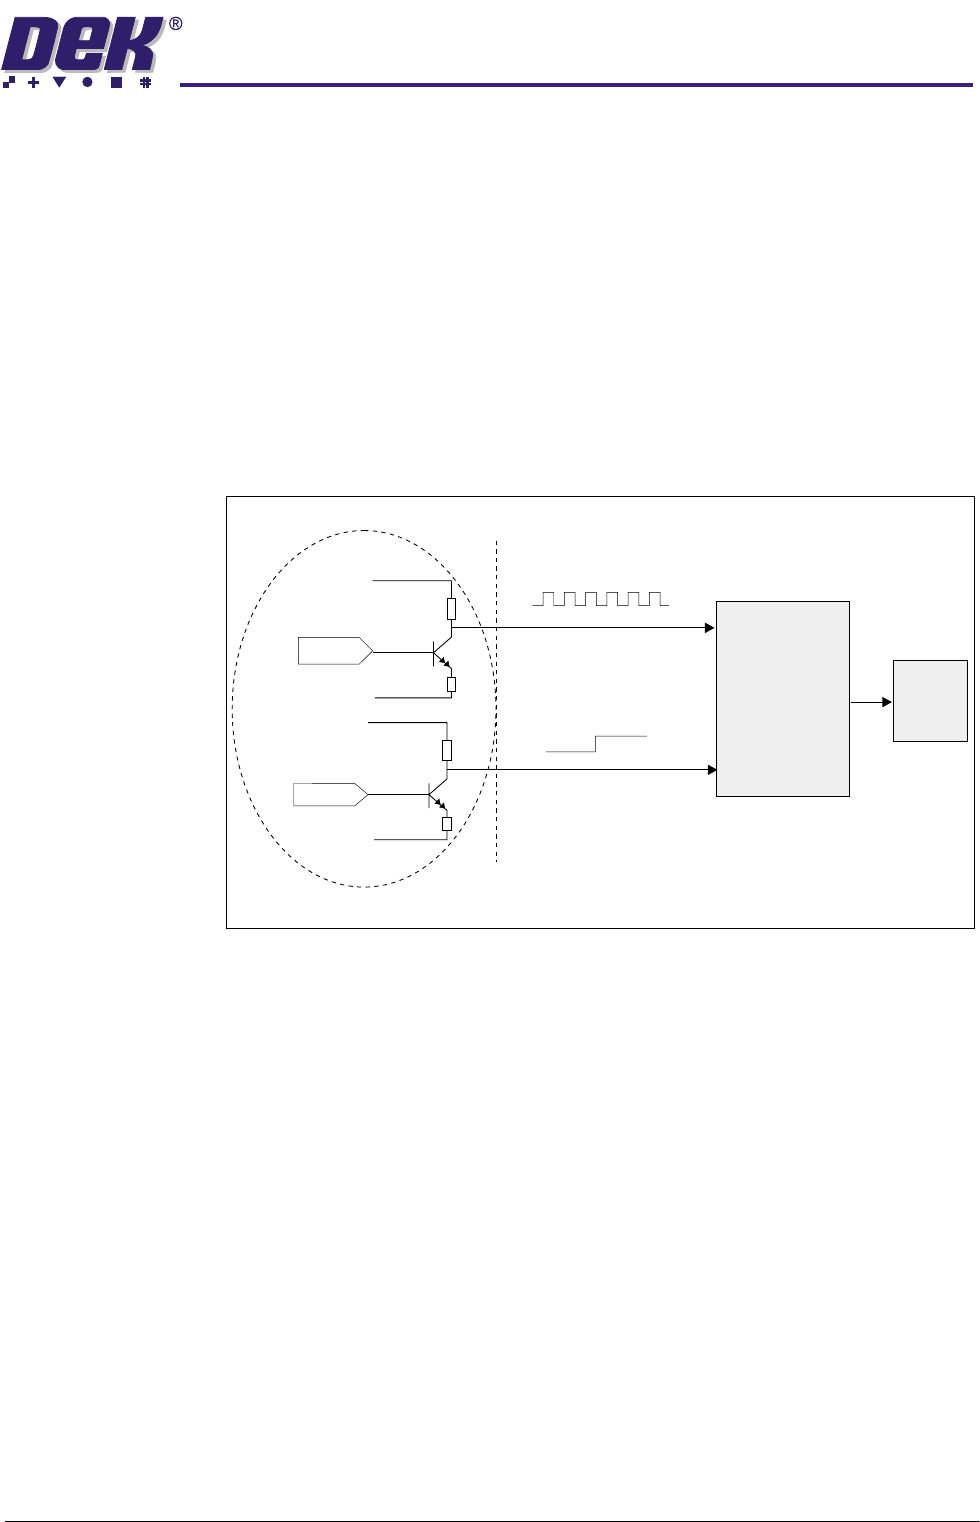
An example of the digital output for the stepper motor system is shown below:
Figure 6-9 Stepper Drive Signals
Single/Dual
Stepper Drive
STEP AXIS
DIR
STEP
NextMove Card
V+
12V
12V
Gnd
V+
Gnd
Stepper
Motor
STEP
DIR