Printer 600 Machine Controller.pdf - 第29页
0$&+ ,1(&21752 //(5 6(592'5 ,9(&$5' Chapter Issue 4 May 03 Technical Reference Manual 6.29 Signals and Pins The following shows servo dr ive card edg e connector pins f or all cards used on the m…
0$&+,1(&21752//(5
6(592'5,9(&$5'
6.28 Technical Reference Manual Chapter Issue 4 May 03
Servo Drive Card
Block Diagram
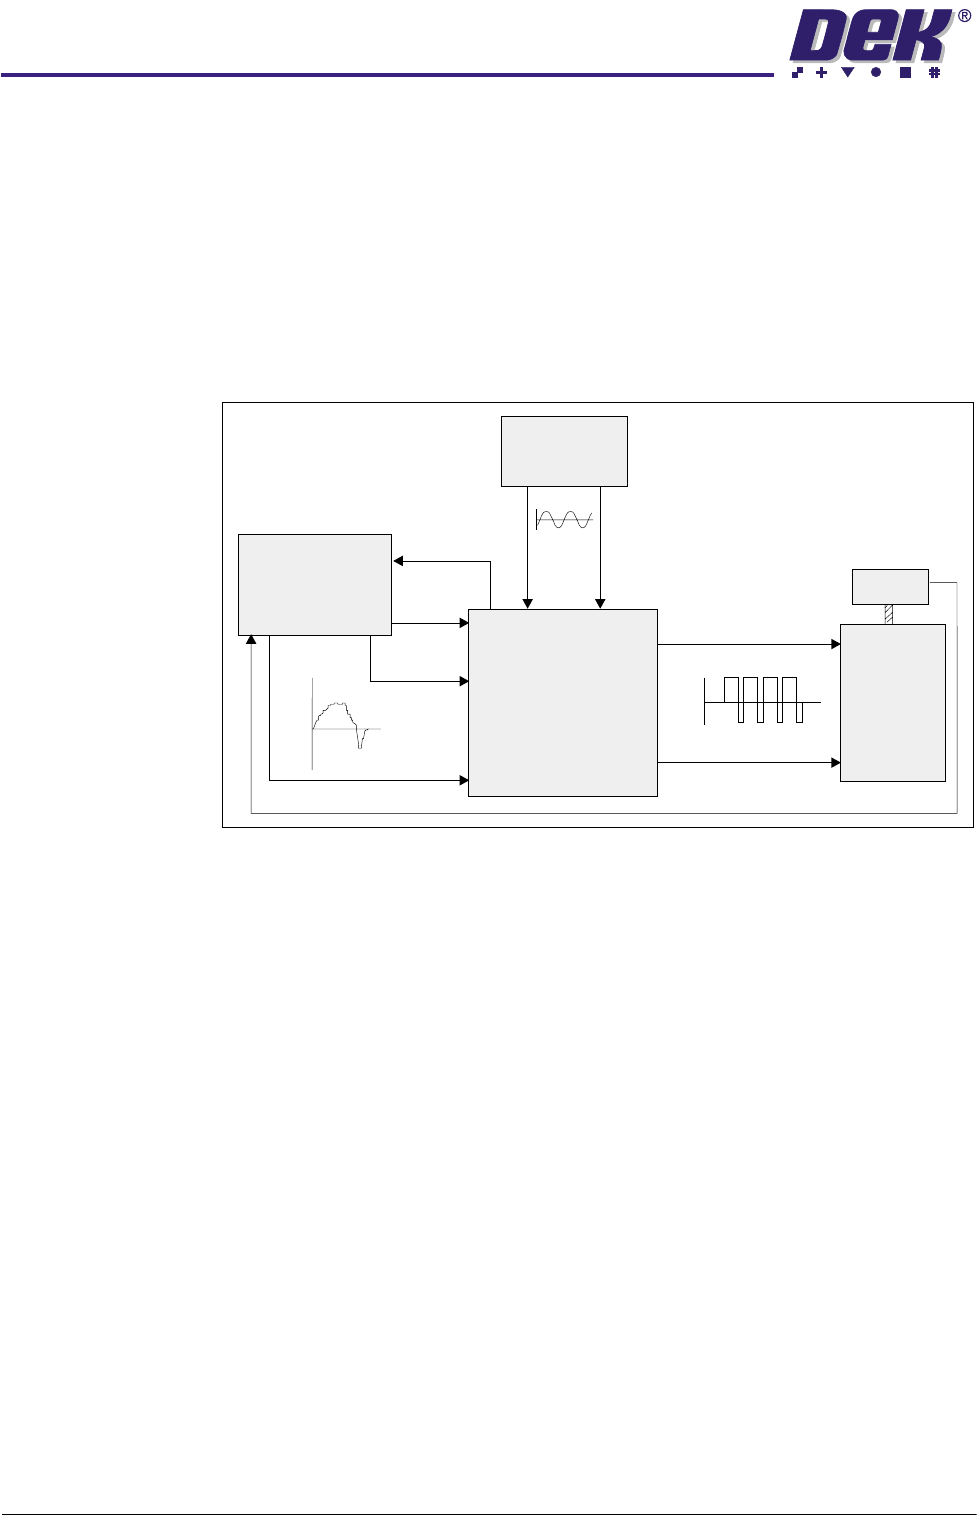
44Vac is applied to the servo amplifier from the mains isolating transformer.
This input is rectified on each card and is used to power the motor output stage.
The servo motors are voltage surge protected by a thermal trip device con-
nected to the system reset circuit in the power supply. The machine software
generates a profile of the correct servo demand voltage to achieve the speed
that the motor is required to rotate. Servo demand signals are applied directly
to the servo drive card from the NextMove card, the derived output is a 25kHz
PWM drive signal. An encoder that is directly attached to the motor feeds back
a series of pulses to the NextMove card to complete the servo loop. If the pulses
returned are in error, an error signal is generated
Figure 6-21 Servo Drive Schematic
NOTE
Each servo drive card has an enable input on pin 2z which must be pulled low
for the card to operate. If this input is disconnected or if there is a voltage on
the line, then the card is disabled
CAUTION
ANTI-STATIC HANDLING.
Standard precautions must be adhered to when
handling electronic cards and configuring and inserting into the enclo-
sures.
NextMove
Card
Mains
Transformer
+VE
Motor +VE
Encoder Out
Motor
Motor -VE
-VE
Demand
Output
to Motor
Error
44V ac
Enable
Servo Drive Card
+62V
25kHz PWM
-62V
+10V
-10V
Encoder
0$&+,1(&21752//(5
6(592'5,9(&$5'
Chapter Issue 4 May 03 Technical Reference Manual 6.29
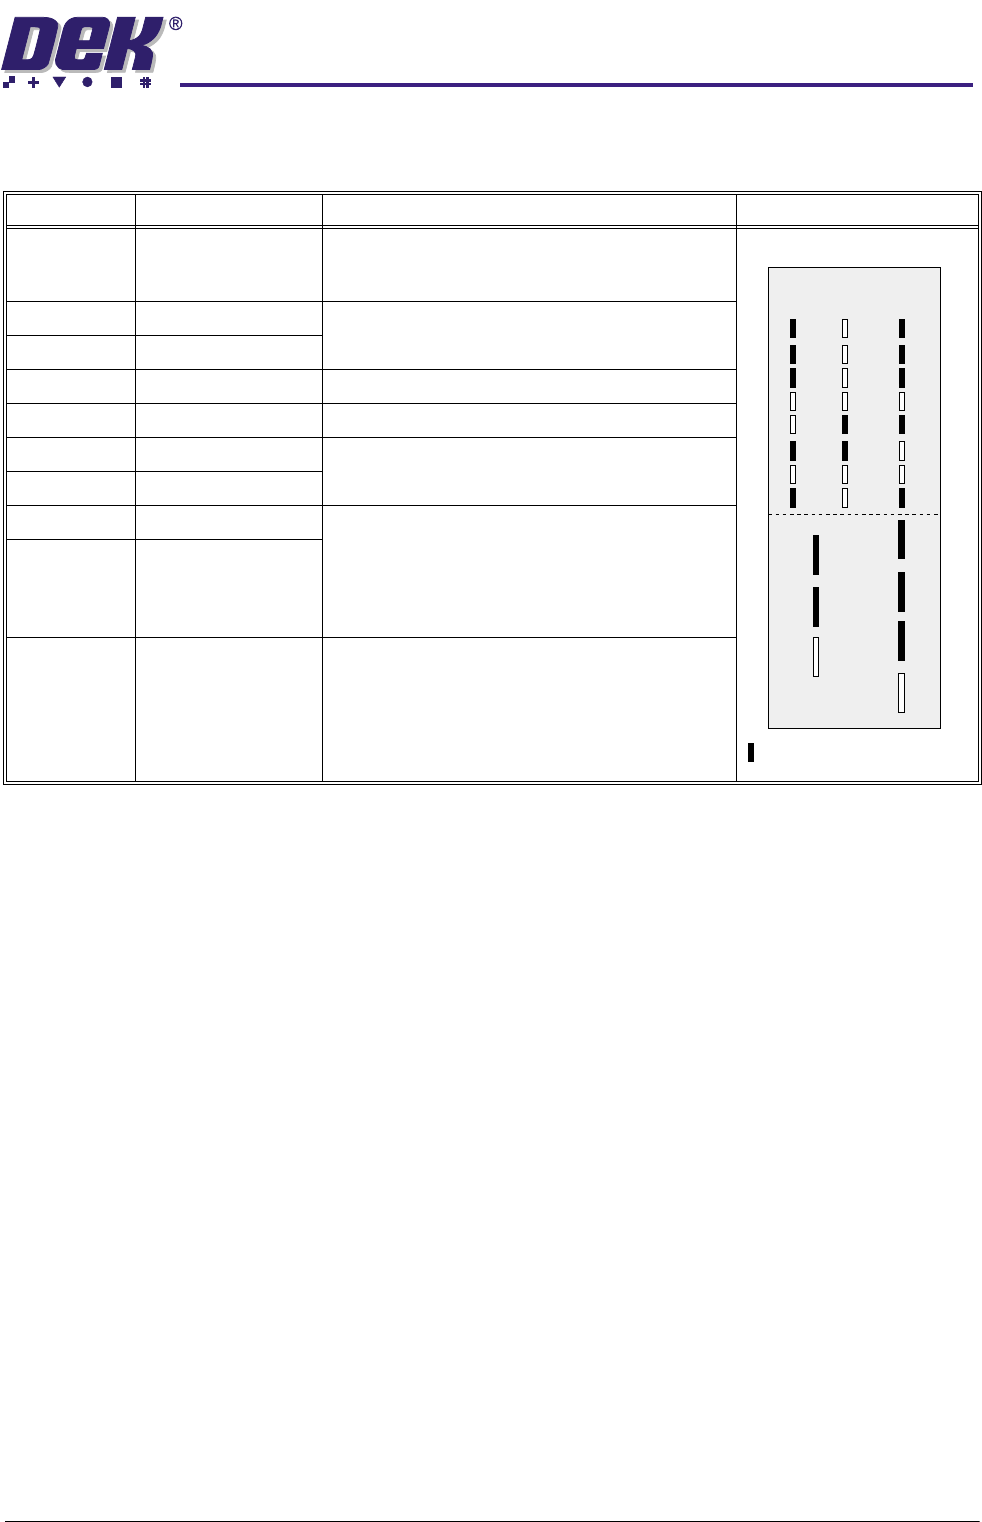
Signals and Pins The following shows servo drive card edge connector pins for all cards used
on the machine:
NOTE
Axis 1 also has an input at pin 14d from the MultiMove card and an output at
pins 14b and 14z (0V) to provide the rising table brake function.
Pin Signal Description Edge Connector
2d Demand +V ±10V with respect to 4d from the NextMove Card.
Torque proportional to demand voltage (max
demand = 10V, Zero demand = 0V)
4d Demand - V Tied to GND
6d GND
2z Master Enable Input, must be grounded to enable card
12b Error Output Normally high, goes low in error condition
20 AC1 44V ac input from transformer tapping
22 AC2
24 Motor +ve Output to motor, ±62V Pulse Width Modulated
(PWM)
NOTE
The connectors for the output are plug-in types, the
wiring diagram does not show this connection
26 Motor -ve
28 GND 0V
2
Indicates connections used
4
6
8
10
12
14
16
d
30
26
22
20
24
28
32
b
z
0$&+,1(&21752//(5
67(33(508/7,3/(;&$5'
6.30 Technical Reference Manual Chapter Issue 4 May 03
STEPPER MULTIPLEX CARD
Multiplexer
Description
The Stepper Multiplexer is used to control the stepper motors and their sensors
which do not need to be controlled in conjunction with each other ie, not for
alignment purposes. A decoder on the multiplexer board converts the three
input control (CTRL 0-2), the drive signal (MUX Axis Step) and the axis direction
control (MUX Axis Dir) into Step and Direction outputs that are used by the Dual
Stepper Drivers. The axes controlled are; the front and rear squeegees; the
moving rail and the paste dispenser. When the axes are driven to their respec-
tive home position switches, they indicate to the multiplexer board that the axis
has reached home, a single MUX Axis Home signal is fed back to the NextMove
controller. All signals can be monitored on LEDs MUX0 to MUX4, in this way the
single home signal can be deduced for the relevant axis used.
The multiplexer can be thought of as a fully programmable switch where the
controlling inputs CTRL 0-2 determine the logical output state of eight internal
switches in the multiplexer. Only five of these switched outputs are utilized in
this application. Two signals are provided by the NextMove card - Step and
Direction (Dir). By combining (multiplexing) these signals it is possible to
sequentially switch the relevant axis (as determined in machine software) to
enable it to be driven to position. The dual stepper cards condition the signals
to achieve optimum drive results.