User-Manual-of-NeoDen4-PNP-machine.pdf - 第33页
28 (4) Click the cen tral po int among four nozzles unde r the shot can set the cen tral poin t. (5) Ano ther way is pressing CTRL button then c lick the mouse to make each nozzle to identify their own centra l point in …
27
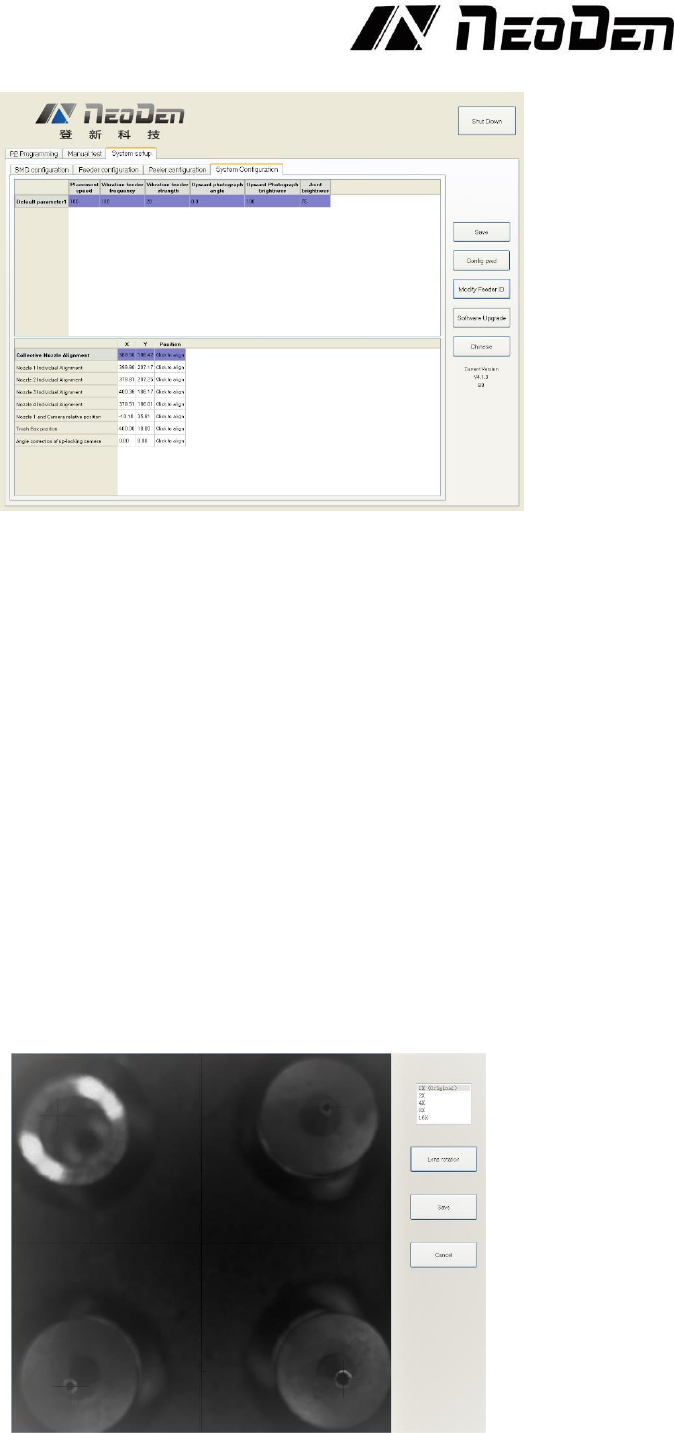
4.7.6 System configuration
Figure 4.27
When used in combination with the “Config pwd” button, this page allows the user to set the
machine’s default placement speed, the vibration feeder frequency and vibration feeder strength,
and brightness of the camera lighting systems. Default values normally require no change. The
interface also contains sophisticated nozzle alignment routines. Because these are set at the factory,
there is normally no need to access them and any use of these functions should be done in
cooperation with NeoDen tech support. See the Figure 4.27.
Function: it is mainly for correction the position of suction nozzle. (Notice: In case change by
mistake, we’ve locked it. It can be changed by clicking the button of “Config pwd” and then click
“ok” button. Strongly recommend operating it under our engineer’s guidance).
Default parameters 1 setting:
(1) Placement speed: placement head movement speed under overall situation, priority is not as fast
as speed set in stacks.
(2) Vibration feeder frequency: setting the frequency of vibration feeder. Discharge state will be
more stable if frequency high.
(3) Vibration feeder strength: it depends on the component, if component too small and strength set
high it will shake out the component easily, of course if strength small, the discharging speed will
be slower.
Collective nozzle Alignment setting:
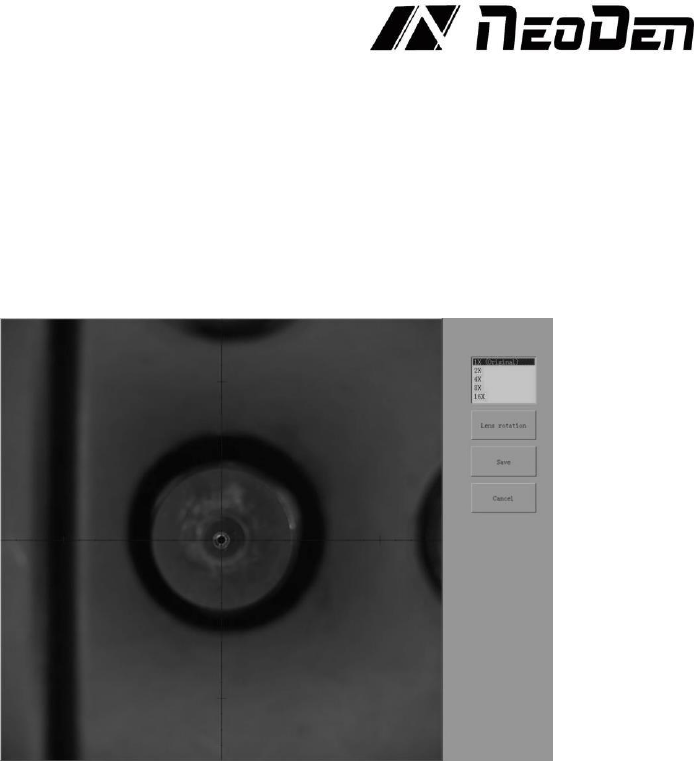
Click the “Click to align” and go into interface below, see the Figure 4.28.
Figure 4.28
28
(4) Click the central point among four nozzles under the shot can set the central point.
(5) Another way is pressing CTRL button then click the mouse to make each nozzle to identify their
own central point in the four quadrants.
(Notice: Please click the LENS ROTATION before setting the suction nozzle, then PnP machine
will collect nozzle’s 360-degree rotation photos to synthesize. After that, press CTRL button to set
each nozzle’s identification of central point.)
(6) Save it after finishing the setting.
Correct nozzle 1~nozzle 4 separately.
Click “click to align” and go into interface below, see the Figure 4.29.
Figure 4.29
(7) Operation steps:
a. Click the button of “LENS ROTATION” to let machine take photos of nozzle’s 360-degree
rotation.
b. Click the central point of nozzle
c. Click the save button.
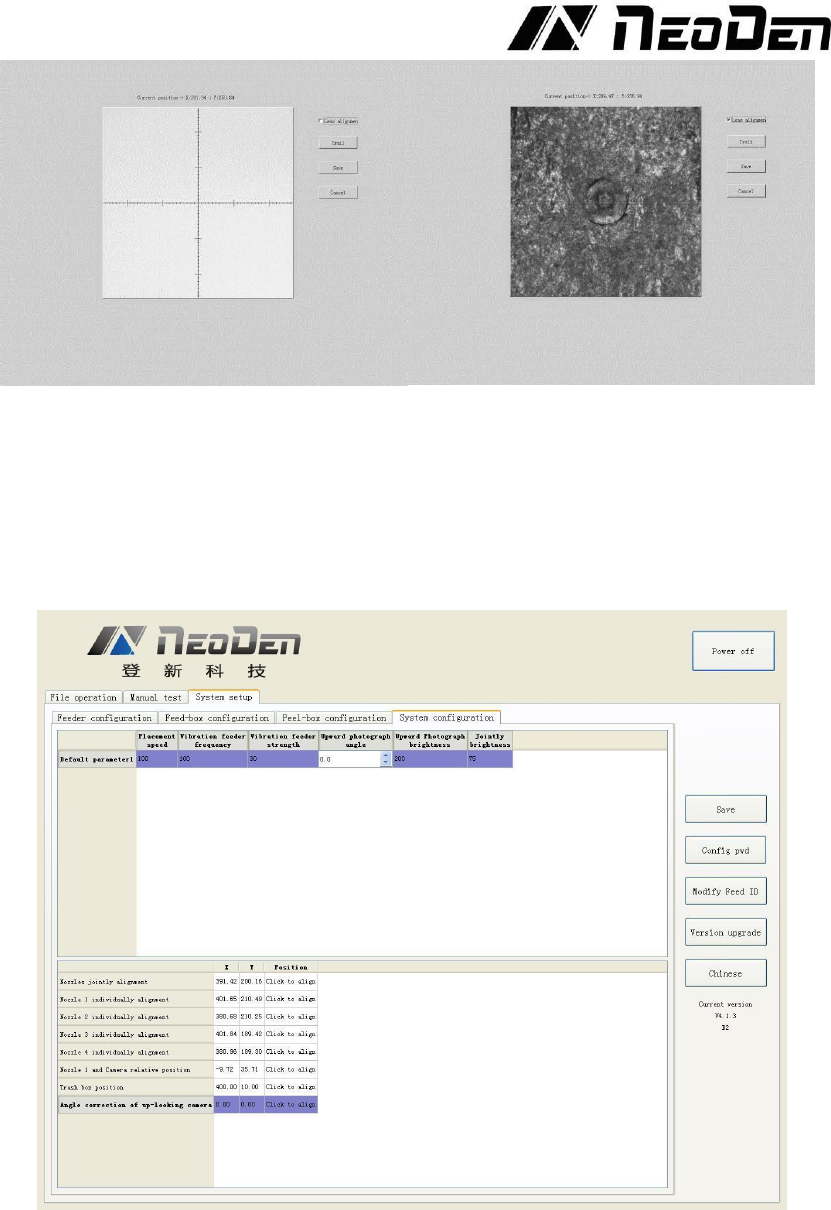
d.Nozzle1 and camera relative position: it is for the synchronism of nozzle and camera, setting it
when placement position does not match with the camera position.
Click “click to align” then go into interface below, see the Figure 4.30.
29
Figure 4.30
e. Move the nozzle to any place of PCB board, put one piece of carbon paper, then click “Trail”,
nozzle will rotate and leave a dot on the carbon, after that click the “Lens alignment”, Focus that dot
and save, it will be done (show as photo above).
(8) Trash box position: setting the position of dropping component, it depends.
(9) Angel Correction of upward-looking camera
Click “Click to align” and enter into upward-looking cameras angle correction interface.
The vision interface will lock at 3rd nozzle