TSR2000-Series-Teaching-Pendant-User-Guide-V1.pdf - 第10页
10 8.1 Calibrating t he Dispen se T ip When a dispense tip is changed, or the valve is removed from the robot , it is normal for the tip/valve to be slightly out of the original position when reat tached. By creating a p…
9
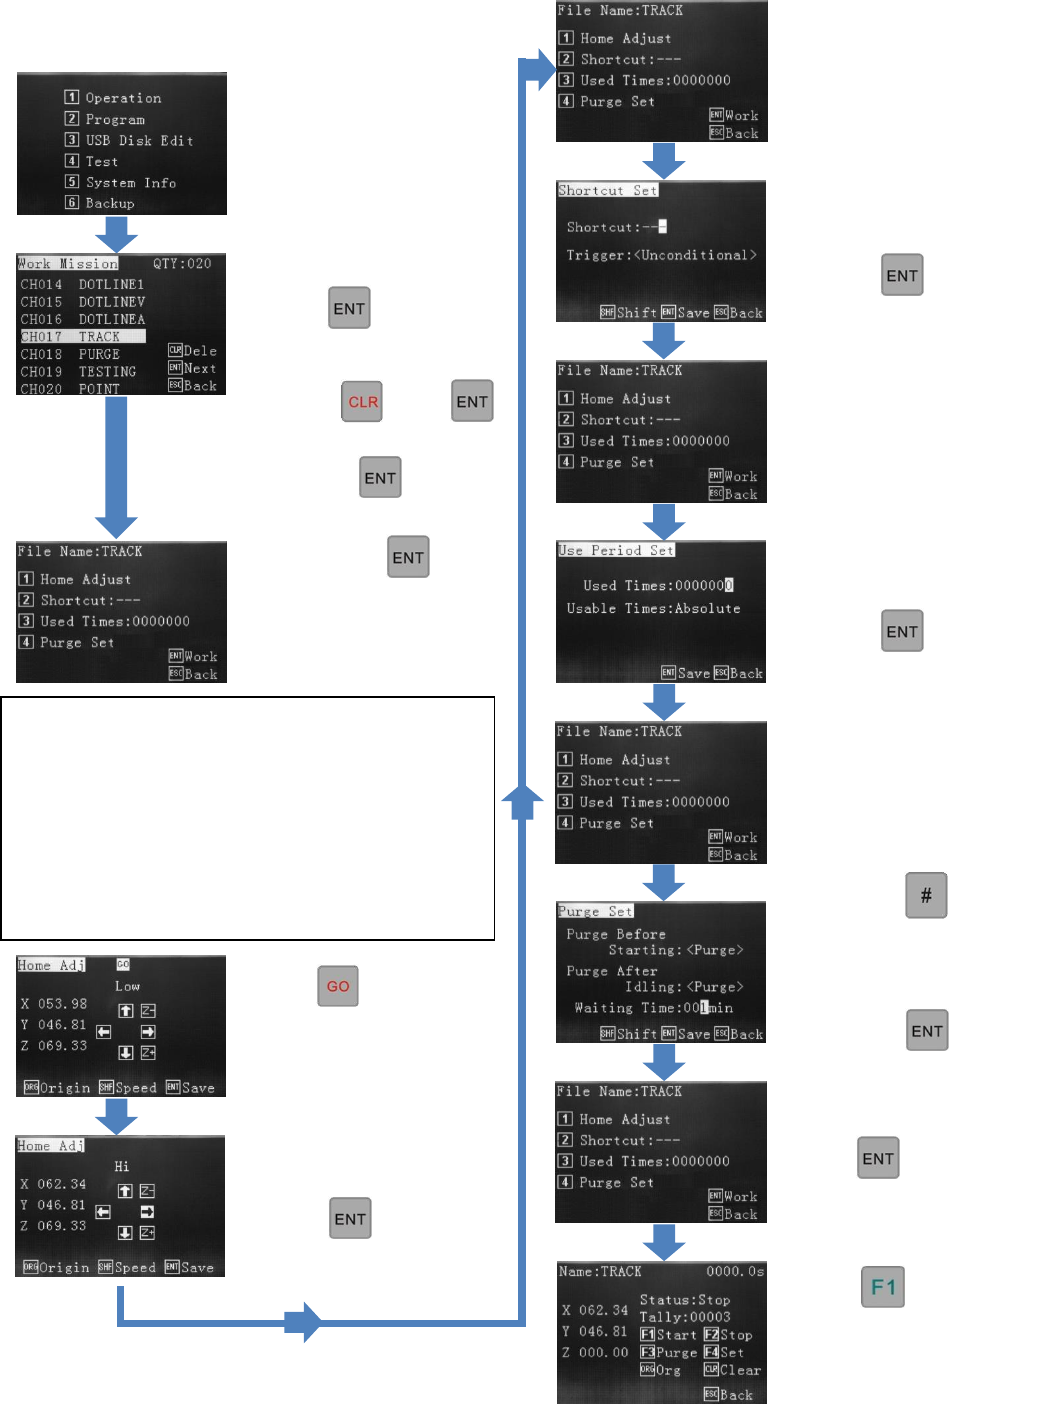
8. OPEARATION – RUNNING A SAVED PROGRAM
Press 1
Select program to be used and
press
or
Select program to be deleted
and press then
If selecting dispense cycle to
load, press twice.
This will go to the final step.
By pressing once:
1 – Calibrate tip position
2 – Create shortcut
3 – Reset counter
4 – Set Purge Position
(Optional) Press 2
Change current state and press
(Optional) Press 3
Change counter,
press
Using the button,
select if Purge is required at
start or end of program, or not
at all.
Press
Press and then use
alphanumeric keys to
move to the correct
location.
Note: Home Adjust is the process in which to
adjust/offset the co-ordinates completely in cases such
that: the dispensing tip has been changed or the
dispensing valve has been removed and refitted. Due
to very small differences from product to product or if
the valve has been removed and put on at a slightly
different position, the operator can calibrate the
program to the new position. The entire program will
offset to where the operator has set it to.
Press
(Optional) Press 4
Press
Press
This starts the dispensing
cycle.
10
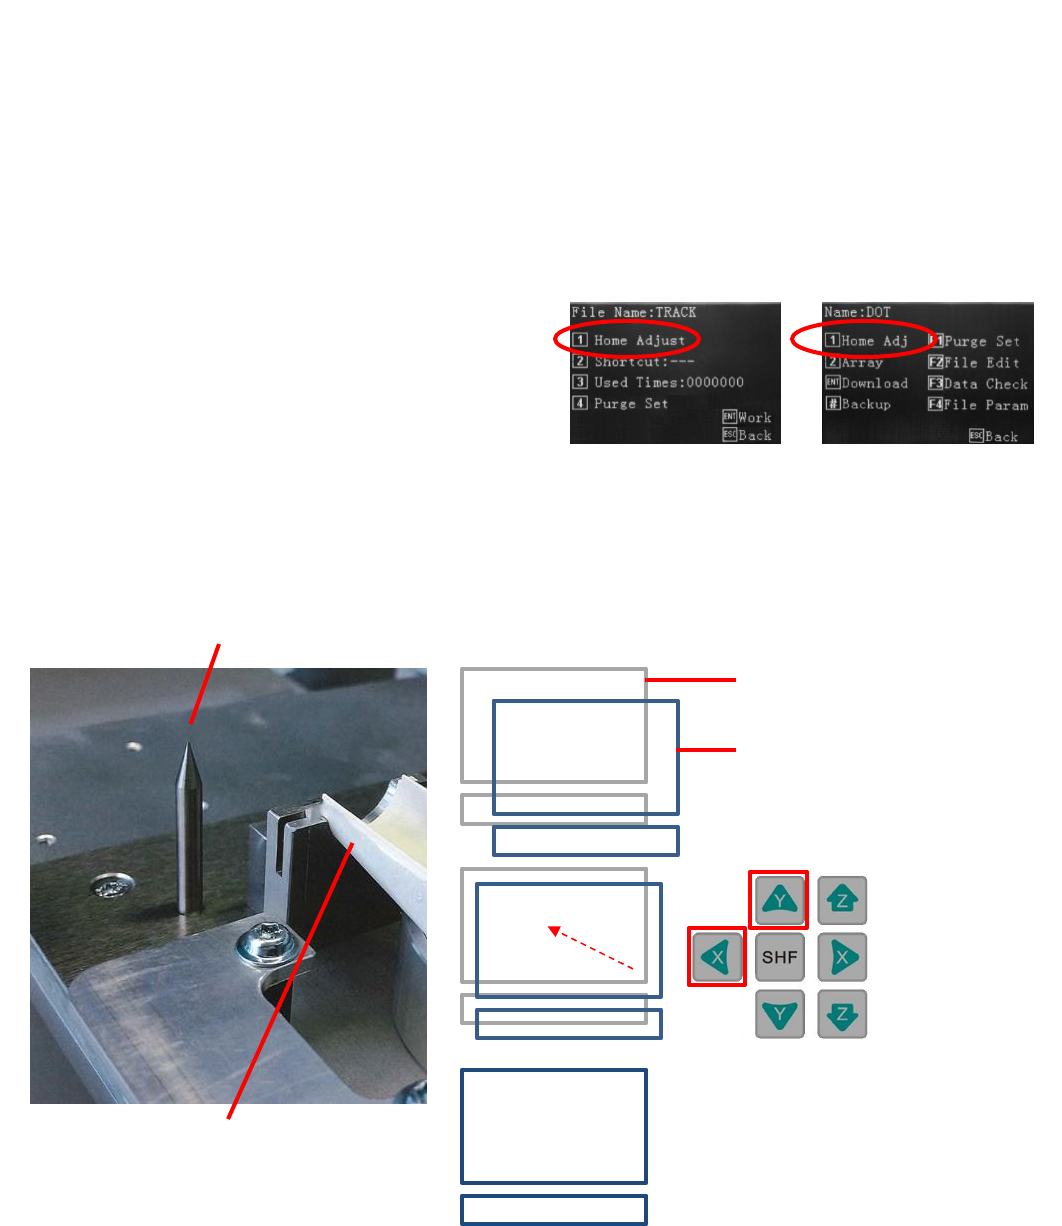
8.1 Calibrating the Dispense Tip
When a dispense tip is changed, or the valve is removed from the robot, it is normal for the tip/valve to be slightly out of
the original position when reattached. By creating a physical calibration point, on the device or fixture, the program can be
adjusted to suit the new tip position. This change will only effect the current program and not other programs stored in the
memeory. All programs can have their own unique calibration position.
There are 2 ways to achieve this calibration in the x, y and z axis:
Reference Point – by inserting a “REF PT”, into the Points List, during programming, calibration of the tip is performed
at a specified place by the user, such as a pointed stick or cross-hair markings on the holding fixture.
Home Adjust – if the “REF PT” is not inserted into the program the robot will use the first dispensing location as the
calibration co-ordinate.
By pressing Home, Home Adjust or Home Adj
Home Adjust can be found in the following screens:
If this function is performed in the Editing screen the program
will need to be Downloaded after the Home Adjust.
In Operation Menu
In Editing Screen
Typical calibration pin
Device to be dispensed onto
Original dispense location
New dispense location due to
dispense tip variance or valve
refitted to robot slightly out of
position.
Use jog keys to
align.
Dispense tip now calibrated.
11
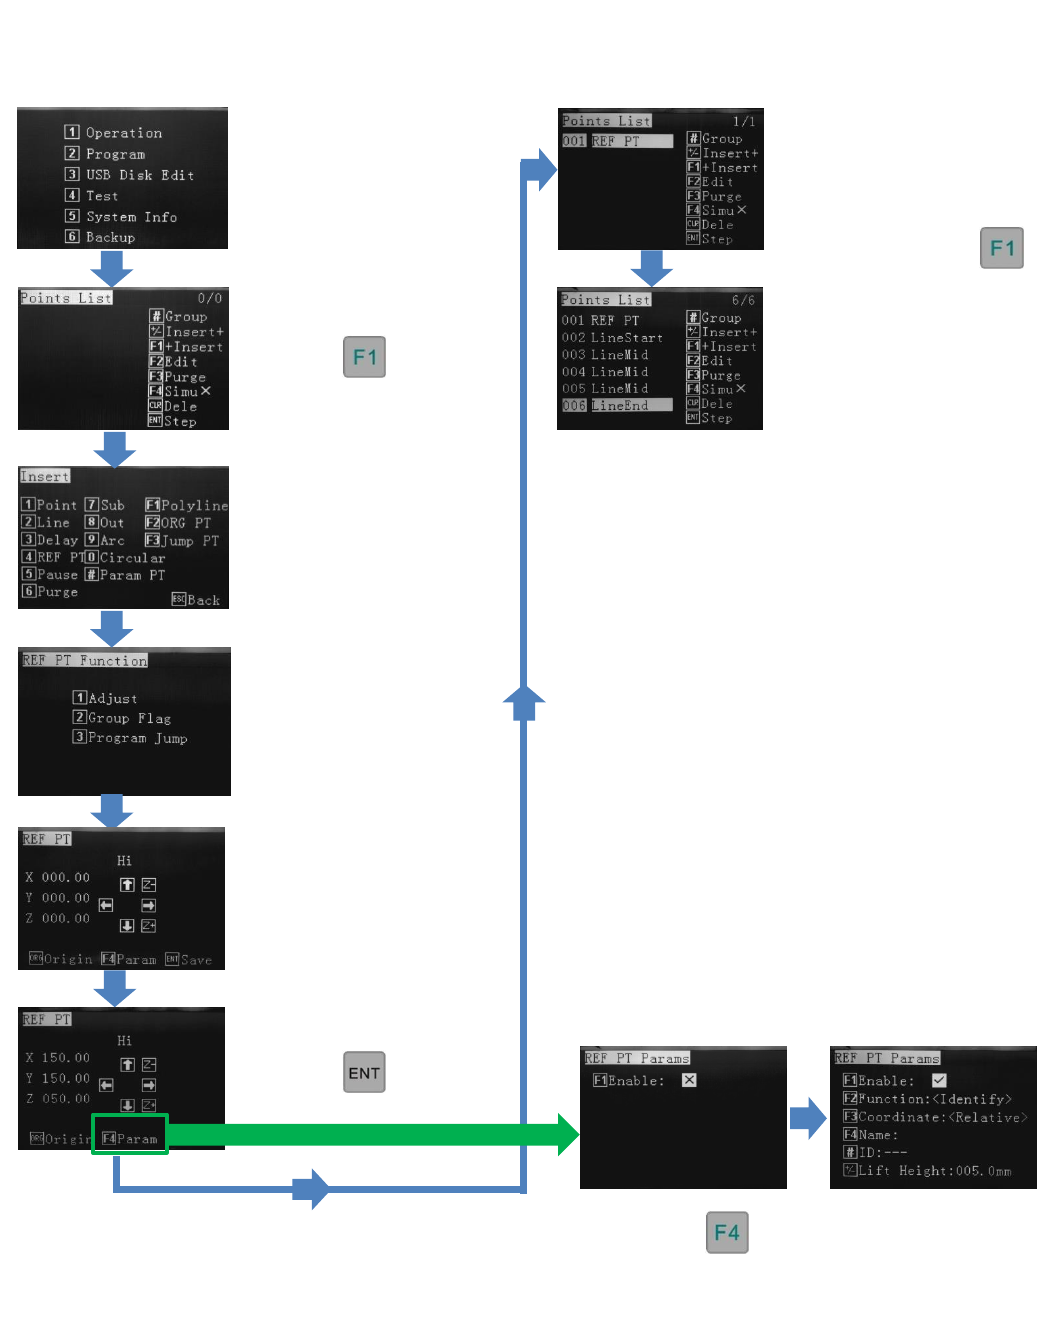
8.2 Creating the Calibration Location During Programming
Points List – This method inserts a calibration point (REF PT) into the body of the program, which can be modified at
anytime. It is also possible to modify the stored progam to include a calibration point (REF PT) later. It is recommended to
program in the calibration point (REF PT) at the start
Reference Section 9.2
Reference Section 9.2
From the Insert screen,
select option 4 – REF PT
Press 1
Options 2 and 3 are for
future use
Press
Press
Use jog or alphanumeric
keys to move to
calibration location.
The calibration location is
now set.Continue to write
program by inserting the
dispensing co-ordinates.
Start by pressing
This program consisisted of a
Polyline to created a gasket
(square).
If is pressed, these
functions are for future use and should not
be altered.