TSR2000-Series-Teaching-Pendant-User-Guide-V1.pdf - 第4页
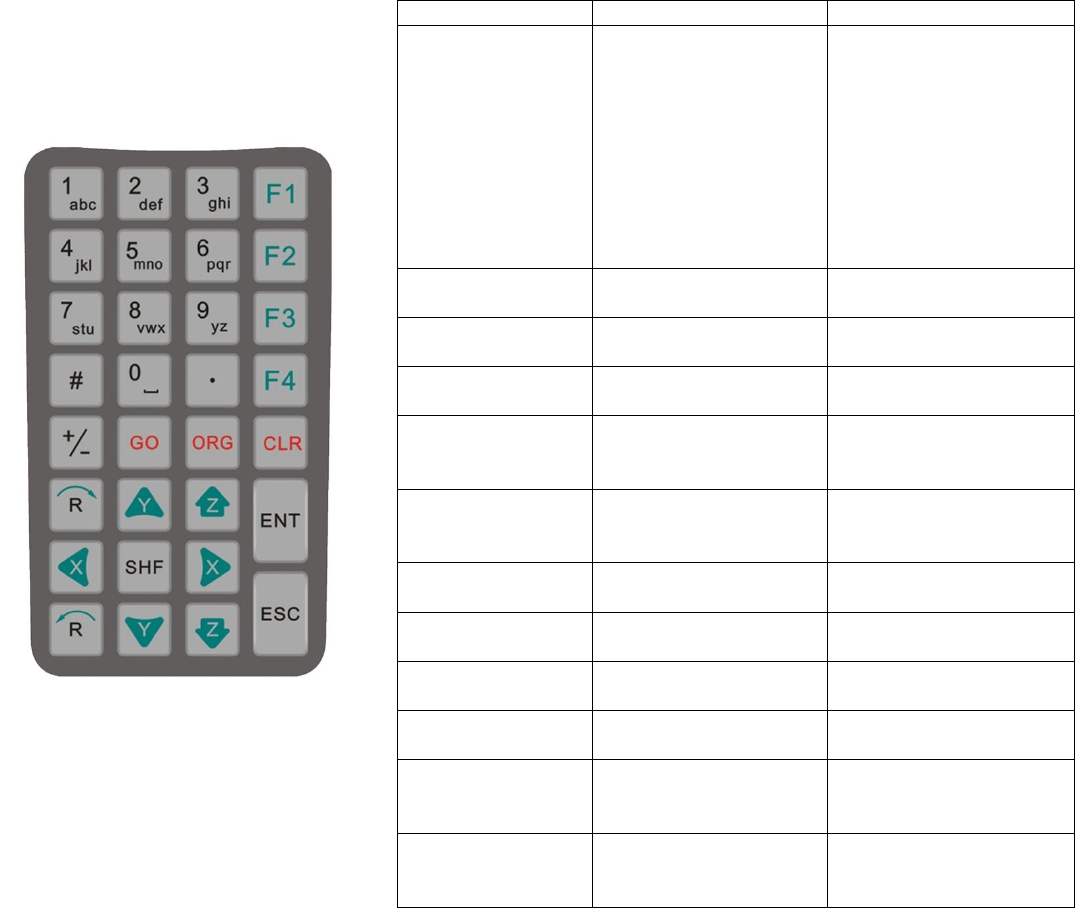
4 2. FUNCTIONS O F THE KEY P AD Button Name Description F1, F2, F3, F4 Function Buttons F1 – create new file, i nsert drawing, start/ pause a process. F2 – Edit f ile or stop a process or gro up of fset. F3 – Data ch eck…
3
10.3 Distance Parameters…………………………………………………………..………….….………
10.4 Park Location……………………………………………………….……….………………….…….
10.5 #Set as Default…………………………………………………….….………….…….……………..
10.6 Insert Screen……………………………………………………………………………..…………...
11. Set Menu……………………………………………………………………….….…………..………….
11.1 How to Set a Program to Run in a Loop………………………………………………..….………….
12. File Transfer…………………………………………………………………………………..…….……..
12.1 How to Transfer Program to USB Stick………………………………………………….……………
12.2 How to Transfer Program from USB Stick………………………………………………...………..
13. Troubleshooting…………………………………………………………….……..………..........……………
1. INTRODUCTION
Congratulations on the purchase of a Techcon Systems Automated Dispensing Robot. If you have not done so, see the
installation guide provided with your system for installation instructions.
Now that your dispensing system is ready to use, take a few moments to get to know the parts of your dispensing system and
software. This manual is designed to help you use the robot as quickly as possible.
We, here at Techcon Systems, hope you find this product beneficial. If you have any questions, please contact us at the details
listed below:
For Sales and Support:
Techcon Systems Corporate Headquarters,
10800 Valley View Street, Cypress, California, 90630, USA.
Tel: 1-714-230-2398, Fax: 1-714-828-2001
E-mail: oemorders@okinternational.com
Techcon Systems European Corporate Office,
Eagle Close, Chandler’s Ford Industrial Estate,
Eastleigh, Hampshire, SO53 4NF, UK.
Tel: +44 2380 489 100, Fax: +44 2380 489 109
E-mail: europe-orders@okinternational.com
Or visit www.techcon.com
This manual is designed to provide information about Techcon Systems robot software. Every effort has been made to make
this manual as complete and accurate as possible. There is no implied or expressed warranty as to the purpose, suitability or
fitness of the information. The information is provided on an as-is basis. Techcon Systems reserves the right to improve and
revise its products. This manual specifies and describes the product as it existed at the time of publication. As with any new
programming software, a basic understanding of the vocabulary is necessary.
46
46
47
47
48-49
49
50
50
50
51
4
2. FUNCTIONS OF THE KEYPAD
Button
Name
Description
F1, F2, F3, F4
Function
Buttons
F1 – create new file, insert
drawing, start/pause a
process.
F2 – Edit file or stop a
process or group offset.
F3 – Data check and file
copy.
F4 – Array, parameter
setting and change file
name.
X, Y, Z, R
Navigation
Buttons
Control jog movements of
X, Y, Z and R axis
0 – 9, A – Z
Alphanumeric
Buttons
To create file names and
set parameters.
.
Decimal Point
Button
To input decimal point.
SHF
Switch
Button
Change jog speed (low,
med, high), or change
parameters
+/-
Front Insert
Button
To insert a new point or
figure at the front of a
selected point.
#
Group
Button
Used in group edit and
parameter settings.
GO
Go
Button
When displayed, press to
move valve to position.
ORG
Reset
Button
Return to zero position (0,
0, 0, 0)
CLR
Delete
Button
Delete a file or part of a
file.
ESC
Escape
Button
Cancel an operation
and/or exit from current
interface.
ENT
Enter
Button
Download or process the
current file, or save an
edited file, etc.
5
3 . CLASSIFICATION OF A POINT
The programming has many types of point. Graphic points include point, line origin, etc. Non-graphic points include
delay point, clean point, etc and can refer to the following table. When inserting a “point” the operator must select to
insert the point at the front or back of the selected point.
No.
Point
Type
Instruction
1
Point
Graphic
The speed between points is the “jog move speed”. Can set
the lift height and delay time.
2
Line
Graphic
Includes Line start, Line middle and Line end points
3
Delay (Time)
Non-Graphic
Delay point is used to set delay time in the range of 0 –
65532ms.
4
Mark
Graphic
Mark point is a moving assistant point and is only used to
move to another position and is also valid during simulated
step.
5
Pause
Non-Graphic
When setting a pause point the robot will pause automatically
until a start signal is sent.
6
Clean
Non-Graphic
Set the clean point location and parameters.
7
Subroutine
Non-Graphic
Subroutine is a teaching file and can be inserted into another
teaching file but cannot be edited again.
8
Output
Non-Graphic
For setting an input/output by inserting an output point.
9
Origin
Graphic
Reference point. Also a basic point when group skewing.
In the teaching pendant, the teaching file exists as points. A line is a special graphic point and has at least two points:
Line-Start and Line-End. In this way it is made of segment lines. When processed it is a continual line.
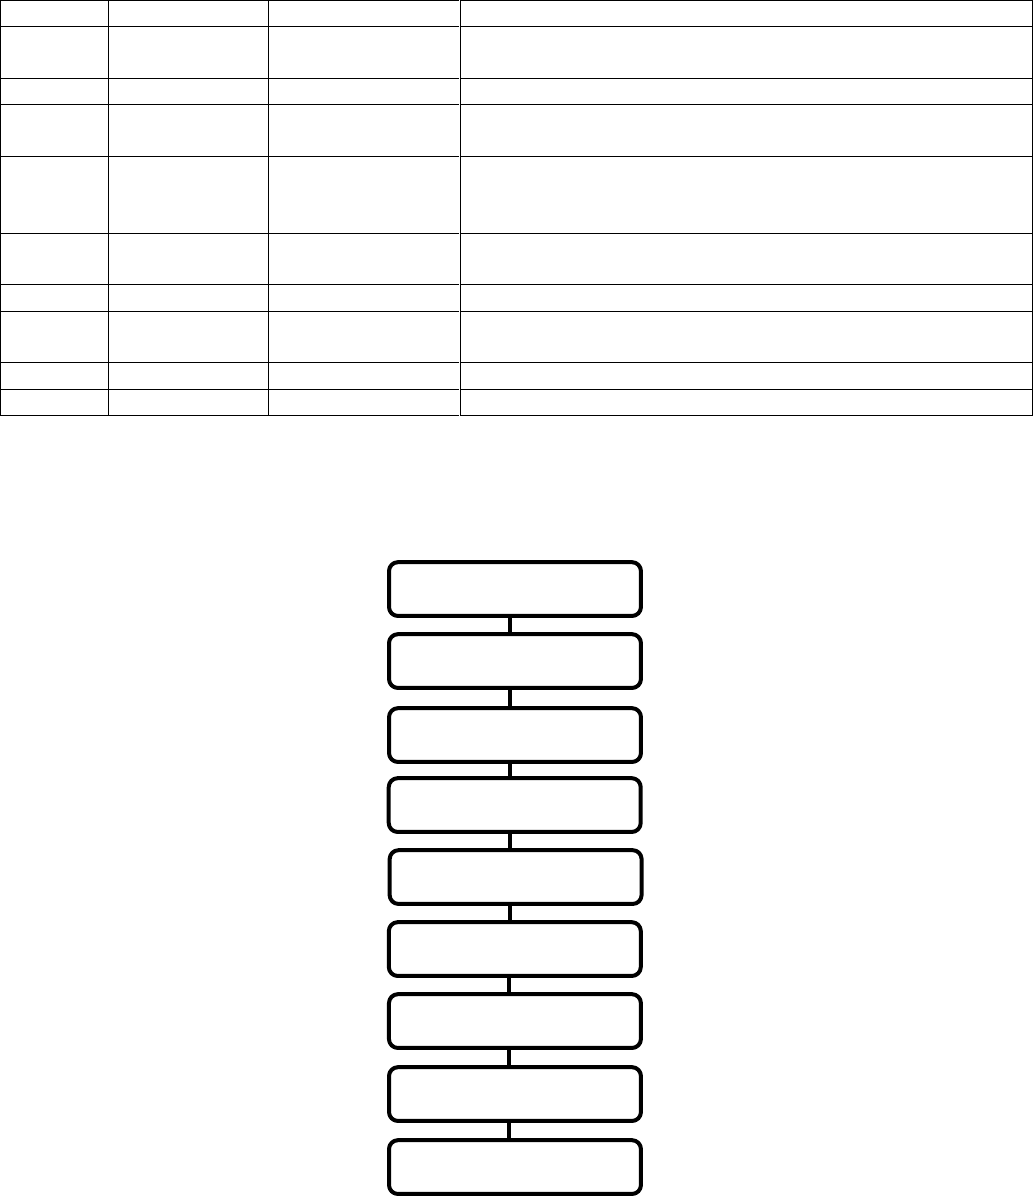
4. RAPID INSTRUCTION OF DISPENSING PROCESS
START
ATTACH DEVICE
NEW TEACHING FILE
END
PROCESS
EDIT PARAMETERS
SELECT PROCESSING FILE
DOWNLOAD TEACHING FILE
EDIT TEACHING FILE