_414214_AVK3 服务手册.pdf - 第51页
4.1 Adjustment Check List SERVICE MANUAL A VK3 4.1−8 D77SEC−83−010−A0 = MEMO =
4.1 Adjustment Check List
SERVICE MANUAL
AVK3
4.1−7
D77SEC−83−010−A0
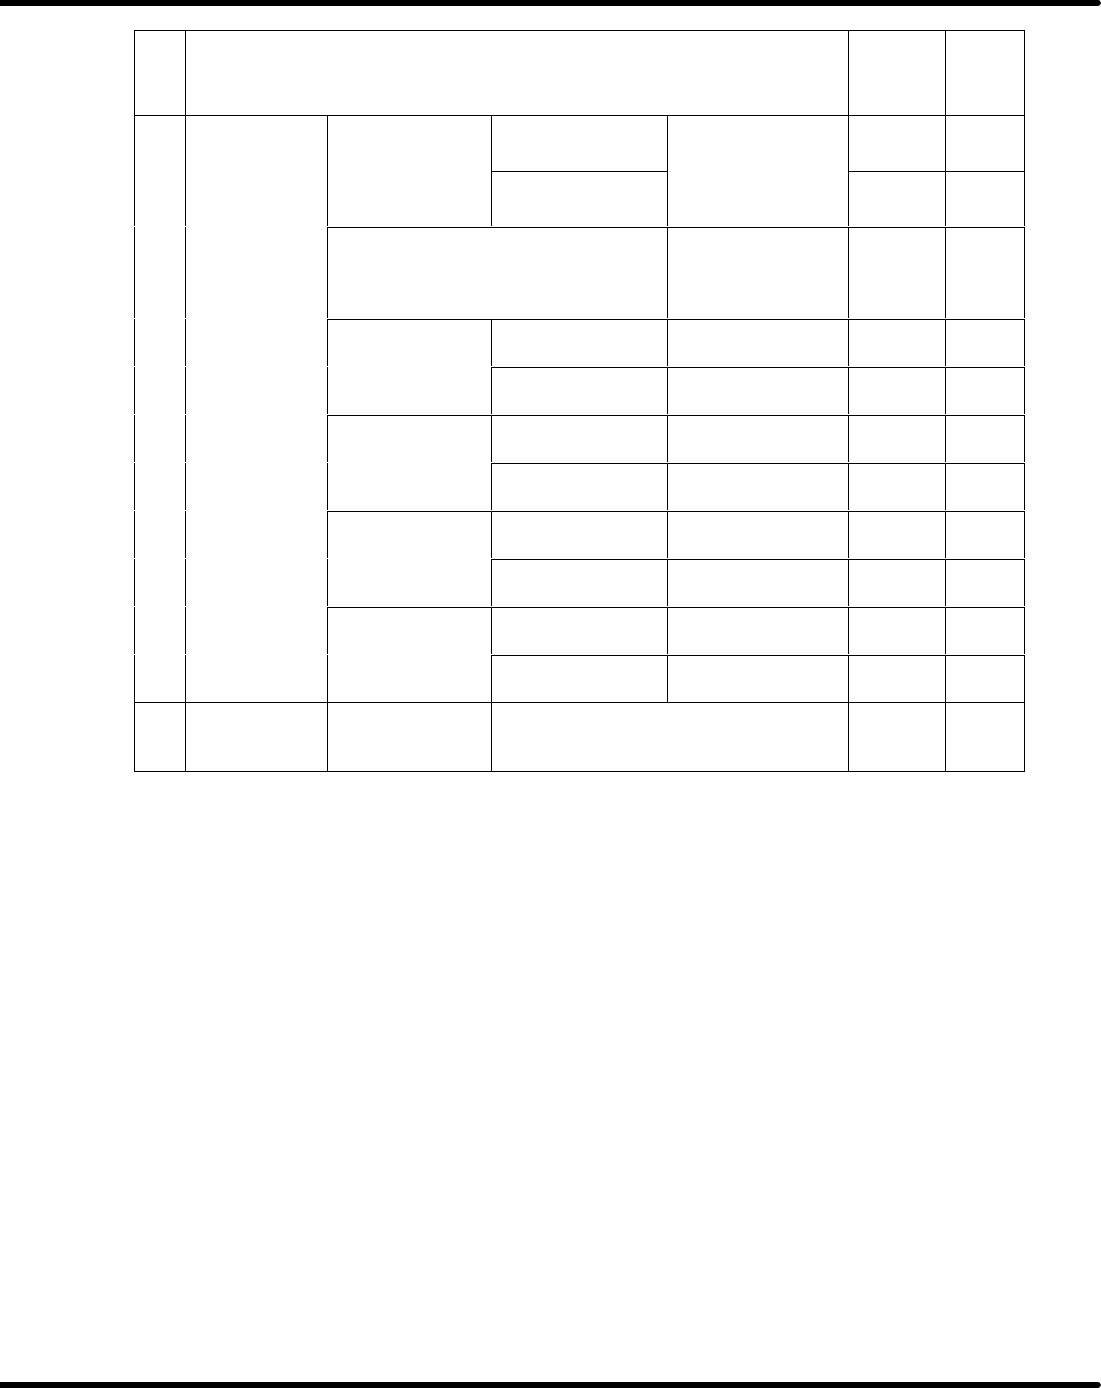
No.
Adjustment Item Check
Refer-
ence
Rail
height
Loader
The height of fixed
rail and movable
R
a
il
h
e
i
g
ht
Unloader
rail
and
movable
rail are same.
(Visual check)
Traverse and return timing of loader
and unloader
Check the timing
is synchronizing
(Visual check)
Rail
parallelism
Loader rail 0to0.5mm
34.
T
ransfer
unit
R
a
il
para
ll
e
li
sm
Unloader rail 0to0.5mm
34
.
T
ransfer
unit
Parallelism with
Loader rail 0to0.3mm
Parallelism
with
XY table
Unloader rail 0to0.3mm
Hei
g
ht with XY
Loader rail 0to0.3mm
Height
with
XY
table
Unloader rail 0to0.3mm
Clearance with
Loader rail 1to3mm
Clearance
with
XY table
Unloader rail 1to3mm
35. Camera Camera image
Make sure there is no foreign matter
within the camera image.
4.1 Adjustment Check List
SERVICE MANUAL
AVK3
4.1−8
D77SEC−83−010−A0
= MEMO =
4.2 Axis Origin Adjustment
SERVICE MANUAL
AVK3
4.2−1
D77SEC−83−1Z0−A0
4.2 Axis Origin Adjustment
D77SEC−83−1Z0−A0
Sentence No.
4.2 Axis Origin
Adjustment
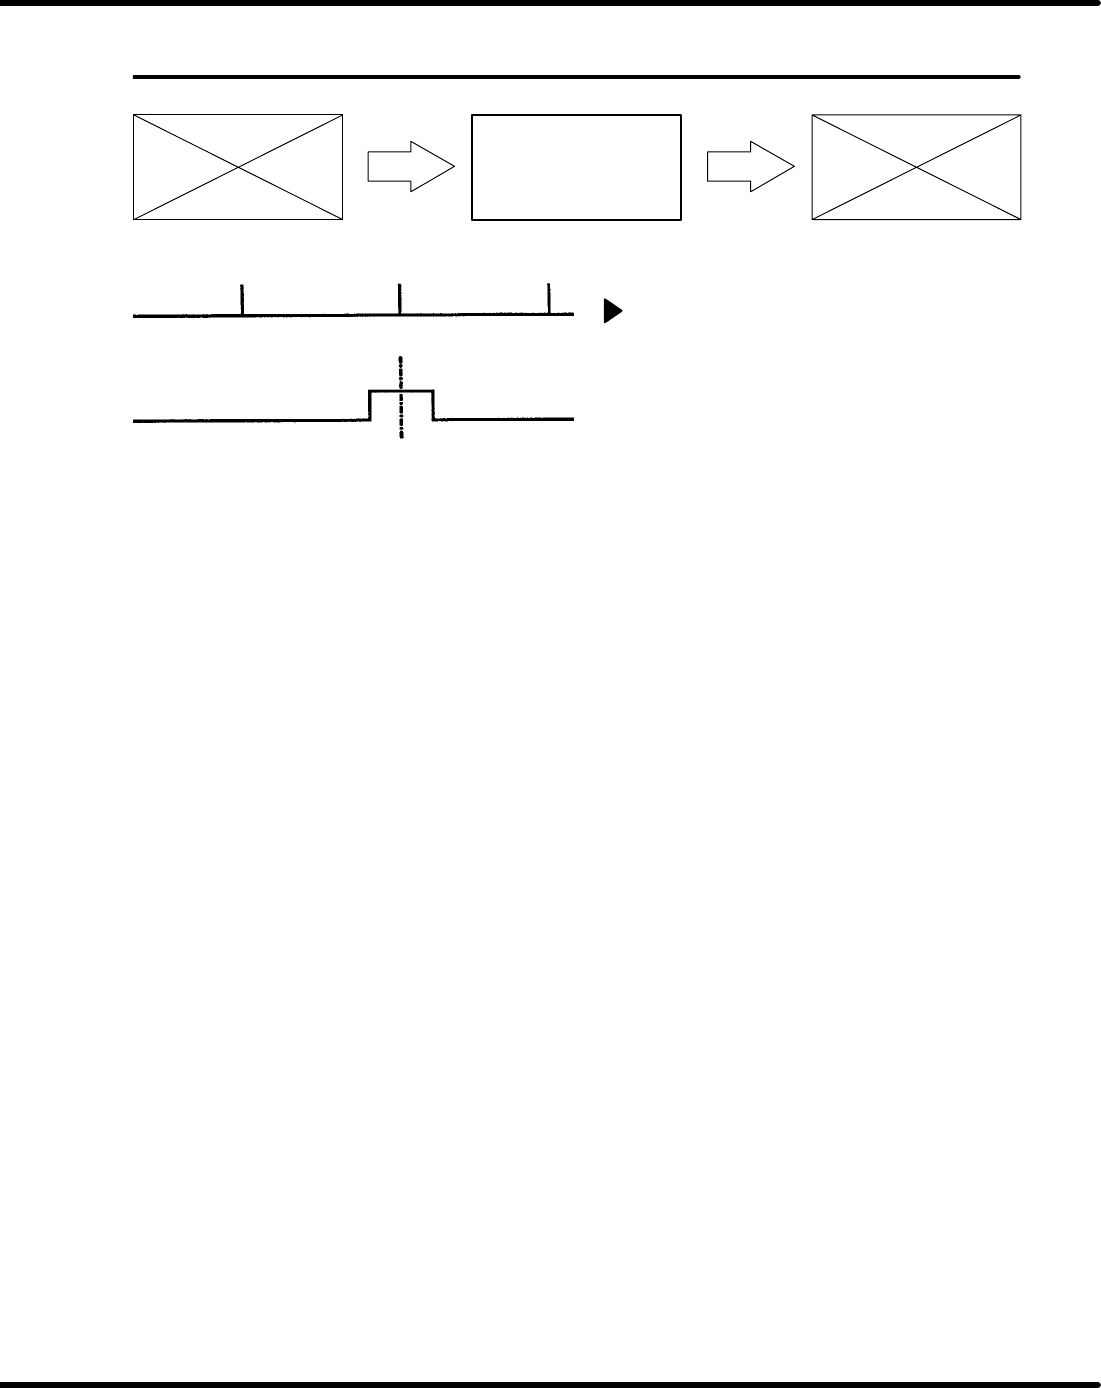
Motor origin
Origin sensor
Origin ← One motor rotation → Origin
←
One motor rotation → Origin
=Preparation=
1. Vinyl tape
Axis origin adjustment
1. Turn the power [ON].
2. Loosen the N coupling fixing the axis or
one side (the driving side) of the cotter.
=NOTE=
Make sure that the motor and N
coupling or the cotter is in the
locked state, and the driving axis
lightly rotates.
3. Short-circuit t he origin sensor or shield
with the vinyl tape to set it to come [ON].
4. Return to origin.
5. Move the driving side until the sensor dog
is the center of the origin sensor.
6. Tighten the N coupling or the cotter.
7. Take the vinyl tape out from the origin
sensor.
8. Check the sensor position.
=NOTE=
Be sure to fasten the origin sensor
to meet the center of the sensor dog
and the center of the sensor.(Check
for symmetrical positioning.)
=NOTE=
There is no slow down sensor.
Manual origin return moves at slow
speed and auto origin return moves
at high speed (pulse count move-
ment).