00193631-0602.pdf - 第21页
Adjustment Instructions MTC 2 3 Construction and mode of operation 12/2007 Edition 3.4 Modules of the controller 21 3.4.2 Masterdrives The Masterdrives are con trolled via the CAN bus system T asks: – Controlling the hol…
3 Construction and mode of operation Adjustment Instructions MTC 2
3.4 Modules of the controller 12/2007 Edition
20
3.4.1 C167 controller board
The controller program (firmware) on the C167 controller board is saved in a flash EPROM. The
version number can be queried from the SITEST program.
The machine data and the set-up are saved in RAM. After the machine is switched off, the data is
held by a buffer battery (buffer time approx. 3.5 years), which is also located on the C167 controller
board. In addition, an electrolytic capacitor ("Goldcap") with a capacity of 1 F is fitted. This saves
the data for approximately 8 hours when the buffer battery is changed.
The "neutral position" light barriers and the software limit switches are wired to the Masterdrives
and are made available there via the CAN bus of the controller.
Tasks:
– Communicating with the station computer of the SIPLACE station
– Controlling the machine via the firmware
– Exchanging data with the axis controllers
– Saving the firmware (flash EPROM)
– Saving the machine data and the set-up (battery-buffered RAM)
– Saving machine-specific parameters, such as serial numbers (in the EEPROM)
– Providing a realtime clock
– Inputs for sensors
– Displaying operating statuses and error statuses via LEDs
Two RS232 interfaces (maximum transfer rate: 115.2 kBaud/s)
COM 1: Test interface for debugging service
COM 2: Free
Two CAN bus interfaces (maximum transfer rate: 1 MBaud/s)
CAN1: Communication with the SIPLACE station
CAN2: Control of the 4 Masterdrives
Power supply: 24 V DC
Power consumption: 500 mA
24 inputs via a 37-pole Sub-D connector for the sensors
8 inputs via a 15-pole Sub-D connector for the actuators;
The outputs are short-circuit proof;
Current per output: 0.7 A, briefly up to 2.5A
Adjustment Instructions MTC 2 3 Construction and mode of operation
12/2007 Edition 3.4 Modules of the controller
21
3.4.2 Masterdrives
The Masterdrives are controlled via the CAN bus system
Tasks:
– Controlling the holding brakes for the lifting axes
– Controlling the permanently excited synchronous motors of the lifting and feed axes
– Evaluating the resolver
3.4.3 24V power supply
The 24V power supply supplies:
– The C167 controller board
– The logic circuitry of the Masterdrives
– The sensors and the actuators
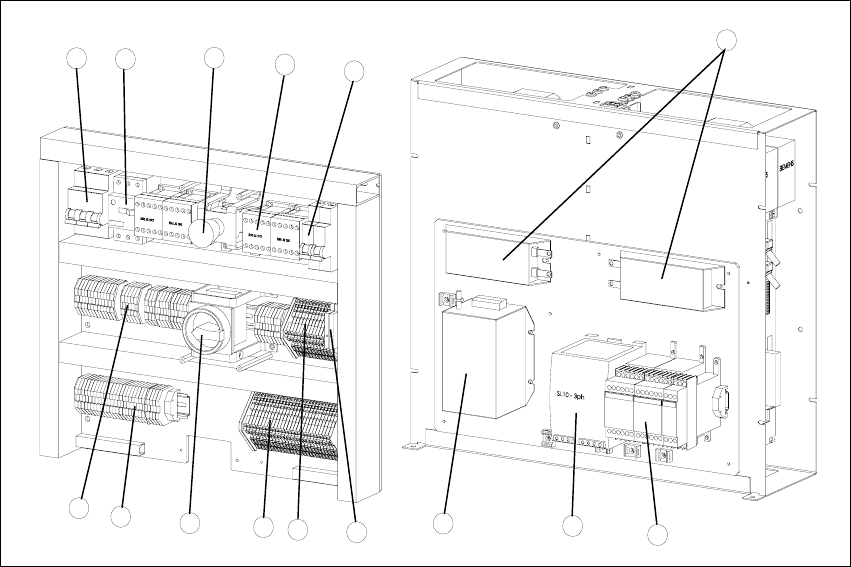
3.4.4 Electronics board
Electronics board with the following components:
– Main switch: S01
– EMERGENCY STOP button:S15
– Automatic circuit breakers: F00 main fuse
F01 24V sensors 1
F02 24V sensors 2, Masterdrive control voltage
– Motor protection swtich: Q01 Masterdrives
– Contactors: K01.1 Masterdrive lifting axis tower 1
K01.2 Masterdrive feed axis tower 1
K02.1 Masterdrive lifting axis tower 2
K02.2 Masterdrive feed axis tower 2
– Optocouplers: U09 brake tower 1
U06 brake tower 2
– Terminal strips: X01 supply
X02 24V power supply sensors / actuators
X03 EMERGENCY STOP circuit
X04 sensors / actuators tower 1
X05 sensors / actuators tower 2
X06 sensors / actuators
3 Construction and mode of operation Adjustment Instructions MTC 2
3.4 Modules of the controller 12/2007 Edition
22
3.4.5 Mounting plate
A mounting plate with the following components:
– Combination circuit breakers: K03 - K05
– Braking resistor: R01
– Braking resistor: R02
– Power supply, 24 V DC: T01
– Line filter: Z01
Fig. 3.4 - 2 Electronics board and mounting plate
Key
1 Main switches 8 Initiator LED terminals
2 EMERGENCY STOP button 9 Actuator LED terminals
3 Automatic circuit breakers 10 Optocouplers
4 Motor protection switches 11 Combination circuit breakers
5 Contactors 12 Braking resistors
6 Grounding terminals 13 Power supply
7 Through terminals 14 Line filters
8
3
6
4
2
5
3
1
9
12
13
14
11
10
7