sh030051g.pdf - 第110页
4 - 3 4. STARTUP 2) When regenerative option is used over 5kW for 200V class and 3.5kW for 400V class The lead of built-in regenerative resistor connected to P terminal and C terminal of TE1 terminal block should not be …
4 - 2
4. STARTUP
4.1.2 Wiring check
(1) Power supply system wiring
Before switching on the main circuit and control circuit power supplies, check the following items.
(a) Power supply system wiring
The power supplied to the power input terminals (L
1, L2, L3, L11, L21) of the servo amplifier should satisfy
the defined specifications. (Refer to section 1.3.)
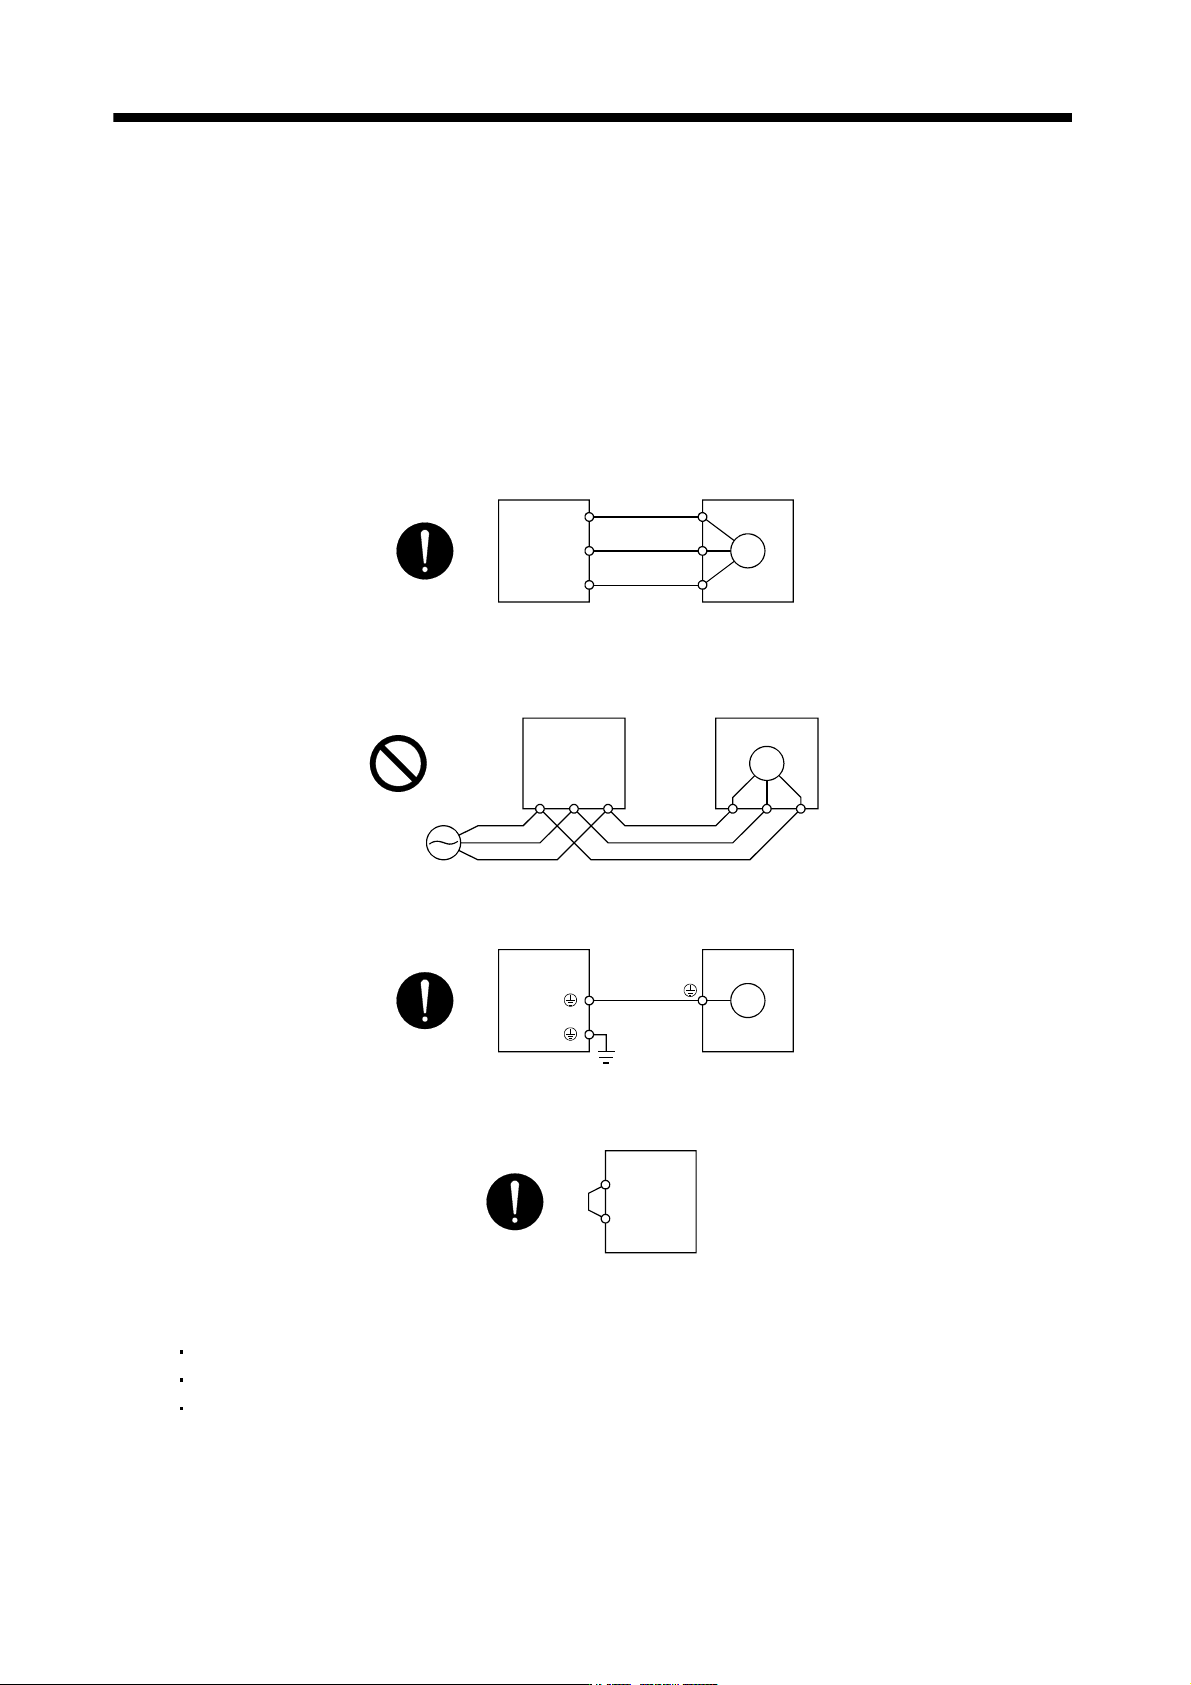
(b) Connection of servo amplifier and servo motor
1) The servo motor power supply terminals (U, V, W) of the servo amplifier match in phase with the
power input terminals (U, V, W) of the servo motor.
M
U
V
W
U
V
W
Servo amplifier Servo motor
2) The power supplied to the servo amplifier should not be connected to the servo motor power supply
terminals (U, V, W). To do so will fail the connected servo amplifier and servo motor.
UVW
UVW
M
Servo amplifie
r
Servo moto
r
3) The earth terminal of the servo motor is connected to the PE terminal of the servo amplifier.
M
Servo amplifier Servo motor
4) P
1-P2 (For 11kW or more, P1-P) should be connected.
P
1
P
2
Servo amplifie
r
(c) When option and auxiliary equipment are used
1) When regenerative option is used under 3.5kW for 200V class and 2kW for 400V class
The lead between P terminal and D terminal of CNP2 connector should not be connected.
The generative brake option should be connected to P terminal and C terminal.
A twisted cable should be used. (Refer to section 11.2)
4 - 3
4. STARTUP
2) When regenerative option is used over 5kW for 200V class and 3.5kW for 400V class
The lead of built-in regenerative resistor connected to P terminal and C terminal of TE1 terminal block
should not be connected.
The generative brake option should be connected to P terminal and C terminal.
A twisted cable should be used when wiring is over 5m and under 10m. (Refer to section 11.2)
3) When brake unit and power regenerative converter are used over 5kW
The lead of built-in regenerative resistor connected to P terminal and C terminal of TE1 terminal block
should not be connected.
Brake unit, power regenerative converter or power regeneration converter should be connected to P
terminal and N terminal. (Refer to section 11.3 to 11.5)
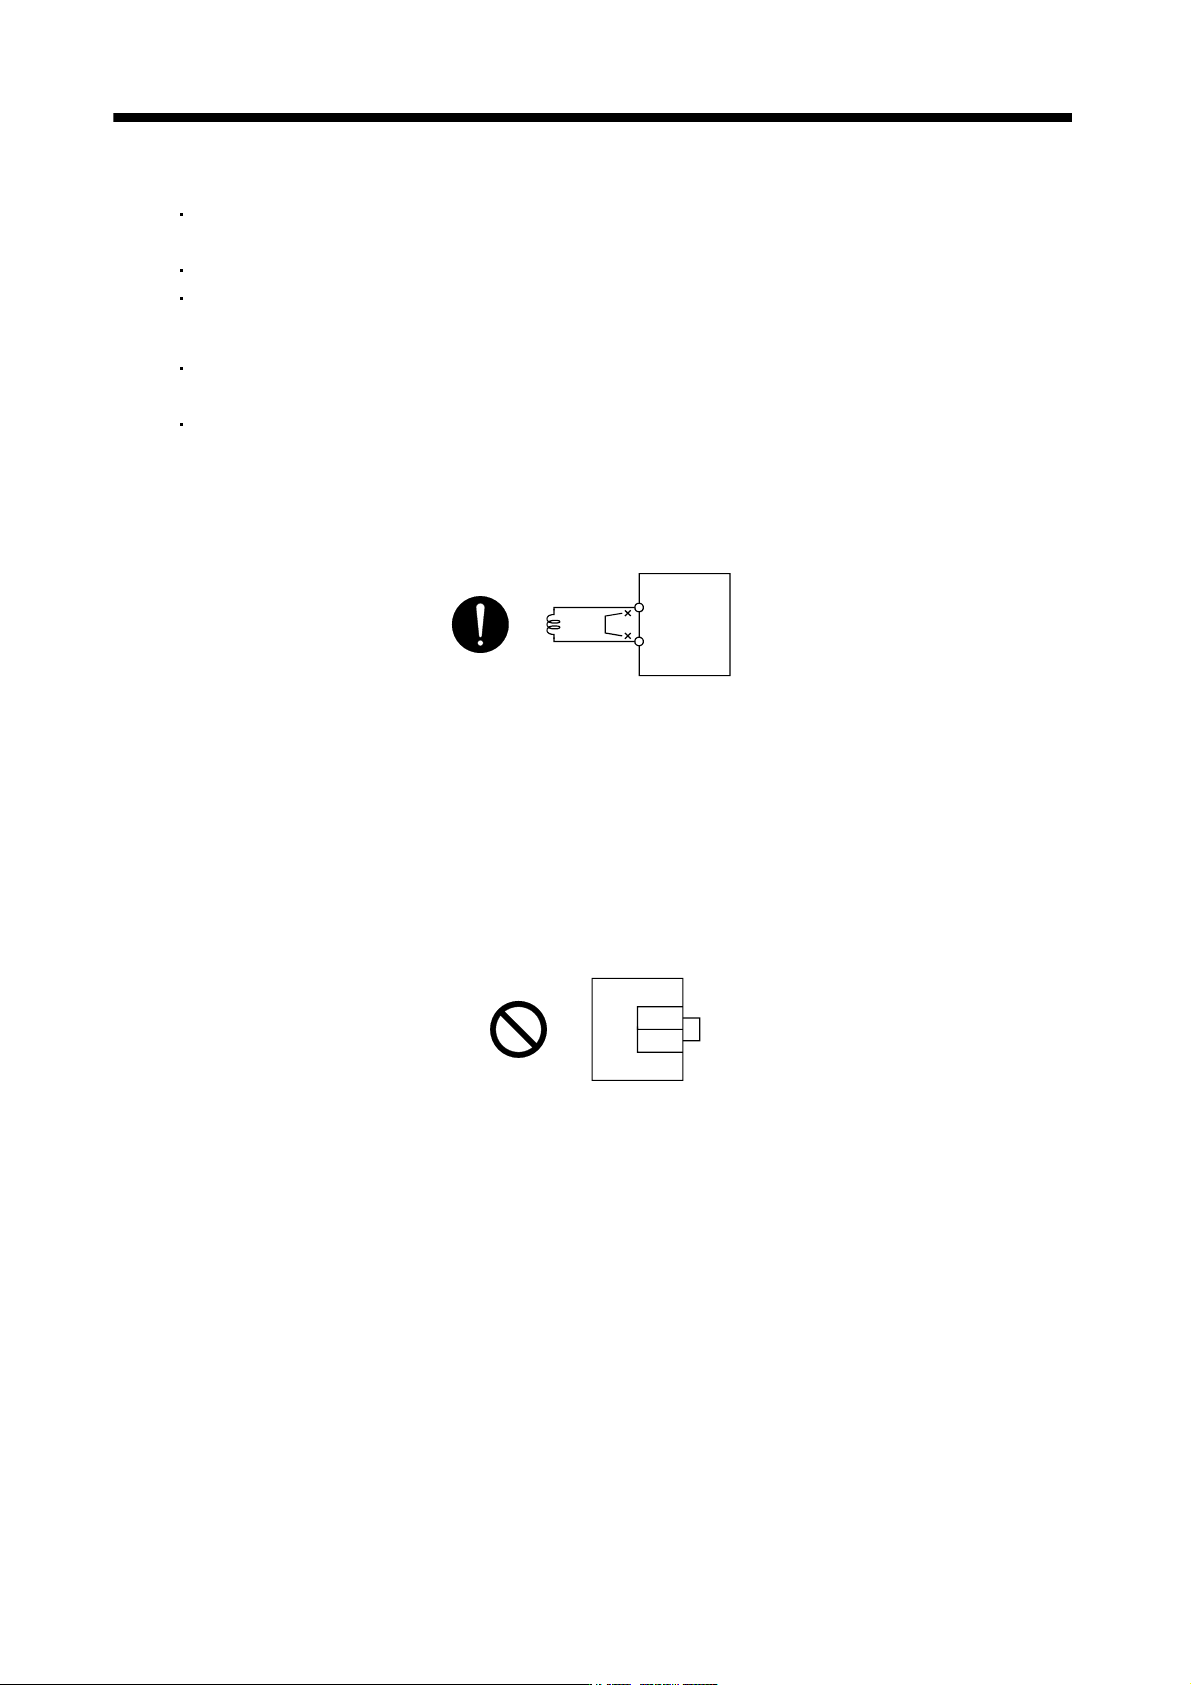
4) The power factor improving DC reactor should be connected P
1 and P2 (For 11k to 22kW, P
1
and P).
(Refer to section 11.13.)
P1
P2
Servo amplifie
r
(Note)
Power factor
improving DC
reactor
Note. Always disconnect P1 and P2. (For 11k to 22kW P1 and P)
(2) I/O signal wiring
(a) The I/O signals should be connected correctly.
Use DO forced output to forcibly turn on/off the pins of the CN3 connector. This function can be used to
perform a wiring check. In this case, switch on the control circuit power supply only.
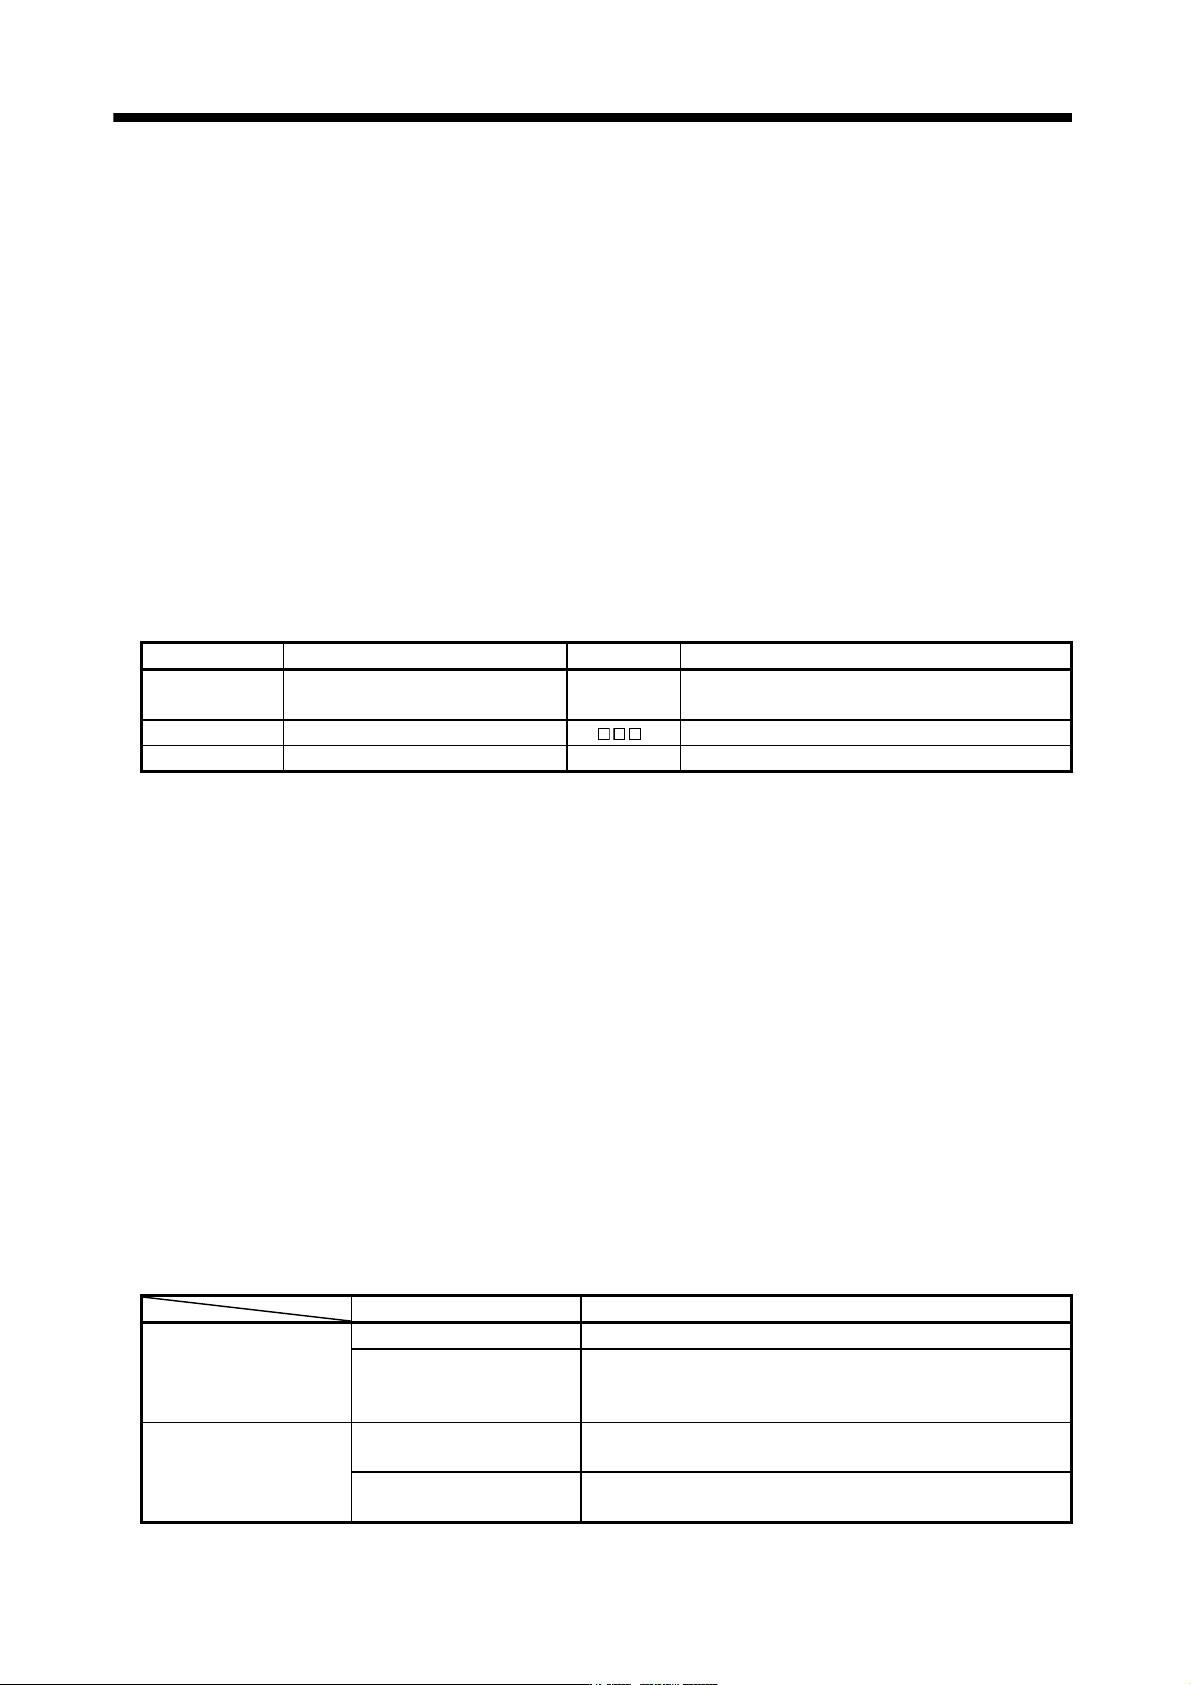
(b) 24VDC or higher voltage is not applied to the pins of connectors CN3.
(c) SD and DOCOM of connector CN3 is not shorted.
DOCOM
SD
CN3
Servo amplifier
4.1.3 Surrounding environment
(1) Cable routing
(a) The wiring cables are free from excessive force.
(b) The encoder cable should not be used in excess of its flex life. (Refer to section 10.4.)
(c) The connector part of the servo motor should not be strained.
(2) Environment
Signal cables and power cables are not shorted by wire offcuts, metallic dust or the like.
4 - 4
4. STARTUP
4.2 Start up
Connect the servo motor with a machine after confirming that the servo motor operates properly alone.
(1) Power on
When the main and control circuit power supplies are switched on, "b01" (for the first axis) appears on the
servo amplifier display.
In the absolute position detection system, first power-on results in the absolute position lost (25) alarm and
the servo system cannot be switched on.
The alarm can be deactivated by then switching power off once and on again.
Also in the absolute position detection system, if power is switched on at the servo motor speed of 500r/min
or higher, position mismatch may occur due to external force or the like. Power must therefore be switched
on when the servo motor is at a stop.
(2) Parameter setting
Set the parameters according to the structure and specifications of the machine. Refer to chapter 5 for the
parameter definitions.
Parameter No. Name Setting Description
PA14 Rotation direction setting 0
Increase in positioning address rotates the motor in
the CCW direction.
PA08 Auto tuning mode 1 Used.
PA09 Auto tuning response 12 Slow response (initial value) is selected.
After setting the above parameters, switch power off once. Then switch power on again to make the set
parameter values valid.
(3) Servo-on
Switch the servo-on in the following procedure.
1) Switch on main circuit/control circuit power supply.
2) The controller transmits the servo-on command.
When placed in the servo-on status, the servo amplifier is ready to operate and the servo motor is locked.
(4) Home position return
Always perform home position return before starting positioning operation.
(5) Stop
If any of the following situations occurs, the servo amplifier suspends the running of the servo motor and
brings it to a stop.
When the servo motor is with an electromagnetic brake, refer to section 3.11.
Operation/command Stopping condition
Servo system controller
Servo off command The base circuit is shut off and the servo motor coasts.
Forced stop command
The base circuit is shut off and the dynamic brake operates to bring
the servo motor to stop. The controller forced stop warning (E7)
occurs.
Servo amplifier
Alarm occurrence
The base circuit is shut off and the dynamic brake operates to bring
the servo motor to stop.
Forced stop
(EM1) OFF
The base circuit is shut off and the dynamic brake operates to bring
the servo motor to stop. The servo forced stop warning (E6) occurs.