sh030051g.pdf - 第114页
4 - 7 4. STARTUP 4.4 Test operation Before starting actual operation , perform test operatio n to make sur e that the machine operate s normally. Refer to section 4.2 for the power on and off methods of the servo amplifi…
4 - 6
4. STARTUP
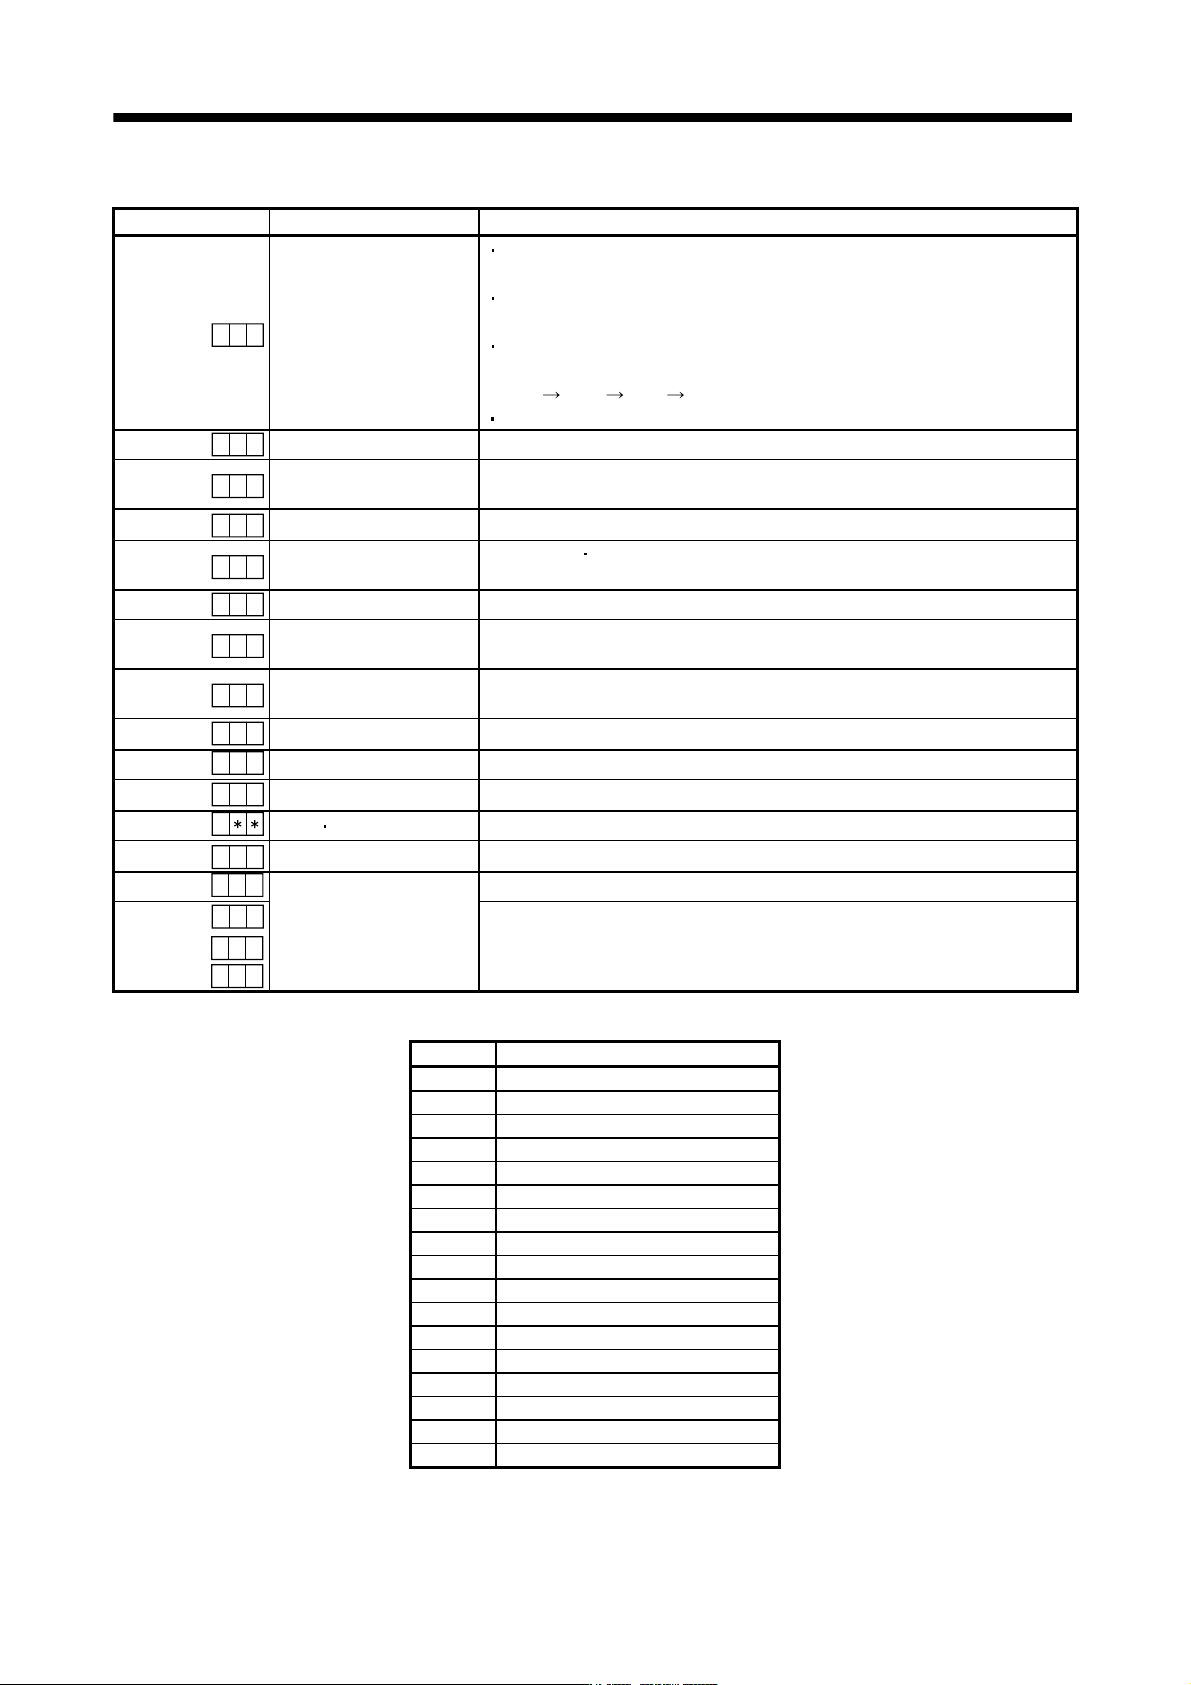
(2) Indication list
Indication Status Description
A b
Initializing
Power of the servo amplifier was switched on at the condition that the power of
servo system controller is OFF.
The axis No. set to the servo system controller does not match the axis No. set
with the rotary axis setting switch (SW1) of the servo amplifier.
A servo amplifier fault occurred or an error took place in communication with the
servo system controller. In this case, the indication changes.
"Ab "
"AC " "Ad " "Ab "
The servo system controller is faulty.
.
A
b
Initializing During initial setting for communication specifications
A C
Initializing
Initial setting for communication specifications completed, and then it synchronized
with servo system controller.
A d
Initializing During initial parameter setting communication with servo system controller
A E
Initializing
During motor
encoder information and telecommunication with servo system
controller
A F
Initializing During initial signal data communication with servo system controller
A H
Initializing completion
During the completion process for initial data communication with servo system
controller
A A
Initializing standby
The power supply of servo system controller is turned off during the power supply
of servo amplifier is on.
(Note 1)
b
# #
Ready OFF The ready off signal from the servo system controller was received.
(Note 1)
d
# #
Servo ON The ready off signal from the servo system controller was received.
(Note 1)
C
# #
Servo OFF The ready off signal from the servo system controller was received.
(Note 2)
Alarm
Warning The alarm No./warning No. that occurred is displayed. (Refer to section 9.1.)
8 88
CPU Error CPU watchdog error has occurred.
(Note 3)
0 0.b
(Note 3)
Test operation mode
JOG operation, positioning operation, programmed operation, DO forced output.
(Note 1)
# #.b
# #.d
# #.C
Motor-less operation
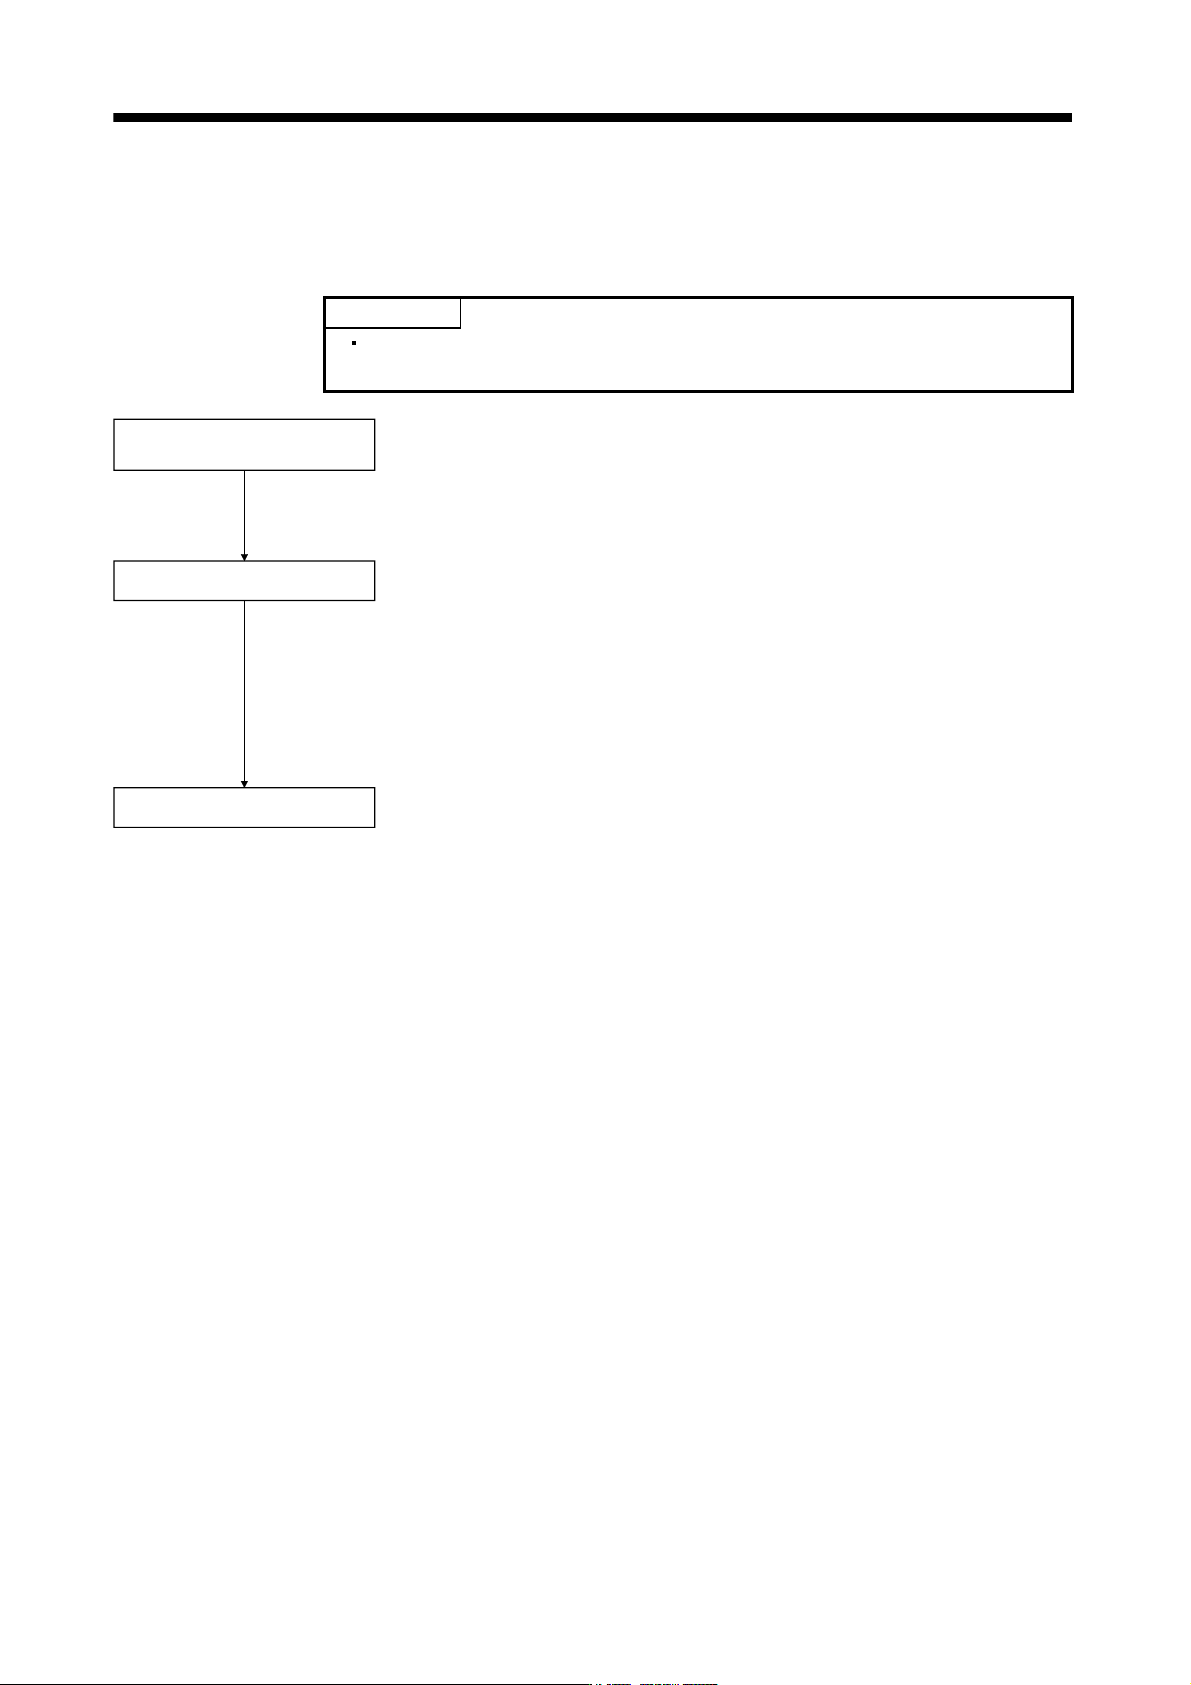
Note 1. ## denotes any of numerals 00 to 16 and what it means is listed below.
# Description
0 Set to the test operation mode.
1 First axis
2 Second axis
3 Third axis
4 Fourth axis
5 Fifth axis
6 Sixth axis
7 Seventh axis
8 Eighth axis
9 Ninth axis
10 Tenth axis
11 Eleventh axis
12 Twelfth axis
13 Thirteenth axis
14 Fourteenth axis
15 Fifteenth axis
16 Sixteenth axis
2. ** indicates the warning/alarm No.
3. Requires the MR Configurator.
4 - 7
4. STARTUP
4.4 Test operation
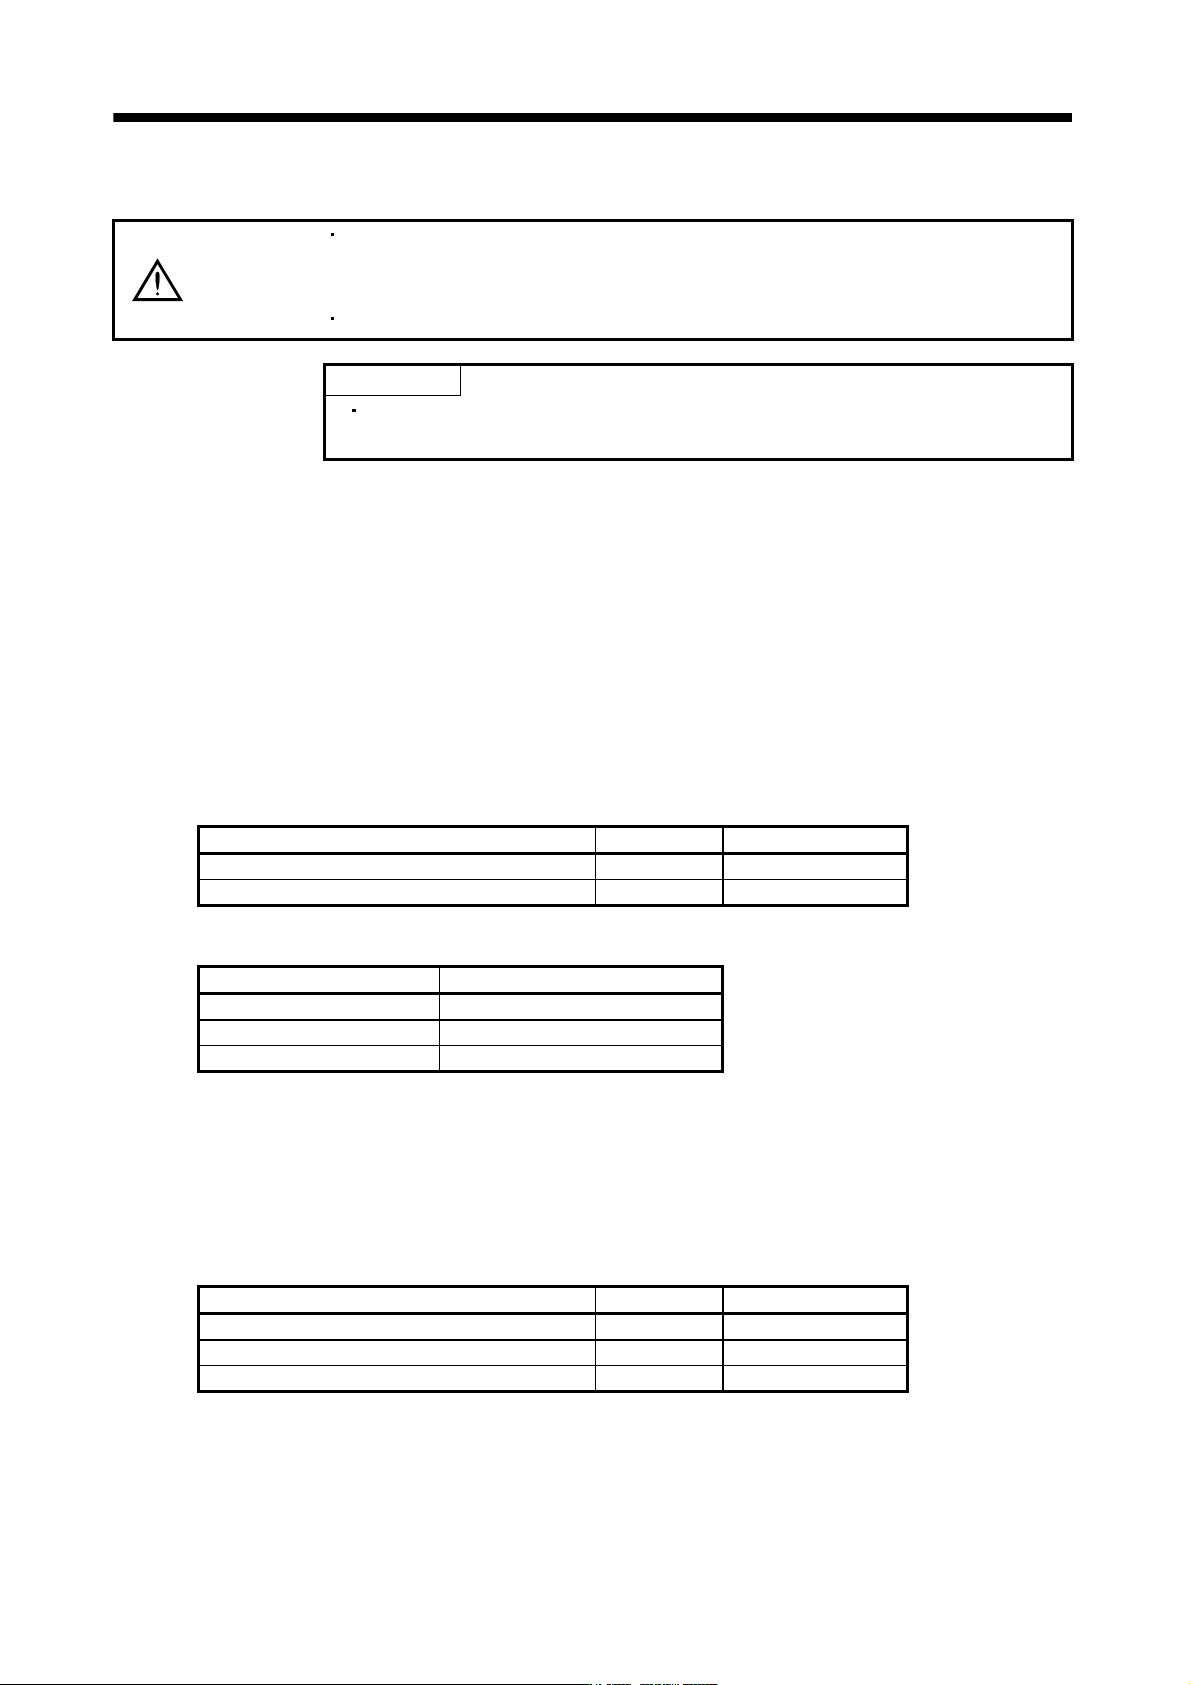
Before starting actual operation, perform test operation to make sure that the machine operates normally.
Refer to section 4.2 for the power on and off methods of the servo amplifier.
POINT
If necessary, verify controller program by using motorless operation.
Refer to section 4.5.2 for the motorless operation.
Test operation of servo motor
alone in JOG operation of test
operation mode
Test operation of servo motor
alone by commands
Test operation with servo motor
and machine connected
In this step, confirm that the servo amplifier and servo motor operate normally.
With the servo motor disconnected from the machine, use the test operation
mode and check whether the servo motor rotates correctly. Refer to section
4.5 for the test operation mode.
In this step, confirm that the servo motor rotates correctly under the
commands from the controller.
Make sure that the servo motor rotates in the following procedure.
Give a low speed command at first and check the rotation direction, etc. of the
servo motor.
If the servo motor does not operate in the intended direction, check the input
signal.
In this step, connect the servo motor with the machine and confirm that the
machine operates normally under the commands from the command device.
Make sure that the servo motor rotates in the following procedure.
Give a low speed command at first and check the operation direction, etc. o
f
the machine. If the machine does not operate in the intended direction, check
the input signal. In the status display, check for any problems of the servo
motor speed, command pulse frequency, load ratio, etc.
Then, check automatic operation with the program of the command device.
4 - 8
4. STARTUP
4.5 Test operation mode
CAUTION
The test operation mode is designed for servo operation confirmation and not for
machine operation confirmation. Do not use this mode with the machine. Always
use the servo motor alone.
If an operation fault occurred, use the forced stop (EM1) to make a stop.
POINT
The content described in this section indicates the environment that servo
amplifier and personal computer are directly connected.
By using a personal computer and the MR Configurator, you can execute jog operation, positioning operation,
DO forced output program operation without connecting the servo system controller.
4.5.1 Test operation mode in MR Configurator
(1) Test operation mode
(a) Jog operation
Jog operation can be performed without using the servo system controller. Use this operation with the
forced stop reset. This operation may be used independently of whether the servo is on or off and
whether the servo system controller is connected or not.
Exercise control on the jog operation screen of the MR Configurator.
1) Operation pattern
Item Initial value Setting range
Speed [r/min] 200 0 to max. speed
Acceleration/deceleration time constant [ms] 1000 0 to 50000
2) Operation method
Operation Screen control
Forward rotation start Click the "Forward" button.
Reverse rotation start Click the "Reverse" button.
Stop Click the "Stop" button.
(b) Positioning operation
Positioning operation can be performed without using the servo system controller. Use this operation
with the forced stop reset. This operation may be used independently of whether the servo is on or off
and whether the servo system controller is connected or not.
Exercise control on the positioning operation screen of the MR Configurator.
1) Operation pattern
Item Initial value Setting range
Travel [pulse] 4000 0 to 99999999
Speed [r/min] 200 0 to max. speed
Acceleration/deceleration time constant [ms] 1000 0 to 50000