sh030051g.pdf - 第79页
3 - 24 3. SIGNALS AND WI RING 3.5 Signal (device) explanations For the I/O in terfaces (symbols in I/O division column in the table), refer to section 3.7 .2. In the control mode field of the table The pin No.s in the co…
3 - 23
3. SIGNALS AND WIRING
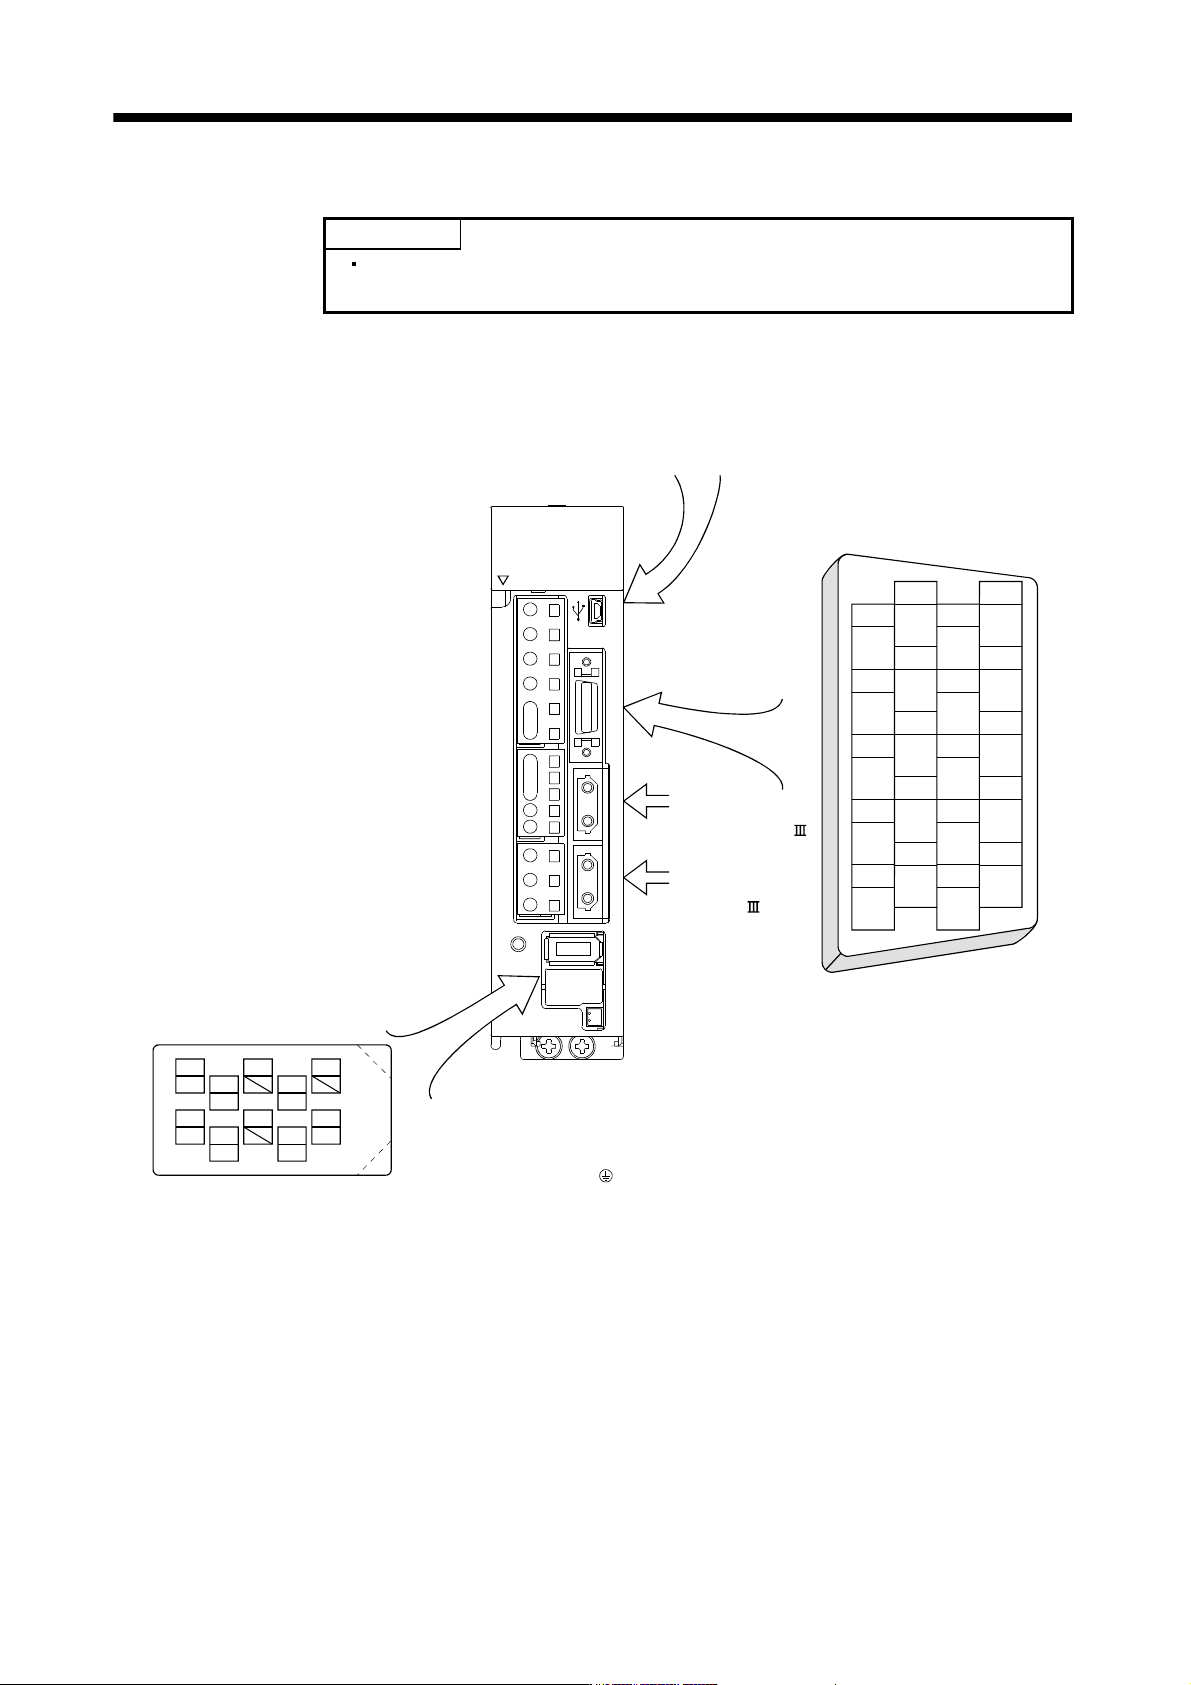
3.4 Connectors and signal arrangements
POINT
The pin configurations of the connectors are as viewed from the cable
connector wiring section.
(1) Signal arrangement
The servo amplifier front view shown is that of the MR-J3-20B or less. Refer to chapter 9 Outline Drawings
for the appearances and connector layouts of the other servo amplifiers.
The 3M make connector is shown.
When using any other connector,
refer to section 11.1.2.
9
4
MRR
2
LG
8
6
1
P5
5
10
3
MR
7
BAT
CN2
MDR
MD
CN4 CN2L CN2 CN1B CN1A CN3 CN5
CHARGE
L
2
U
W
V
D
L
12
L11
C
P
N
P
1
P
2
L
3
L
1
OPEN
CN5 (USB connector)
Refer to section 11.8.
CN3
The frames of the CN2 and CN3
connectors are connected to the
PE (earth) terminal ( ) in the
amplifier.
Connector for
the front axis of
CN1A SSCNET
cable.
Connector for the
rear axis of CN1B
SSCNET cable.
2
111
12
4
313
14
6
515
16
8
717
18
10
919
20
DI1
LG LG
DI2
MO1
DOCOM
MBR
MO2
LA
DICOM
ALM
LAR
LZ
LB LBR
LZR
DICOM
INP DI1
EM1
3 - 24
3. SIGNALS AND WIRING
3.5 Signal (device) explanations
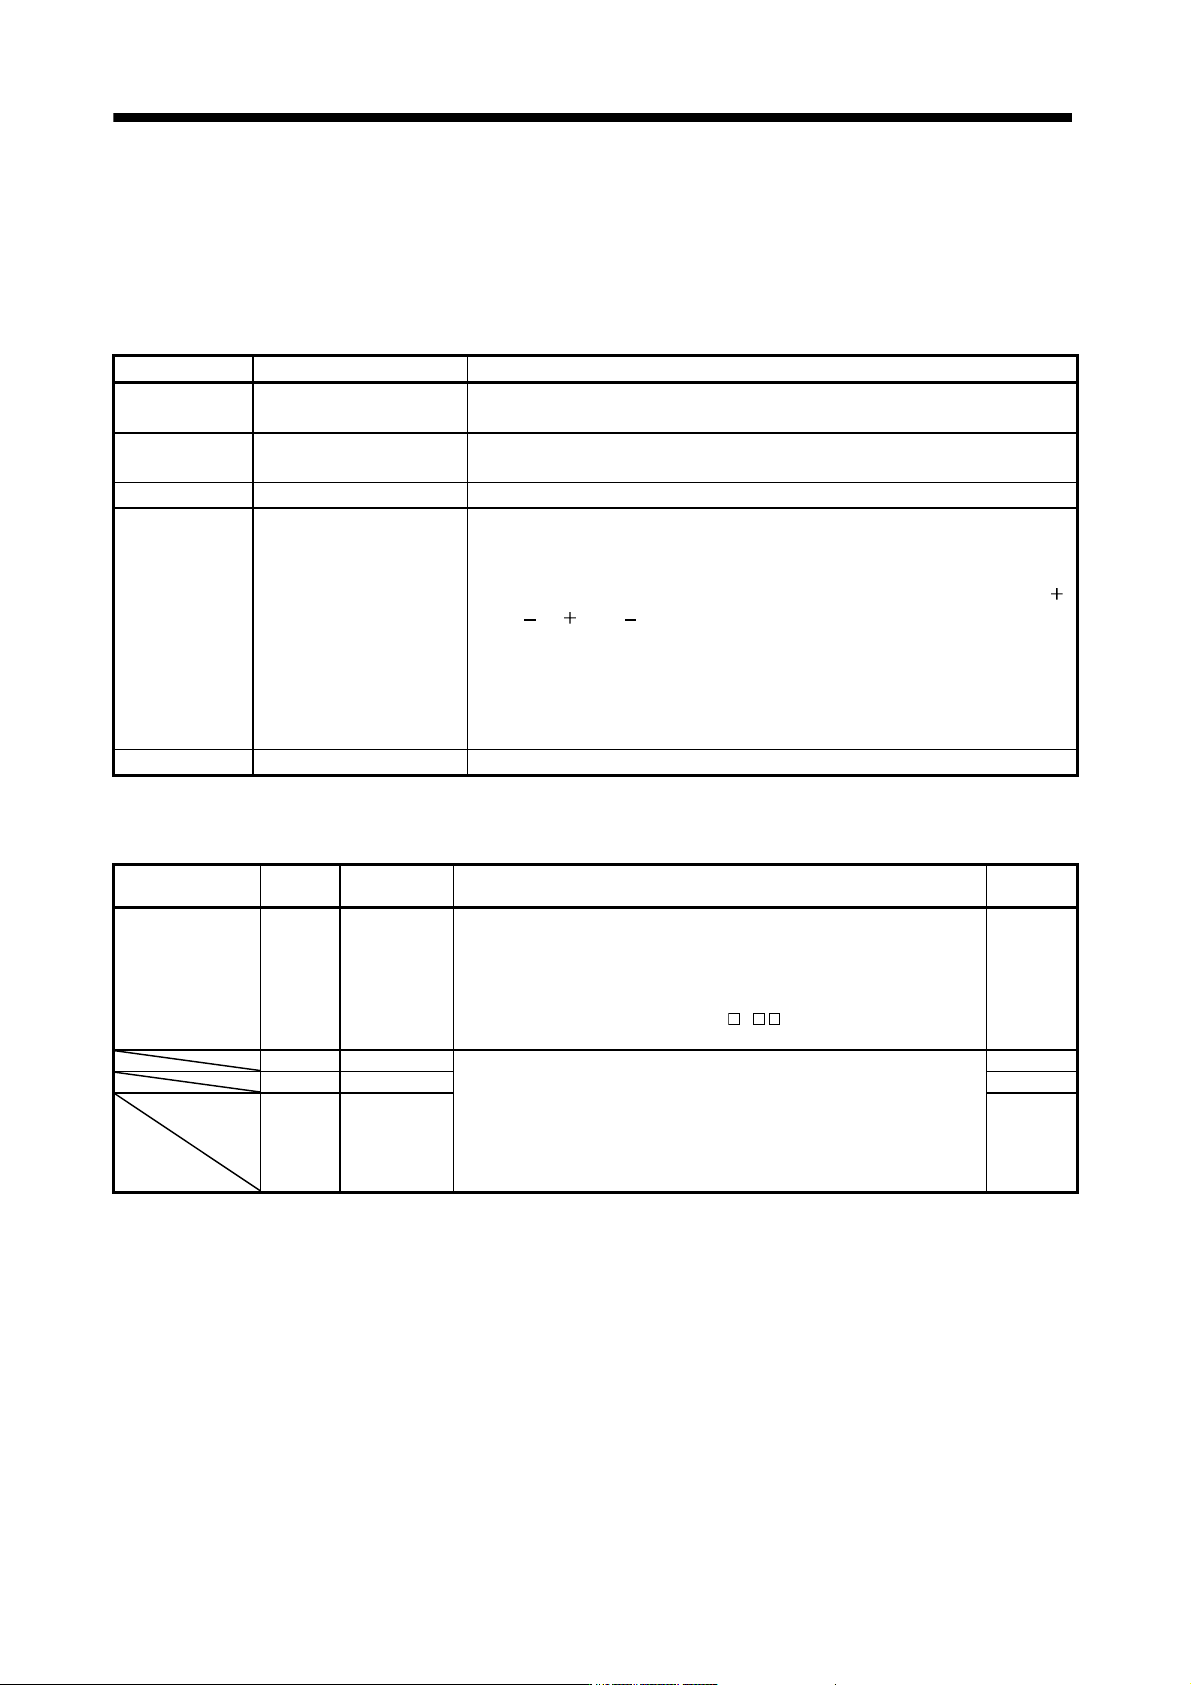
For the I/O interfaces (symbols in I/O division column in the table), refer to section 3.7.2.
In the control mode field of the table
The pin No.s in the connector pin No. column are those in the initial status.
(1) Connector applications
Connector Name Function/Application
CN1A Connector for bus cable
from preceding axis.
Used for connection with the controller or preceding-axis servo amplifier.
CN1B Connector for bus cable to
next axis
Used for connection with the next-axis servo amplifier or for connection of the cap.
CN2 Encoder connector Used for connection with the servo motor encoder.
CN4 Battery connection
connector
When using as absolute position detection system, connect to battery (MR-J3BAT).
Before installing a battery, turn off the main circuit power while keeping the control
circuit power on. Wait for 15 minutes or more (20 minutes or for drive unit 30kW or
more) until the charge lamp turns off. Then, confirm that the voltage between P(
)
and N(
) (L and L for drive unit 30kW or more) is safe with a voltage tester and
others. Otherwise, an electric shock may occur. In addition, always confirm from the
front of the servo amplifier whether the charge lamp is off or not. Replace the
battery with main circuit power OFF and with control circuit power ON. Replacing
the battery with the control circuit power OFF results in loosing absolute position
data.
CN5 Communication connector The personal computer is connected.
(2) I/O device
(a) Input device
Device Symbol
Connector
pin No.
Function/Application
I/O
division
Forced stop EM1 CN3-20 Turn EM1 off (open between commons) to bring the motor to an forced
stop state, in which the base circuit is shut off and the dynamic brake is
operated.
Turn EM1 on (short between commons) in the forced stop state to reset
that state.
When parameter No.PA.04 is set to "
1 ", automatically ON
(always ON) can be set inside.
DI-1
DI1 CN3-2 Devices can be assigned for DI1 DI2 DI3 with controller setting.
For devices that can be assigned, refer to the controller instruction
manual. The following devices can be assigned for Q172HCPU
Q173HCPU QD75MH.
DI1: upper stroke limit (FLS)
DI2: lower stroke limit (RLS)
DI3: proximity dog (DOG)
DI-1
DI2 CN3-12 DI-1
DI3 CN3-19 DI-1
3 - 25
3. SIGNALS AND WIRING
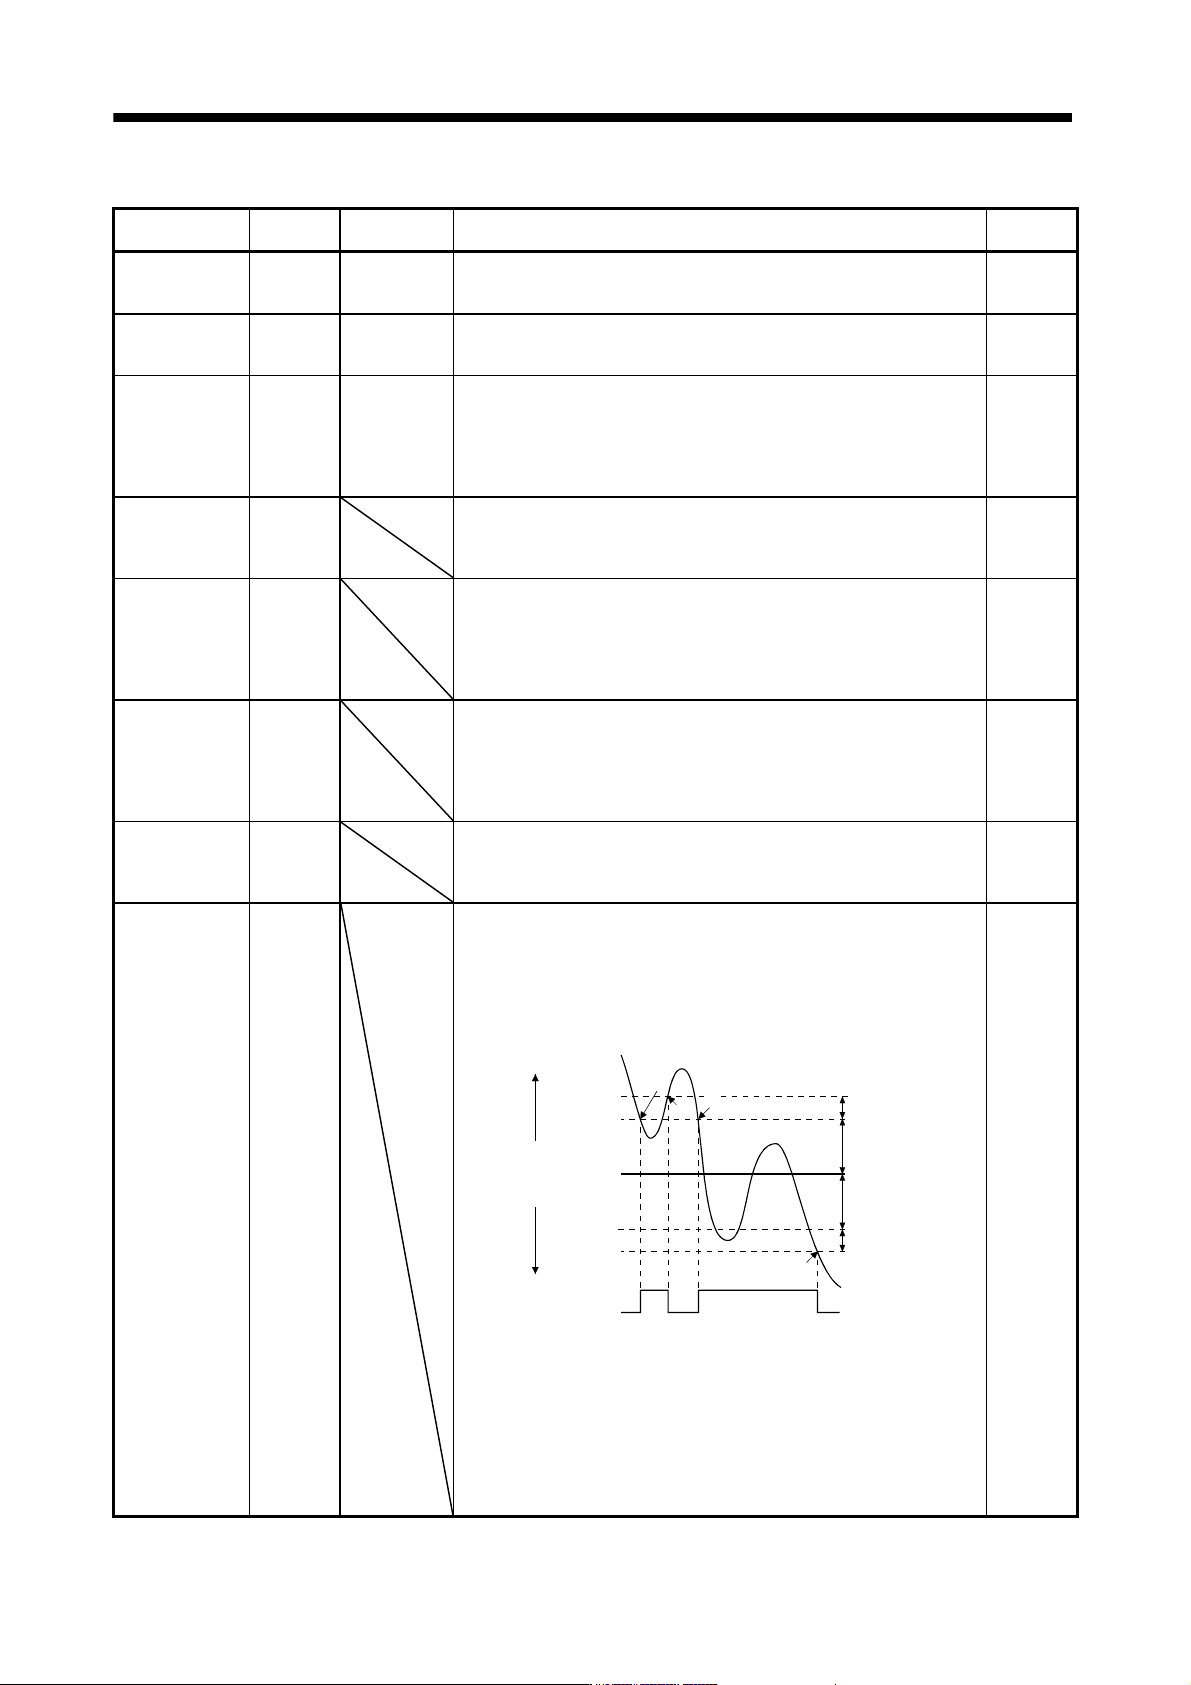
(b) Output device
Device Symbol
Connector
pin No.
Function/Application
I/O
division
Trouble ALM CN3-15 ALM turns off when power is switched off or the protective circuit is
activated to shut off the base circuit.
Without alarm occurring, ALM turns on within about 1s after power-on.
DO-1
Electromagnetic
brake interlock
MBR CN3-13 When using this signal, set operation delay time of the electromagnetic
brake in parameter No.PC02.
In the servo-off or alarm status, MBR turns off.
DO-1
In-position
(Positioning
completed)
INP CN3-9 INP turns on when the number of droop pulses is in the preset in-position
range. The in-position range can be changed using parameter No.PA10.
When the in-position range is increased, INP may be on conductive
status during low-speed rotation.
INP turns on when servo on turns on.
This signal cannot be used in the speed loop mode.
DO-1
Ready RD When using the signal, make it usable by the setting of parameter
No.PD07 to PD09.
RD turns on when the servo is switched on and the servo amplifier is
ready to operate.
DO-1
Dynamic brake
interlock
DB When using the signal, make it usable by the setting of parameter
No.PD07 to PD09. DB turns off simultaneously when the dynamic brake
is operated. When using the external dynamic brake on the servo
amplifier of 11 kW or more, this device is required. (Refer to section
11.6.) For the servo amplifier of 7kW or less, it is not necessary to use
this device.
DO-1
Speed reached SA When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
When the servo is off, SA will be turned OFF. When servo motor rotation
speed becomes approximately setting speed, SA will be turned ON.
When the preset speed is 20r/min or less, SA always turns on. This
signal cannot be used in position loop mode.
DO-1
Limiting torque TLC When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
When torque is produced level of torque set with controller, TLC will be
turned ON. When the servo is off, TLC will be turned OFF.
DO-1
Zero speed ZSP
When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
When the servo is off, SA will be turned OFF.
ZSP turns on when the servo motor speed is zero speed (50r/min) or
less. Zero speed can be changed using parameter No.PC07.
Example
Zero speed is 50r/min
OFF
ON
0r/min
1)
3)
2)
4)
Forward
rotation
direction
Servo motor
speed
Reverse
rotation
direction
zero speed
(ZSP)
ON level
50r/min
OFF level
70r/min
ON level
50r/min
OFF level
70r/min
Parameter
No.PC07
20r/min
(Hysteresis width)
20r/min
(Hysteresis width)
Parameter
No.PC07
ZPS turns on
1)
when the servo motor is decelerated to 50r/min, and
ZPS turns off
2)
when the servo motor is accelerated to 70r/min again.
ZPS turns on
3)
when the servo motor is decelerated again to 50r/min,
and turns off
4)
when the servo motor speed has reached -70r/min.
The range from the point when the servo motor speed has reached ON
level, and ZPS turns on, to the point when it is accelerated again and has
reached OFF level is called hysteresis width.
Hysteresis width is 20r/min for the MR-J3-B servo amplifier.
DO-1