sh030051g.pdf - 第149页
6 - 4 6. GENERAL GAIN ADJUSTMEN T 6.2.2 Auto tuning mode operation The block diagram of real-time auto tunin g is shown below. Servo motor Command Automa tic se tting Loop ga ins PG1,VG1 PG2,VG2,VIC Current control Curre…
6 - 3
6. GENERAL GAIN ADJUSTMENT
6.2 Auto tuning
6.2.1 Auto tuning mode
The servo amplifier has a real-time auto tuning function which estimates the machine characteristic (load inertia
moment ratio) in real time and automatically sets the optimum gains according to that value. This function
permits ease of gain adjustment of the servo amplifier.
(1) Auto tuning mode 1
The servo amplifier is factory-set to the auto tuning mode 1.
In this mode, the load inertia moment ratio of a machine is always estimated to set the optimum gains
automatically.
The following parameters are automatically adjusted in the auto tuning mode 1.
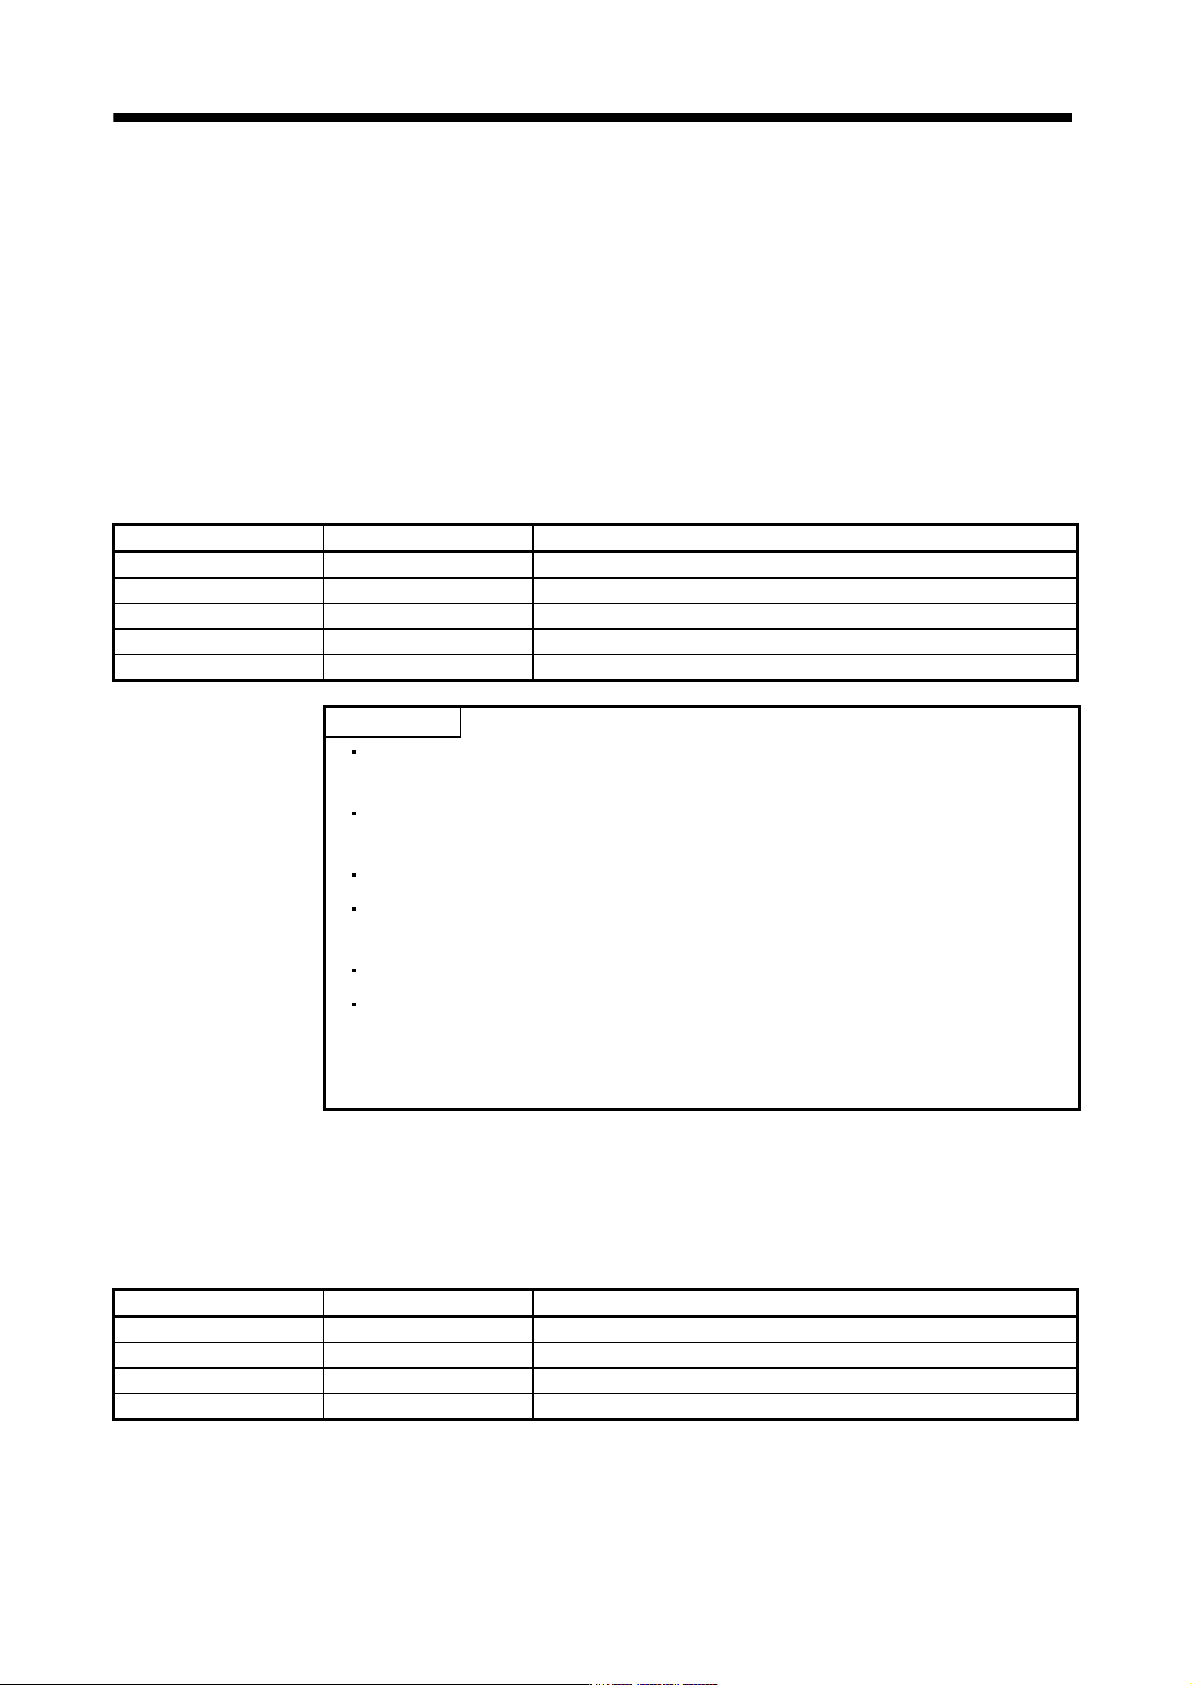
Parameter No. Abbreviation Name
PB06 GD2 Ratio of load inertia moment to servo motor inertia moment
PB07 PG1 Model loop gain
PB08 PG2 Position loop gain
PB09 VG2 Speed loop gain
PB10 VIC Speed integral compensation
POINT
The auto tuning mode 1 may not be performed properly if the following
conditions are not satisfied.
Time to reach 2000r/min is the acceleration/deceleration time constant of 5s or
less.
Speed is 150r/min or higher.
The ratio of load inertia moment to servo motor inertia moment is 100 times or
less.
The acceleration/deceleration torque is 10% or more of the rated torque.
Under operating conditions which will impose sudden disturbance torque
during acceleration/deceleration or on a machine which is extremely loose,
auto tuning may not function properly, either. In such cases, use the auto
tuning mode 2 or manual mode to make gain adjustment.
(2) Auto tuning mode 2
Use the auto tuning mode 2 when proper gain adjustment cannot be made by auto tuning mode 1. Since
the load inertia moment ratio is not estimated in this mode, set the value of a correct load inertia moment
ratio (parameter No.PB06).
The following parameters are automatically adjusted in the auto tuning mode 2.
Parameter No. Abbreviation Name
PB07 PG1 Model loop gain
PB08 PG2 Position loop gain
PB09 VG2 Speed loop gain
PB10 VIC Speed integral compensation
6 - 4
6. GENERAL GAIN ADJUSTMENT
6.2.2 Auto tuning mode operation
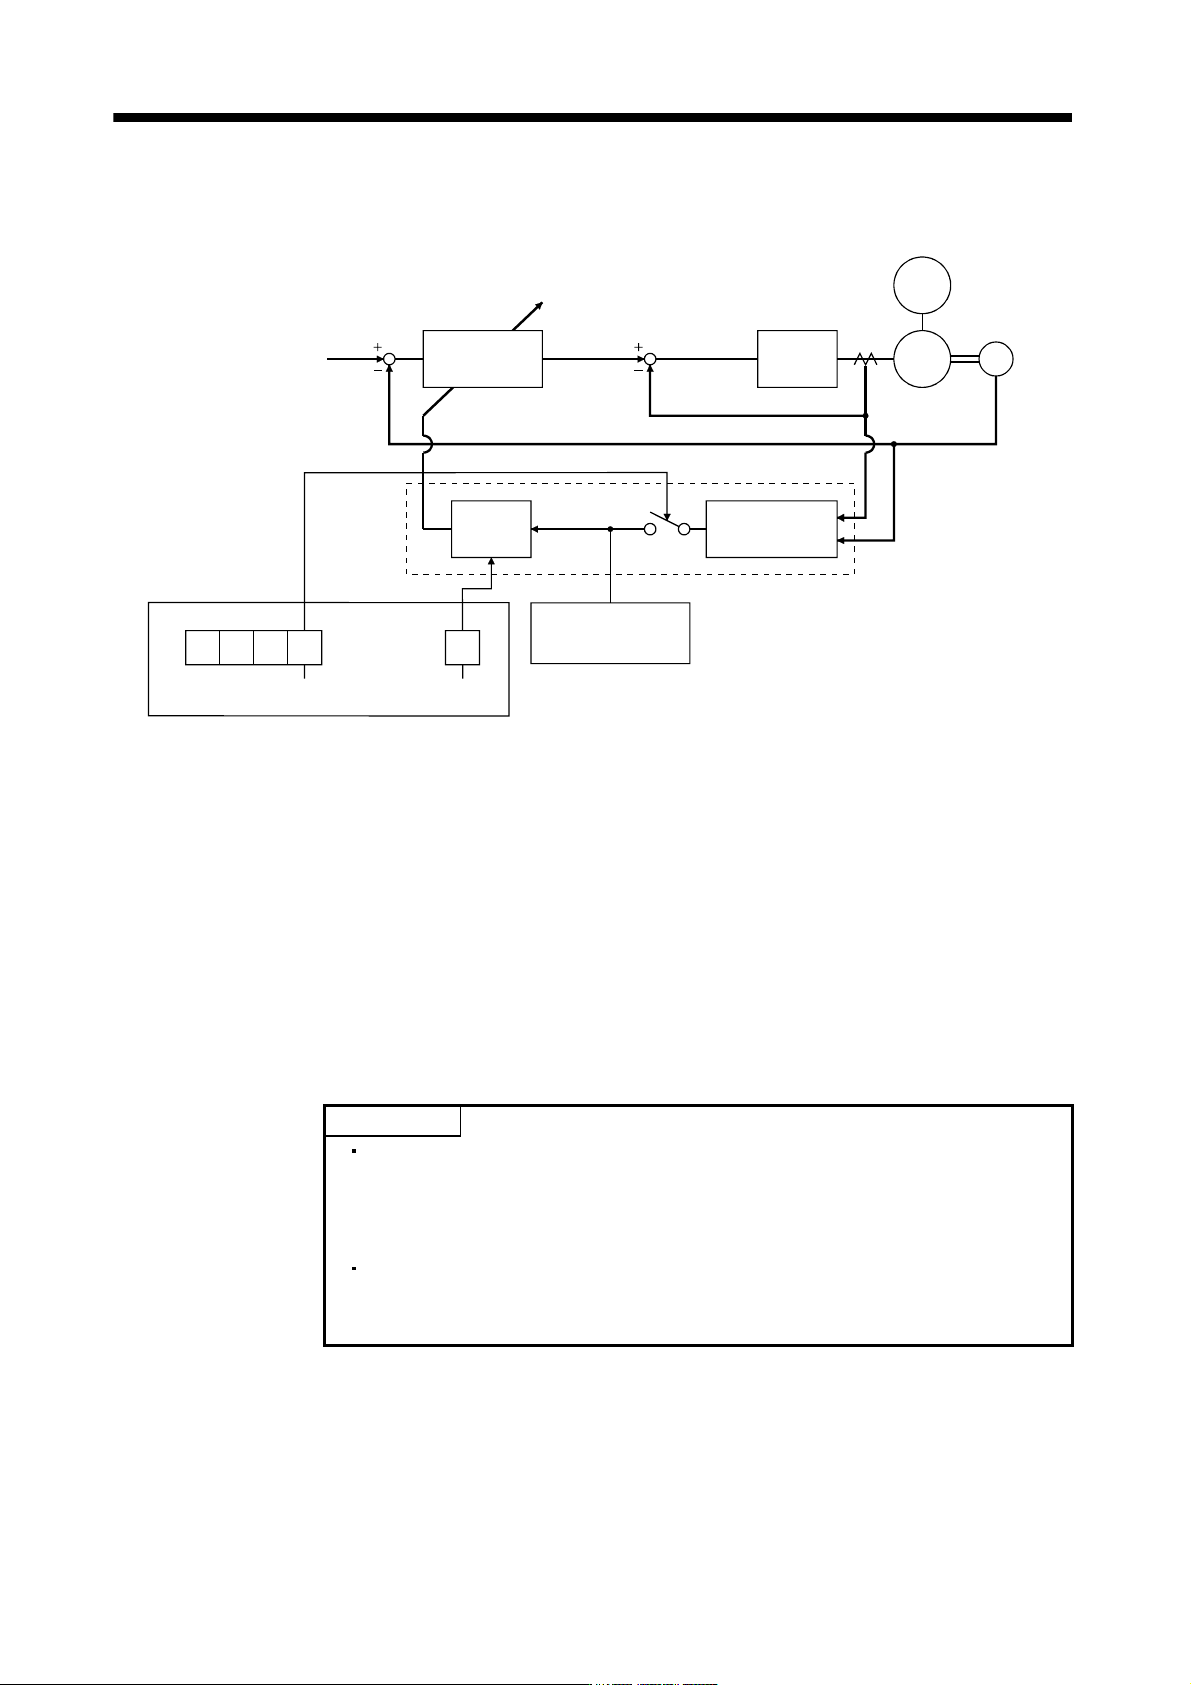
The block diagram of real-time auto tuning is shown below.
Servo
motor
Command
Automatic setting
Loop gains
PG1,VG1
PG2,VG2,VIC
Current
control
Current feedback
Load inertia
moment
Encoder
Position/speed
feedback
Real-time auto
tuning section
Speed feedback
Load inertia
moment ratio
estimation section
Gain
table
Parameter No.PB06
Load inertia moment
ratio estimation value
Set 0 or 1 to turn on.
Switch
Response
setting
Gain adjustment mode
selection
Parameter No.PA08
Parameter No.PA09
000
When a servo motor is accelerated/decelerated, the load inertia moment ratio estimation section always
estimates the load inertia moment ratio from the current and speed of the servo motor. The results of estimation
are written to parameter No.PB06 (the ratio of load inertia moment to servo motor). These results can be
confirmed on the status display screen of the MR Configurator.
If the value of the load inertia moment ratio is already known or if estimation cannot be made properly, chose
the "auto tuning mode 2" (parameter No.PA08: 0002) to stop the estimation of the load inertia moment ratio
(Switch in above diagram turned off), and set the load inertia moment ratio (parameter No.34) manually.
From the preset load inertia moment ratio (parameter No.PB06) value and response level (parameter
No.PA09), the optimum loop gains are automatically set on the basis of the internal gain tale.
The auto tuning results are saved in the EEP-ROM of the servo amplifier every 60 minutes since power-on. At
power-on, auto tuning is performed with the value of each loop gain saved in the EEP-ROM being used as an
initial value.
POINT
If sudden disturbance torque is imposed during operation, the estimation of
the inertia moment ratio may malfunction temporarily. In such a case, choose
the "auto tuning mode 2" (parameter No.PA08: 0002) and set the correct load
inertia moment ratio in parameter No.PB06.
When any of the auto tuning mode 1 and auto tuning mode settings is
changed to the manual mode 2 setting, the current loop gains and load inertia
moment ratio estimation value are saved in the EEP-ROM.
6 - 5
6. GENERAL GAIN ADJUSTMENT
6.2.3 Adjustment procedure by auto tuning
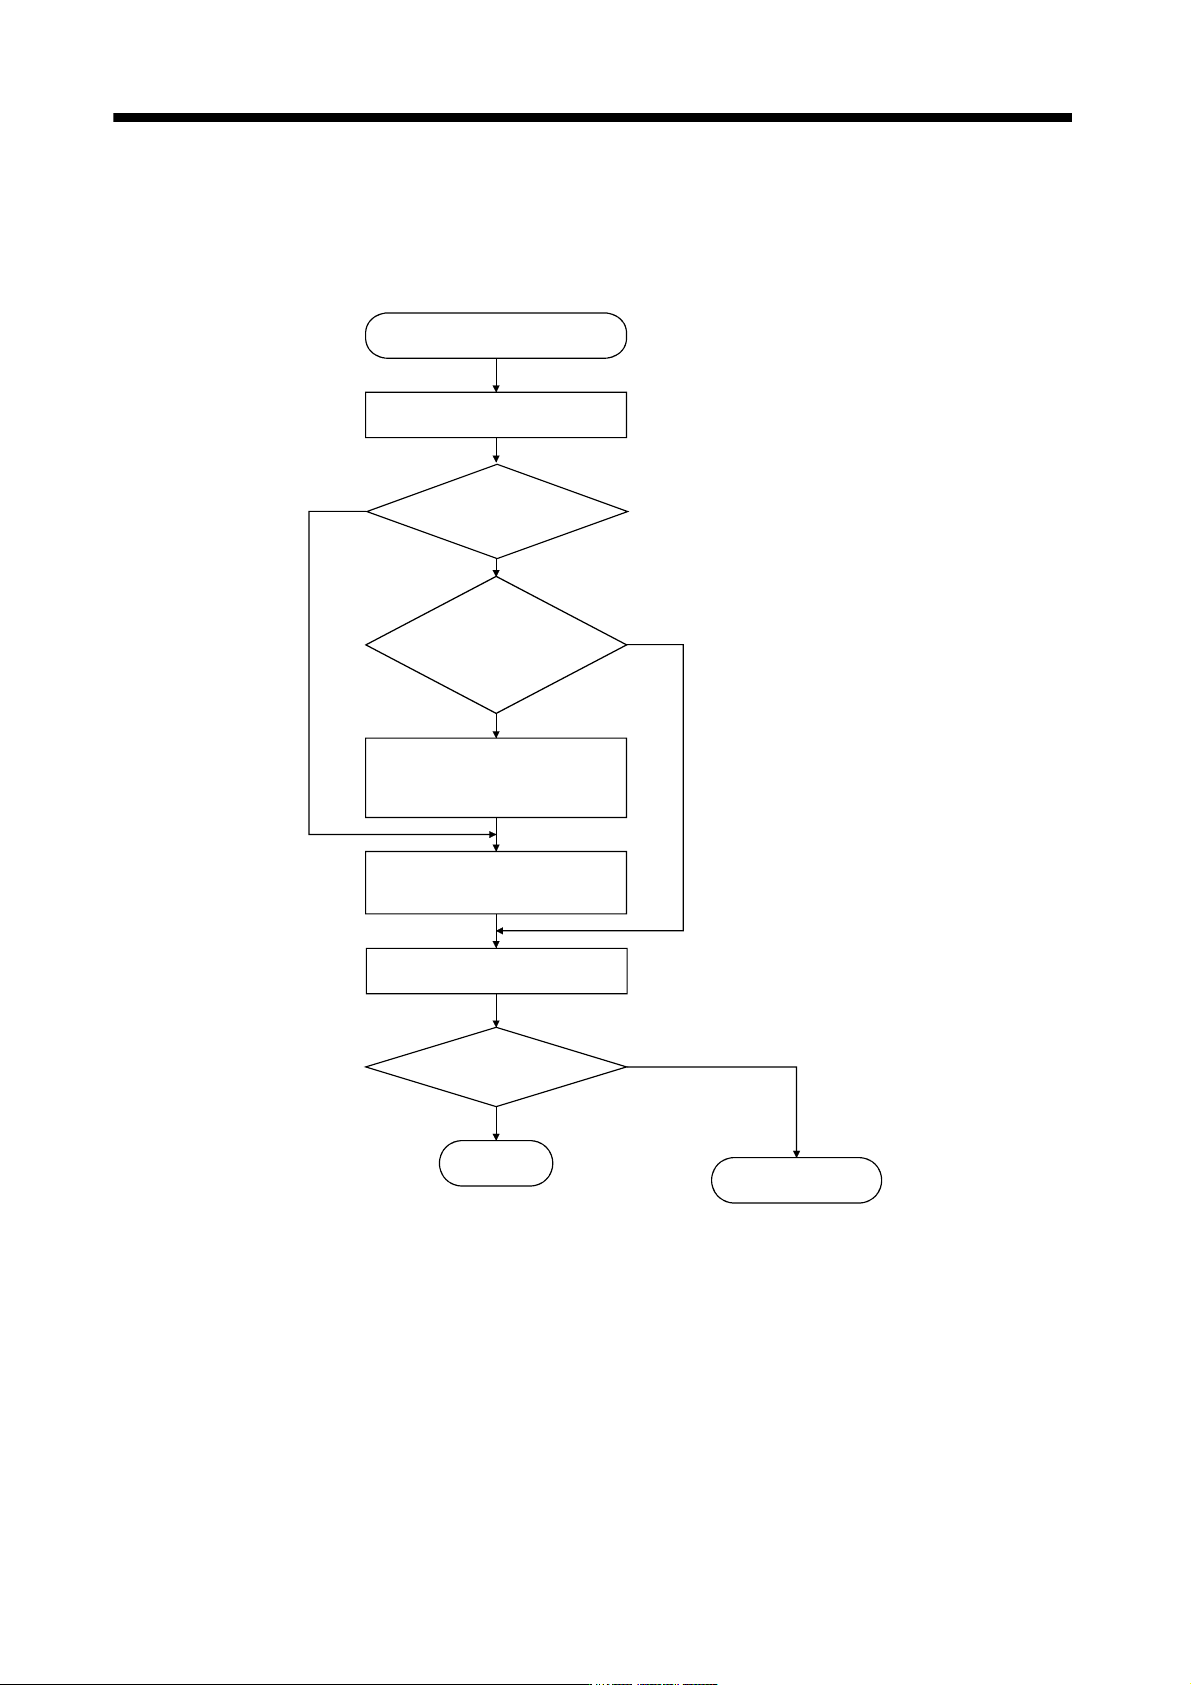
Since auto tuning is made valid before shipment from the factory, simply running the servo motor automatically
sets the optimum gains that match the machine. Merely changing the response level setting value as required
completes the adjustment. The adjustment procedure is as follows.
END
Yes
No
Yes
No
No
Yes
Auto tuning adjustment
Acceleration/deceleration repeated
Load inertia moment ratio
estimation value stable?
Auto tuning
conditions not satisfied.
(Estimation of load inertia
moment ratio is difficult)
Adjust response level setting
so that desired response is
achieved on vibration-free level.
Acceleration/deceleration repeated
Requested
performance satisfied?
To manual mode
Choose the auto tuning mode 2
(parameter No.PA08 : 0002) and
set the load inertia moment ratio
(parameter No.PB06) manually.