sh030051g.pdf - 第180页
8 - 7 8. TROUBLESHOOTING Display Name Definition Cause Action 51 Overload 2 Machine collision or the like caused max. For the time of the alarm occurrence, refer to the section 10.1. 1. Machine struck something. 1. Check…
8 - 6
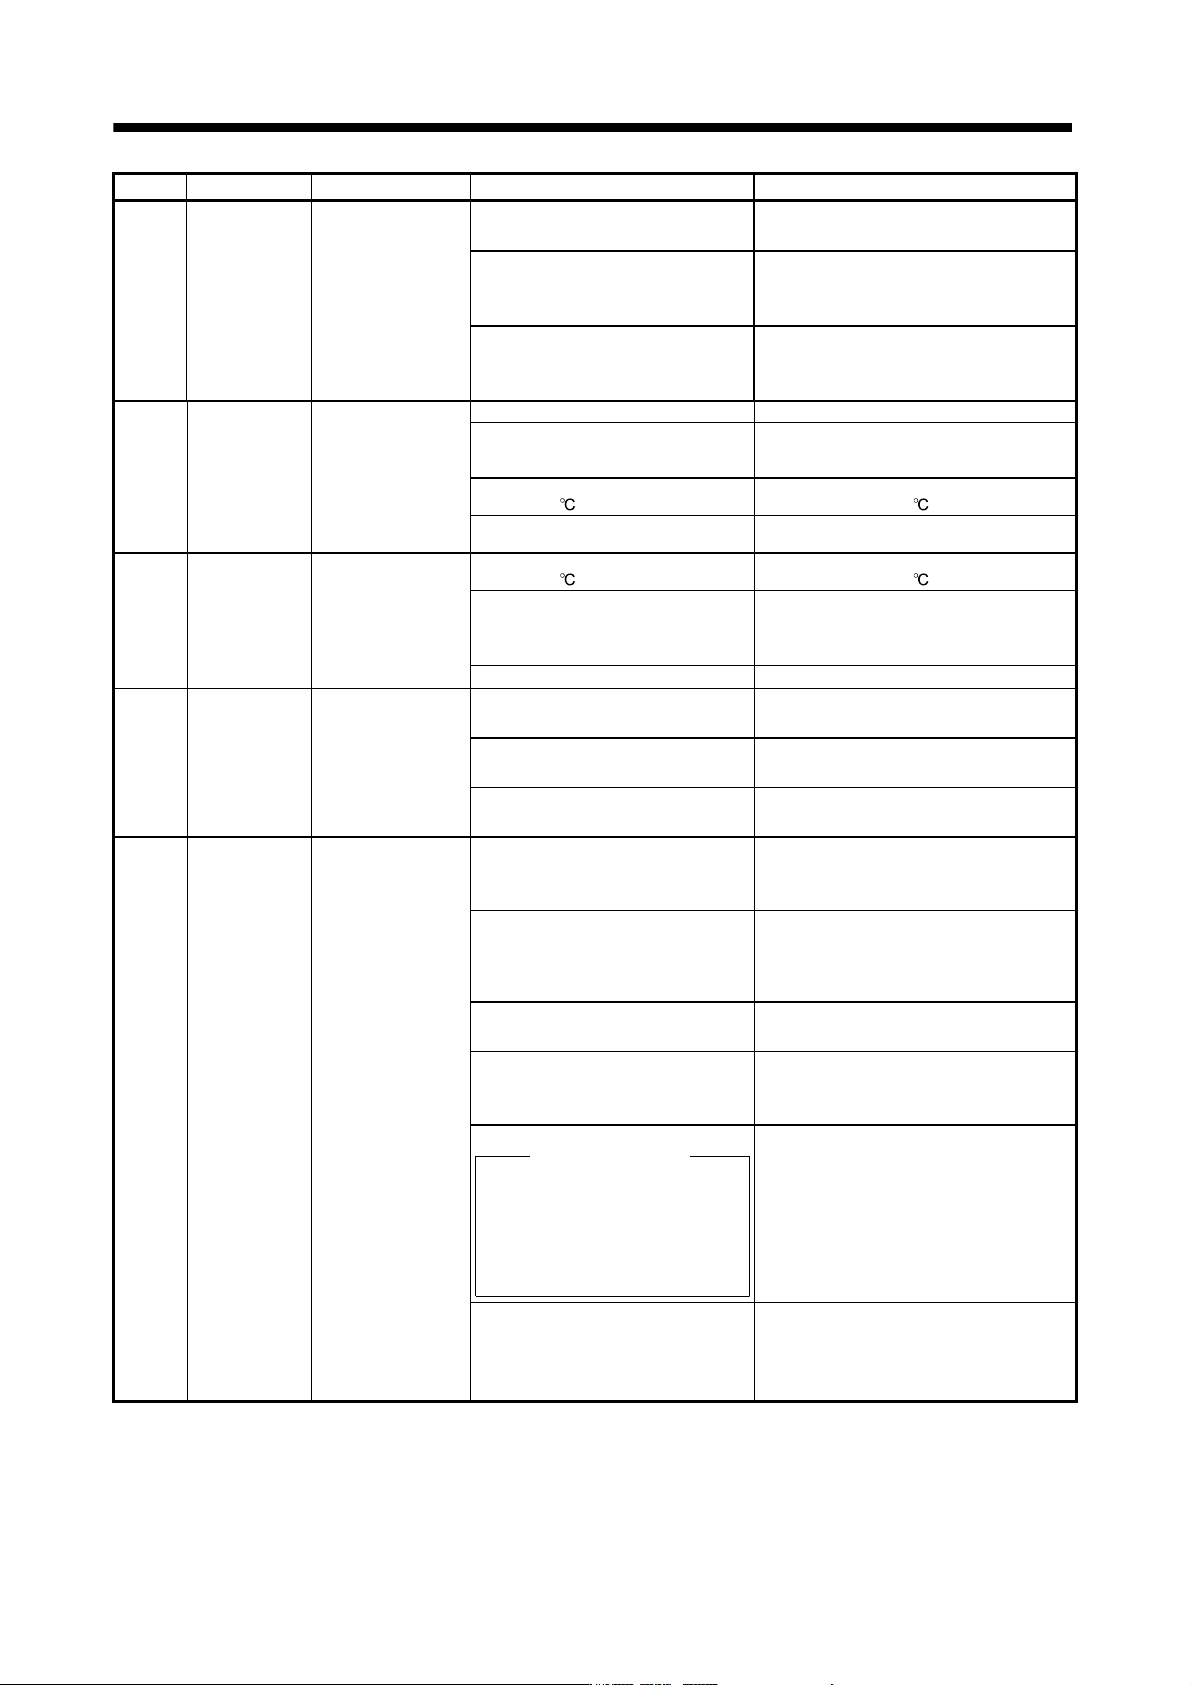
8. TROUBLESHOOTING
Display Name Definition Cause Action
37 Parameter error Parameter setting is
wrong.
1. Servo amplifier fault caused the
parameter setting to be rewritten.
Change the servo amplifier.
2. There is a parameter whose value
was set to outside the setting range
by the controller.
Change the parameter value to within the
setting range.
3. The number of write times to EEP-
ROM exceeded 100,000 due to
parameter write, etc.
Change the servo amplifier.
45 Main circuit
device overheat
Main circuit device
overheat
1. Servo amplifier faulty. Change the servo amplifier.
2. The power supply was turned on
and off continuously by overloaded
status.
The drive method is reviewed.
3. Ambient temperature of servo motor
is over 55
.
Check environment so that ambient
temperature is 0 to 55 .
4. Used beyond the specifications of
close mounting.
Use within the range of specifications.
46 Servo motor
overheat
Servo motor
temperature rise
actuated the thermal
sensor.
1. Ambient temperature of servo motor
is over 40
.
Check environment so that ambient
temperature is 0 to 40 .
2. Servo motor is overloaded. 1. Reduce load.
2. Check operation pattern.
3. Use servo motor that provides larger
output.
3. Thermal sensor in encoder is faulty. Change the servo motor.
47 Cooling fan
error
The cooling fan of
the servo amplifier
stopped, or its speed
decreased to or
below the alarm
level.
1. Cooling fan life expiration (Refer to
section 2.5.)
Change the cooling fan of the servo
amplifier.
2. Foreign matter caught in the cooling
fan stopped rotation.
Remove the foreign matter.
3. The power supply of the cooling fan
failed.
Change the servo amplifier.
50 Overload 1 Load exceeded
overload protection
characteristic of
servo amplifier.
1. Servo amplifier is used in excess
of its continuous output current.
1. Reduce load.
2. Check operation pattern.
3. Use servo motor that provides larger
output.
2. Servo system is instable and
hunting.
1. Repeat acceleration/
deceleration to execute auto tuning.
2. Change the auto tuning response setting.
3. Set auto tuning to OFF and make gain
adjustment manually.
3. Machine struck something. 1. Check operation pattern.
2. Install limit switches.
4. Wrong connection of servo motor.
Servo amplifier's output terminals U,
V, W do not match servo motor's
input terminals U, V, W.
Connect correctly.
5. Encoder faulty.
Checking method
When the servo motor shaft is
rotated with the servo off, the
cumulative feedback pulses do not
vary in proportion to the rotary angle
of the shaft but the indication skips
or returns midway.
Change the servo motor.
6. After Overload 2 (51) occurred, turn
OFF/ON the power supply to clear
the alarm. Then the overload
operation is repeated.
1. Reduce load.
2. Check operation pattern.
3. Use servo motor that provides larger
output.
8 - 7
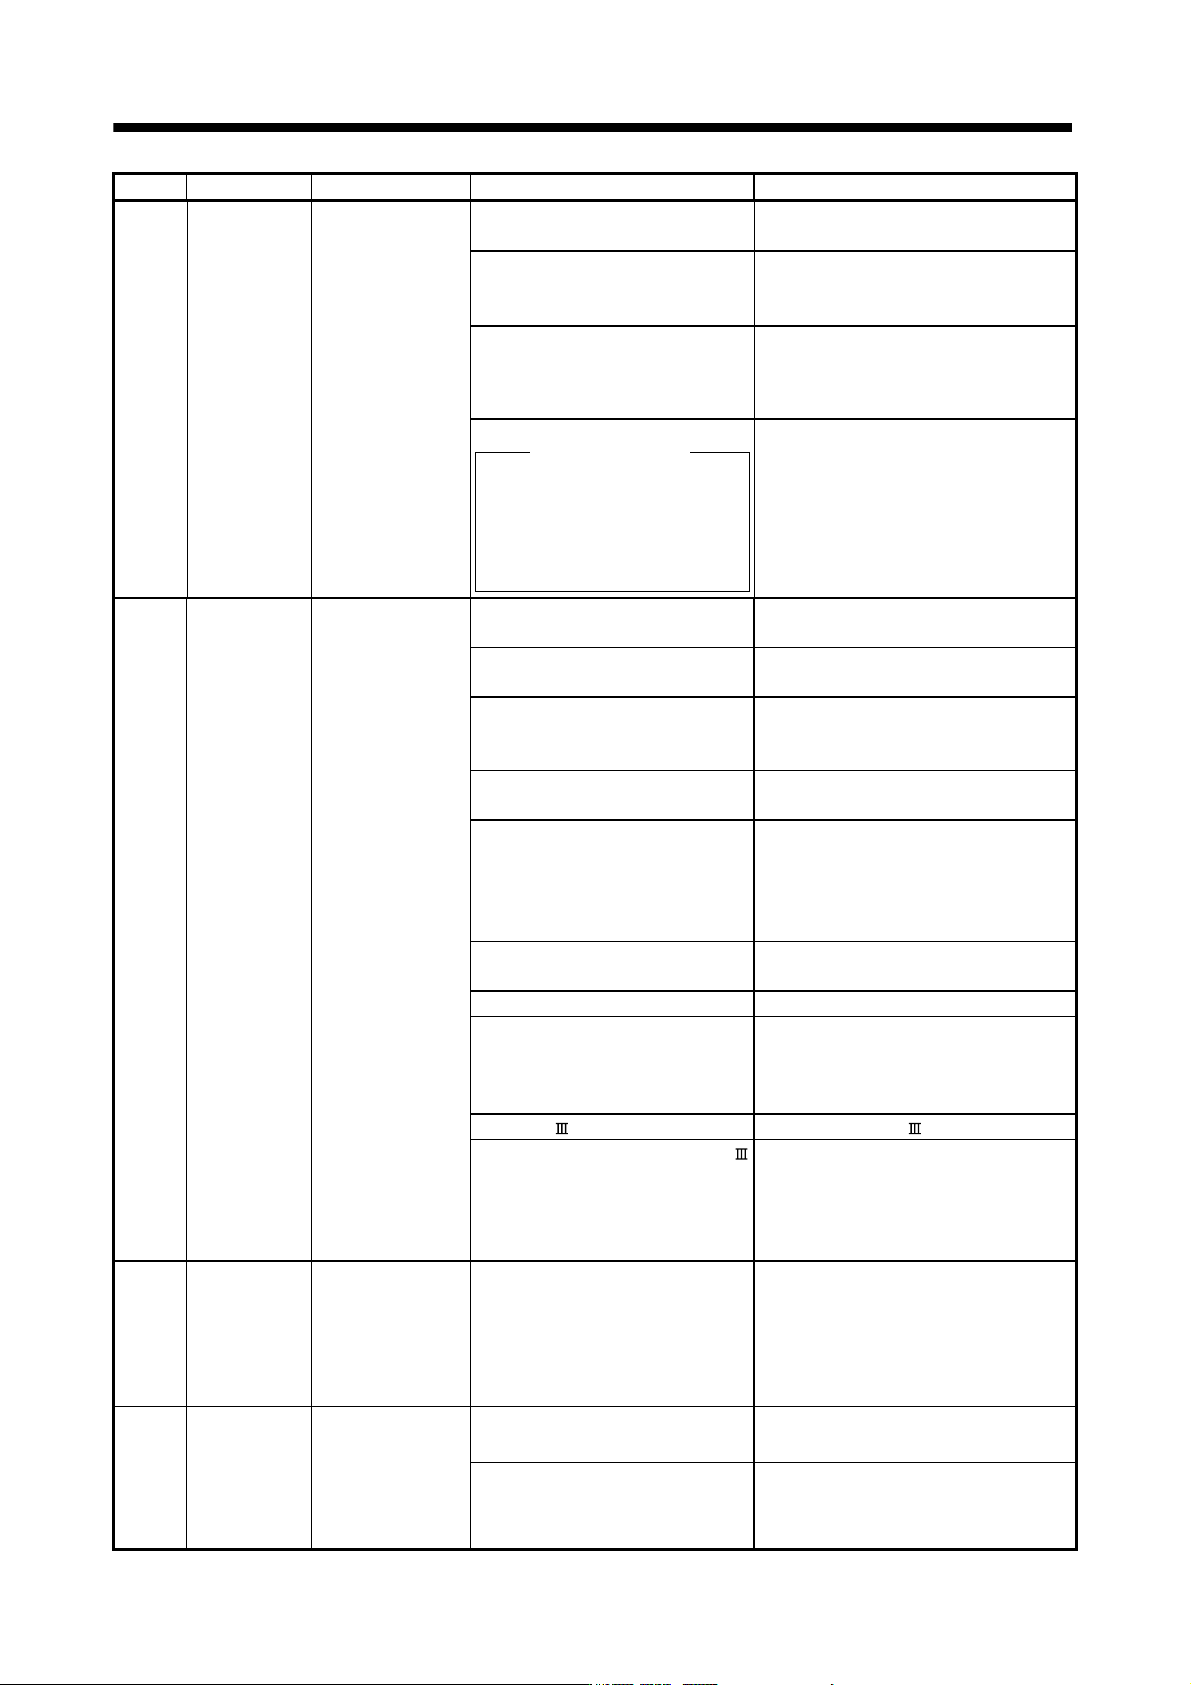
8. TROUBLESHOOTING
Display Name Definition Cause Action
51 Overload 2 Machine collision or
the like caused max.
For the time of the
alarm occurrence,
refer to the section
10.1.
1. Machine struck something. 1. Check operation pattern.
2. Install limit switches.
2. Wrong connection of servo motor.
Servo amplifier's output terminals U,
V, W do not match servo motor's
input terminals U, V, W.
Connect correctly.
3. Servo system is instable and
hunting.
1. Repeat acceleration/deceleration to
execute auto tuning.
2. Change the auto tuning response setting.
3. Set auto tuning to OFF and make gain
adjustment manually.
4. Encoder faulty.
Checking method
When the servo motor shaft is
rotated with the servo off, the
cumulative feedback pulses do not
vary in proportion to the rotary angle
of the shaft but the indication skips
or returns midway.
Change the servo motor.
52 Error excessive The deviation
between the model
position and the
actual servo motor
position exceeds the
parameter No.PC01
setting value (initial
value: 3 revolutions).
1. Acceleration/deceleration time
constant is too small.
Increase the acceleration/deceleration time
constant.
2. Torque limit value set with controller
is too small.
Increase the torque limit value.
3. Motor cannot be started due to
torque shortage caused by power
supply voltage drop.
1. Check the power supply capacity.
2. Use servo motor which provides larger
output.
4. Position loop gain 1 (parameter
No.PB08) value is small.
Increase set value and adjust to ensure
proper operation.
5. Servo motor shaft was rotated by
external force.
1. When torque is limited, increase the limit
value.
2. Reduce load.
3. Use servo motor that provides larger
output.
6. Machine struck something. 1. Check operation pattern.
2. Install limit switches.
7. Encoder faulty Change the servo motor.
8. Wrong connection of servo motor.
Servo amplifier's output terminals U,
V, W do not match servo motor's
input terminals U, V, W.
Connect correctly.
9. SSCNET cable fault Change the SSCNET cable.
10. Optical characteristic of SSCNET
cable deteriorated because vinyl
tape and/or wire sheath, which
contains migrating plasticizer,
adhered to the cable.
Remove the vinyl tape and/or wire sheath,
which contains migrating plasticizer, and
exchange the cable.
8A USB
communication
time-out error
Communication with
MR Configurator in
test operation mode
stopped for longer
than the specified
time.
1. USB cable breakage. Change the USB cable.
8E USB
communication
error
Serial communication
error occurred
between servo
amplifier and
communication
device (e.g. personal
computer).
1. USB cable fault
(Open cable or short circuit)
Change the USB cable.
2. Communication device (e.g.
personal computer) faulty
Change the communication device (e.g.
personal computer).
8 - 8
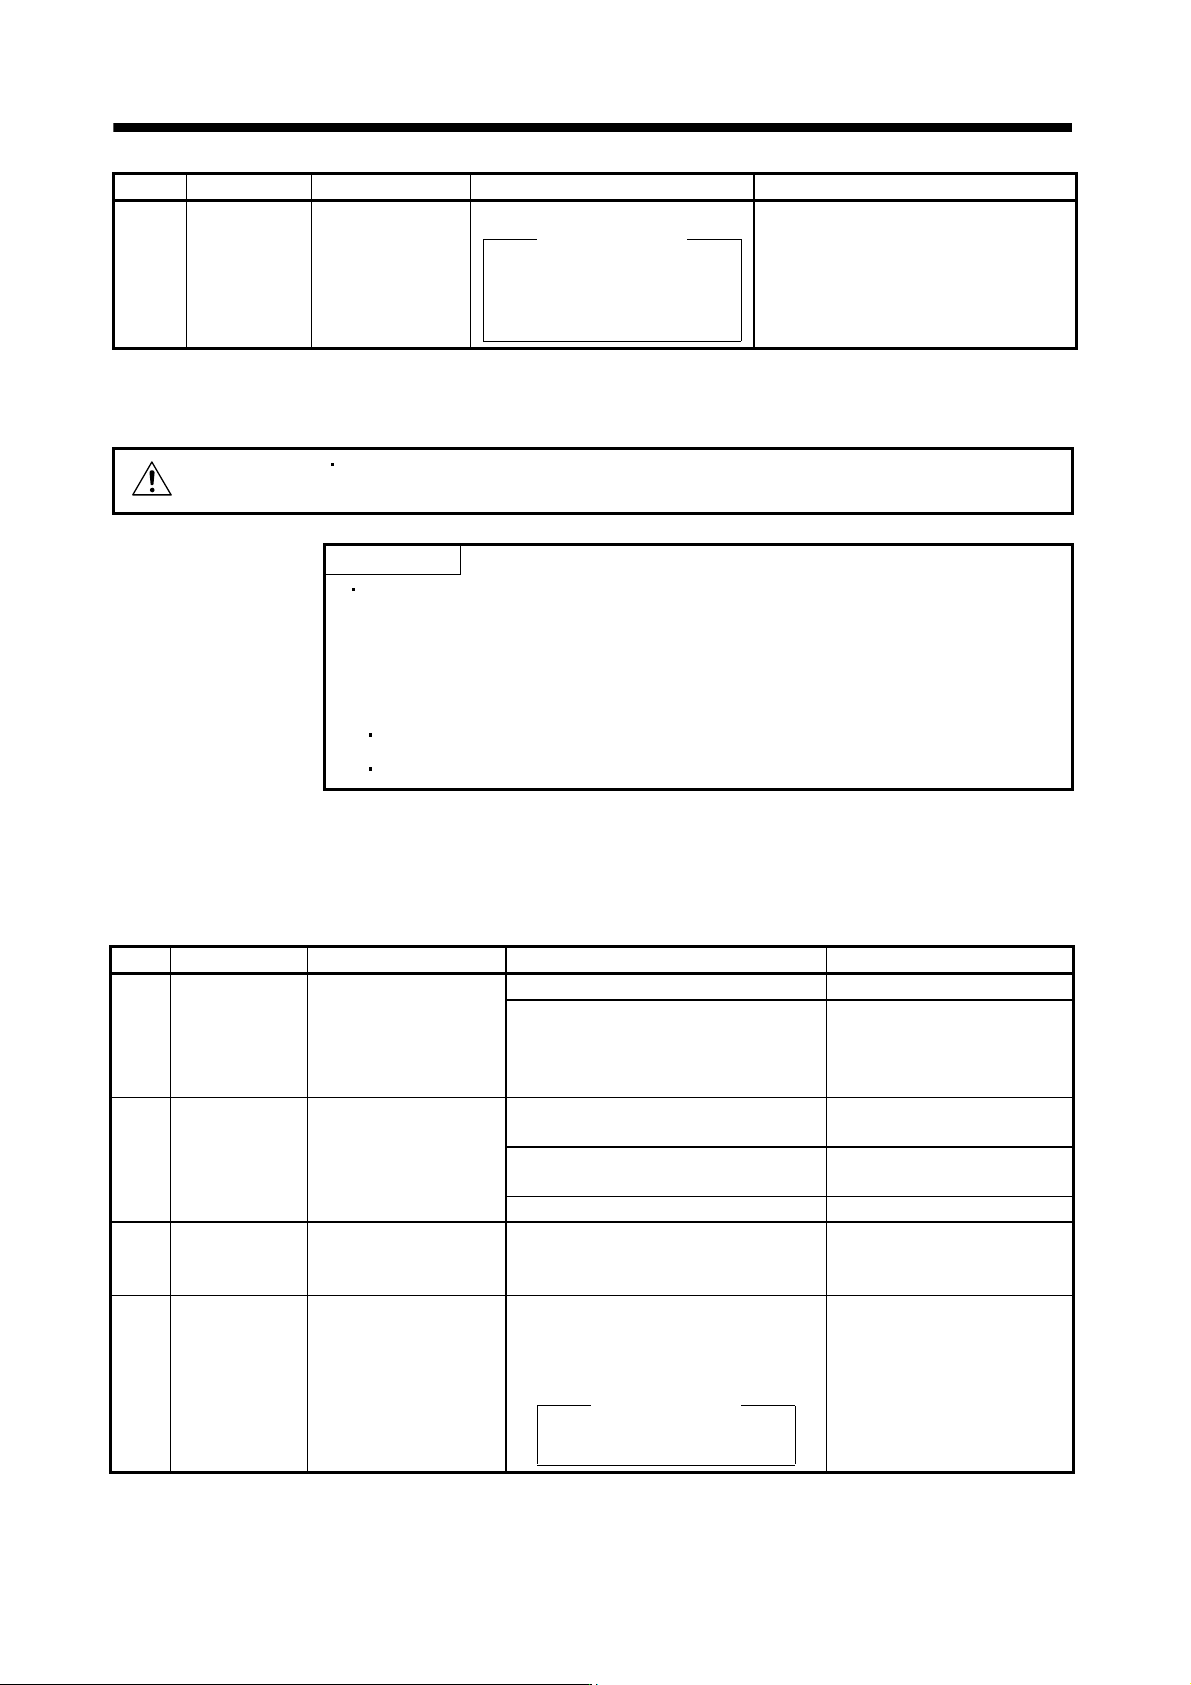
8. TROUBLESHOOTING
Display Name Definition Cause Action
(Note)
888
Watchdog CPU, parts faulty Fault of parts in servo amplifier
Checking method
Alarm (888) occurs if power is
switched on after disconnection of
all cables but the control circuit
power supply cable.
Change the servo amplifier.
Note. At power-on, "888" appears instantaneously, but it is not an error.
8.3 Remedies for warnings
CAUTION
If an absolute position counter warning (E3) occurred, always make home position
setting again. Not doing so may cause unexpected operation.
POINT
When any of the following alarms has occurred, do not resume operation by
switching power of the servo amplifier OFF/ON repeatedly. The servo amplifier
and servo motor may become faulty. If the power of the servo amplifier is
switched OFF/ON during the alarms, allow more than 30 minutes for cooling
before resuming operation.
Excessive regenerative warning (E0)
Overload warning 1 (E1)
If E6, E7 or E9 occurs, the servo off status is established. If any other warning occurs, operation can be
continued but an alarm may take place or proper operation may not be performed.
Remove the cause of warning according to this section. Use the MR Configurator to refer to a factor of warning
occurrence.
Display Name Definition Cause Action
92 Battery cable
disconnection
warning
Absolute position detection
system battery voltage is
low.
1. Battery cable is open. Repair cable or changed.
2. Battery voltage supplied from the servo
amplifier to the encoder fell to about 3V or
less.
(Detected with the encoder)
Change the battery.
96 Home position
setting warning
Home position setting
could not be made.
1. Droop pulses remaining are greater than
the in-position range setting.
Remove the cause of droop pulse
occurrence
2. Command pulse entered after clearing of
droop pulses.
Do not enter command pulse
after clearing of droop pulses.
3. Creep speed high. Reduce creep speed.
9F Battery warning Voltage of battery for
absolute position detection
system reduced.
Battery voltage fell to 3.2V or less.
(Detected with the servo amplifier)
Change the battery.
E0 Excessive
regeneration
warning
There is a possibility that
regenerative power may
exceed permissible
regenerative power of
built-in regenerative
resistor or regenerative
option.
Regenerative power increased to 85% or
more of permissible regenerative power of
built-in regenerative resistor or regenerative
option.
Checking method
Call the status display and check
regenerative load ratio.
1. Reduce frequency of
positioning.
2. Change the regenerative
option for the one with larger
capacity.
3. Reduce load.