sh030051g.pdf - 第116页
4 - 9 4. STARTUP 2) Operation method Operation Screen control Forward rotation start Click the "For ward" button. Reverse rotation start Click the "Reverse" button. Pause Click the "Pause" b…
4 - 8
4. STARTUP
4.5 Test operation mode
CAUTION
The test operation mode is designed for servo operation confirmation and not for
machine operation confirmation. Do not use this mode with the machine. Always
use the servo motor alone.
If an operation fault occurred, use the forced stop (EM1) to make a stop.
POINT
The content described in this section indicates the environment that servo
amplifier and personal computer are directly connected.
By using a personal computer and the MR Configurator, you can execute jog operation, positioning operation,
DO forced output program operation without connecting the servo system controller.
4.5.1 Test operation mode in MR Configurator
(1) Test operation mode
(a) Jog operation
Jog operation can be performed without using the servo system controller. Use this operation with the
forced stop reset. This operation may be used independently of whether the servo is on or off and
whether the servo system controller is connected or not.
Exercise control on the jog operation screen of the MR Configurator.
1) Operation pattern
Item Initial value Setting range
Speed [r/min] 200 0 to max. speed
Acceleration/deceleration time constant [ms] 1000 0 to 50000
2) Operation method
Operation Screen control
Forward rotation start Click the "Forward" button.
Reverse rotation start Click the "Reverse" button.
Stop Click the "Stop" button.
(b) Positioning operation
Positioning operation can be performed without using the servo system controller. Use this operation
with the forced stop reset. This operation may be used independently of whether the servo is on or off
and whether the servo system controller is connected or not.
Exercise control on the positioning operation screen of the MR Configurator.
1) Operation pattern
Item Initial value Setting range
Travel [pulse] 4000 0 to 99999999
Speed [r/min] 200 0 to max. speed
Acceleration/deceleration time constant [ms] 1000 0 to 50000
4 - 9
4. STARTUP
2) Operation method
Operation Screen control
Forward rotation start Click the "Forward" button.
Reverse rotation start Click the "Reverse" button.
Pause Click the "Pause" button.
(c) Program operation
Positioning operation can be performed in two or more operation patterns combined, without using the
servo system controller. Use this operation with the forced stop reset. This operation may be used
independently of whether the servo is on or off and whether the servo system controller is connected or
not.
Exercise control on the programmed operation screen of the MR Configurator. For full information, refer
to the MR Configurator Installation Guide.
Operation Screen control
Start Click the "Start" button.
Stop Click the "Reset" button.
(d) Output signal (DO) forced output
Output signals can be switched on/off forcibly independently of the servo status. Use this function for
output signal wiring check, etc.
Exercise control on the DO forced output screen of the MR Configurator.
(2) Operation procedure
(a) Jog operation, positioning operation, program operation, DO forced output.
1) Switch power off.
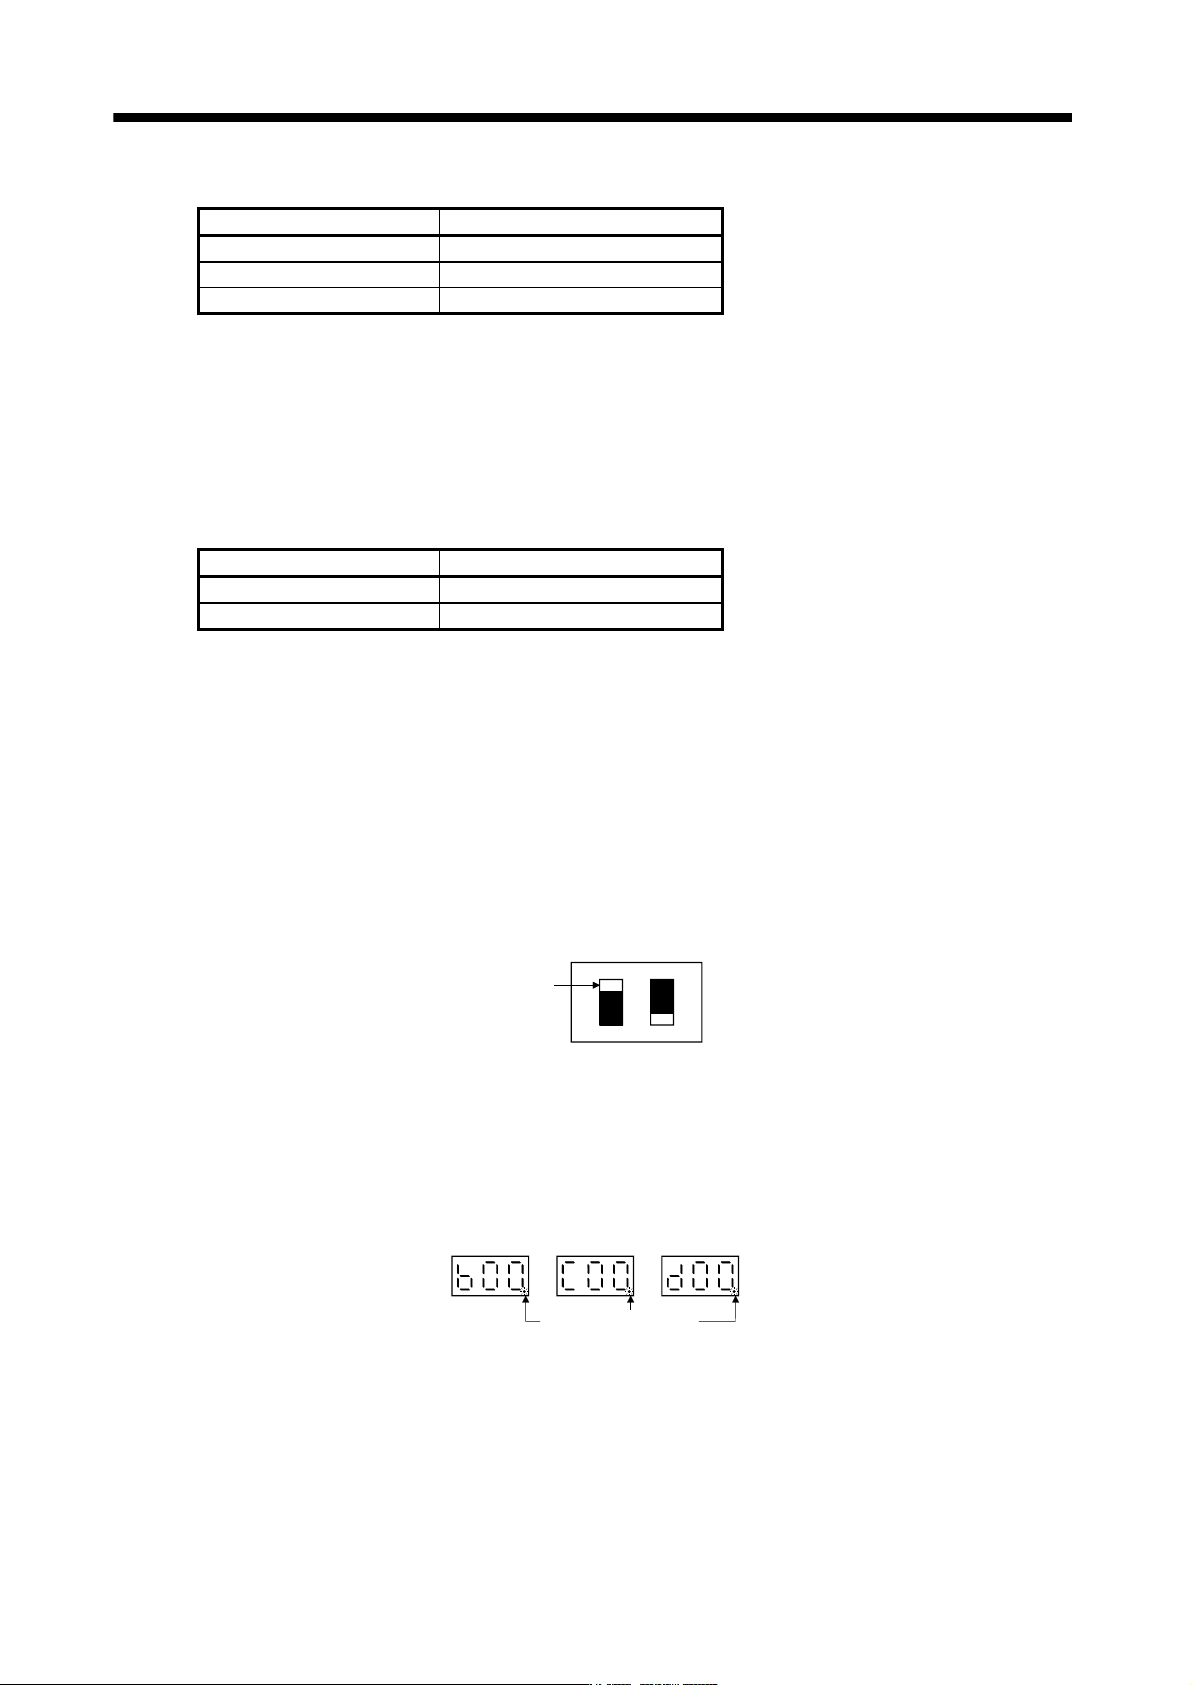
2) Set SW2-1 to "UP".
SW2
DOWN
UP
12
Set SW2-1 to "UP"
When SW1 and SW2-1 is set to the axis number and operation is performed by the servo system
controller, the test operation mode screen is displayed on the personal computer, but no function is
performed.
3) Switch servo amplifier power on.
When initialization is over, the display shows the following screen.
Decimal point flickers.
4) Perform operation with the personal computer.
4 - 10
4. STARTUP
4.5.2 Motorless operation in controller
POINT
Use motor-less operation which is available by making the servo system
controller parameter setting.
Motorless operation is done while connected with the servo system controller.
(1) Motorless operation
Without connecting the servo motor, output signals or status displays can be provided in response to the
servo system controller commands as if the servo motor is actually running. This operation may be used to
check the servo system controller sequence. Use this operation with the forced stop reset. Use this
operation with the servo amplifier connected to the servo system controller.
For stopping the motorless operation, set the selection of motorless operation to [Invalid] in servo parameter
setting of servo system controller. Motorless operation will be invalid condition after switching on power
supply next time.
(a) Load conditions
Load item Condition
Load torque 0
Load inertia moment ratio Same as servo motor inertia moment
(b) Alarms
The following alarms and warning do not occur. However, the other alarms and warnings occur as
when the servo motor is connected.
Encoder error 1 (16)
Encoder error 2 (20)
Absolute position erasure (25)
Battery cable disconnection warning (92)
Battery warning (9F)
Converter error (1B) (Note 1)
Converter warning (9C) (Note 1)
Main circuit off warning (E9) (Note 2)
Note 1. Alarm and warning for the drive units of 30kW or more. For details, refer to section 13.6.2.
2. Main circuit off warning (E9) does not occur only when the forced stop of the converter unit is enabled as the cause
of occurrence with the drive unit of 30kW or more. Main circuit of warning, otherwise, occurs when the cause of
occurrence with the drive unit of 30kW or more is other than above, or with the servo amplifier of 22 kW or less.
(2) Operating procedure
1) Switch off servo amplifier
2) Set parameter No.PC05 to "1", change test operation mode switch (SW2-1) to normal condition side
"Down", and then turn on the power supply.
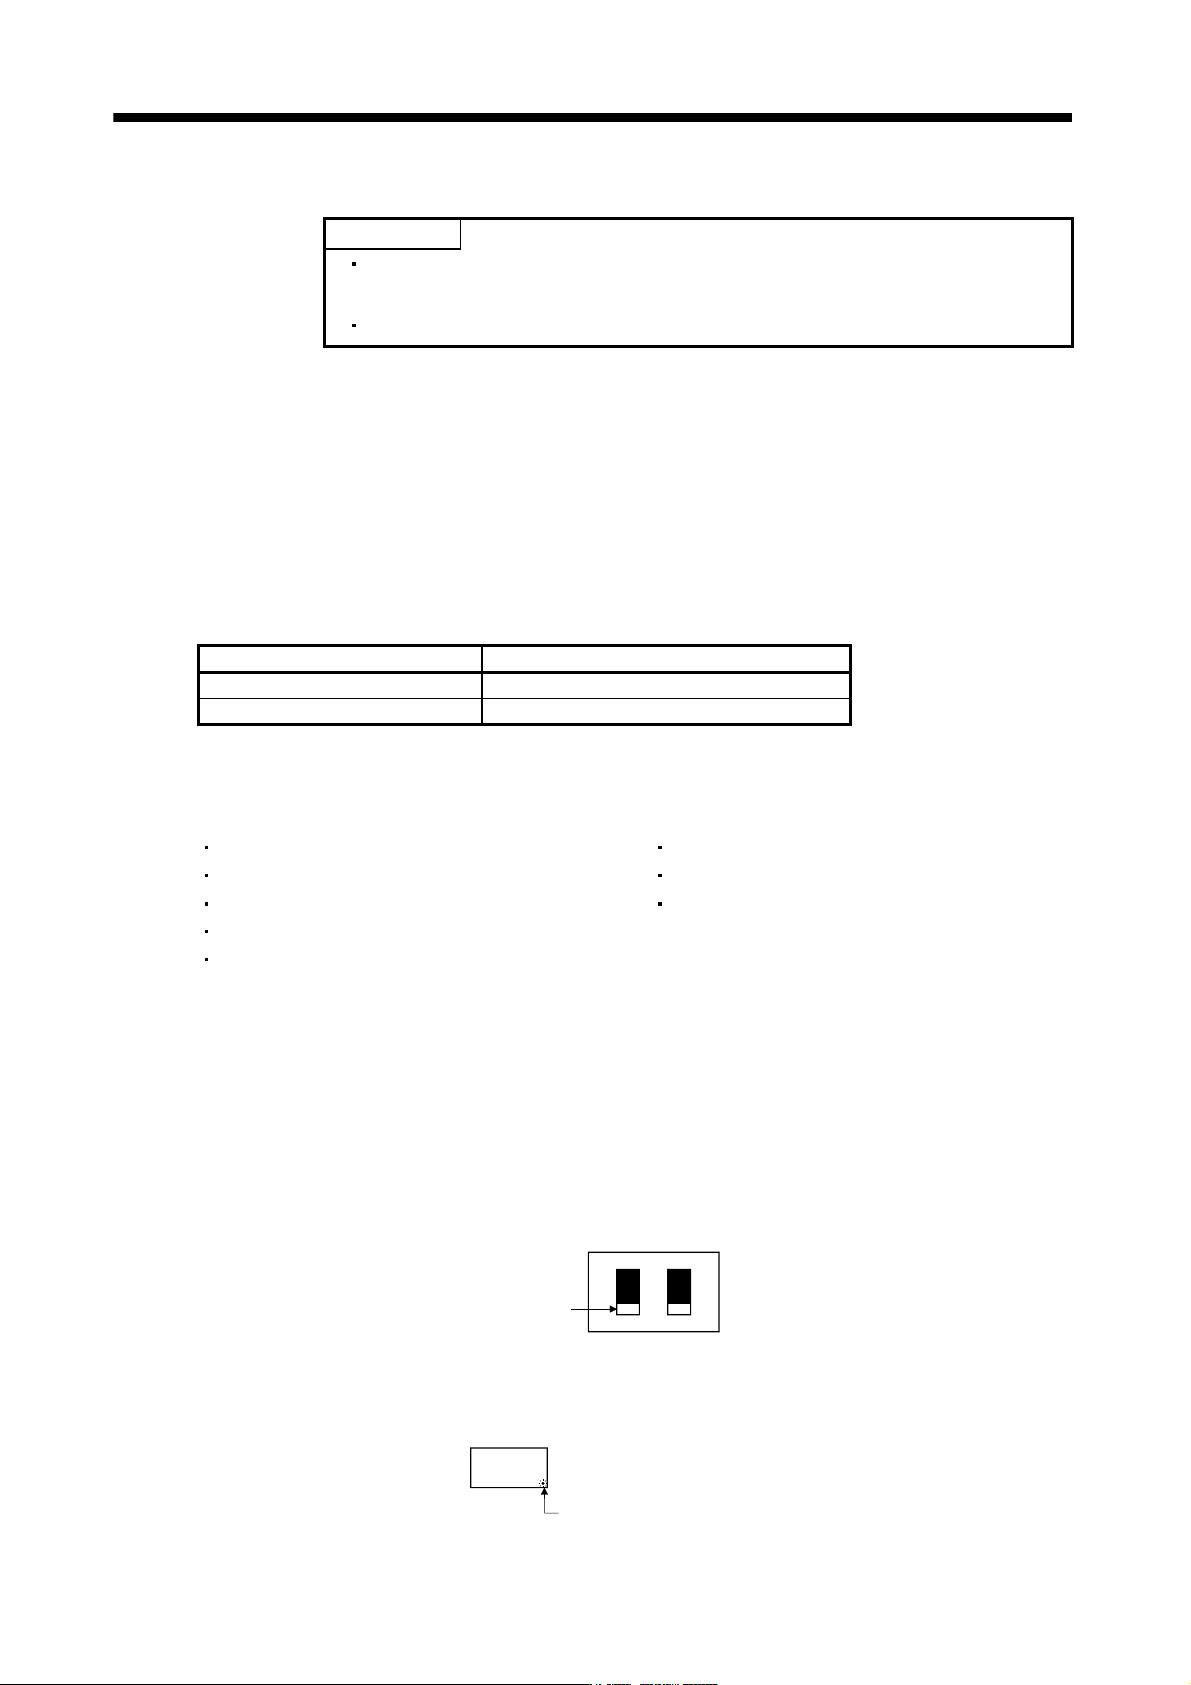
SW2
DOWN
UP
12
Set SW2-1 to "DOWN"
3) Perform motor-less operation with the personal computer.
The display shows the following screen.
Decimal point flickers.