sh030051g.pdf - 第368页
13 - 67 13. SERVO AMPLIFIERS WI TH A LARGE CAPACITY ( 30k TO 55kW ) 13.8 Characteristics 13.8.1 Overload protection characteri stics An electronic thermal relay is built in the converter unit and drive unit to protect th…
13 - 66
13. SERVO AMPLIFIERS WITH A LARGE CAPACITY
(
30k TO 55kW
)
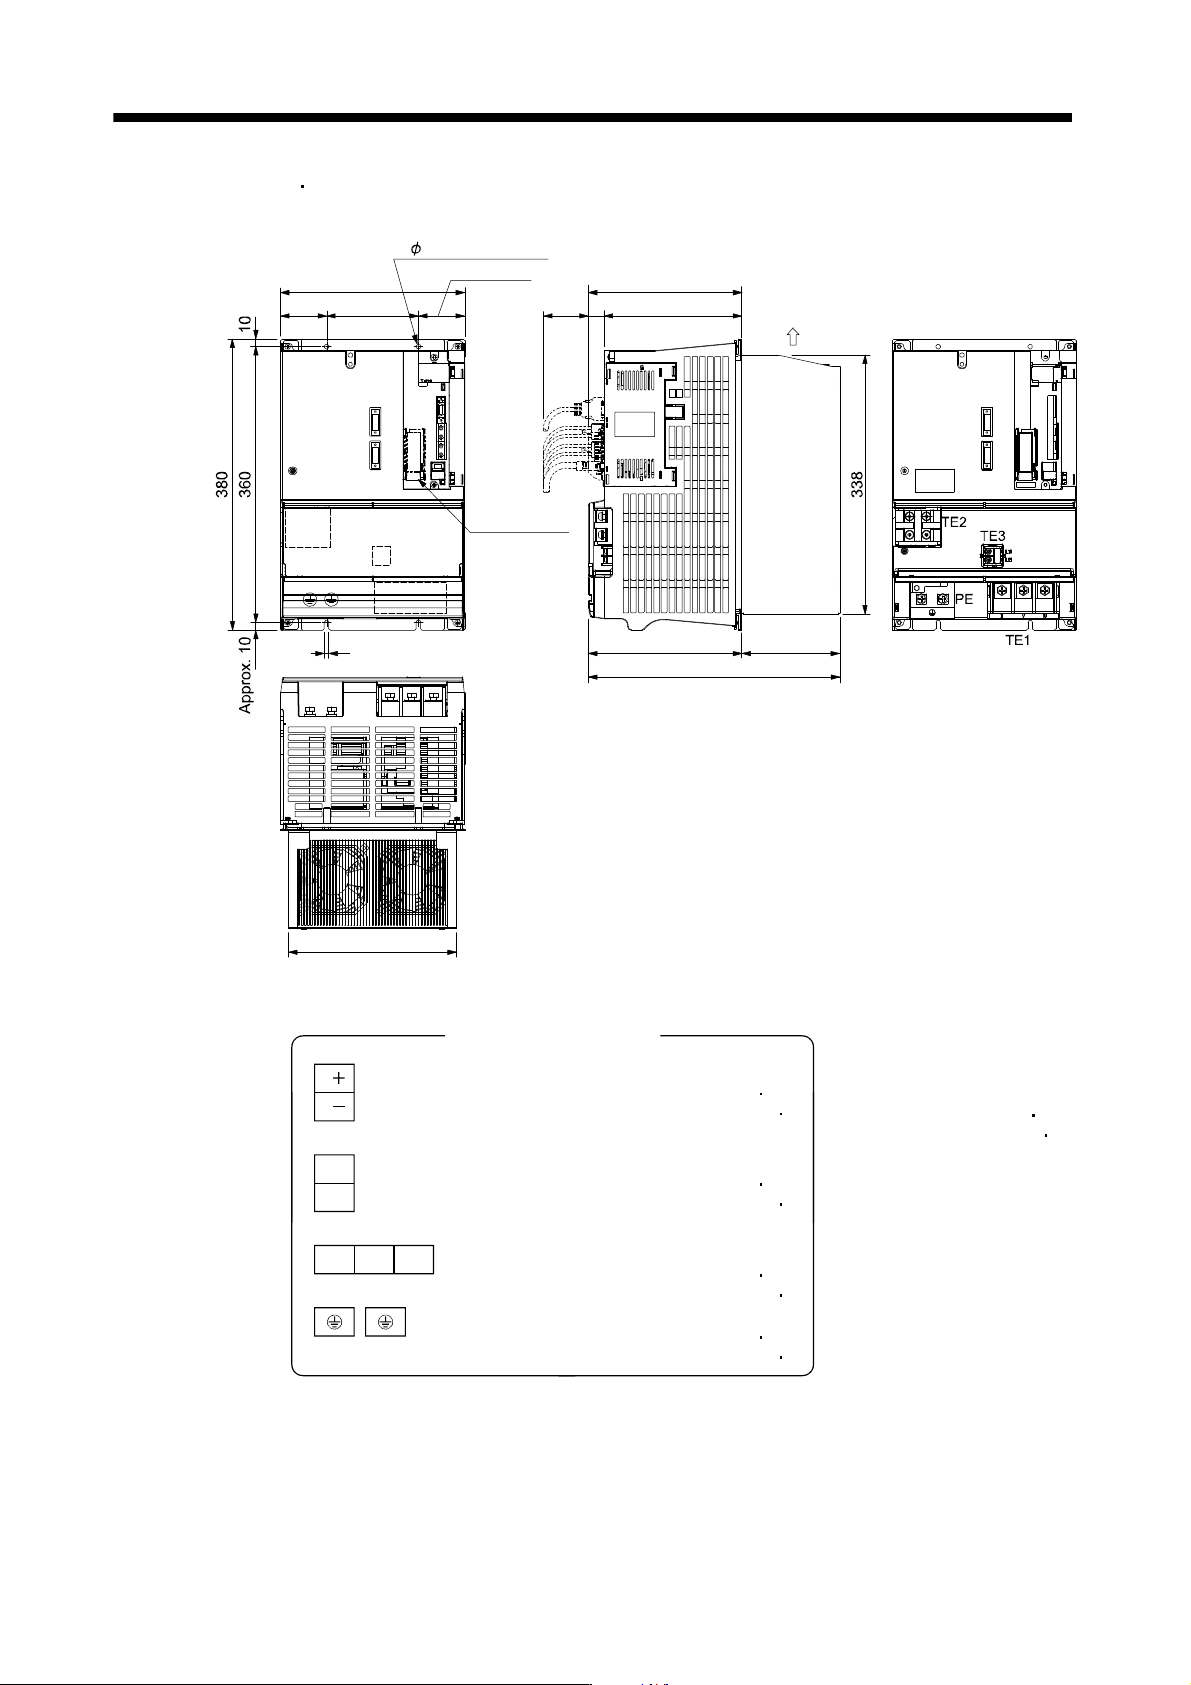
(2) MR-J3-DU30KB4
MR-J3-DU37KB4
[Unit: mm]
240
Approx. 200
Approx. 200
328
128
180
12060
6
219.2
TE2
TE3
TE1
For mounting
MR-J3BAT
Approx. 60
Approx. 80
2- 6 Installation hole
Cooling fan
wind direction
Terminal block layout
(Terminal cover removed)
Mass: 18[kg] (39.7[lb])
TE1
TE2
TE3
L11
L
21
PE
Terminal block signal layout
Terminal block screw: M6
Tightening torque: 3.0 [N m]
(26.6 [lb in])
L
L
Terminal block screw: M4
Tightening torque: 1.2 [N m]
(10.6 [lb in])
Terminal block screw: M8
Tightening torque: 6.0 [N m]
(53.1 [lb in])
Terminal block screw: M8
Tightening torque: 6.0 [N m]
(53.1 [lb in])
Mounting screw
Screw size: M5
Tightening torque: 3.2 [N m]
(28.3 [lb in])
UVW
13 - 67
13. SERVO AMPLIFIERS WITH A LARGE CAPACITY
(
30k TO 55kW
)
13.8 Characteristics
13.8.1 Overload protection characteristics
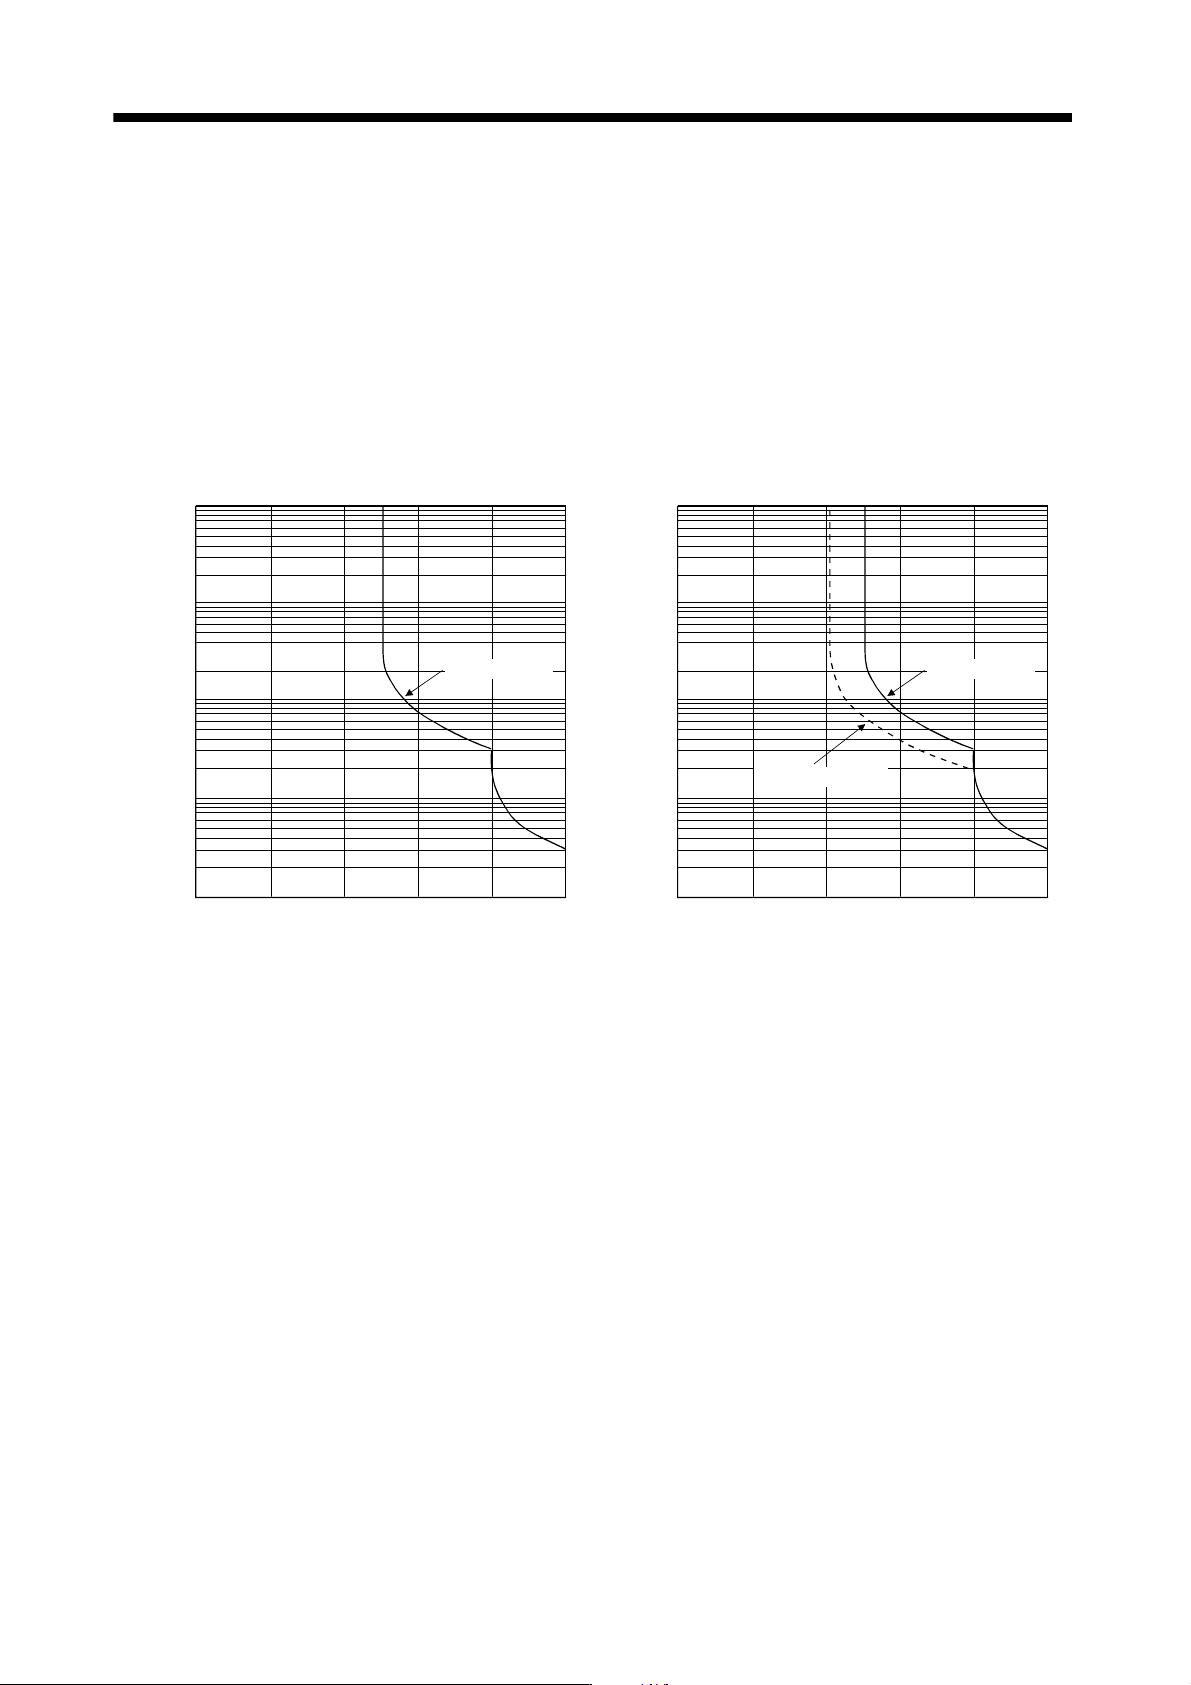
An electronic thermal relay is built in the converter unit and drive unit to protect the servo motor, converter unit
and drive unit from overloads.
Overload 1 alarm (50) occurs if overload operation performed is above the electronic thermal relay protection
curve shown below. Overload 2 alarm (51) occurs if the maximum current flew continuously for several
seconds due to machine collision, etc. Use the equipment on the left-hand side area of the continuous or
broken line in the graph.
It is recommended to use the machine which generates unbalanced torque, e.g. a vertical lift application, so
that the unbalanced torque is not more than 70% of the rated torque.
10000
1000
100
10
1
0 100 200 250
During rotation
(Note 2)
Operation time [s]
Load ratio [%]
Converter unit
10000
1000
100
10
1
0 100 200 250
During servo lock
During rotation
(Note 2)
Operation time [s]
(Note 1) Load ratio [%]
Drive unit
Note 1. If operation that generates torque more than 100% of the rating is performed with an abnormally high frequency in a servo motor
stop status (servo lock status) or in a 30r/min or less low-speed operation status, the drive unit may fail even when the electronic
thermal relay protection is not activated.
2. Load ratio 100% indicates the rated output of each converter unit and drive unit. Refer to section 13.1.4 for rated output.
Fig. 13.1 Overload protection characteristics
13 - 68
13. SERVO AMPLIFIERS WITH A LARGE CAPACITY
(
30k TO 55kW
)
13.8.2 Power supply equipment capacity and generated loss
POINT
The calculation method of heat dissipation area for enclosed control panel is
the same as that for servo amplifiers with 22kW or less. Refer to section 10.2
(2).
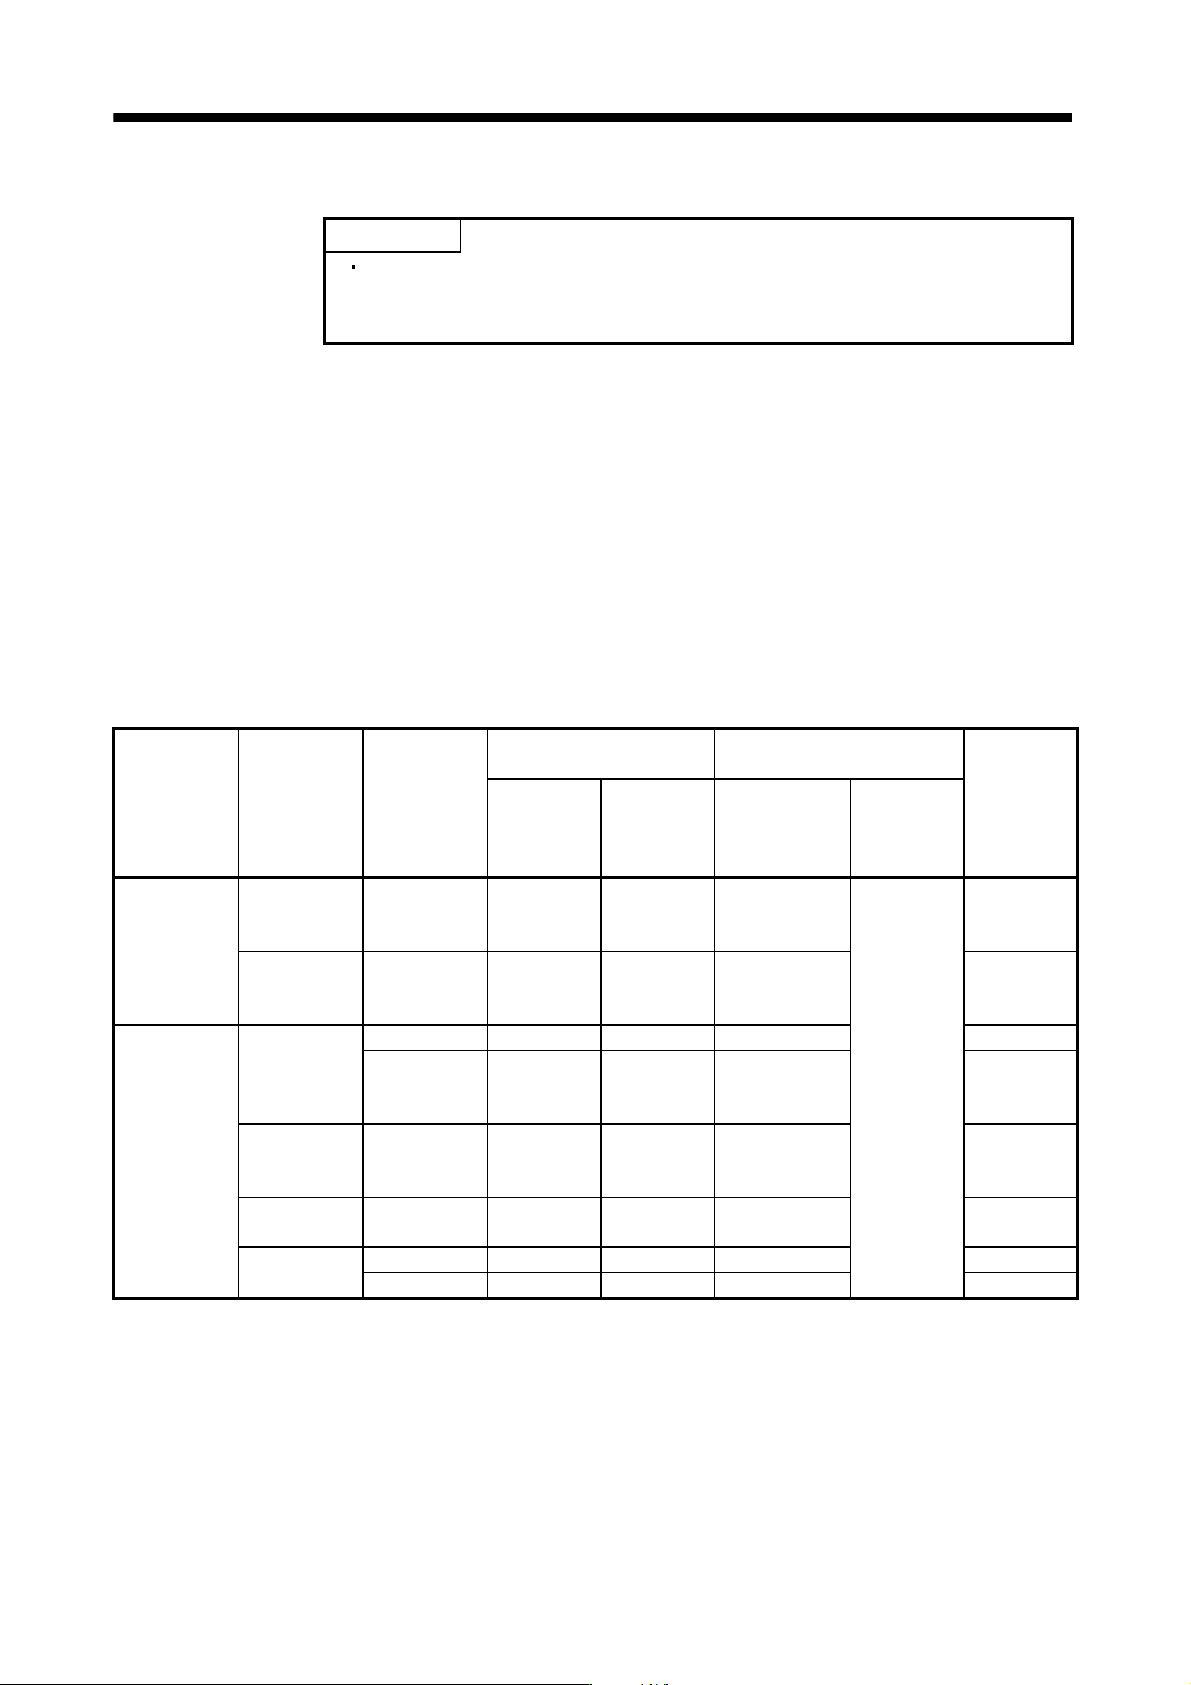
Table 13.1 indicates the generated loss and power supply capacity under rated load per combination of the
converter unit and drive unit. When the servo motors is run at less than the maximum speed, the power supply
equipment capacity is lower than the value in the table but the heat generated does not change.
Since the servo motor requires 2 to 2.5 times greater instantaneous power for acceleration, use the power
supply which ensures that the voltage lies within the permissible voltage fluctuation at the main circuit power
supply terminals (L
1
, L
2
, L
3
) of the converter unit. The power supply equipment capacity changes with the power
supply impedance.
The actually generated heat falls within the ranges at rated torque and at zero torque according to the
frequencies of use during operation. When designing an enclosed control box, use the values in the table,
considering the worst operating conditions. The generated heat in Table 13.1 does not include heat produced
during regeneration.
Table 13.1 Power supply capacity and generated heat per servo amplifier at rated output
Converter unit Drive unit Servo motor
Power supply
capacity [kVA]
(Note)
Drive unit-generated heart[W]
Area required
for heat
dissipation
[m
2
]
Power factor
improving DC
reactor is not
used
Power factor
improving DC
reactor is used
At rated torque At zero torque
MR-J3-CR55K
MR-J3-DU30KB
HA-LP30K1
HA-LP30K1M
HA-LP30K2
48 40 1550(1100+450) 31.0
MR-J3-DU37KB
HA-LP37K1
HA-LP37K1M
HA-LP37K2
59 49 1830(1280+550) 36.6
MR-J3-CR55K4
MR-J3-
DU30KB4
HA-LP25K14 40 35 1080(850+230) 21.6
HA-LP30K14
HA-LP30K1M4
HA-LP30K24
48 40 1290(1010+280) 60(30+30) 25.8
MR-J3-
DU37KB4
HA-LP37K14
HA-LP37K1M4
HA-LP37K24
59 49 1542(1200+342) 30.8
MR-J3-
DU45KB4
HA-LP45K1M4
HA-LP45K24
71 59 1810(1370+440) 36.2
MR-J3-
DU55KB4
HA-LP50K1M4 80 67 2120(1650+470) 42.4
HA-LP55K24 87 72 2150(1650+500) 43.0
Note. The heat generated by the drive unit is indicated in the left term within the parentheses, and the heat generated by the converter
unit in the right term.