sh030051g.pdf - 第65页
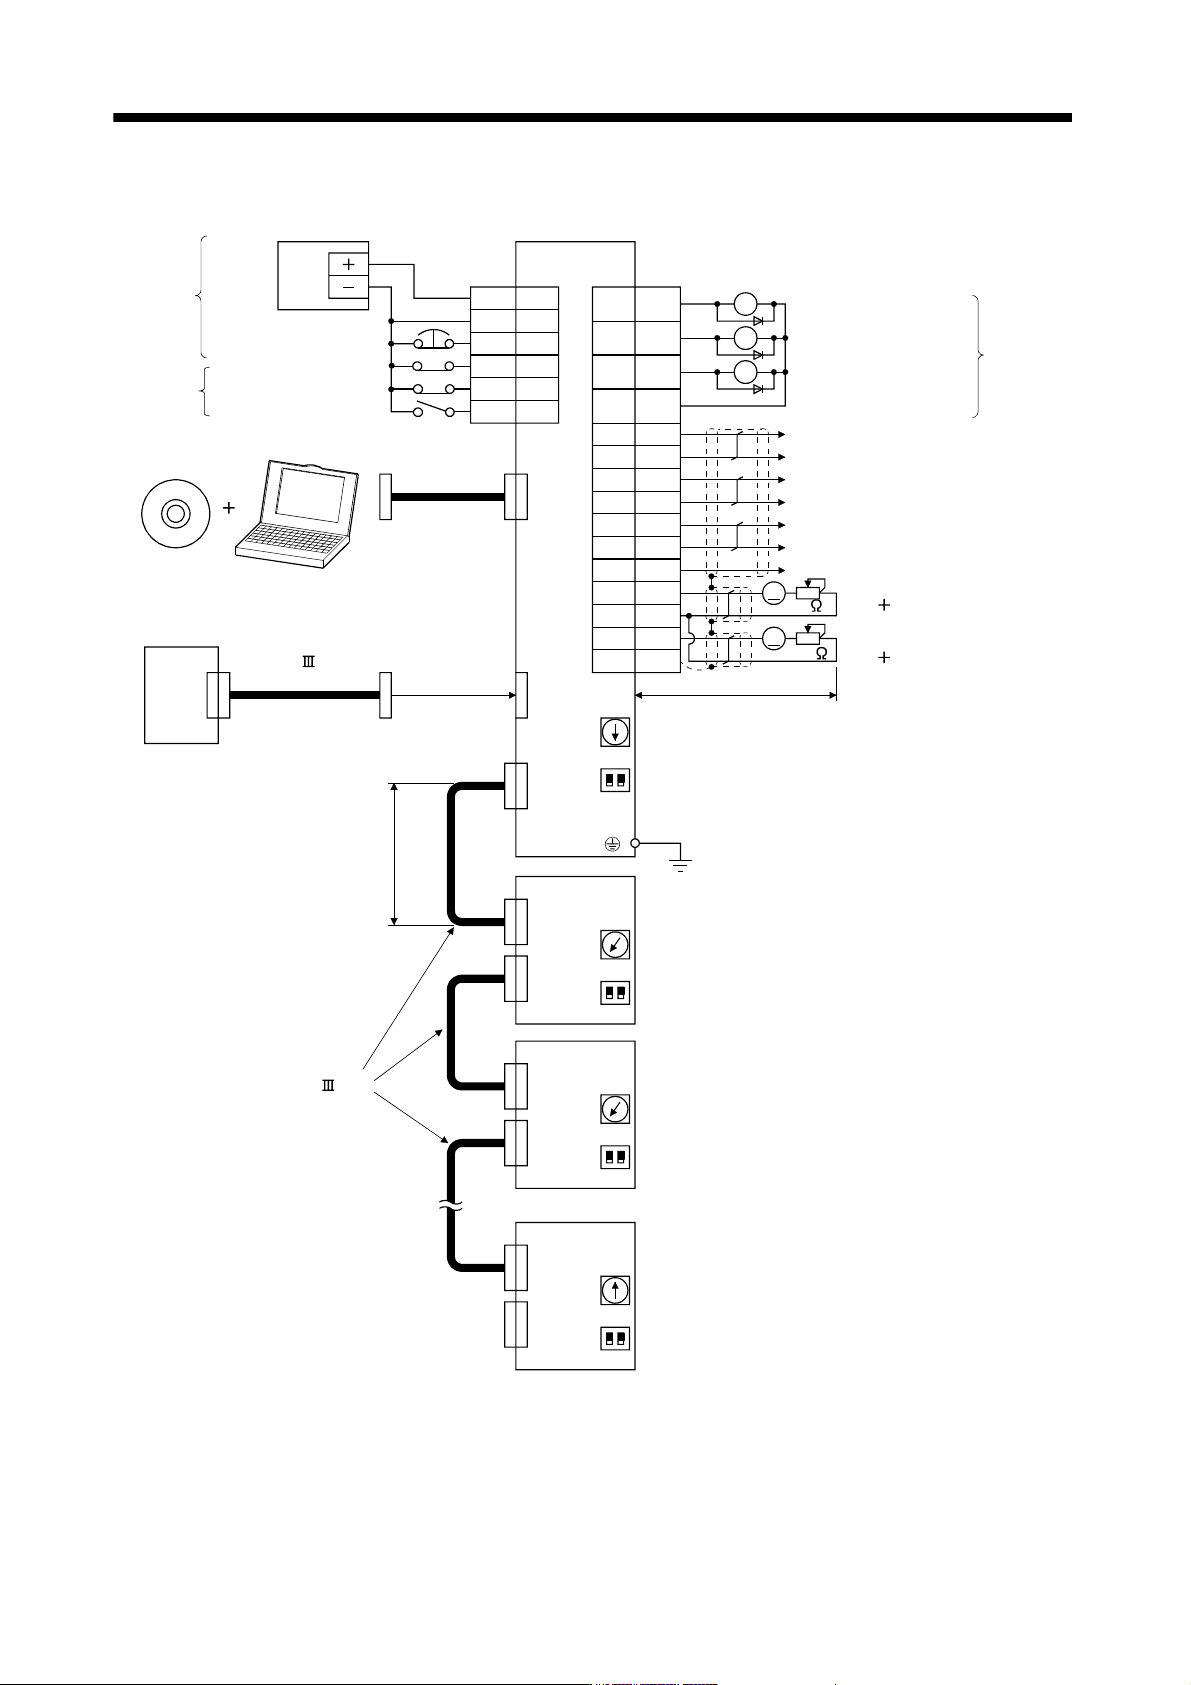
3 - 10 3. SIGNALS AND WI RING 3.2 I/O signal connection example 13 9 15 10 6 16 7 17 2 12 19 CN3 Encoder Z-phase pulse (differentia l line driv er) 2m Max (Note 12) (Note 5) MR Configurator Personal computer Magnetic bra…
3 - 9
3. SIGNALS AND WIRING
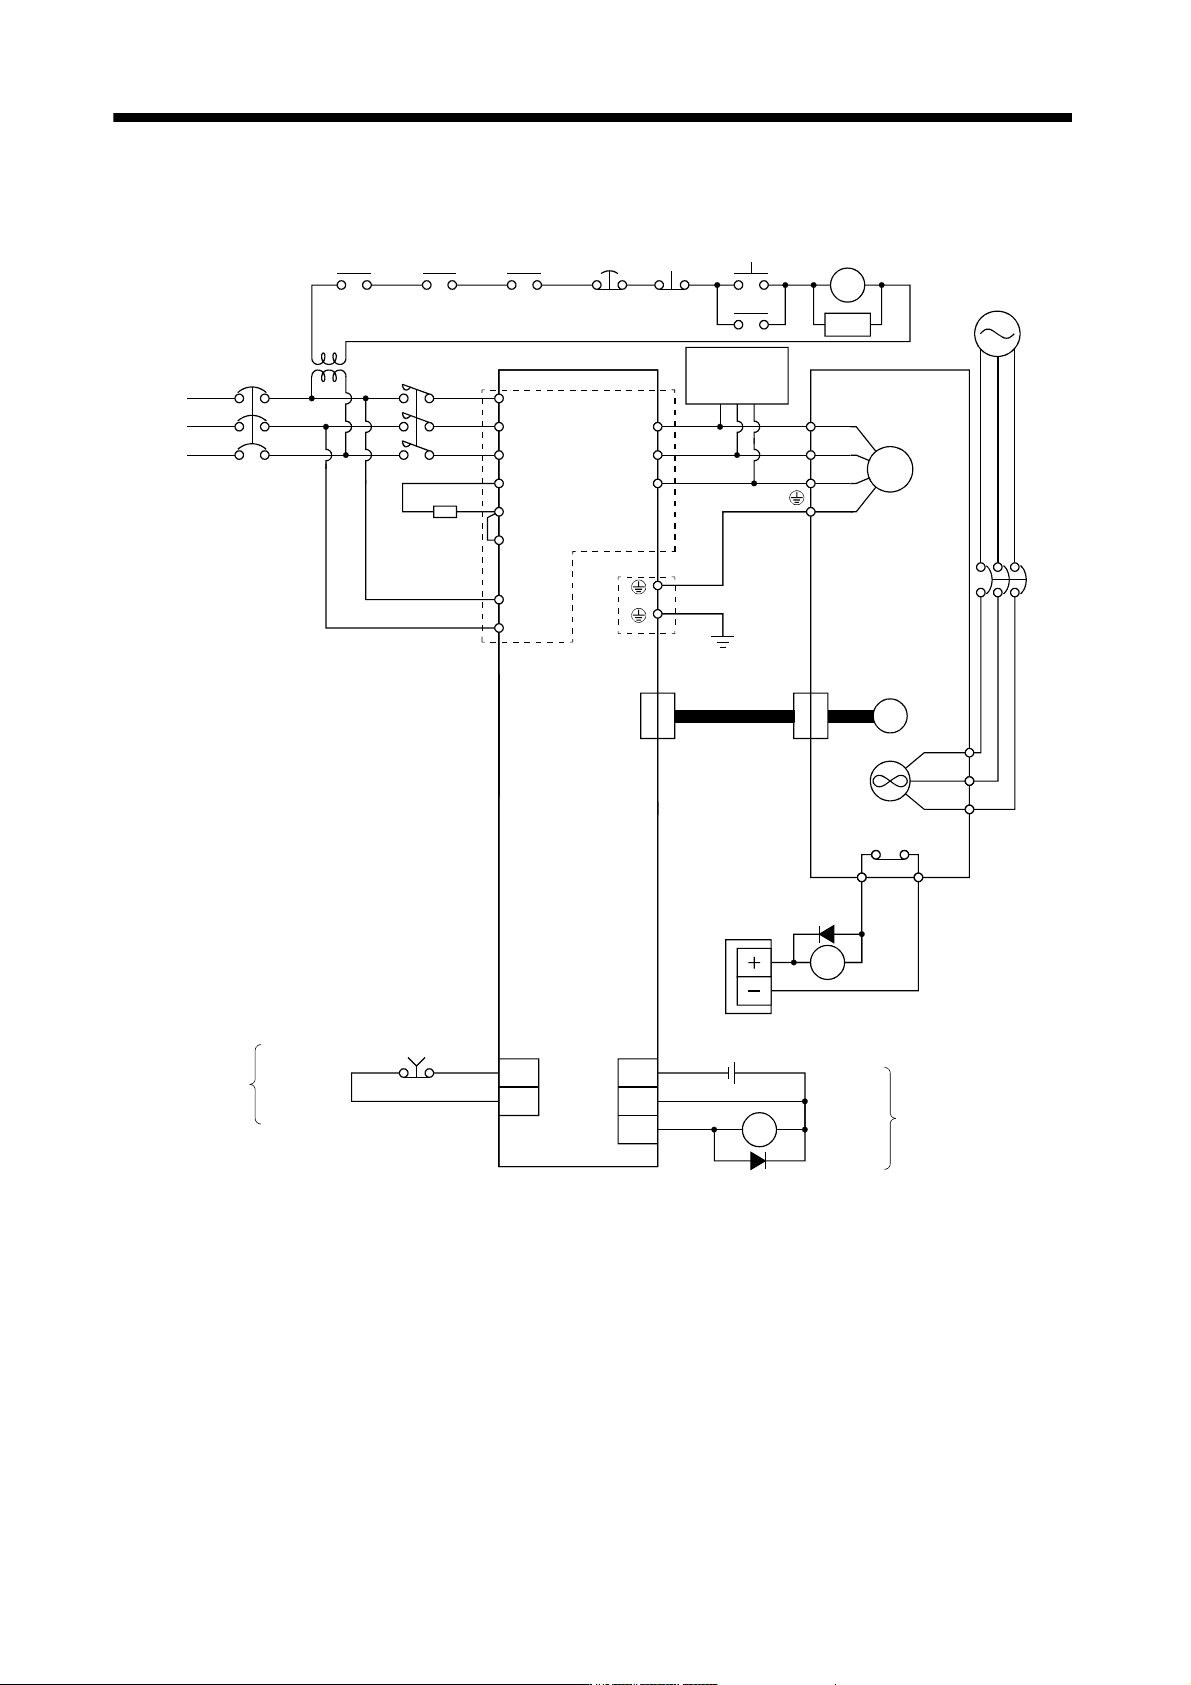
(8) MR-J3-11KB4 to MR-J3-22KB4
BW
BV
BU
Cooling fan
(Note 7)
(Note 8)
Cooling fan
power supply
Dynamic
break
(Option)
OFF
Forced
stop
ON
MC
MC
SK
(Note 4)
Alarm
RA1
Controller
forced stop
RA2
Servo amplifier
NFB MC
L
1
L2
L
3
3-phase
380 to
480VAC
P
C
TE1
PE
L
11
L
21
U
V
W
M
Encoder
CN2
(Note 3)
Encoder cable
(Note 6)
P
1
(Note 1)
(Note 2)
Regenerative
resistor
24VDC
power supply
OHS2OHS1
Servo motor
thermal relay
Servo motor
thermal relay
RA3
RA3
U
V
W
Servo motor
EM1
ALM RA1
DICOM
DOCOM
24VDC
DOCOM
Forced stop
CN3CN3
(Note 5)
Trouble
(Note 4)
(Note 5)
(Note 9)
Stepdown
transformer
NFB
Note 1. Always connect P1 and P. (Factory-wired.) When using the power factor improving DC reactor, refer to section 11.13.
2. When using the regenerative option, refer to section 11.2.
3. For the encoder cable, use of the option cable is recommended. Refer to section 11.1 for selection of the cable.
4. If deactivating output of trouble (ALM) with parameter change, configure up the power supply circuit which switches off the
magnetic contactor after detection of alarm occurrence on the controller side.
5. For the sink I/O interface. For the source I/O interface, refer to section 3.7.3.
6. Refer to section 3.10.
7. Servo amplifiers does not have BW when the cooling fan power supply is 1-phase.
8. For the cooling fan power supply, refer to section 3.10.2 (3) (b).
9. Stepdown transformer is required for coil voltage of magnetic contactor more than 200V class.
3 - 10
3. SIGNALS AND WIRING
3.2 I/O signal connection example
13
9
15
10
6
16
7
17
2
12
19
CN3
Encoder Z-phase pulse
(differential line driver)
2m Max
(Note 12)
(Note 5)
MR Configurator
Personal
computer
Magnetic brake interlock
CN5
Servo amplifier
CN1A
Servo system
controller
USB cable
MR-J3USBCBL3M
(option)
Trouble (Note 11)
In-position
CN3
(Note 12)
CN1A
CN1B
MR-J3-B
(2 axis)
(Note 7)
(Note 9)
Cap
(Note 1)
CN1B
SW1
21
SW2
SW1
21
SW2
Between electrodes
Control common
(Note 8)
(Note 8)
CN1A
CN1B
MR-J3-B
(Note 7)
SW1
21
SW2
(Note 8)
CN1A
CN1B
MR-J3-B
(Note 7)
SW1
21
SW2
(Note 8)
24VDC
Power
supply
(Note 10)
(Note 3,4)Forced stop
(Note 14)
(3 axis)
(n axis)
(Note 6 )
SSCNET cable
(option)
(Note 6)
SSCNET cable
(option)
Analog monitor 2
Max. 1mA meter
both directions
Analog monitor 1
Max. 1mA meter
both directions
10k
Encoder B-phase pulse
(differential line driver)
Encoder A-phase pulse
(differential line driver)
A
A
10k
(Note 15)
RA3
RA2
RA1
DICOM
DOCOM
EM1
DI1
DI2
DI3
5
3
20
DICOM
MBR
INP
ALM
LA
LAR
LB
LBR
8LZ
18 LZR
11 LG
4MO1
1LG
14 MO2
Plate SD
(Note 2)
(Note 13,14)
Upper stroke limit (FLS)
Lower stroke limit (RLS)
Proximity dog (DOG)
3 - 11
3. SIGNALS AND WIRING
Note 1 To prevent an electric shock, always connect the protective earth (PE) terminal (terminal marked ) of the servo amplifier to the
protective earth (PE) of the control box.
2. Connect the diode in the correct direction. If it is connected reversely, the servo amplifier will be faulty and will not output
signals, disabling the forced stop (EM1) and other protective circuits.
3. If the controller does not have an forced stop (EM1) function, always install a forced stop switch (Normally closed).
4. When starting operation, always turn on the forced stop (EM1). (Normally closed contacts) By setting "
1 " in DRU
parameter No.PA04 of the drive unit, the forced stop (EM1) can be made invalid.
5. Use MRZJW3-SETUP 221E.
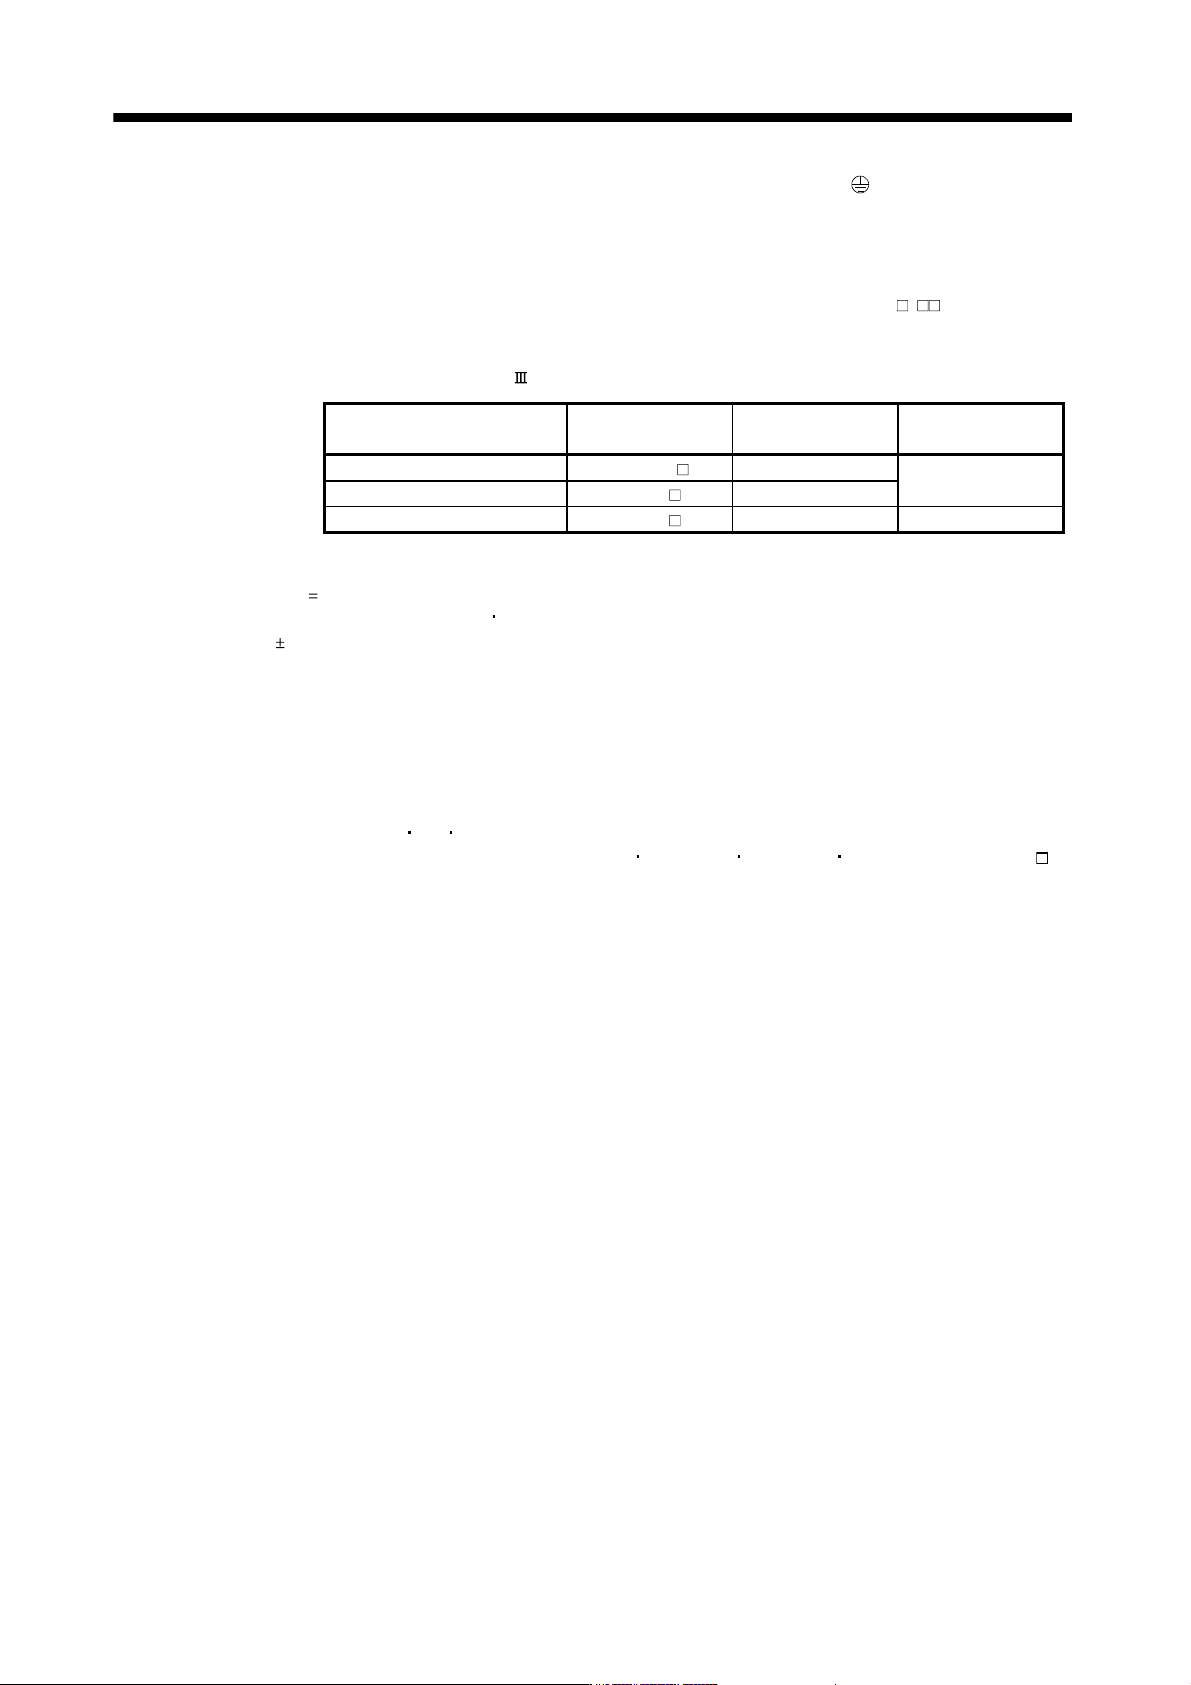
6. For the distance between electrodes of SSCNET
cable, refer to the following table.
Cable Cable model name Cable length
Distance between
electrodes
Standard code inside panel MR-J3BUS M 0.15m to 3m
20m
Standard cable outside panel MR-J3BUS M-A 5m to 20m
Long-distance cable MR-J3BUS M-B 30m to 50m 50m
7. The wiring of the second and subsequent axes is omitted.
8. Up to eight axes (n
1 to 8) may be connected. Refer to section 3.13 for setting of axis selection.
9. Make sure to put a cap on the unused CN1A
CN1B.
10. Supply 24VDC
10% 150mA current for interfaces from the outside. 150mA is the value applicable when all I/O signals are
used. The current capacity can be decreased by reducing the number of I/O points. Refer to section 3.7.2 (1) that gives the
current value necessary for the interface.
11. Trouble (ALM) turns on in normal alarm-free condition. When this signal is switched off (at occurrence of an alarm), the output
of the programmable controller should be stopped by the sequence program.
12. The pins with the same signal name are connected in the servo amplifier.
13. The signal can be changed by parameter No.PD07, PD08, PD09.
14. For the sink I/O interface. For the source I/O interface, refer to section 3.7.3.
15. Devices can be assigned for DI1
DI2 DI3 with controller setting. For devices that can be assigned, refer to the controller
instruction manual. The assigned devices are for the Q173DCPU
Q172DCPU Q173HCPU Q172HCPU and QD75MH .