sh030051g.pdf - 第81页
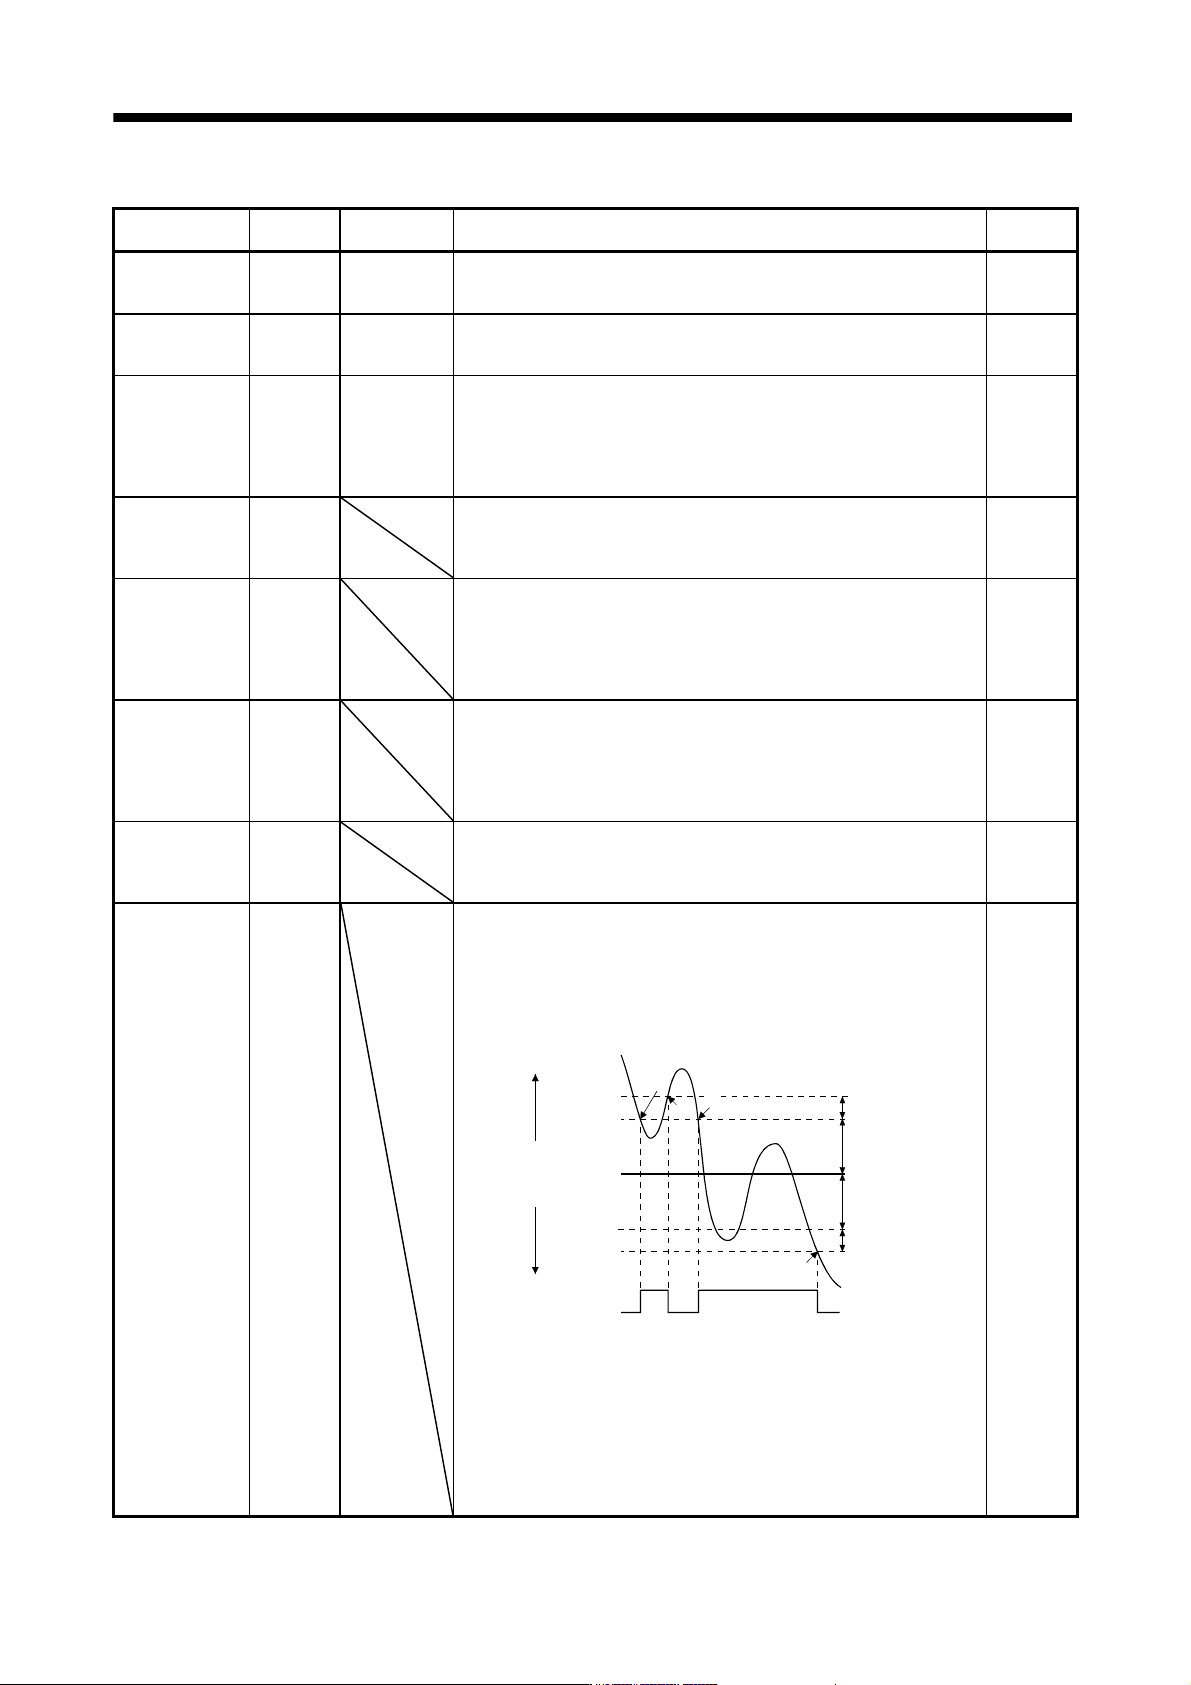
3 - 26 3. SIGNALS AND WI RING Device Symbol Connector pin No. Function/Application I/O division Warning WNG When using this signal, make it us able by the setting of para meter No.PD07 to PD09. When warning has occurred,…
3 - 25
3. SIGNALS AND WIRING
(b) Output device
Device Symbol
Connector
pin No.
Function/Application
I/O
division
Trouble ALM CN3-15 ALM turns off when power is switched off or the protective circuit is
activated to shut off the base circuit.
Without alarm occurring, ALM turns on within about 1s after power-on.
DO-1
Electromagnetic
brake interlock
MBR CN3-13 When using this signal, set operation delay time of the electromagnetic
brake in parameter No.PC02.
In the servo-off or alarm status, MBR turns off.
DO-1
In-position
(Positioning
completed)
INP CN3-9 INP turns on when the number of droop pulses is in the preset in-position
range. The in-position range can be changed using parameter No.PA10.
When the in-position range is increased, INP may be on conductive
status during low-speed rotation.
INP turns on when servo on turns on.
This signal cannot be used in the speed loop mode.
DO-1
Ready RD When using the signal, make it usable by the setting of parameter
No.PD07 to PD09.
RD turns on when the servo is switched on and the servo amplifier is
ready to operate.
DO-1
Dynamic brake
interlock
DB When using the signal, make it usable by the setting of parameter
No.PD07 to PD09. DB turns off simultaneously when the dynamic brake
is operated. When using the external dynamic brake on the servo
amplifier of 11 kW or more, this device is required. (Refer to section
11.6.) For the servo amplifier of 7kW or less, it is not necessary to use
this device.
DO-1
Speed reached SA When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
When the servo is off, SA will be turned OFF. When servo motor rotation
speed becomes approximately setting speed, SA will be turned ON.
When the preset speed is 20r/min or less, SA always turns on. This
signal cannot be used in position loop mode.
DO-1
Limiting torque TLC When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
When torque is produced level of torque set with controller, TLC will be
turned ON. When the servo is off, TLC will be turned OFF.
DO-1
Zero speed ZSP
When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
When the servo is off, SA will be turned OFF.
ZSP turns on when the servo motor speed is zero speed (50r/min) or
less. Zero speed can be changed using parameter No.PC07.
Example
Zero speed is 50r/min
OFF
ON
0r/min
1)
3)
2)
4)
Forward
rotation
direction
Servo motor
speed
Reverse
rotation
direction
zero speed
(ZSP)
ON level
50r/min
OFF level
70r/min
ON level
50r/min
OFF level
70r/min
Parameter
No.PC07
20r/min
(Hysteresis width)
20r/min
(Hysteresis width)
Parameter
No.PC07
ZPS turns on
1)
when the servo motor is decelerated to 50r/min, and
ZPS turns off
2)
when the servo motor is accelerated to 70r/min again.
ZPS turns on
3)
when the servo motor is decelerated again to 50r/min,
and turns off
4)
when the servo motor speed has reached -70r/min.
The range from the point when the servo motor speed has reached ON
level, and ZPS turns on, to the point when it is accelerated again and has
reached OFF level is called hysteresis width.
Hysteresis width is 20r/min for the MR-J3-B servo amplifier.
DO-1
3 - 26
3. SIGNALS AND WIRING
Device Symbol
Connector
pin No.
Function/Application
I/O
division
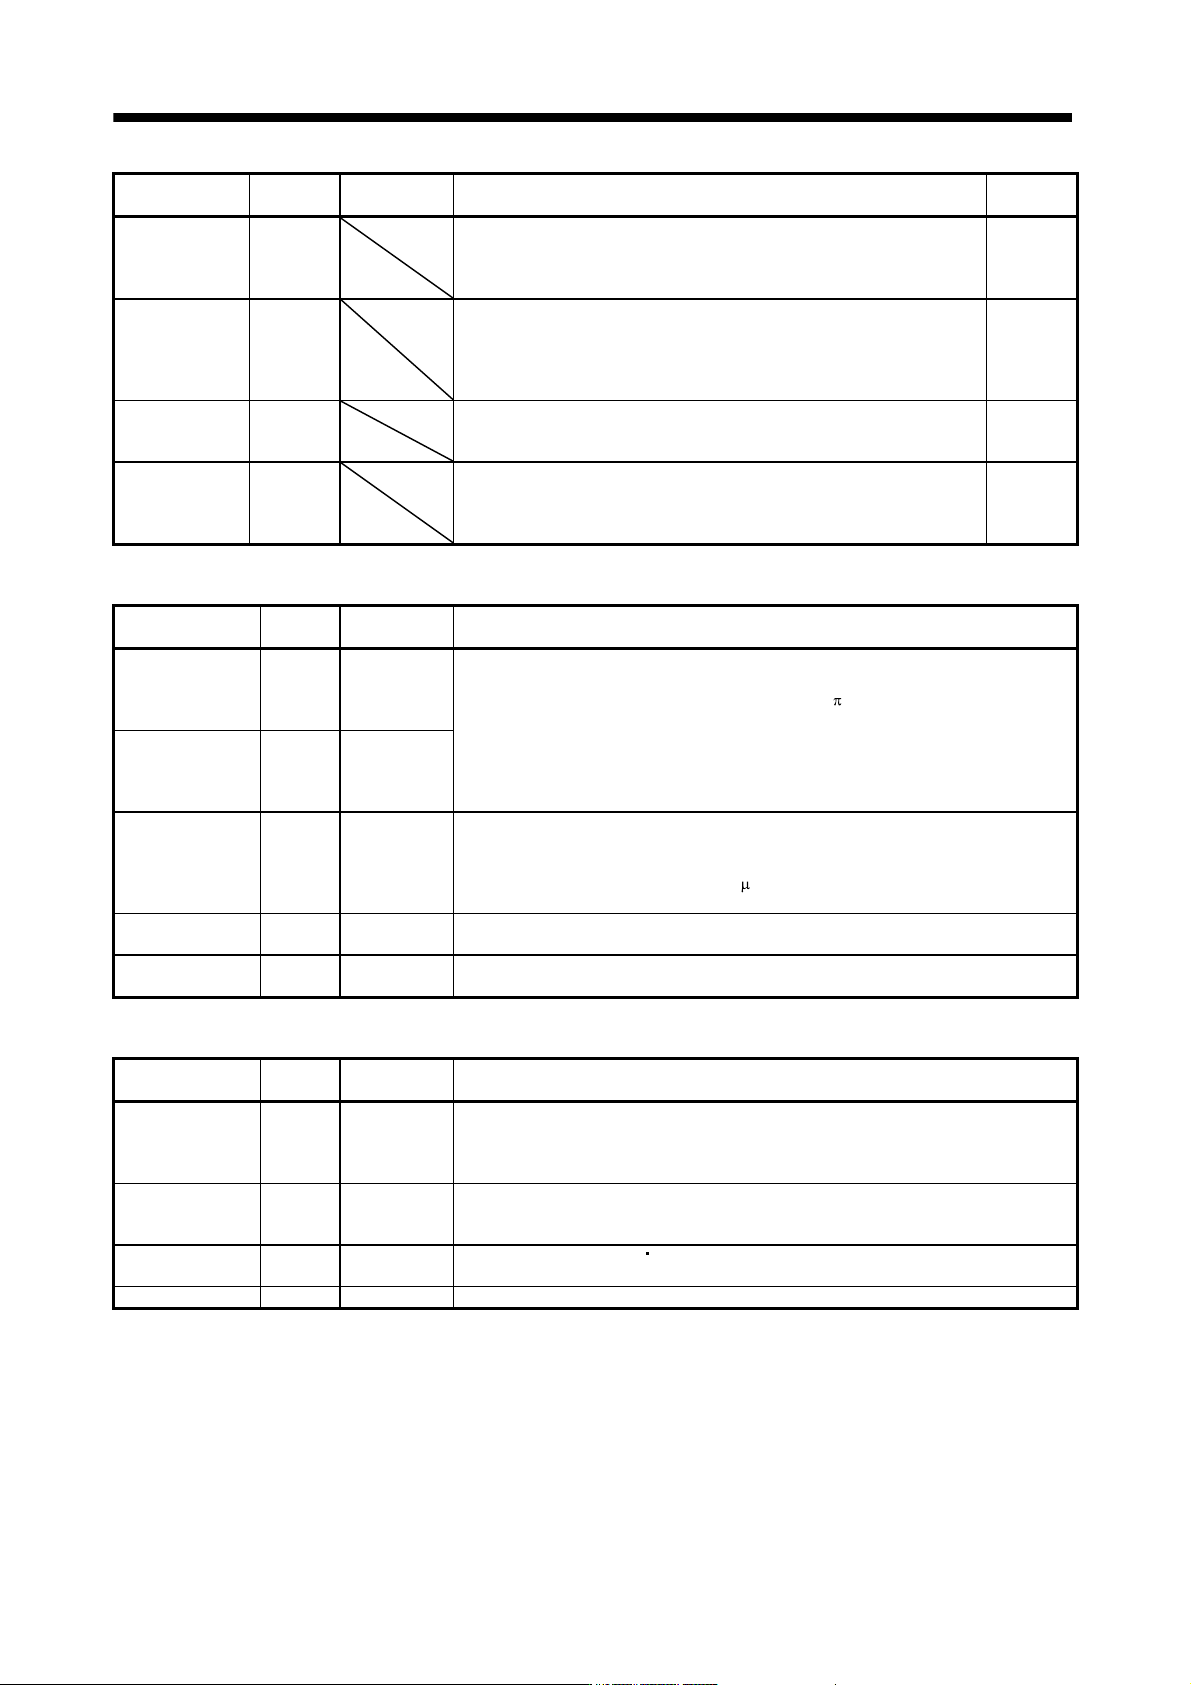
Warning WNG
When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
When warning has occurred, WNG turns on. When there is no warning,
WNG turns off within about 1.5s after power-on.
DO-1
Battery warning BWNG
When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
BWNG turns on when battery cable disconnection warning (92) or battery
warning (9F) has occurred. When there is no battery warning, BWNG
turns off within about 1.5s after power-on.
DO-1
Variable gain
selection
CDPS
When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
CDPS is on during variable gain.
DO-1
Absolute position
erasing
ABSV
When using this signal, make it usable by the setting of parameter
No.PD07 to PD09.
ABSV turns on when the absolute position erased.
This signal cannot be used in position loop mode.
DO-1
(c) Output signals
Signal name Symbol
Connector
pin No.
Function/Application
Encoder A-phase
pulse
(Differential line
driver)
LA
LAR
CN3-6
CN3-16
Outputs pulses per servo motor revolution set in parameter No.PA15 in the differential
line driver system. In CCW rotation of the servo motor, the encoder B-phase pulse
lags the encoder A-phase pulse by a phase angle of
/2.
The relationships between rotation direction and phase difference of the A- and B-
phase pulses can be changed using parameter No.PC03.
Output pulse specification and dividing ratio setting can be set. (Refer to section
5.1.9.)
Encoder B-phase
pulse
(Differential line
driver)
LB
LBR
CN3-7
CN3-17
Encoder Z-phase
pulse
(Differential line
driver)
LZ
LZR
CN3-8
CN3-18
Outputs the zero-point signal in the differential line driver system of the encoder. One
pulse is output per servo motor revolution. turns on when the zero-point position is
reached.
The minimum pulse width is about 400
s. For home position return using this pulse,
set the creep speed to 100r/min. or less.
Analog monitor 1 MO1 CN3-4 Used to output the data set in parameter No.PC09 to across MO1-LG in terms of
voltage. Resolution 10 bits
Analog monitor 2 MO2 CN3-14 Used to output the data set in parameter No.PC10 to across MO2-LG in terms of
voltage. Resolution 10 bits
(d) Power supply
Signal name Symbol
Connector
pin No.
Function/Application
Digital I/F power
supply input
DICOM CN3-5
CN3-10
Used to input 24VDC (24VDC 10% 150mA) for I/O interface of the servo amplifier.
The power supply capacity changes depending on the number of I/O interface points
to be used. Connect the positive terminal of the 24VDC external power supply for the
sink interface.
Digital I/F common DOCOM CN3-3 Common terminal for input device such as EM1 of the servo amplifier. Pins are
connected internally. Separated from LG. Connect the positive terminal of the 24VDC
external power supply for the source interface.
Monitor common LG CN3-1
CN3-11
Common terminal of M01 M02
Pins are connected internally.
Shield SD Plate Connect the external conductor of the shield cable.
3 - 27
3. SIGNALS AND WIRING
3.6 Alarm occurrence timing chart
CAUTION
When an alarm has occurred, remove its cause, make sure that the operation
signal is not being input, ensure safety, and reset the alarm before restarting
operation.
As soon as an alarm occurs, make the Servo off status and interrupt the main
circuit power.
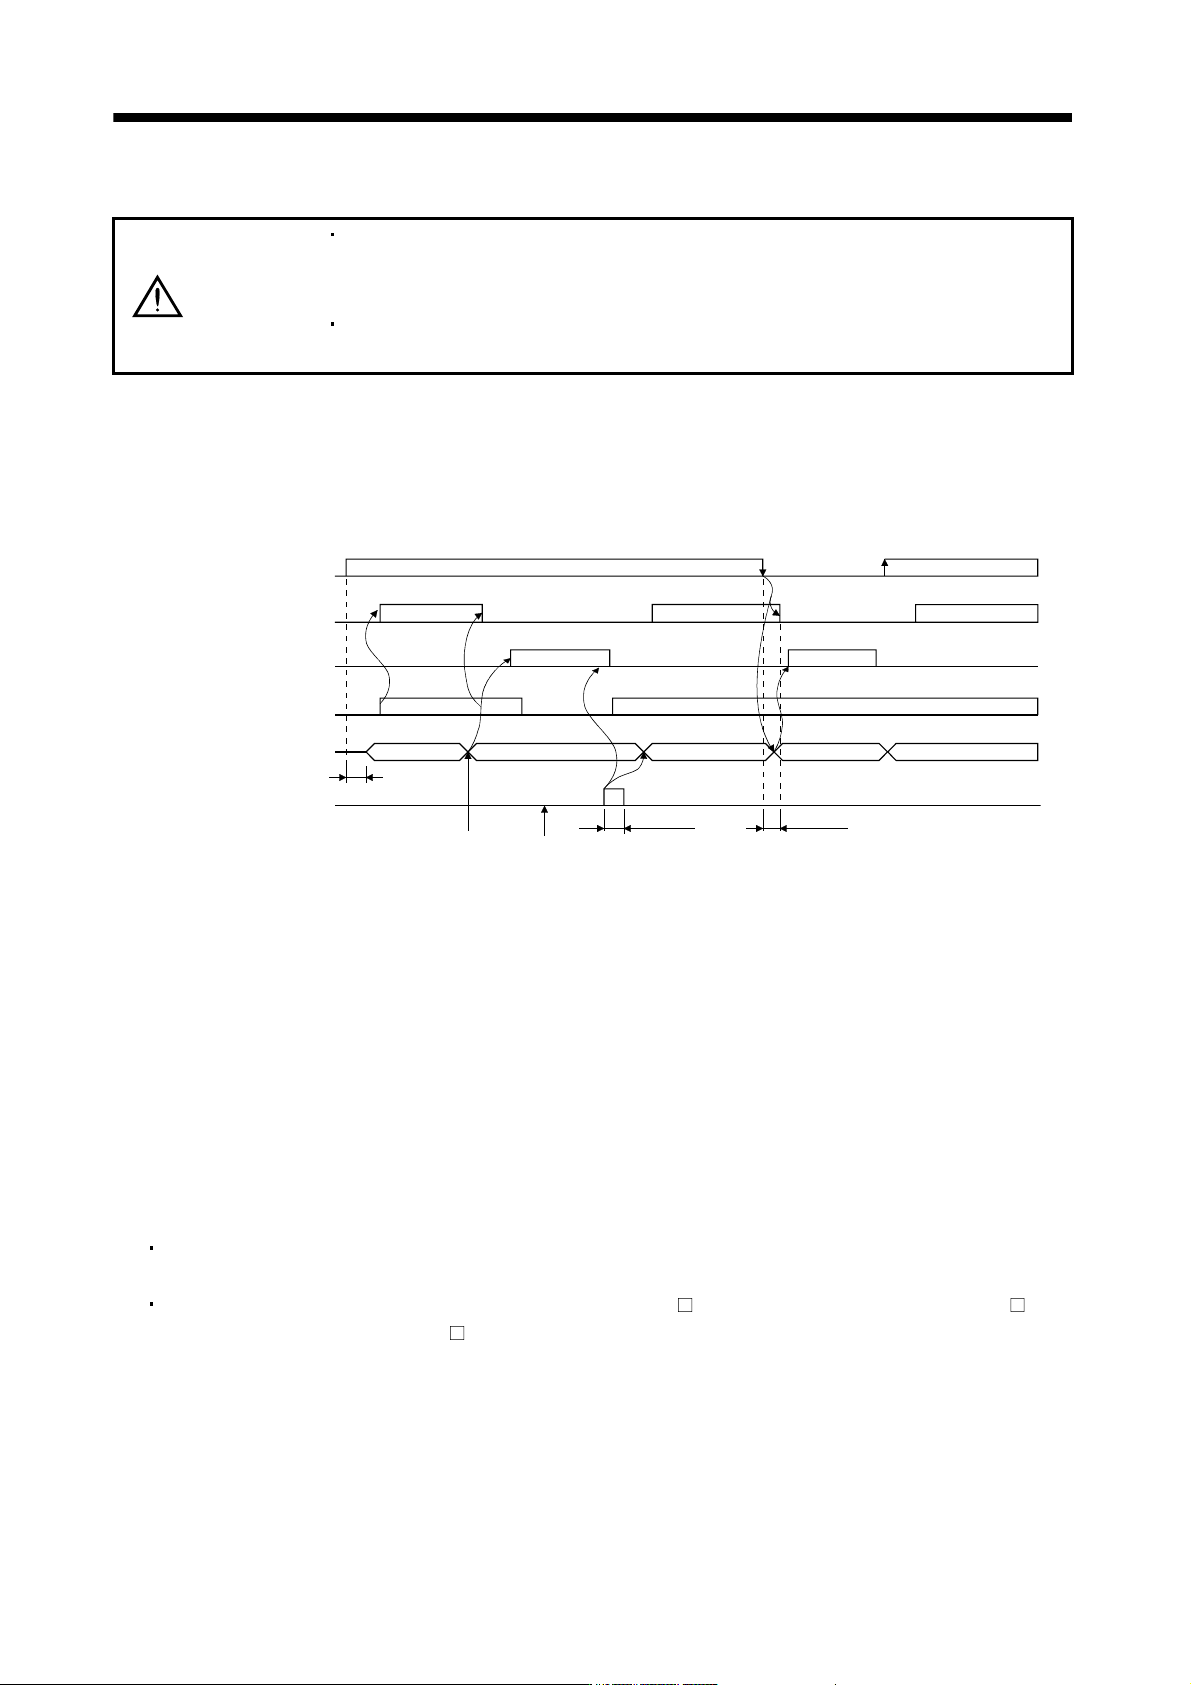
When an alarm occurs in the servo amplifier, the base circuit is shut off and the servo motor is coated to a stop.
Switch off the main circuit power supply in the external sequence. To deactivate the alarm, power the control
circuit off, then on or give the error reset or CPU reset command from the servo system controller. However,
the alarm cannot be deactivated unless its cause is removed.
ON
OFF
ON
OFF
ON
OFF
NO
YES
ON
OFF
1s
NO
YES
Main circuit
Control circuit
power
Base circuit
Dynamic brake
Servo-on command
(from controller)
Alarm
Reset command
(from controller)
Valid
Invalid
Alarm occurs.
Remove cause of trouble.
50ms or more
60ms or more
NO
Brake operation
Brake operation
Power on
Power off
(Note)
Note. Switch off the main circuit power as soon as an alarm occurs.
(1) Overcurrent, overload 1 or overload 2
If operation is repeated by switching control circuit power off, then on to reset the overcurrent (32), overload
1 (50) or overload 2 (51) alarm after its occurrence, without removing its cause, the servo amplifier and
servo motor may become faulty due to temperature rise. Securely remove the cause of the alarm and also
allow about 30 minutes for cooling before resuming operation.
(2) Regenerative alarm
If operation is repeated by switching control circuit power off, then on to reset the regenerative (30) alarm
after its occurrence, the external regenerative resistor will generate heat, resulting in an accident.
(3) Instantaneous power failure
Undervoltage (10) occurs when the input power is in either of the following statuses.
A power failure of the control circuit power supply continues for 60ms or longer and the control circuit is
not completely off.
The bus voltage dropped to 200VDC or less for the MR-J3- B, to 158VDC or less for the MR-J3- B1, or
to 380VDC or less for the MR-J3-
B4.